Related Experiment Videos
Fractional-Order PID Cooperative Pose Control of Multi-Agent Rigid-Body Systems on TSE(3)N
Mohammad Maadani1, Eric A Butcher1
1Department of Aerospace and Mechanical Engineering, University of Arizona, 1130 N. Mountain Ave., Tucson, AZ 85721, USA.

Abstract:
Fractional-order PID control extends conventional PID control by allowing the integral and derivative orders to take non-integer values, thereby introducing α and β as additional tuning parameters beyond the conventional PID gains. Two strategies for fractional-order PIβDα cooperative pose control of a multi-agent rigid body system are considered assuming both undirected and directed communication networks, together with Caputo fractional derivative and integral operators. The rigid-body pose configurations are described using exponential coordinates associated with the Lie group SE(3), while the state space is TSE(3)N. Analytical stability bounds are obtained using Matignon's theorem in terms of the proportional, derivative, and integral gains for the attitude and translational controllers, as well as the fractional orders, that guarantee global Mittag-Leffler stability. The fractional control strategy provides additional flexibility in tuning the closed-loop response beyond that of conventional integer-order PID control. Since the fractional derivative states are not directly measurable, a Luenberger observer is employed to estimate these states from the measurable pose exponential coordinates, and the resulting estimates are used in the implementation of the feedback protocols. Simulation examples of formation establishment further incorporate cohesion and collision-avoidance strategies based on artificial potential functions, illustrating the effectiveness and practical implementation of the proposed fractional PIβDα control protocols.
Related Concept Videos
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 00:49
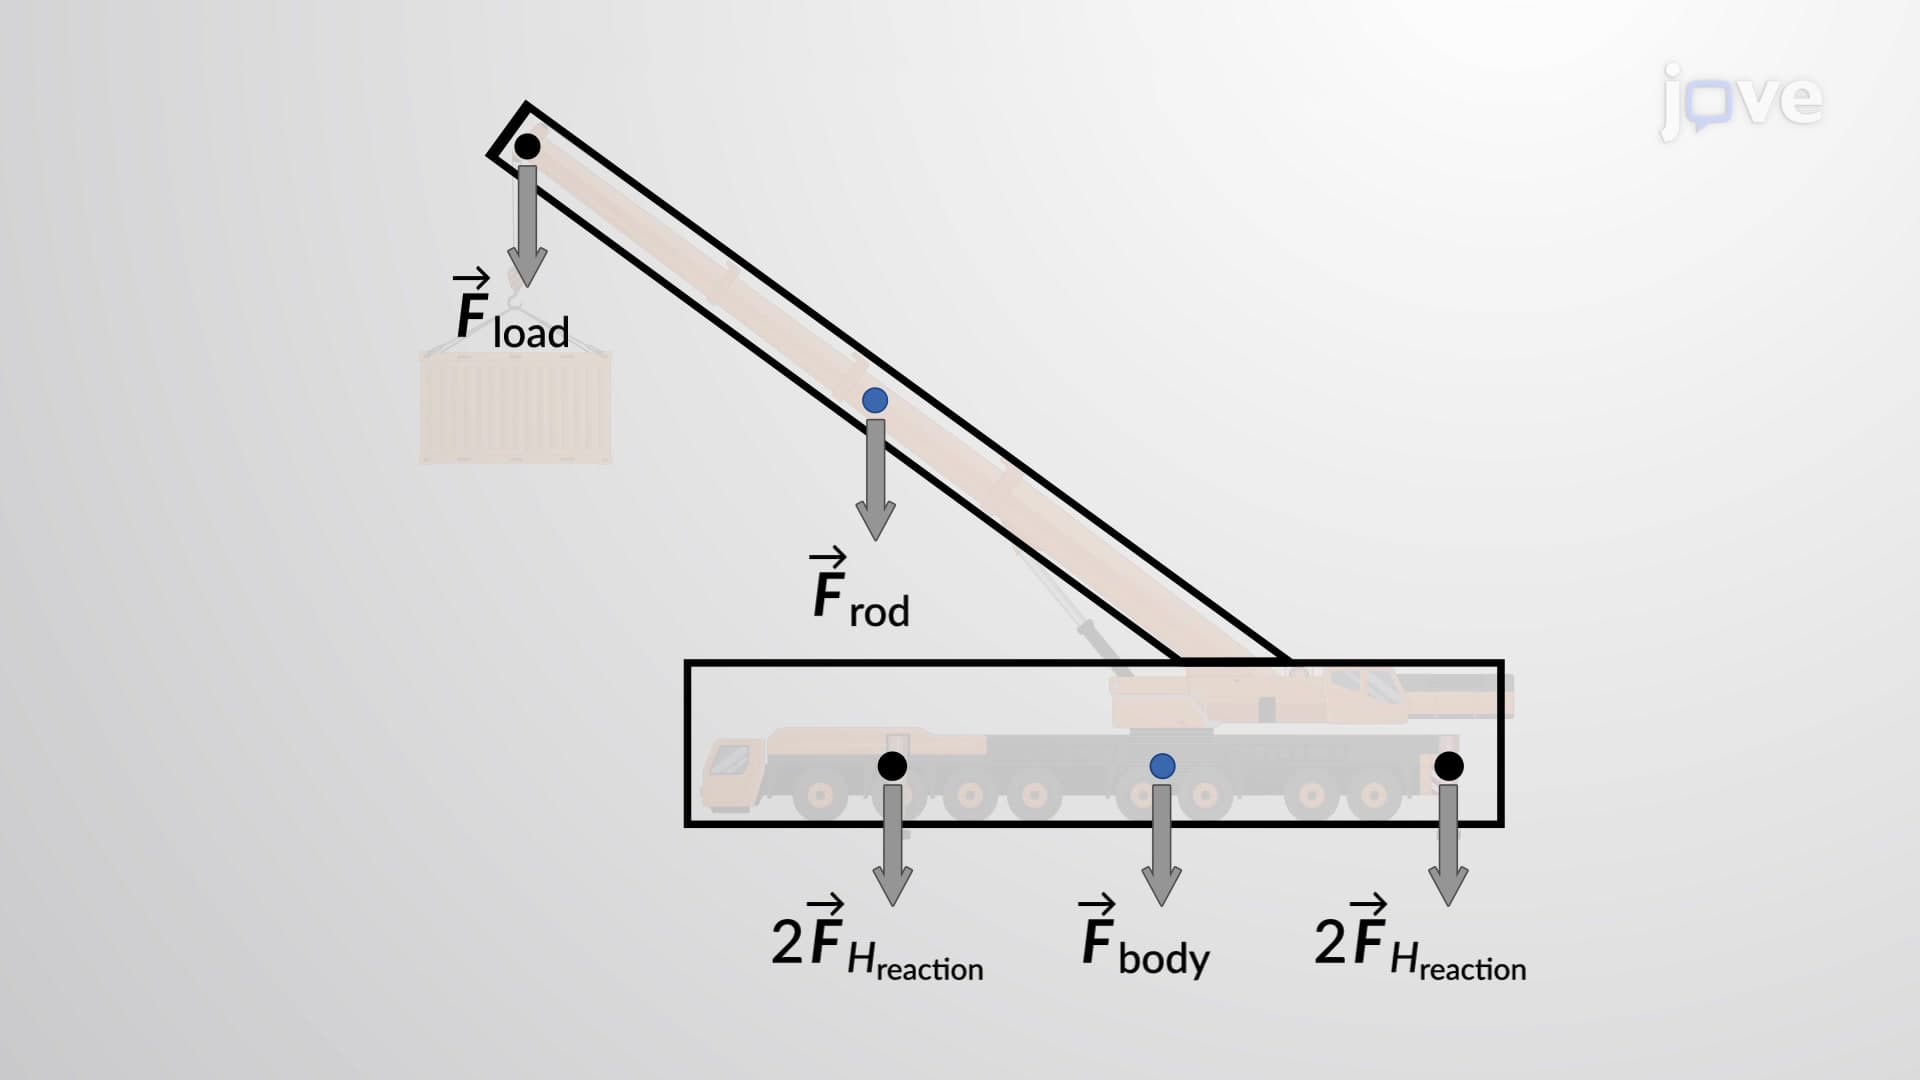
Rigid Body Equilibrium Problems - I