Related Experiment Video
Updated: Jun 15, 2026
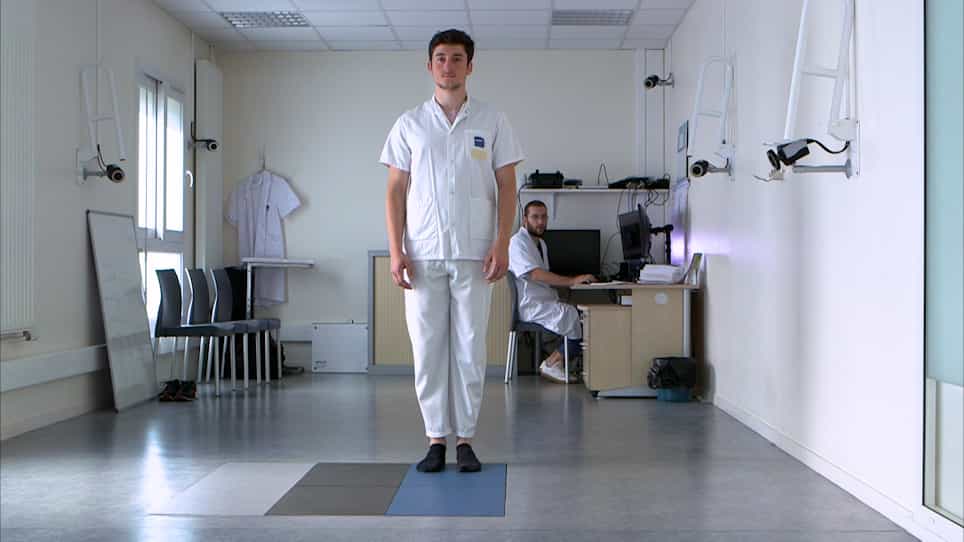

Postural Organization of Gait Initiation for Biomechanical Analysis Using Force Platform Recordings
Published on: July 26, 2022
Contributions of muscles and passive dynamics to swing initiation over a range of walking speeds
1Department of Mechanical Engineering, Clark Center, Room S-324, Stanford University, Mail Code 5450, 318 Campus Drive, Stanford, CA 94305-5450, USA. melanief@stanford.edu

Abstract:
Stiff-knee gait is a common walking problem in cerebral palsy characterized by insufficient knee flexion during swing. To identify factors that may limit knee flexion in swing, it is necessary to understand how unimpaired subjects successfully coordinate muscles and passive dynamics (gravity and velocity-related forces) to accelerate the knee into flexion during double support, a critical phase just prior to swing that establishes the conditions for achieving sufficient knee flexion during swing. It is also necessary to understand how contributions to swing initiation change with walking speed, since patients with stiff-knee gait often walk slowly. We analyzed muscle-driven dynamic simulations of eight unimpaired subjects walking at four speeds to quantify the contributions of muscles, gravity, and velocity-related forces (i.e. Coriolis and centrifugal forces) to preswing knee flexion acceleration during double support at each speed. Analysis of the simulations revealed contributions from muscles and passive dynamics varied systematically with walking speed. Preswing knee flexion acceleration was achieved primarily by hip flexor muscles on the preswing leg with assistance from biceps femoris short head. Hip flexors on the preswing leg were primarily responsible for the increase in preswing knee flexion acceleration during double support with faster walking speed. The hip extensors and abductors on the contralateral leg and velocity-related forces opposed preswing knee flexion acceleration during double support.
Related Concept Videos
 01:21
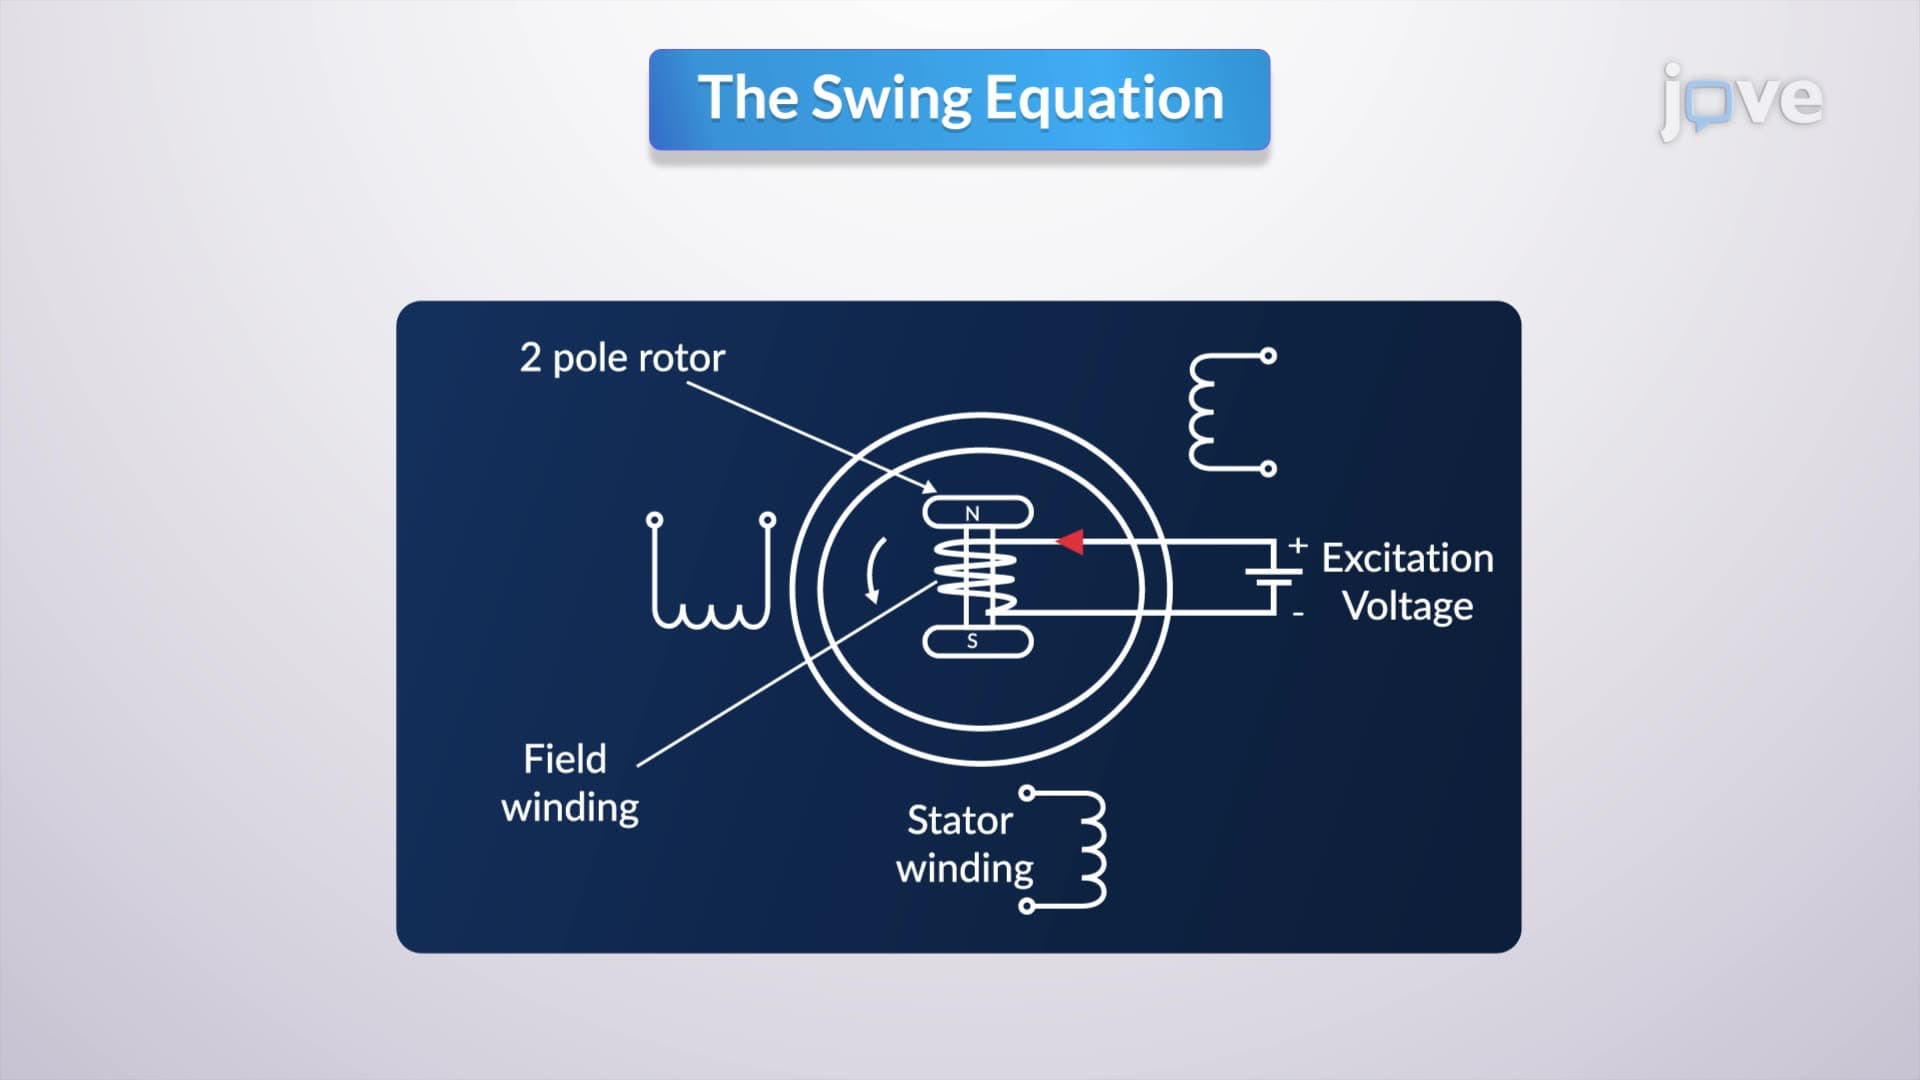
The Swing Equation
In a steady-state operation, the mechanical torque (Τm) supplied to the generator is balanced by the electrical torque (Τe)...
 01:20
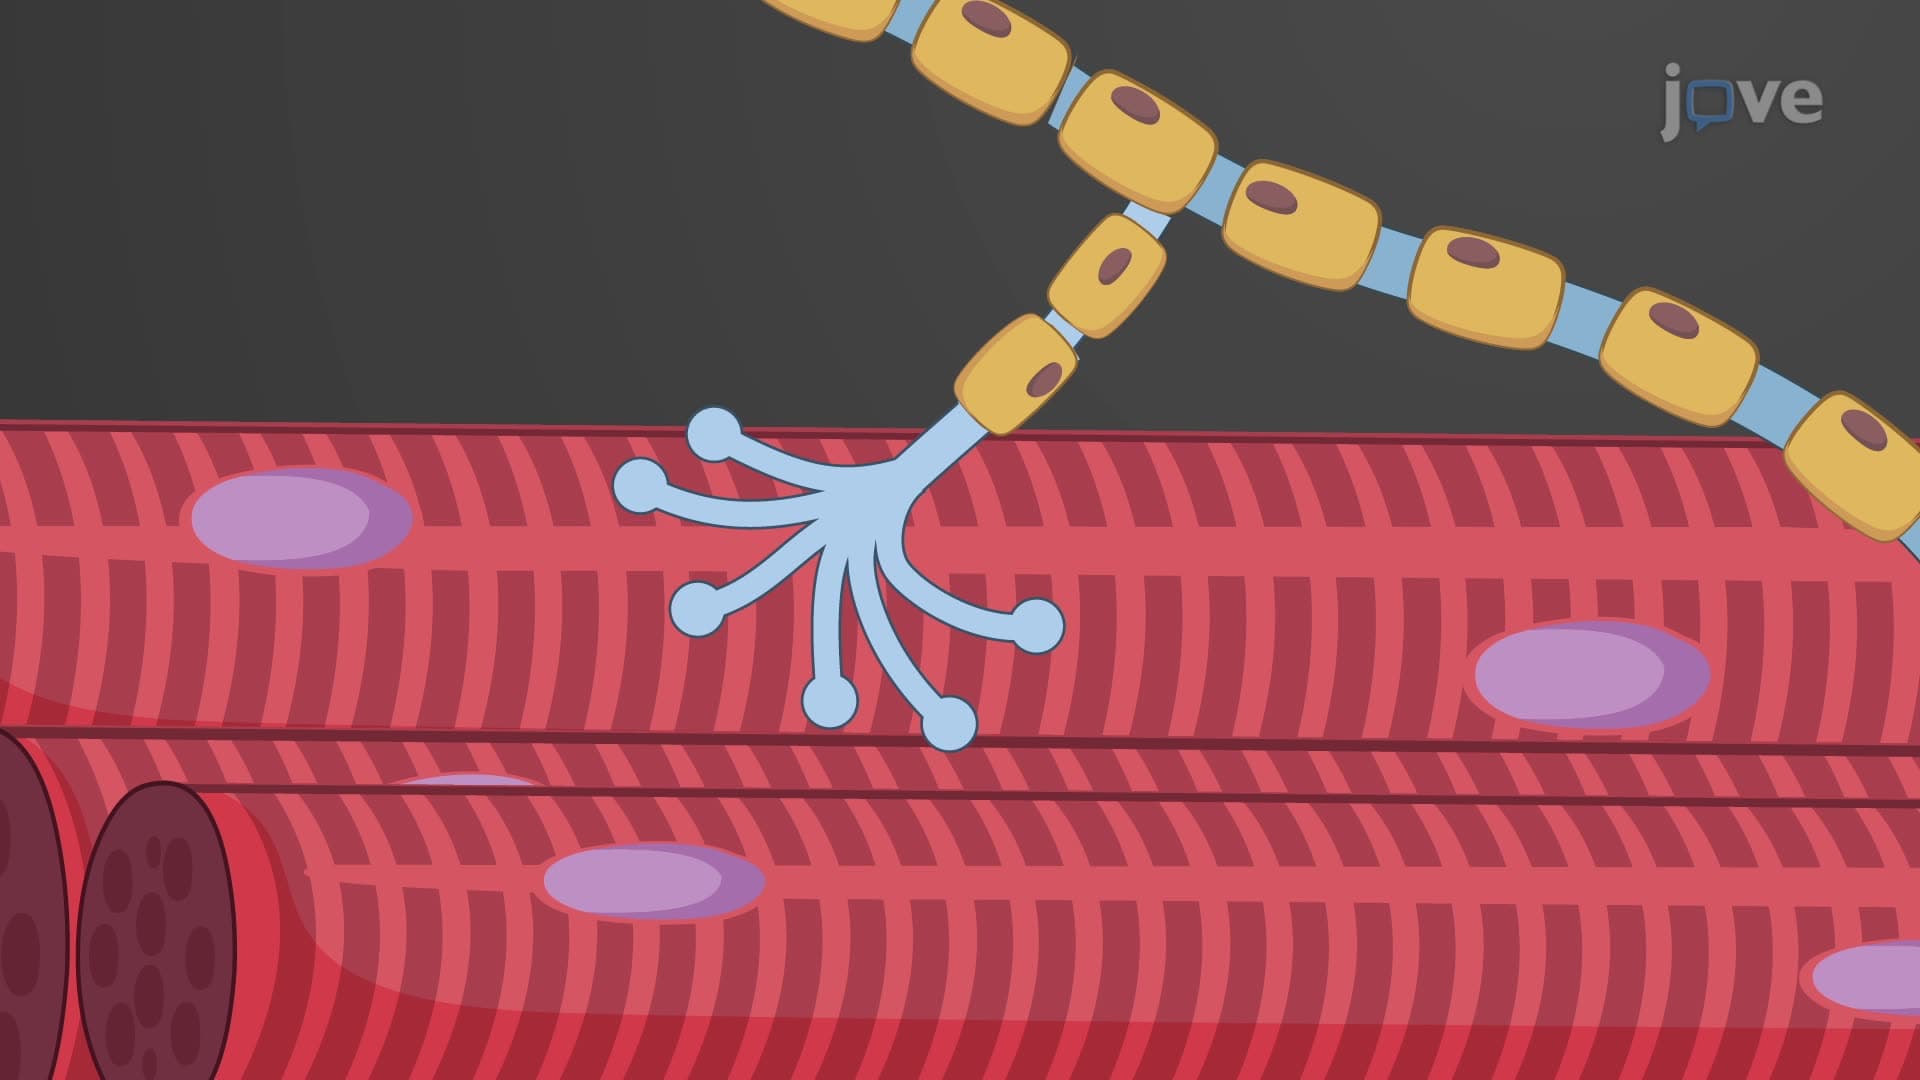
Excitation-Contraction Coupling in Skeletal Muscles
When an action potential...
 01:10
Relative Motion Analysis - Acceleration
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 00:58
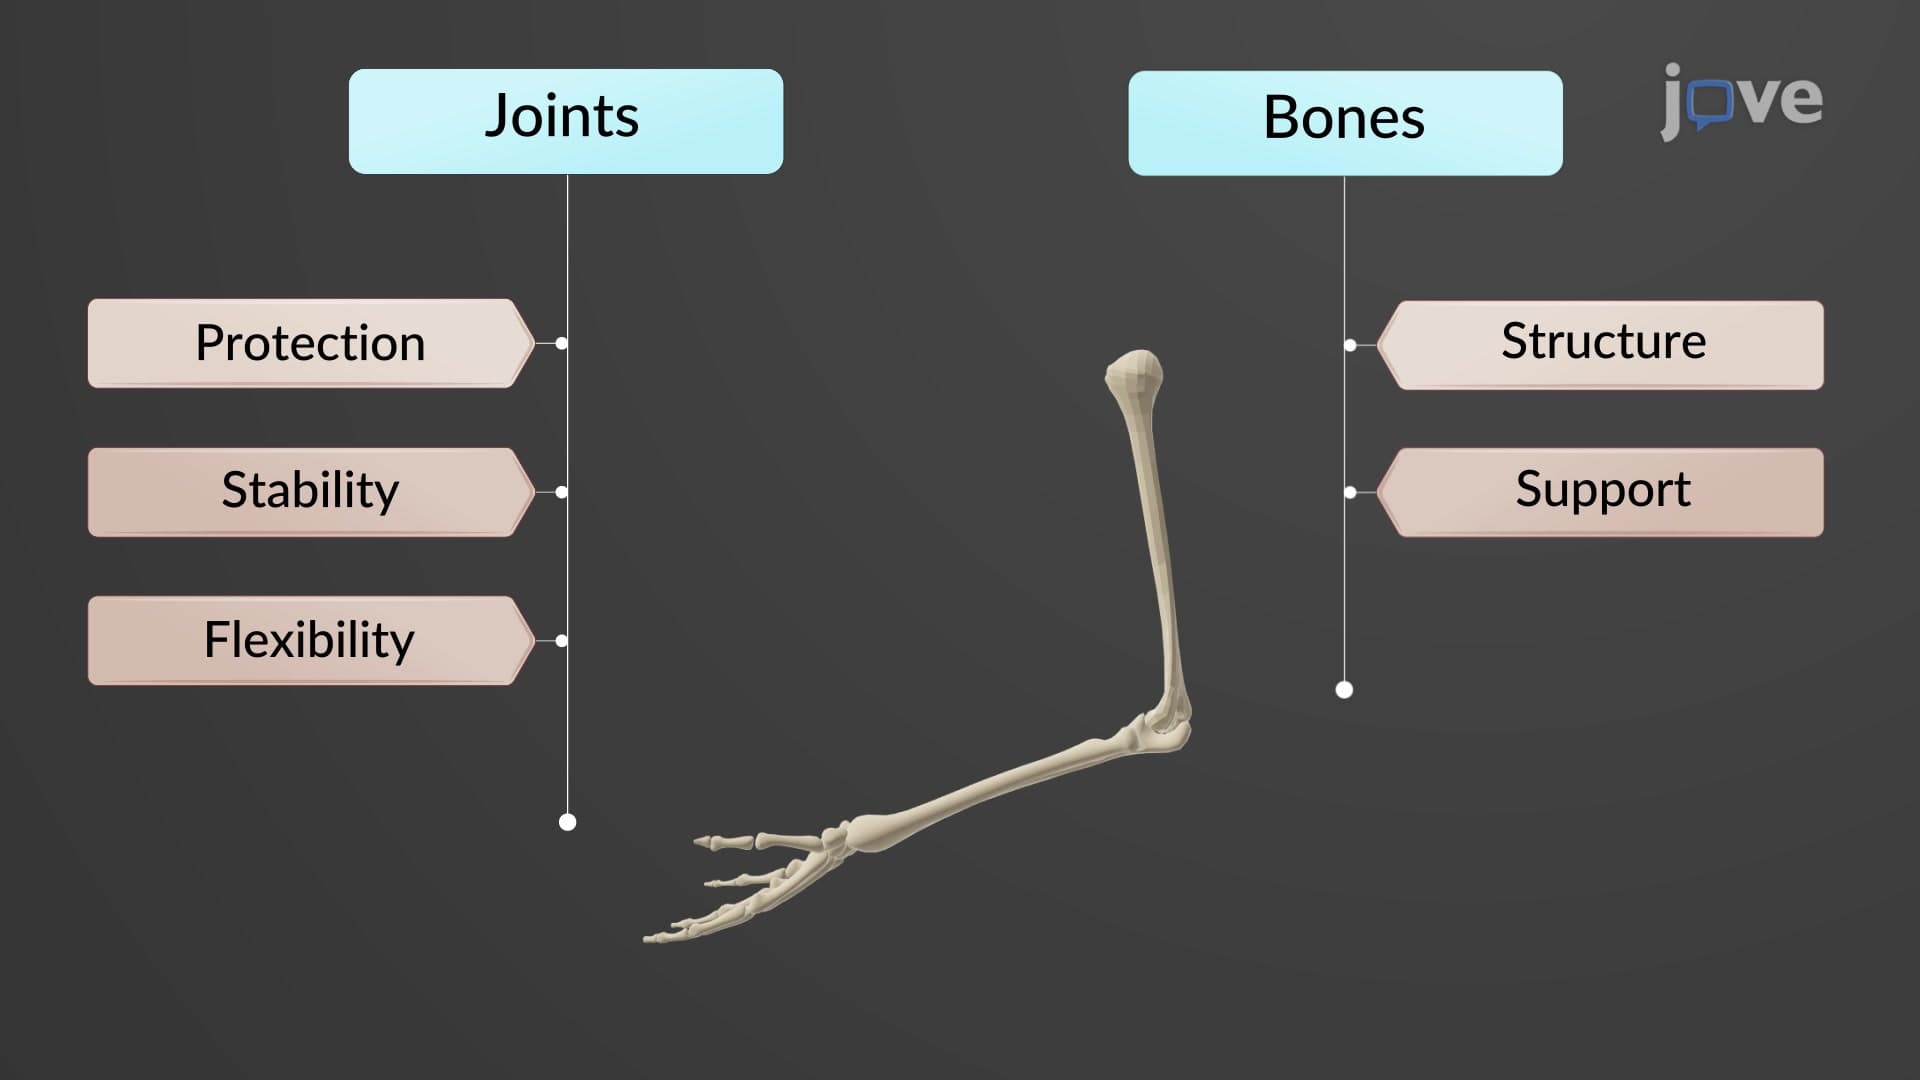
Introduction to Joints
 01:23
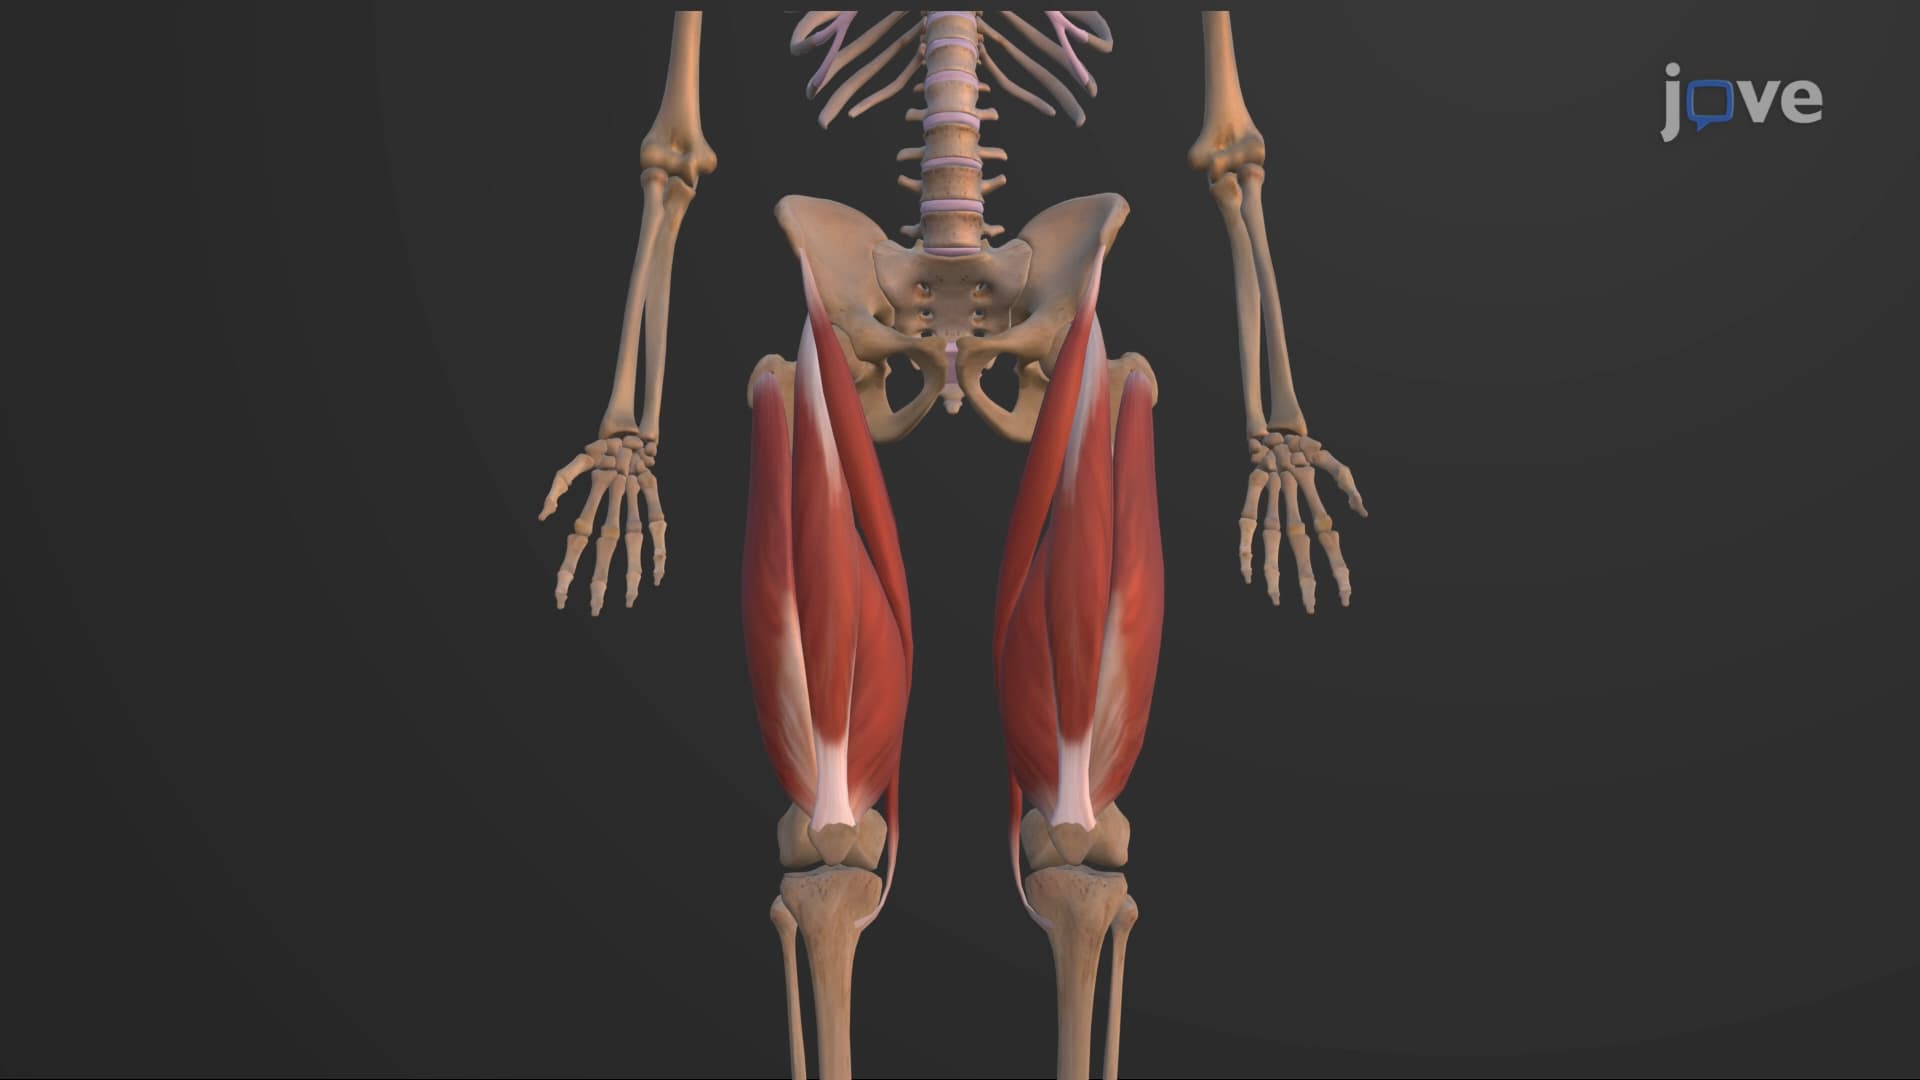
Muscles that Move the Leg
Anterior Compartment
The quadriceps femoris, the most visible muscle of the anterior compartment, is integral for leg extension and thigh flexion. It is formed by merging four distinct muscles — the vastus lateralis, vastus medialis, vastus intermedius, and rectus femoris. The quadriceps tendon, a shared tendon of the four quadriceps muscles, is affixed to...