Robust stabilizing first-order controllers for a class of time delay systems
Related Experiment Video
Updated: Jun 14, 2026

Interactive and Visualized Online Experimentation System for Engineering Education and Research
Published on: November 24, 2021
Karim Saadaoui1, Sana Testouri, Mohamed Benrejeb
1Unité de Recherche LARA-Automatique, Ecole Nationale d'Ingénieurs de Tunis, BP 37, le Belvédère 1002, Tunis, Tunisia. karim.saadaoui@isa2m.rnu.tn

Abstract:
In this paper, stabilizing regions of a first-order controller for an all poles system with time delay are computed via parametric methods. First, the admissible ranges of one of the controller's parameters are obtained. Then, for a fixed value of this parameter, stabilizing regions in the remaining two parameters are determined using the D-decomposition method. Phase and gain margin specifications are then included in the design. Finally, robust stabilizing first-order controllers are determined for uncertain plants with an interval type uncertainty in the coefficients. Examples are given to illustrate the effectiveness of the proposed method.
Related Concept Videos
 01:21
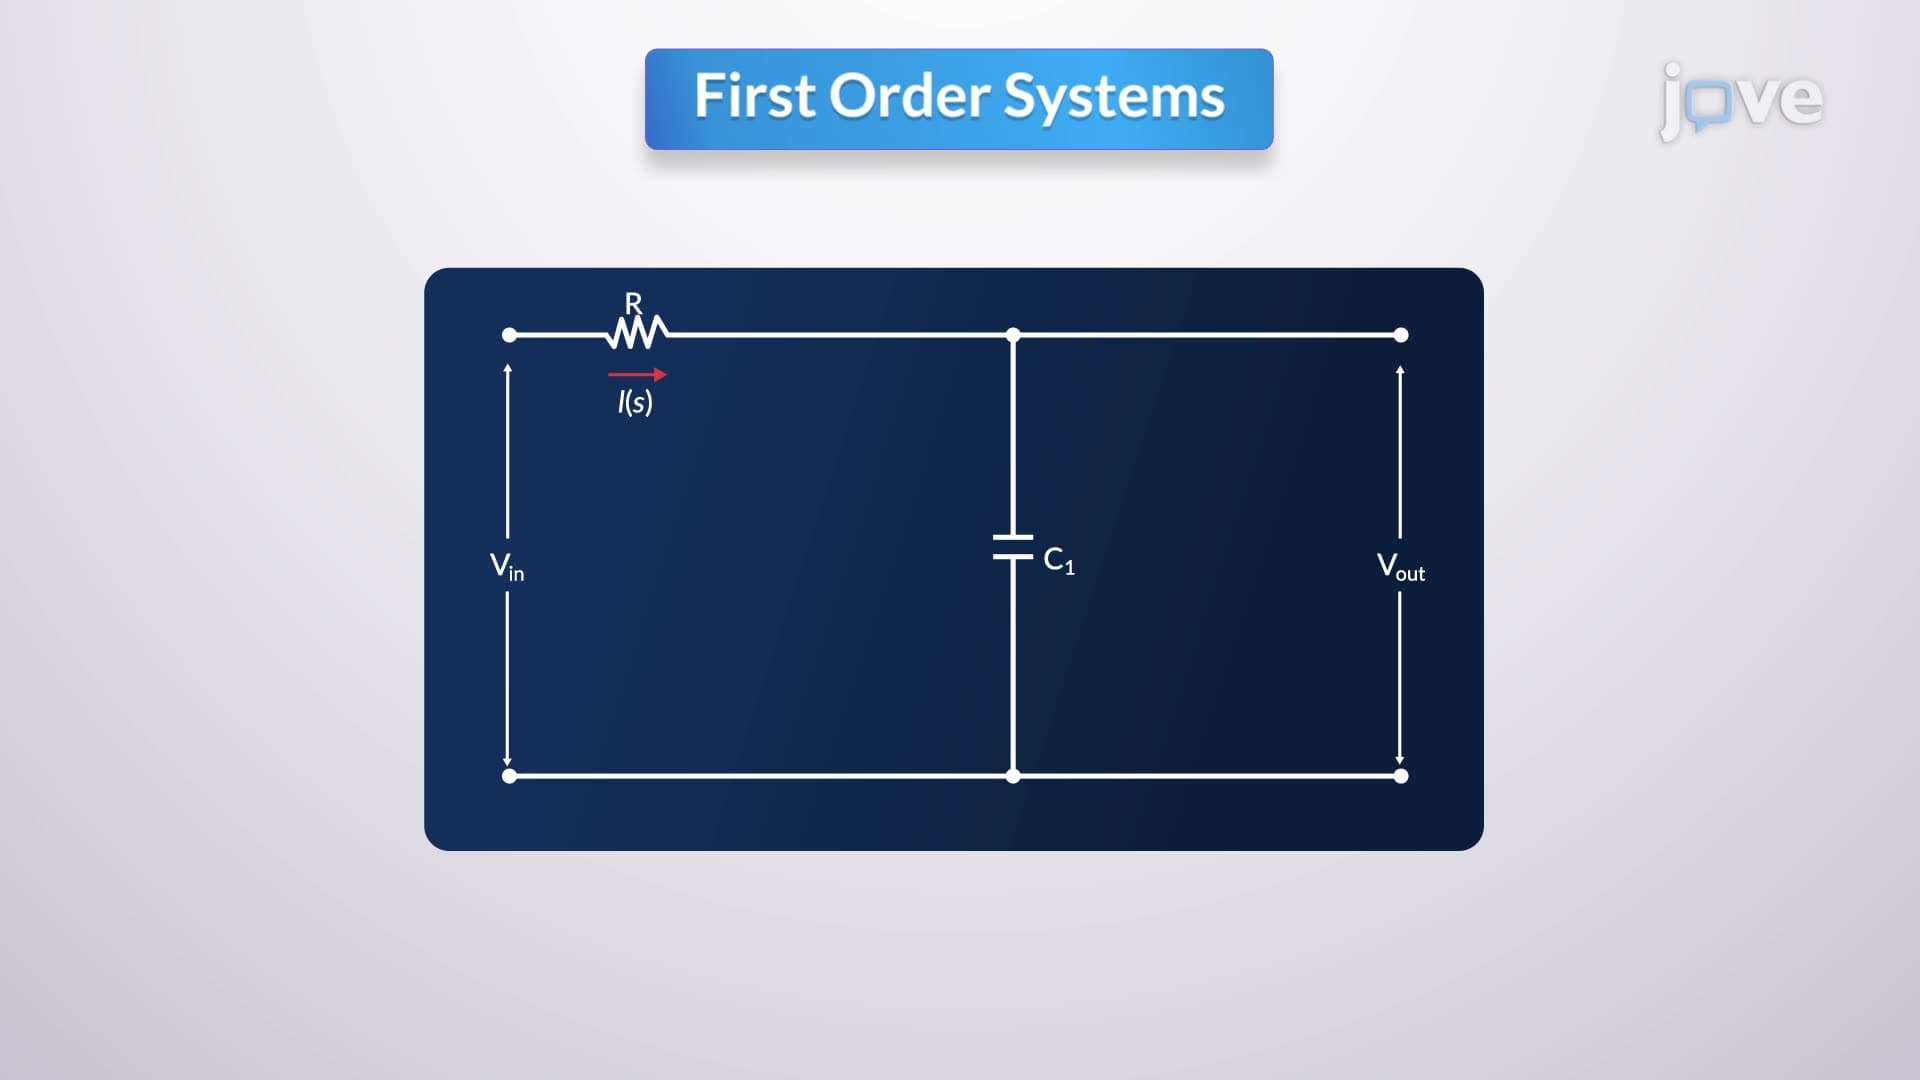
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:18
Second Order systems II
If ζ...
 01:21
Control System Problem
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
 01:27
Time and frequency -Domain Interpretation of PI Control
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires careful...
 01:20
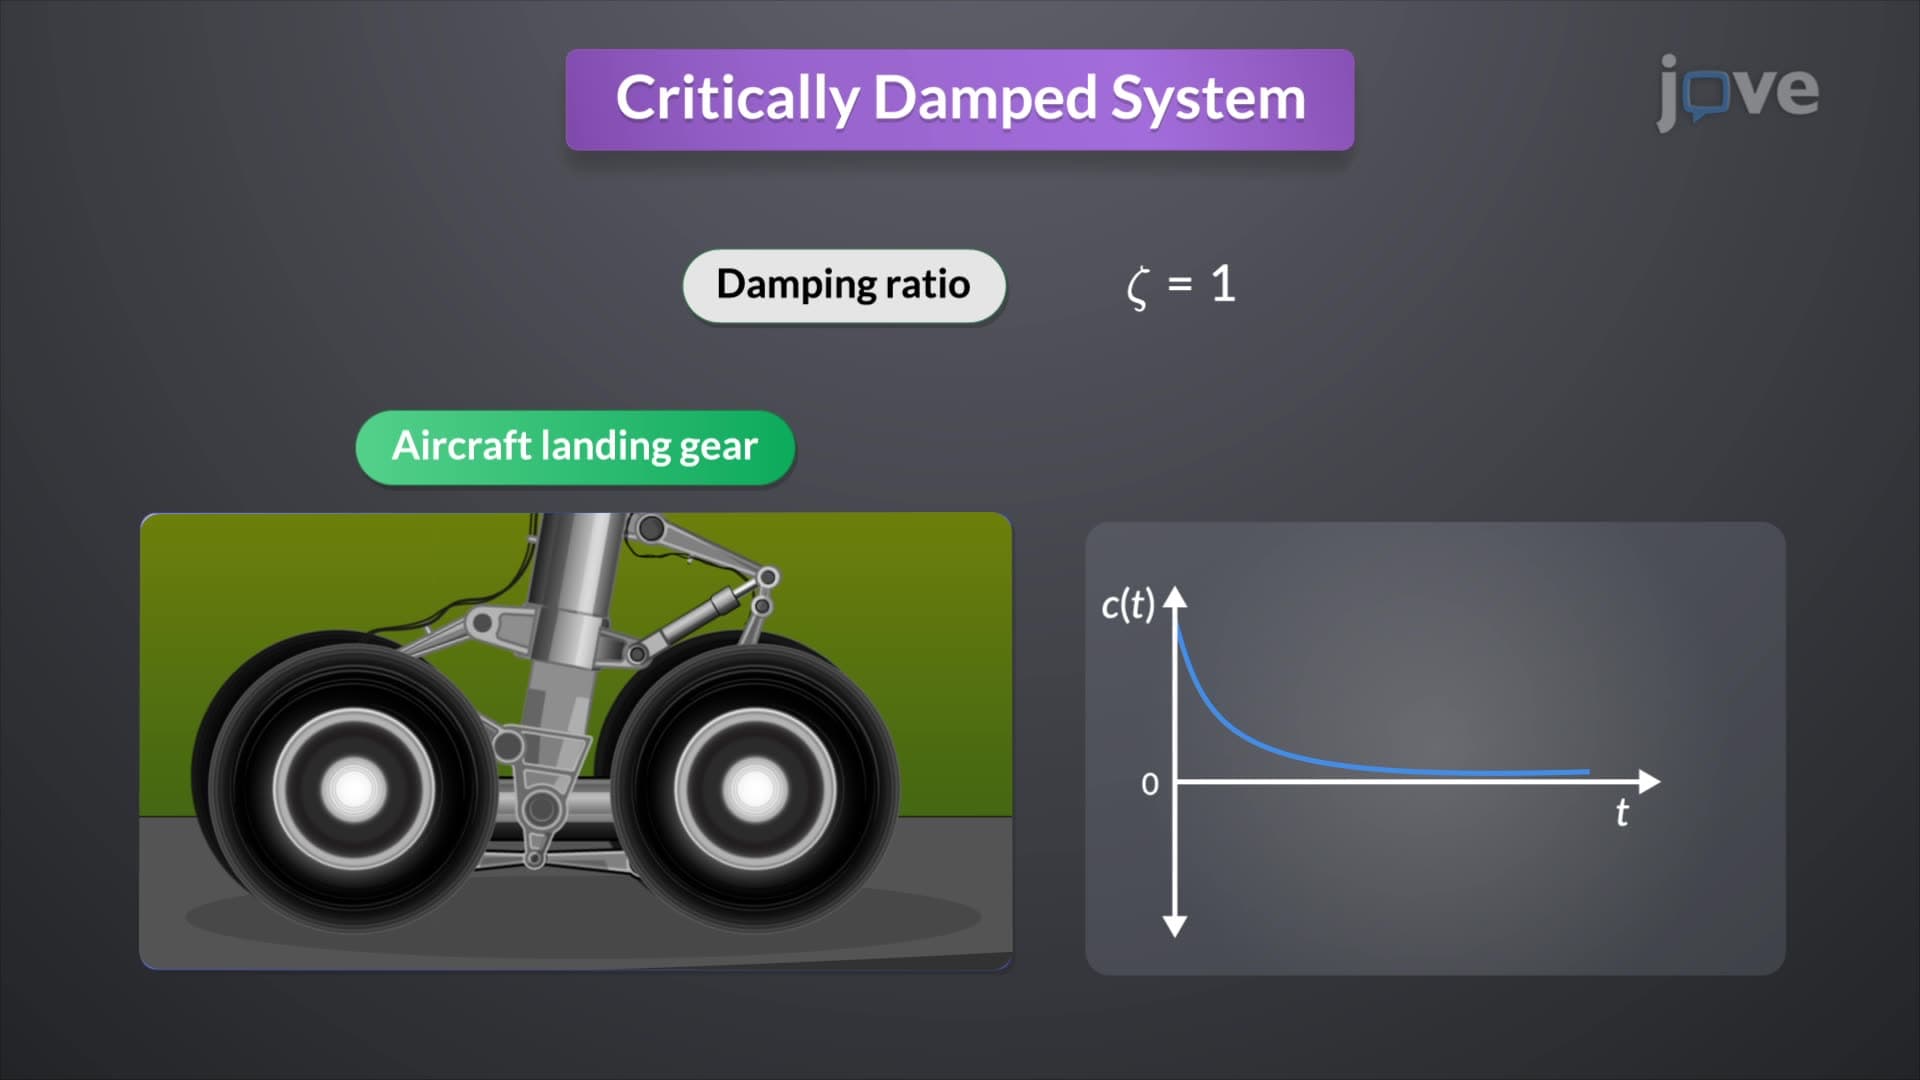
Second Order systems I
By reinterpreting the system, one can derive the closed-loop transfer function, which...