Rigid and articulated point registration with expectation conditional maximization
Related Experiment Video
Updated: Jun 13, 2026
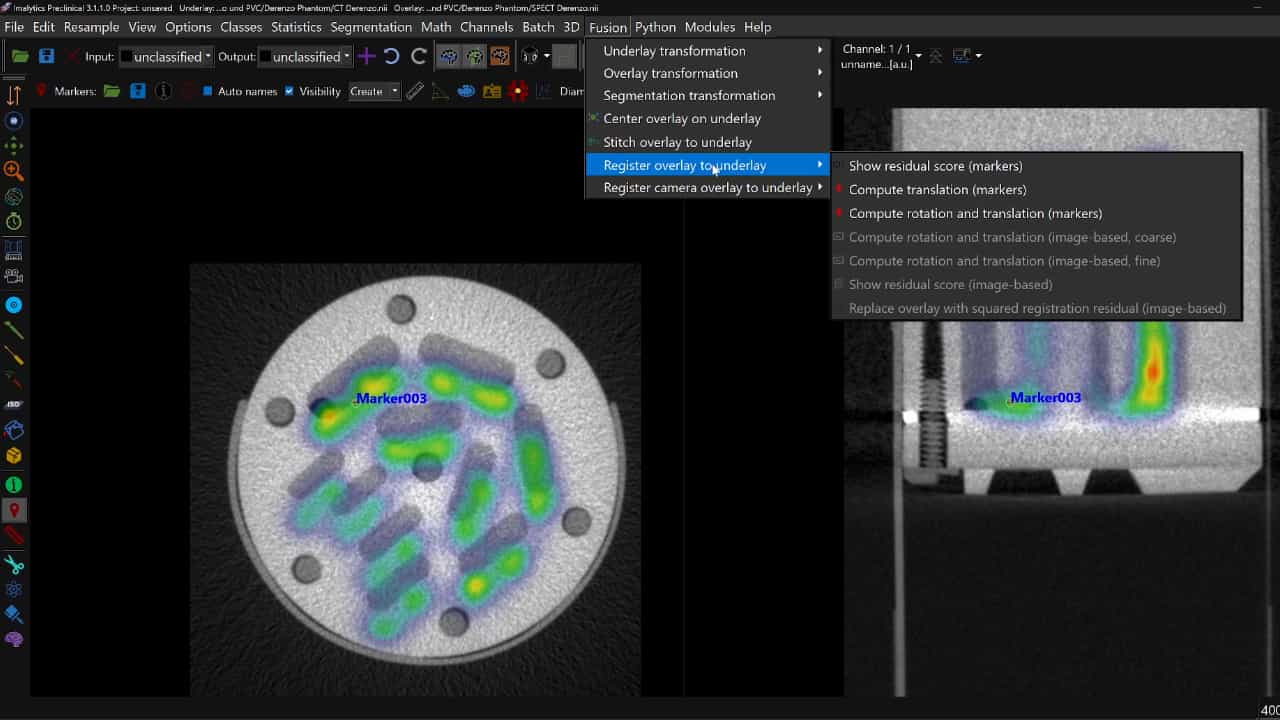
Multimodal Cross-Device and Marker-Free Co-Registration of Preclinical Imaging Modalities
Published on: October 27, 2023
Radu Horaud1, Florence Forbes, Manuel Yguel
1INRIA Grenoble Rhône-Alpes, Montbonnot Saint-Martin, France. radu.horaud@inrialpes.fr

Abstract:
This paper addresses the issue of matching rigid and articulated shapes through probabilistic point registration. The problem is recast into a missing data framework where unknown correspondences are handled via mixture models. Adopting a maximum likelihood principle, we introduce an innovative EM-like algorithm, namely, the Expectation Conditional Maximization for Point Registration (ECMPR) algorithm. The algorithm allows the use of general covariance matrices for the mixture model components and improves over the isotropic covariance case. We analyze in detail the associated consequences in terms of estimation of the registration parameters, and propose an optimal method for estimating the rotational and translational parameters based on semidefinite positive relaxation. We extend rigid registration to articulated registration. Robustness is ensured by detecting and rejecting outliers through the addition of a uniform component to the Gaussian mixture model at hand. We provide an in-depth analysis of our method and compare it both theoretically and experimentally with other robust methods for point registration.


Related Concept Videos
 01:25
Maximizing the Directional Derivative
 01:20
Calibration Curves: Linear Least Squares
For data that follow a straight line, the standard method for fitting is the linear...
 01:26
Constraints and Statical Determinacy
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 01:20
Structural Classification of Joints
A fibrous joint is where the adjacent bones are united by fibrous connective...
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?