Data-Parallel Octrees for Surface Reconstruction
Related Experiment Video
Updated: Jun 12, 2026
Four-Dimensional CT Analysis Using Sequential 3D-3D Registration
Published on: November 23, 2019

Abstract:
We present the first parallel surface reconstruction algorithm that runs entirely on the GPU. Like existing implicit surface reconstruction methods, our algorithm first builds an octree for the given set of oriented points, then computes an implicit function over the space of the octree, and finally extracts an isosurface as a watertight triangle mesh. A key component of our algorithm is a novel technique for octree construction on the GPU. This technique builds octrees in real time and uses level-order traversals to exploit the fine-grained parallelism of the GPU. Moreover, the technique produces octrees that provide fast access to the neighborhood information of each octree node, which is critical for fast GPU surface reconstruction. With an octree so constructed, our GPU algorithm performs Poisson surface reconstruction, which produces high-quality surfaces through a global optimization. Given a set of 500 K points, our algorithm runs at the rate of about five frames per second, which is over two orders of magnitude faster than previous CPU algorithms. To demonstrate the potential of our algorithm, we propose a user-guided surface reconstruction technique which reduces the topological ambiguity and improves reconstruction results for imperfect scan data. We also show how to use our algorithm to perform on-the-fly conversion from dynamic point clouds to surfaces as well as to reconstruct fluid surfaces for real-time fluid simulation.
Related Concept Videos
 01:12
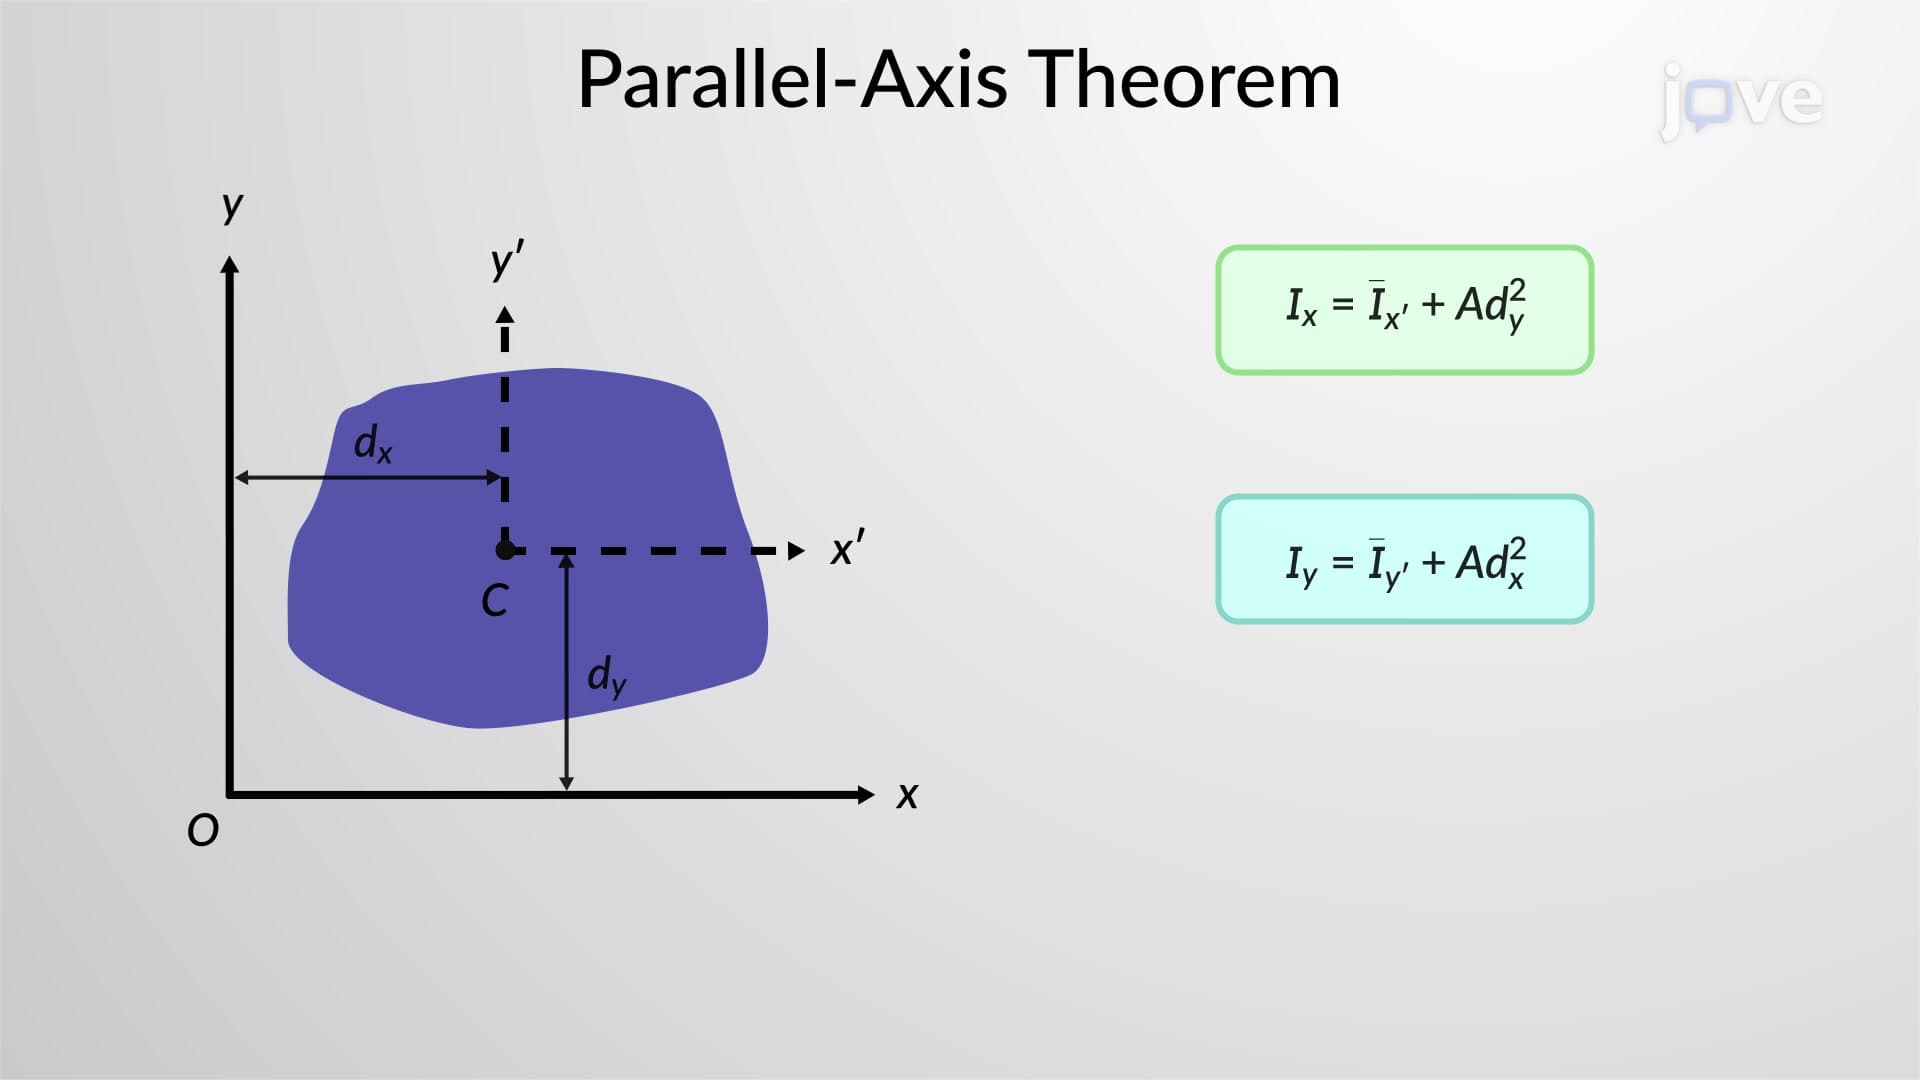
Parallel-Axis Theorem for an Area
For a flywheel approximated as a solid disc, consider an infinitesimal differential element with an arbitrary distance...
 01:06
Parallel-axis Theorem
 01:28
Quadric Surfaces
 01:30
Parametric Surfaces
 01:22
Tangent Planes to a Parametric Surface
 01:30
Oriented Surfaces