Related Experiment Video
Updated: Jun 12, 2026
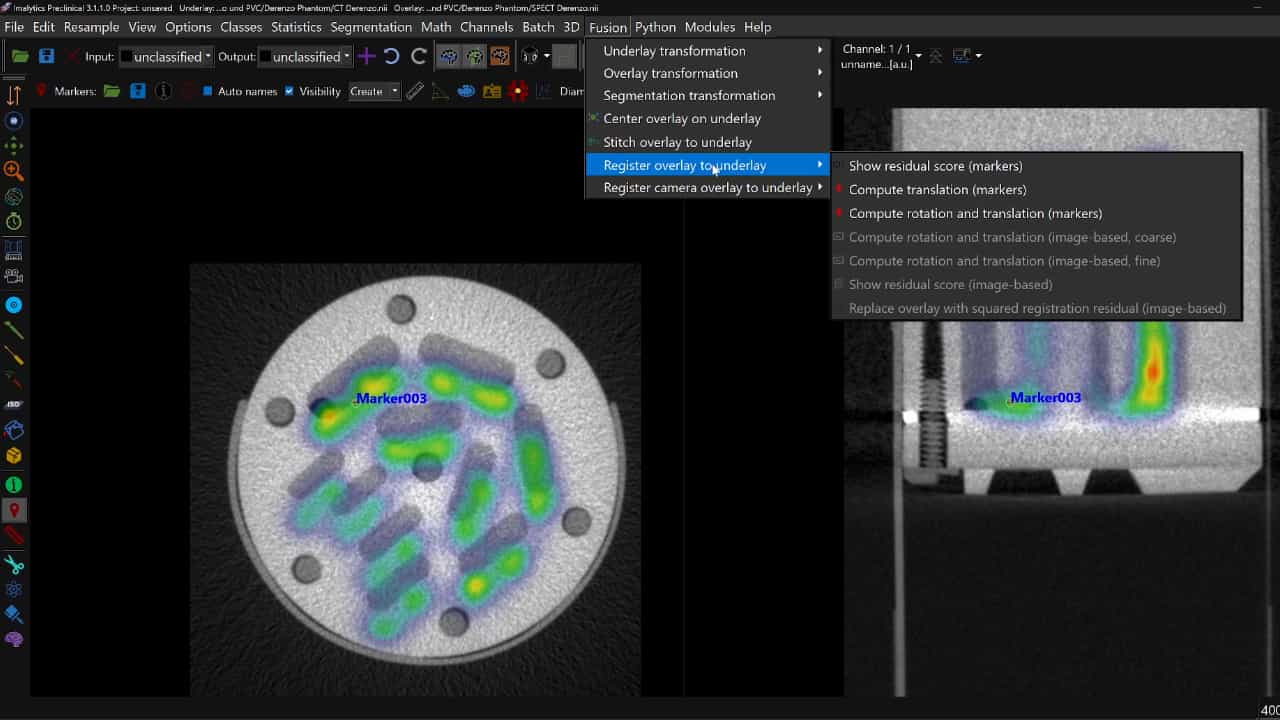

Multimodal Cross-Device and Marker-Free Co-Registration of Preclinical Imaging Modalities
Published on: October 27, 2023
Understanding the effect of bias in fiducial localization error on point-based rigid-body registration
Mehdi Hedjazi Moghari1, Purang Abolmaesumi
1Harvard Medical School, Boston, MA 02115, USA.

Abstract:
Image registration is a single point of failure in the image-guided computer-assisted surgery. Registration is primarily used to align and fuse the data sets taken from patient's anatomy before and during surgeries. Point-based rigid-body registration is usually performed by identifying corresponding fiducials (either natural landmarks or implanted ones) in the data sets. Since the localization of fiducials is imprecise and is generally perturbed by random noise, the performed registration is imperfect and has some error. Previous work has extensively analyzed the behavior of this error when the fiducial localization error has zero-mean over the entire set of fiducials. However, if noise has a nonzero-mean or a bias, no formulation yet exists to determine the effect of noise on the overall registration accuracy. In this work, we derive novel formulations that relate the bias in the localized fiducials to the accuracy of the performed registration. We analytically and numerically demonstrate that by eliminating the estimated bias from the measured fiducial locations, one can effectively increase the accuracy of the performed registration.
Related Concept Videos
 00:49
Rigid Body Equilibrium Problems - I
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 01:12
Equation of Motion for a Rigid Body
The combined moments generated about the center of mass of the object are equal to the rate of change of the angular momentum of the body. An external force, when applied at a different point...