Orientation-Preserving Rod Elements for Real-Time Thin-Shell Simulation
Related Experiment Video
Updated: Jun 12, 2026

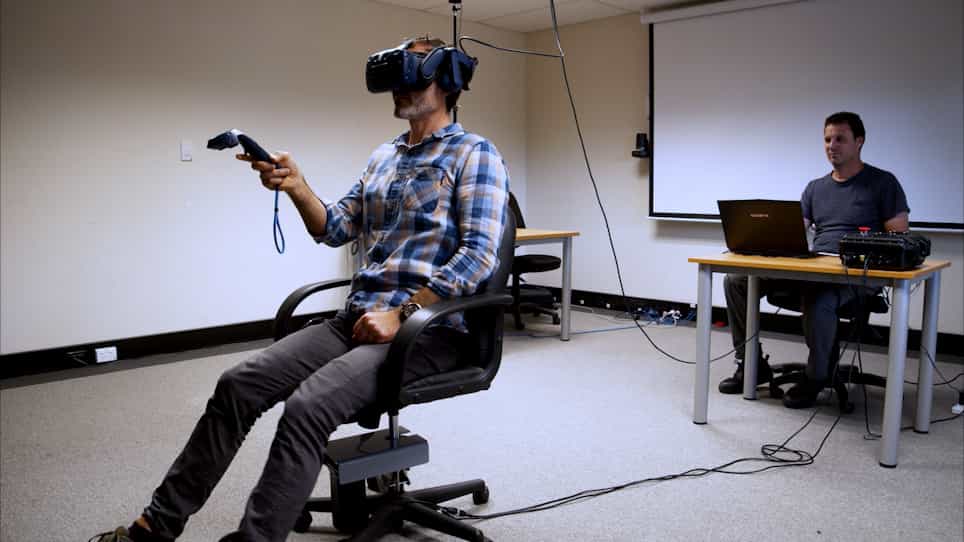
Three-Dimensional Mapping of the Rotation of Interactive Virtual Objects with Eye-Tracking Data
Published on: October 18, 2024

Abstract:
We propose a new computation model for simulating elastic thin shells at interactive rates. Existing graphical simulation methods are mostly based on dihedral angle energy functions, which need to compute the first order and second order partial derivatives with respect to current vertex positions as bending forces and stiffness matrices. The symbolic derivatives are complicated in nonisometric element deformations. To simplify computing the derivatives, instead of directly constructing the dihedral angle energy, we use the orientation change energy of mesh edges. A continuum-mechanics-based orientation-preserving rod element model is developed to provide the bending forces. The advantage of our method is simple bending force and stiffness matrix computation, since in the rod model, we apply a novel incremental construction of the deformation gradient tensor to linearize both tensile and orientation deformations. Consequently, our model is efficient, easy to implement, and supports both quadrilateral and triangle meshes. It also treats shells and plates uniformly.
Related Concept Videos
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:10
Deformation in a Circular Shaft
 01:26
Rotational Motion about a Fixed Axis
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:03
Inertial Frames of Reference