Related Experiment Video
Updated: Jun 12, 2026
10:16

A Protocol for Real-time 3D Single Particle Tracking
Published on: January 3, 2018

Abstract:
Multitarget tracking requires assigning probabilities that measurements are associated with particular targets. A new and efficient algorithm to achieve this is detailed. Its implementation on an analog optical processor using a new and cost-effective frequency-multiplexing technique is discussed.
Related Concept Videos
 01:26
Orthogonal Trajectories
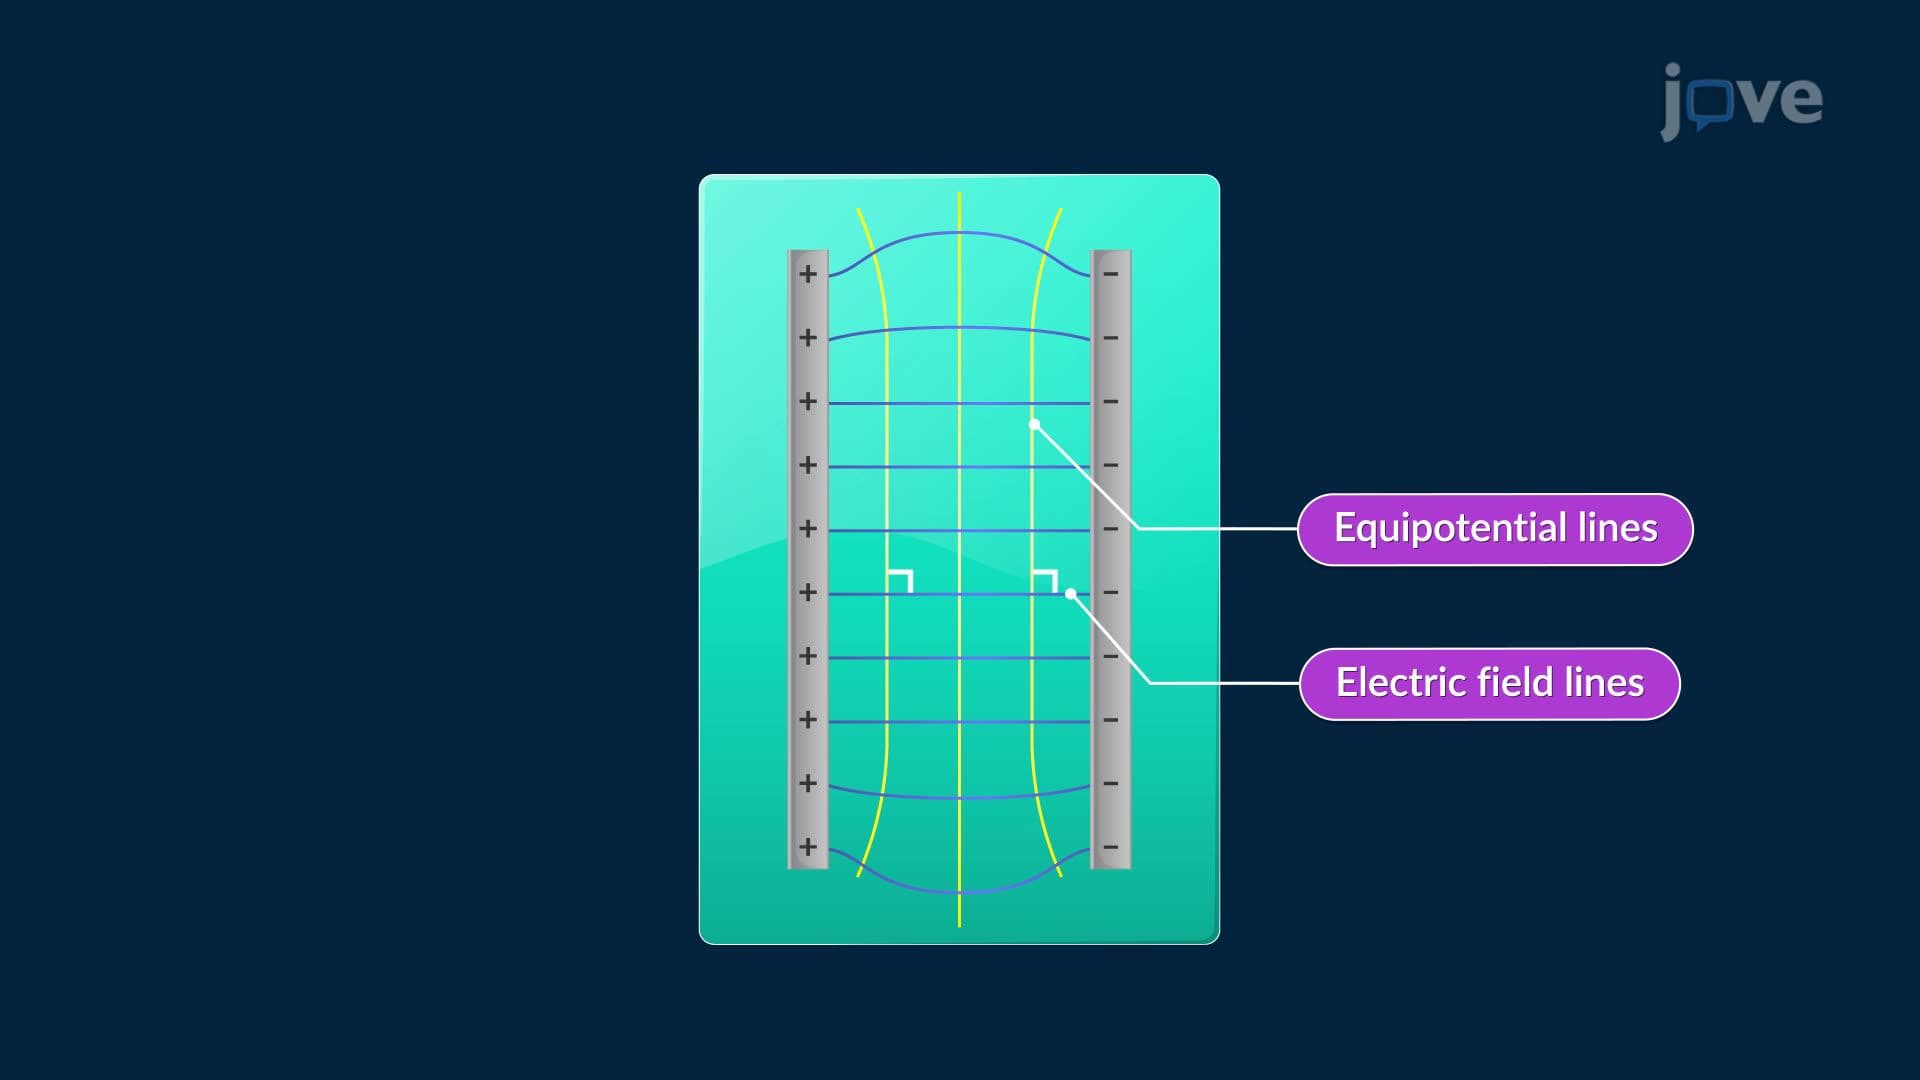
Orthogonal trajectories describe the geometric relationship between two families of curves that intersect each other at right angles. One illustrative case involves a family of parabolas that open sideways along the x-axis. These curves share a common shape but differ by a scaling parameter, resulting in a set of curves that all pass through the origin and widen at different rates.Determining Orthogonal TrajectoriesTo identify the orthogonal trajectories for these parabolas, the first step...
 01:22
Multi-input and Multi-variable systems
Cruise control systems in cars are designed as multi-input systems to maintain a driver's desired speed while compensating for external disturbances such as changes in terrain. The block diagram for a cruise control system typically includes two main inputs: the desired speed set by the driver and any external disturbances, such as the incline of the road. By adjusting the engine throttle, the system maintains the vehicle's speed as close to the desired value as possible.
In the absence of...
In the absence of...
 01:30
Acceleration Vectors
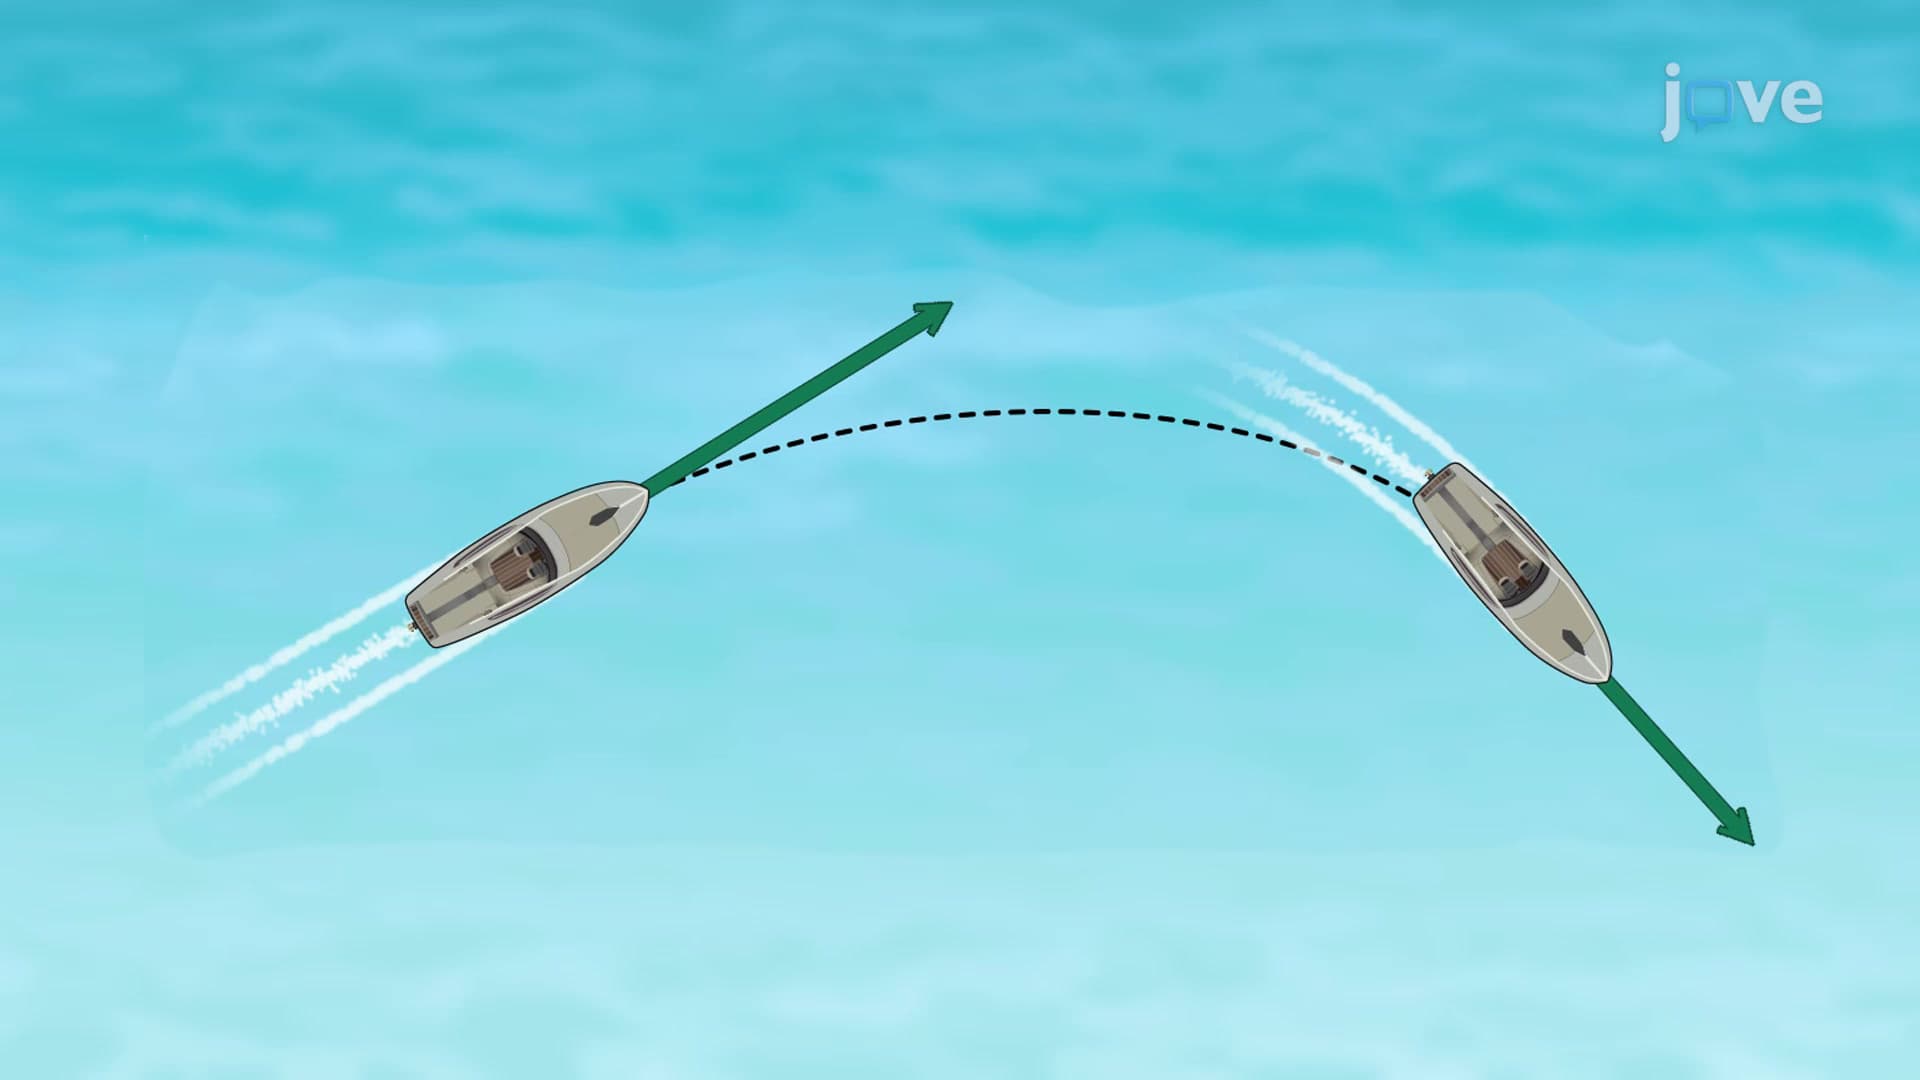
In everyday conversation, accelerating means speeding up. Acceleration is a vector in the same direction as the change in velocity, Δv, therefore the greater the acceleration, the greater the change in velocity over a given time. Since velocity is a vector, it can change in magnitude, direction, or both. Thus acceleration is a change in speed or direction, or both. For example, if a runner traveling at 10 km/h due east slows to a stop, reverses direction, and continues their run at 10 km/h due...
 01:10
Fast Fourier Transform
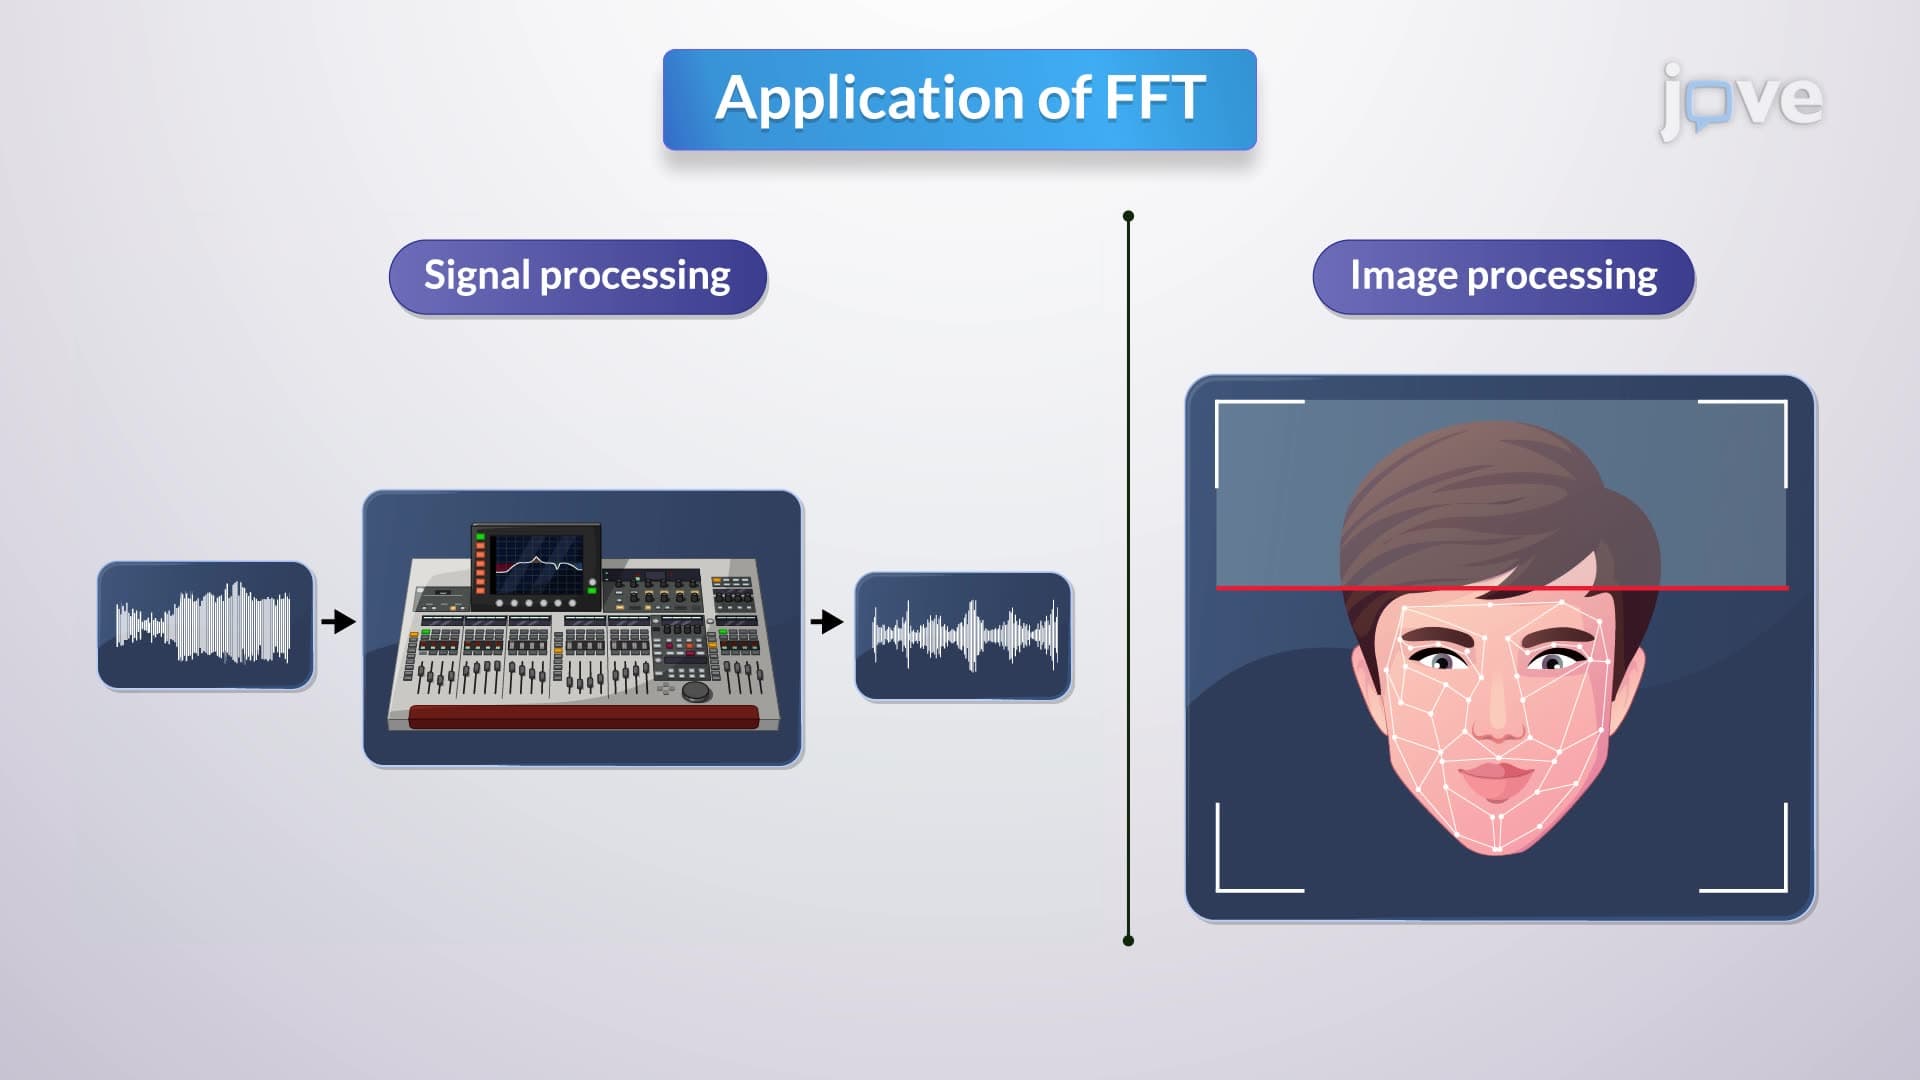
The Fast Fourier Transform (FFT) is a computational algorithm designed to compute the Discrete Fourier Transform (DFT) efficiently. By breaking down the calculations into smaller, manageable sections, the FFT significantly reduces the computational complexity involved. Direct computation of an N-point DFT requires N2 complex multiplications, whereas the FFT algorithm needs only (N/2)log2N multiplications, offering a much faster performance.
The computational efficiency of the FFT becomes...
The computational efficiency of the FFT becomes...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:24
Absolute Motion Analysis- General Plane Motion
Visualize a drone, with its propellers spinning rapidly, hovering mid-air. The fascinating movements and operations of this drone can be comprehended by applying the principle of general plane motion.
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...