Impact dynamics in biped locomotion analysis: two modelling and implementation approaches
Related Experiment Video
Updated: Jun 12, 2026
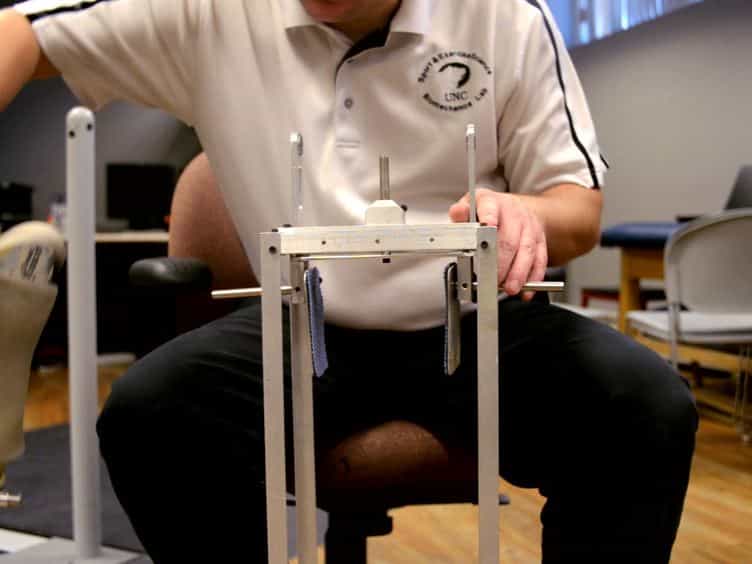
Oscillation and Reaction Board Techniques for Estimating Inertial Properties of a Below-knee Prosthesis
Published on: May 8, 2014
Khalid Addi1, Aleksandar D Rodić
1University of La Réunion, Analyse et Ingénierie Mathématique AIM/LIM EA 2525, Parc Technologique Universitaire, 2 rue Joseph Wetzell, 97490 Sainte-Clotilde, France. khalid.addi@univ-reunion.fr

Abstract:
Stability during the biped locomotion and especially humanoid robots walking is a big challenge in robotics modelling. This paper compares the classical and novel methodologies of modelling and algorithmic implementation of the impact/contact dynamics that occurs during a biped motion. Thus, after establishing the free biped locomotion system model, a formulation using variational inequalities theory via a Linear Complementarity Problem then an impedance model are explicitly developed. Results of the numerical simulations are compared to the experimental measurements then the both approaches are discussed.

Related Concept Videos
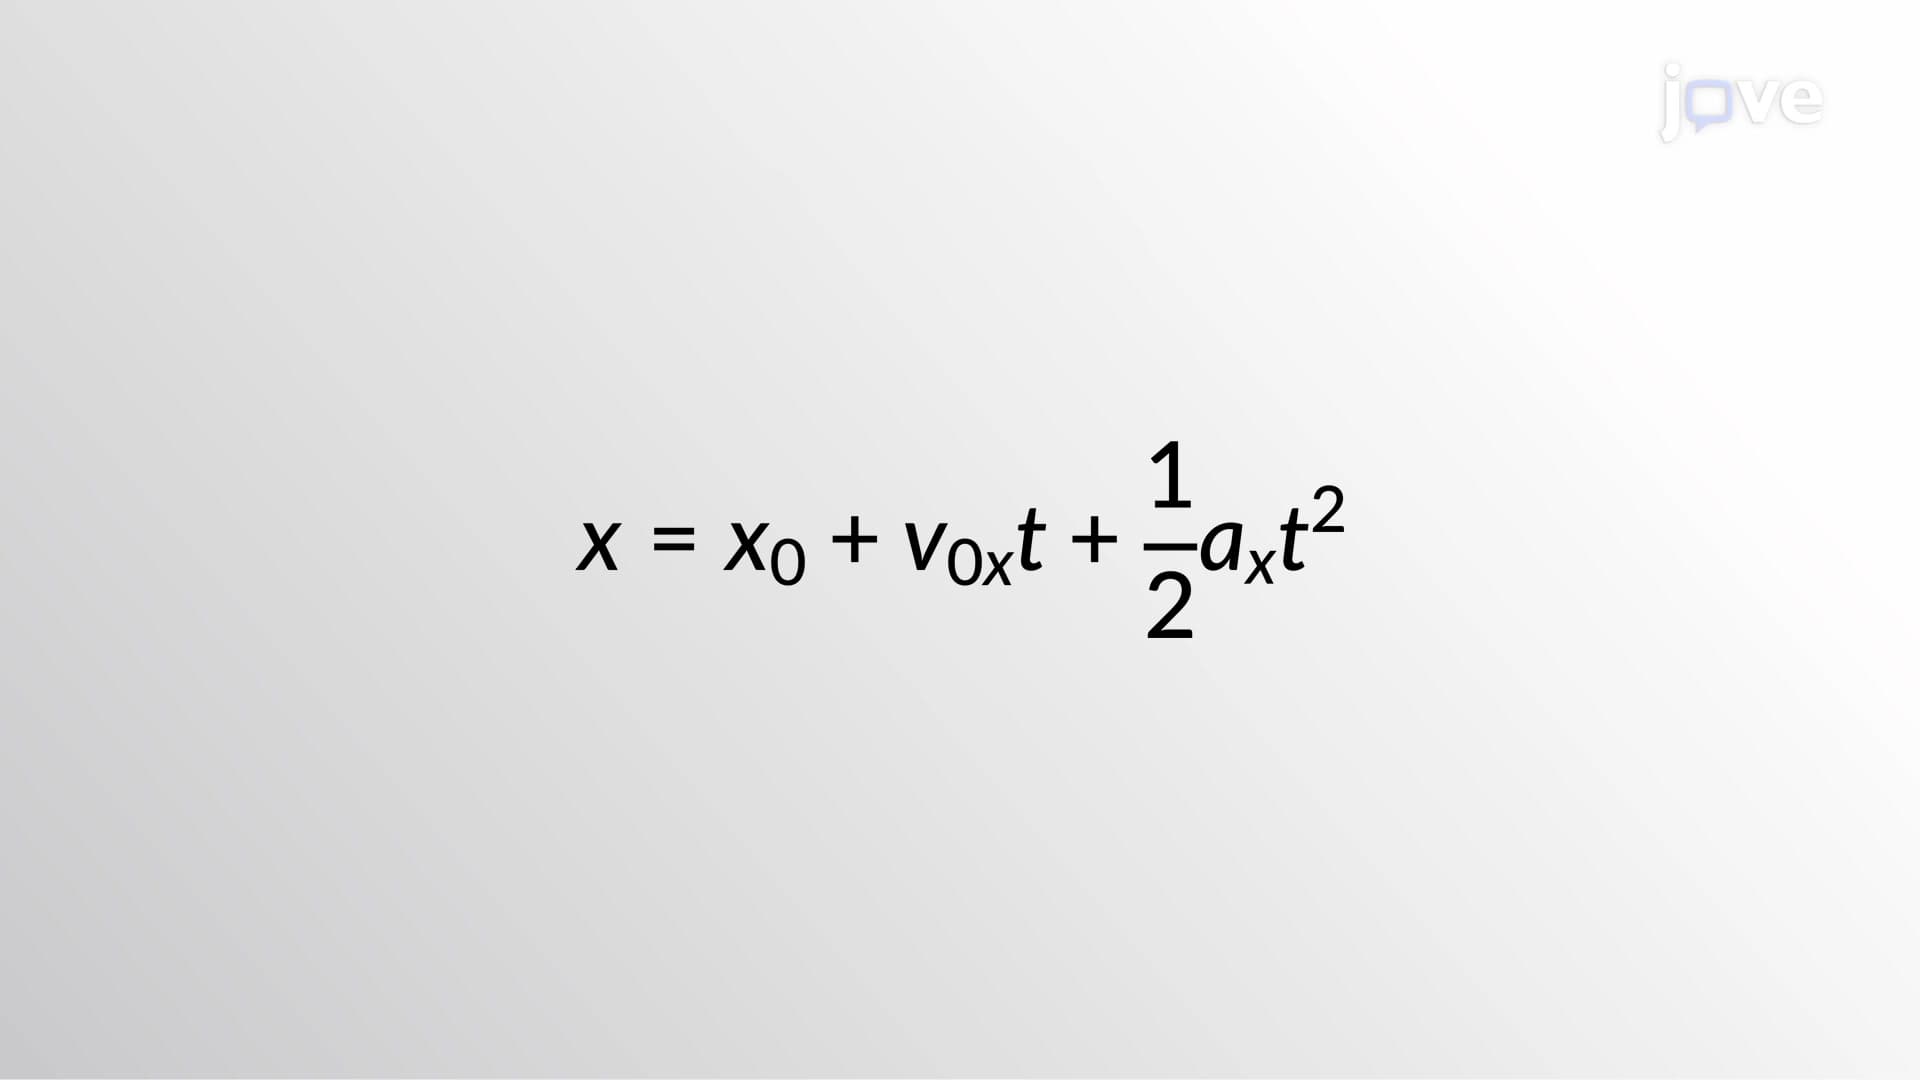 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:10
Relative Motion Analysis - Acceleration
 01:15
Kinematic Equations: Problem Solving
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
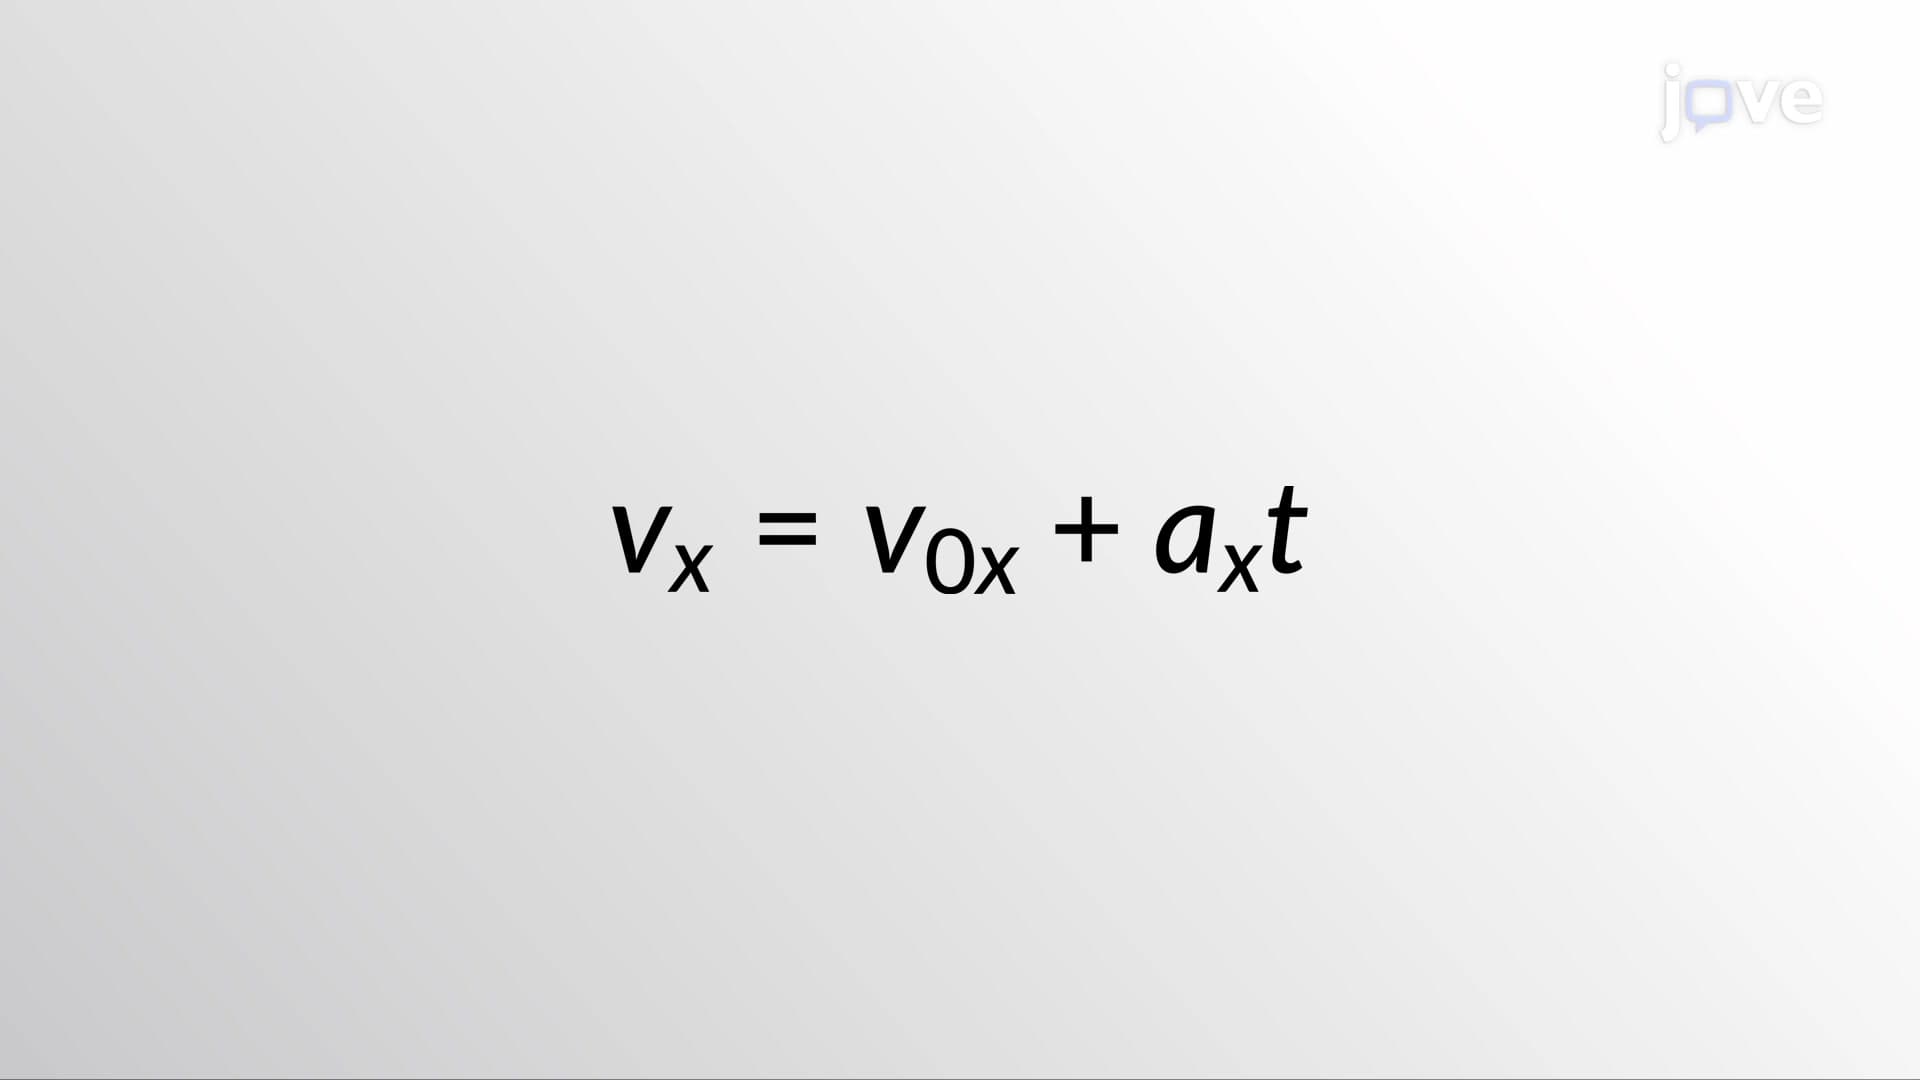 01:26
Kinematic Equations - I