Related Experiment Video
Updated: Oct 29, 2026
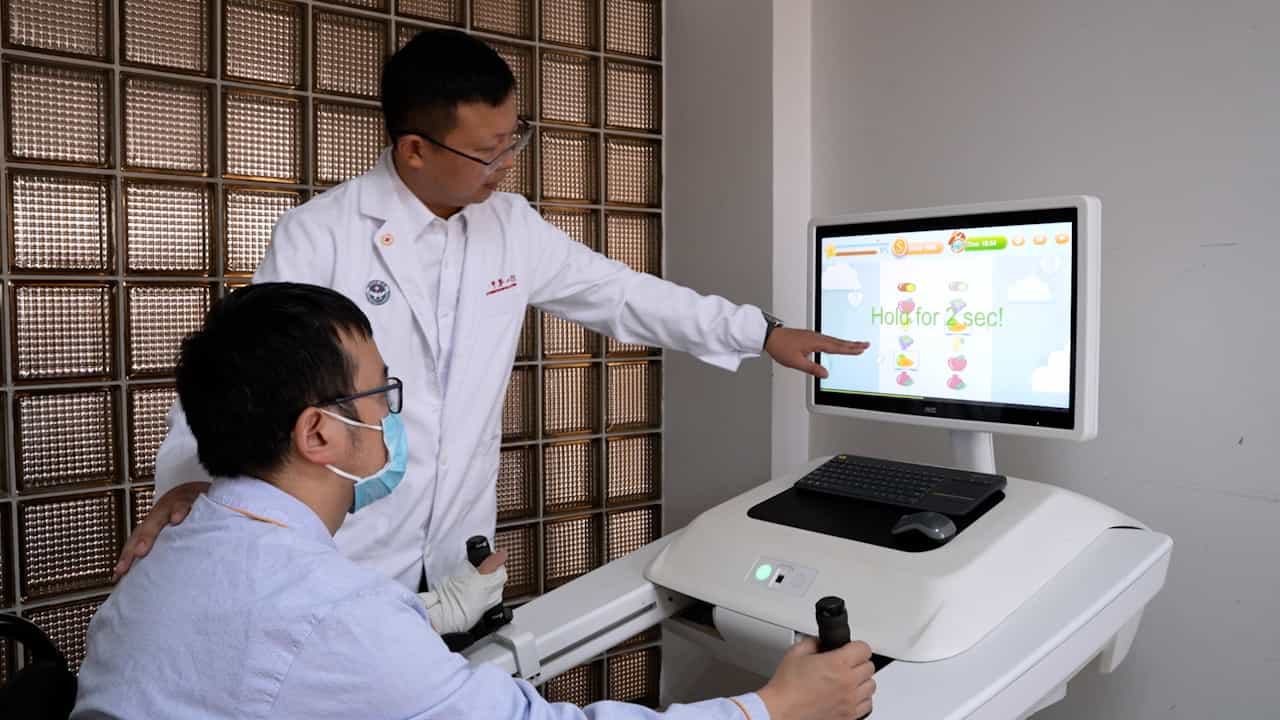
Application of a Dual Upper Limb Task-Oriented Robotic System for the Functional Recovery of the Upper Limb in Stroke Patients
Published on: October 11, 2024
Design and analysis of rehabilitation training mechanism based on upper limb rehabilitation movements
Haoyu Han1, Qinghui Zhu1, Li Feng1
1College of Home and Art Design, Northeast Forestry University, Harbin, Heilongjiang, 150000, China.

Purpose:
To conduct a comparative analysis of the trajectory and joint torque differences between exoskeleton type and end-effector type upper limb rehabilitation training mechanisms during rehabilitation movements, and to identify the more suitable mechanism type for passive upper limb rehabilitation training.
Methods:
Based on the Brunnstrom rehabilitation approach, upper limb rehabilitation movements for the passive training phase were selected. Muscle force simulations were conducted using OpenSim software to identify movements with high muscular engagement. The structures of the two mechanisms were designed through degree-of-freedom analysis, and motion trajectory simulations were completed in Automatic Dynamic Analysis of Mechanical Systems (ADAMS). In MATLAB, discrete Fréchet distance is used to evaluate trajectory similarity. The error of comparing simultaneously the trajectories of two mechanisms with the trajectory of the human body model using R 2 was calculated. In ADAMS, the rotational torque changes of the shoulder, elbow, and wrist joints between two mechanisms were compared.
Results:
The movement trajectory of the exoskeleton mechanism closely matched the natural motion of the human upper limb, with error ≤2 mm and trajectory R 2 ≥ 0.9975. Its joint torque distribution was balanced, with a maximum torque ≤40 Nm. The trajectory error of the end-effector mechanism was ≤5 mm and trajectory R 2 ≥ 0.9910 and torques were concentrated at the wrist and elbow joints, some values being ≥40 Nm.
Conclusion:
The exoskeleton-type upper limb rehabilitation training mechanism demonstrates superior performance in terms of movement trajectory adaptability and joint protection compared to the end-effector-type mechanism, making it more suitable for passive movement assistance and joint range of motion recovery training.