Related Experiment Video
Updated: Jun 11, 2026
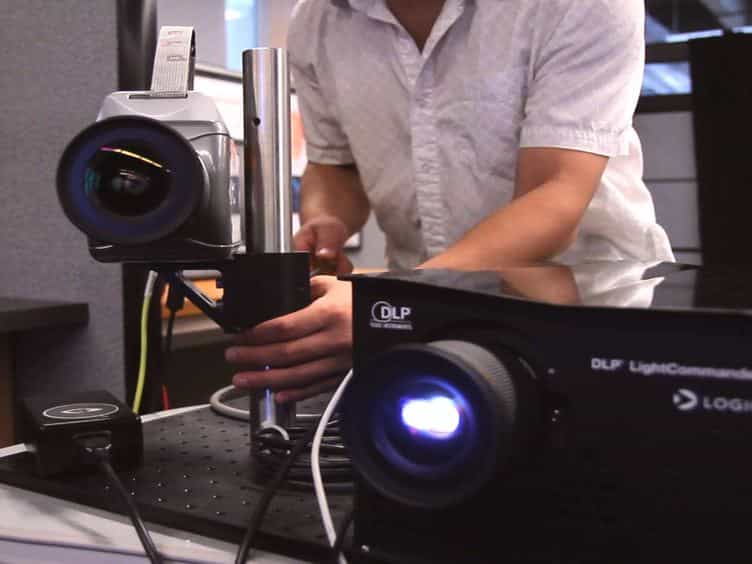
High-resolution, High-speed, Three-dimensional Video Imaging with Digital Fringe Projection Techniques
Published on: December 3, 2013
Sub-hexagonal phase correlation for motion estimation
1Department of Computing, Information Systems and Mathematics, Kingston University, London, Surrey KT1 1LQ, UK. Vasileios.Argyriou@kingston.ac.uk

Abstract:
We present a novel frequency-domain motion estimation technique, which operates on hexagonal images and employs the hexagonal Fourier transform. Our method involves image sampling on a hexagonal lattice followed by a normalised hexagonal cross-correlation in the frequency domain. The term subpixel (or subcell) is defined on a hexagonal grid in order to achieve floating point registration. Experiments using both artificially induced motion and actual motion demonstrate that the proposed method outperforms the state-of-the-art in frequency-domain motion estimation operating on a square lattice, in the shape of phase correlation, in terms of subpixel accuracy for a range of test material and motion scenarios.
Related Concept Videos
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:19
2D NMR: Heteronuclear Single-Quantum Correlation Spectroscopy (HSQC)
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:18
2D NMR: Overview of Heteronuclear Correlation Techniques
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...