Related Experiment Video
Updated: Jun 10, 2026
Subject-specific Musculoskeletal Model for Studying Bone Strain During Dynamic Motion
Published on: April 11, 2018
A musculoskeletal shoulder model based on pseudo-inverse and null-space optimization
Alexandre Terrier1, Martin Aeberhard, Yvan Michellod
1Laboratory of Biomechanical Orthopedics, Ecole Polytechnique Fédérale de Lausanne, Switzerland. alexander.terrier@epfl.ch

Abstract:
The goal of the present work was assess the feasibility of using a pseudo-inverse and null-space optimization approach in the modeling of the shoulder biomechanics. The method was applied to a simplified musculoskeletal shoulder model. The mechanical system consisted in the arm, and the external forces were the arm weight, 6 scapulo-humeral muscles and the reaction at the glenohumeral joint, which was considered as a spherical joint. The muscle wrapping was considered around the humeral head assumed spherical. The dynamical equations were solved in a Lagrangian approach. The mathematical redundancy of the mechanical system was solved in two steps: a pseudo-inverse optimization to minimize the square of the muscle stress and a null-space optimization to restrict the muscle force to physiological limits. Several movements were simulated. The mathematical and numerical aspects of the constrained redundancy problem were efficiently solved by the proposed method. The prediction of muscle moment arms was consistent with cadaveric measurements and the joint reaction force was consistent with in vivo measurements. This preliminary work demonstrated that the developed algorithm has a great potential for more complex musculoskeletal modeling of the shoulder joint. In particular it could be further applied to a non-spherical joint model, allowing for the natural translation of the humeral head in the glenoid fossa.
Related Concept Videos
 01:23
Muscles of the Shoulder
Anterior Thoracic Muscles
The anterior thoracic muscles include the serratus anterior, subclavius, and...
 01:16
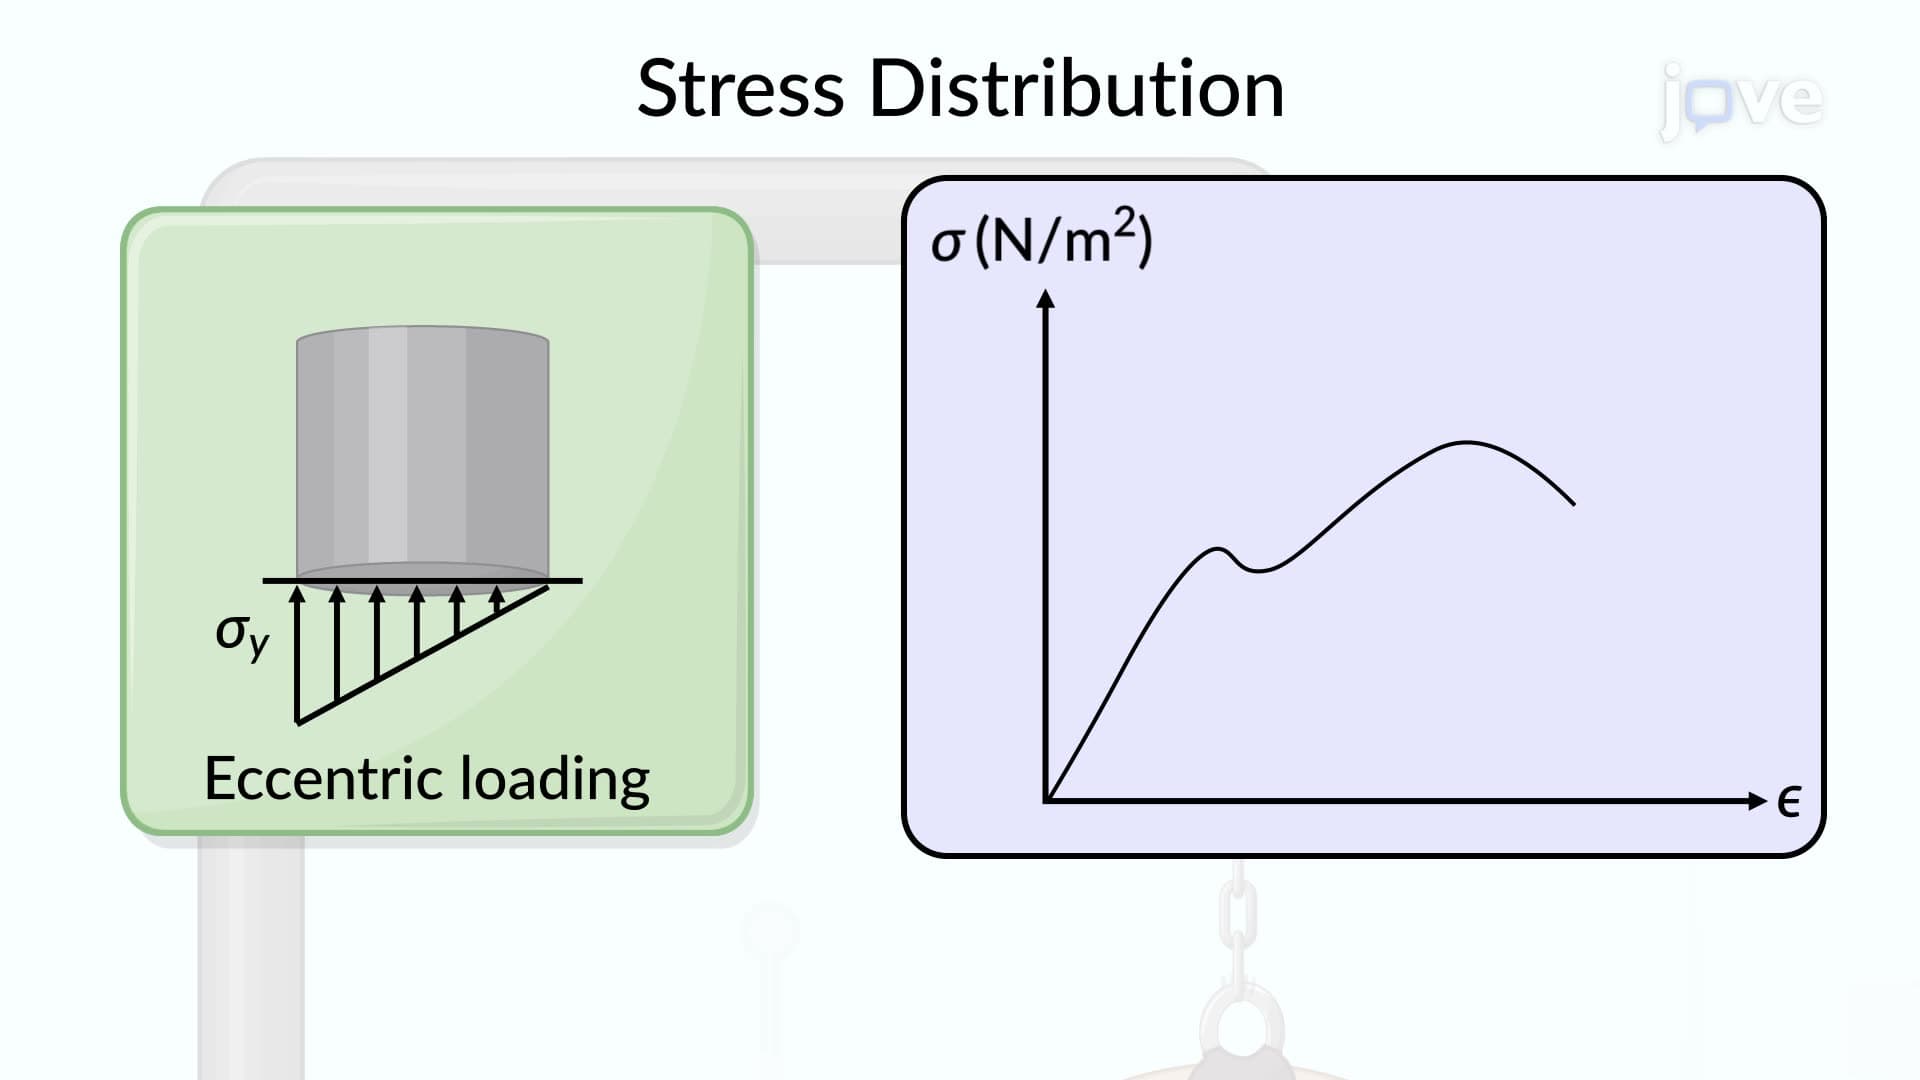
Eccentric Axial Loading in a Plane of Symmetry
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:29
Relaxation of Skeletal Muscles
When an action potential reaches the axon terminal, it depolarizes the membrane and opens voltage-gated sodium channels. Sodium ions enter the cell, further depolarizing the presynaptic membrane. This depolarization causes voltage-gated calcium channels to open.
 01:19
Bones of the Upper Limb: Humerus