Related Experiment Video
Updated: Jun 7, 2026
A Vibrotactile Feedback Device for Seated Balance Assessment and Training
Published on: January 20, 2019
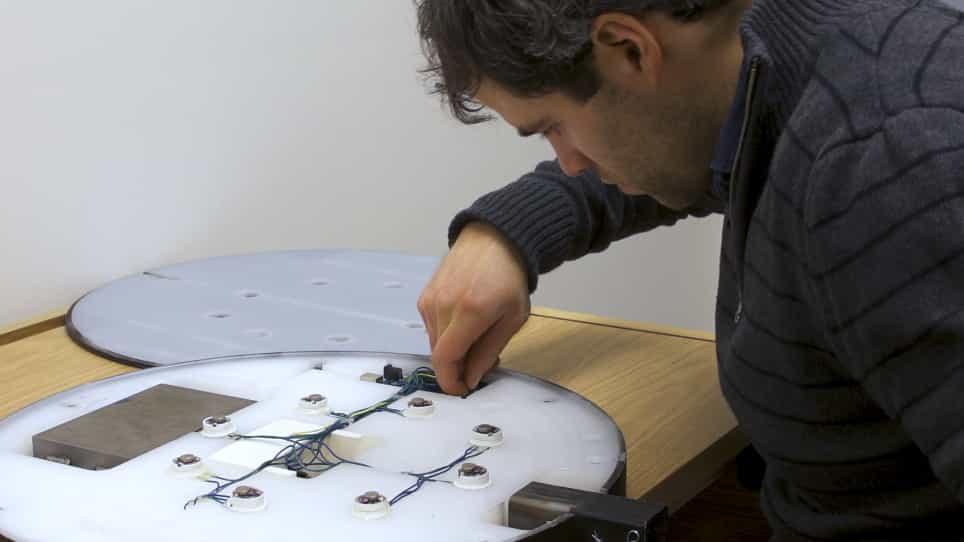
A 3-DOF parallel robot with spherical motion for the rehabilitation and evaluation of balance performance
1Department of Mechanics and Aeronautics, “Sapienza” University of Rome, Italy. fabrizio.patane@uniroma1.it

Abstract:
In this paper a novel electrically actuated parallel robot with three degrees-of-freedom (3 DOF) for dynamic postural studies is presented. The design has been described, the solution to the inverse kinematics has been found, and a numerical solution for the direct kinematics has been proposed. The workspace of the implemented robot is characterized by an angular range of motion of about ±10° for roll and pitch when yaw is in the range ±15°. The robot was constructed and the orientation accuracy was tested by means of an optoelectronic system and by imposing a sinusoidal input, with a frequency of 1 Hz and amplitude of 10°, along the three axes, in sequence. The collected data indicated a phase delay of 1° and an amplitude error of 0.5%-1.5%; similar values were observed for cross-axis sensitivity errors. We also conducted a clinical application on a group of normal subjects, who were standing in equilibrium on the robot base with eyes open (EO) and eyes closed (EC), which was rotated with a tri-axial sinusoidal trajectory with a frequency of 0.5 Hz and amplitude 5° for roll and pitch and 10° for the yaw. The postural configuration of the subjects was recorded with an optoelectronic system. However, due to the mainly technical nature of this paper, only initial validation outcomes are reported here. The clinical application showed that only the tilt and displacement on the sagittal pane of head, trunk, and pelvis in the trials conducted with eyes closed were affected by drift and that the reduction of the yaw rotation and of the mediolateral translation was not a controlled parameter, as happened, instead, for the other anatomical directions.