Related Experiment Video
Updated: Jun 6, 2026


Development of a Novel Task-oriented Rehabilitation Program using a Bimanual Exoskeleton Robotic Hand
Published on: May 20, 2020
On the road to a neuroprosthetic hand: a novel hand grasp orthosis based on functional electrical stimulation
Robert Leeb1, Miguel Gubler, Michele Tavella
1Non-Invasive Brain-Machine Interface, Center for Neuroprosthetics, School of Engineering, Ecole Polytechnique Fédérale de Lausanne, CH-1015, Switzerland. robert.leeb@epfl.ch

Abstract:
To patients who have lost the functionality of their hands as a result of a severe spinal cord injury or brain stroke, the development of new techniques for grasping is indispensable for reintegration and independency in daily life. Functional Electrical Stimulation (FES) of residual muscles can reproduce the most dominant grasping tasks and can be initialized by brain signals. However, due to the very complex hand anatomy and current limitations in FES-technology with surface electrodes, these grasp patterns cannot be smoothly executed. In this paper, we present an adaptable passive hand orthosis which is capable of producing natural and smooth movements when coupled with FES. It evenly synchronizes the grasping movements and applied forces on all fingers, allowing for naturalistic gestures and functional grasps of everyday objects. The orthosis is also equipped with a lock, which allows it to remain in the desired position without the need for long-term stimulation. Furthermore, we quantify improvements offered by the orthosis compare them with natural grasps on healthy subjects.
More Related Videos
 07:34
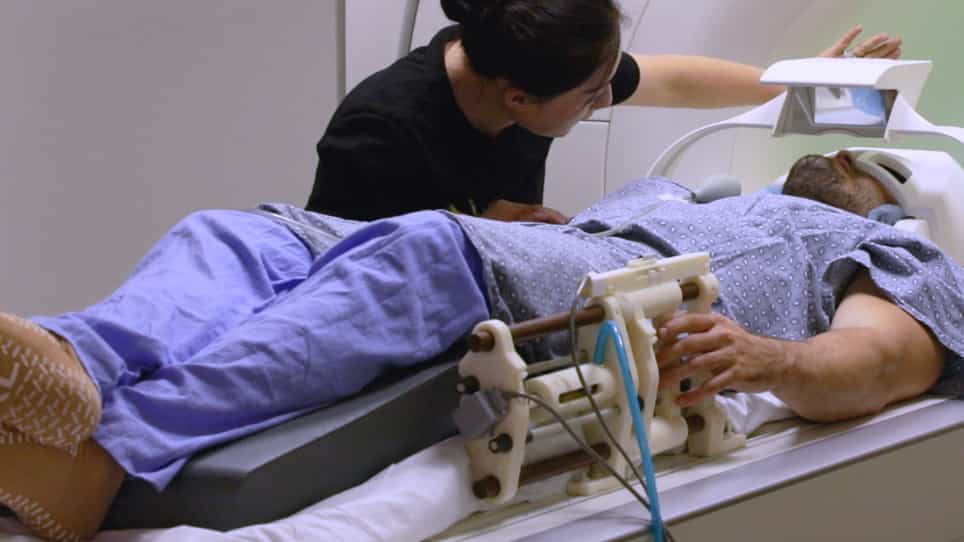
Functional MRI in Conjunction with a Novel MRI-compatible Hand-induced Robotic Device to Evaluate Rehabilitation of Individuals Recovering from Hand Grip Deficits
Published on: November 23, 2019
 03:55
A Flexible Wearable Supernumerary Robotic Limb for Chronic Stroke Patients
Published on: October 27, 2023