Related Experiment Video
Updated: Jun 5, 2026
Construction and Characterization of External Cavity Diode Lasers for Atomic Physics
Published on: April 24, 2014
A multi-band fast-locking delay-locked loop with jitter-bounded feature
Chien-Hung Kuo1, Hung-Jing Lai, Meng-Feng Lin
1National Taiwan Normal University, Applied Electronics Technology, Taipei, Taiwan. chk@ntnu.edu.tw

Abstract:
In this paper, a fast-locking delay-locked loop (DLL) with jitter-bounded feature is presented. In the proposed fast-locking mechanism, a frequency estimator and a programmable voltage circuit are developed to rapidly switch the control node of voltage-controlled delay line to a voltage level near the final required value. After that, the DLL output will be quickly locked by the following charge pumping on the loop filter. In the jitter-bounded approach, two phase-frequency detectors and a tunable delay are employed to hold the output clock jitter between two reference inputs after the DLL is locked. Furthermore, to enhance the flexibility of the presented DLL, a frequency multiplier with fewer active devices is also developed to provide high-frequency clock output for wideband applications. The presented DLL is implemented in a 0.18-μm 1P6M CMOS technology. The active area without contact pads is 0.34 × 0.41 mm(2). A minimum lock time of six clock cycles is measured from no reference input to locked state. The output frequency ranges of the DLL and the frequency multiplier can be measured from 200 to 400 MHz and from 1 to 2 GHz, respectively. The power dissipation of the presented DLL is 31.5 mW at a 1.8 V supply voltage.
Related Concept Videos
 01:01
Feedback Loops
 01:21
Time and frequency -Domain Interpretation of Phase-lag Control
Phase-lag controllers do not place a pole at zero, but instead influence the steady-state error by amplifying any finite,...
 01:14
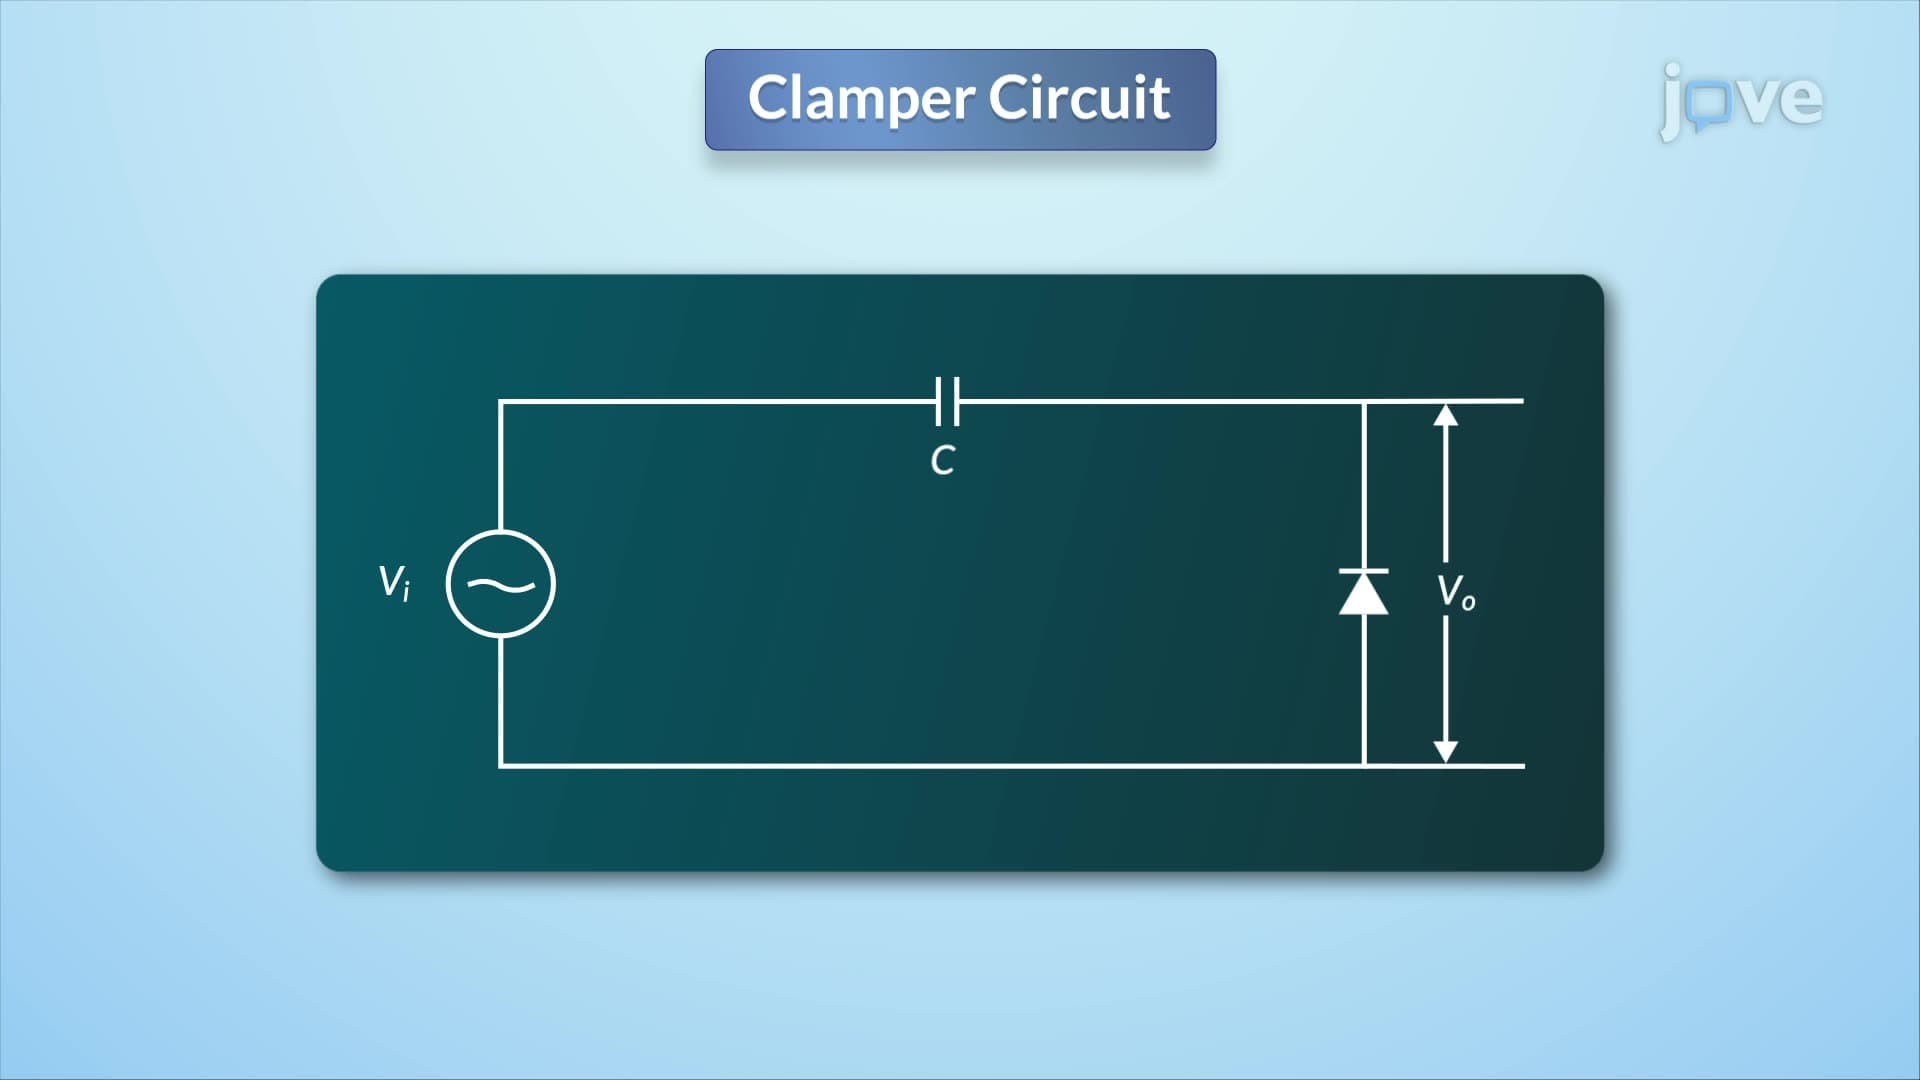
Clamper Circuit
Within this circuit, the diode's orientation prompts the capacitor to charge up to the level of the most negative peak of the input signal. Upon reaching this state, the diode ceases to conduct,...
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be calculated...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:16
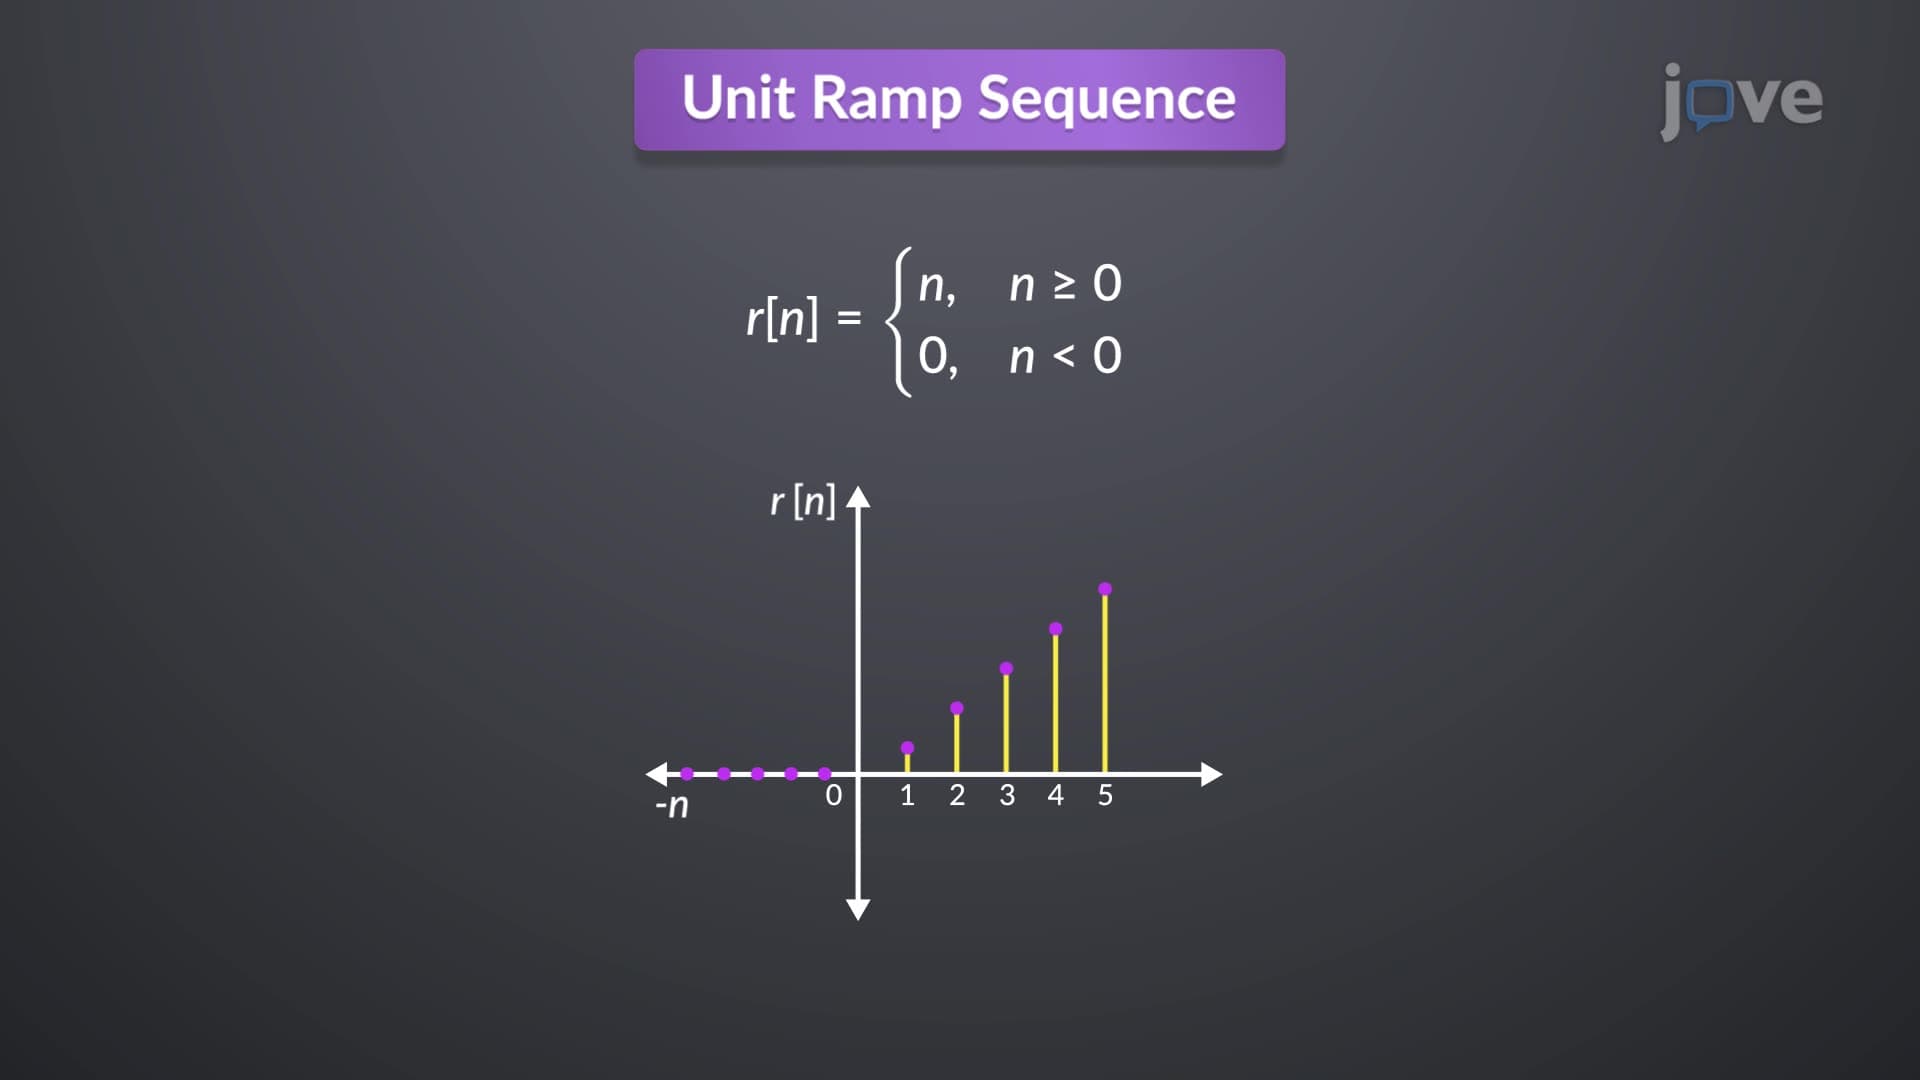
Basic Discrete Time Signals
The unit impulse or sample sequence is mathematically expressed as zero for all n values except at n=0, where it is one. The unit impulse sequence, denoted by δ(n), is the first difference of the unit step sequence, while the unit step sequence u(n) is the...