Related Experiment Video
Updated: Jun 5, 2026

Four-Dimensional CT Analysis Using Sequential 3D-3D Registration
Published on: November 23, 2019
Bone alignment using the iterative closest point algorithm
Maarten Beek1, Carolyn F Small, Randy E Ellis
1Department of Mechanical and Materials Engineering, Queen's University, Kingston, ON, Canada.

Abstract:
Computer assisted surgical interventions and research in joint kinematics rely heavily on the accurate registration of three-dimensional bone surface models reconstructed from various imaging technologies. Anomalous results were seen in a kinematic study of carpal bones using a principal axes alignment approach for the registration. The study was repeated using an iterative closest point algorithm, which is more accurate, but also more demanding to apply. The principal axes method showed errors between 0.35 mm and 0.49 mm for the scaphoid, and between 0.40 mm and 1.22 mm for the pisiform. The iterative closest point method produced errors of less than 0.4 mm. These results show that while the principal axes method approached the accuracy of the iterative closest point algorithm in asymmetrical bones, there were more pronounced errors in bones with some symmetry. Principal axes registration for carpal bones should be avoided.
Related Concept Videos
 01:30
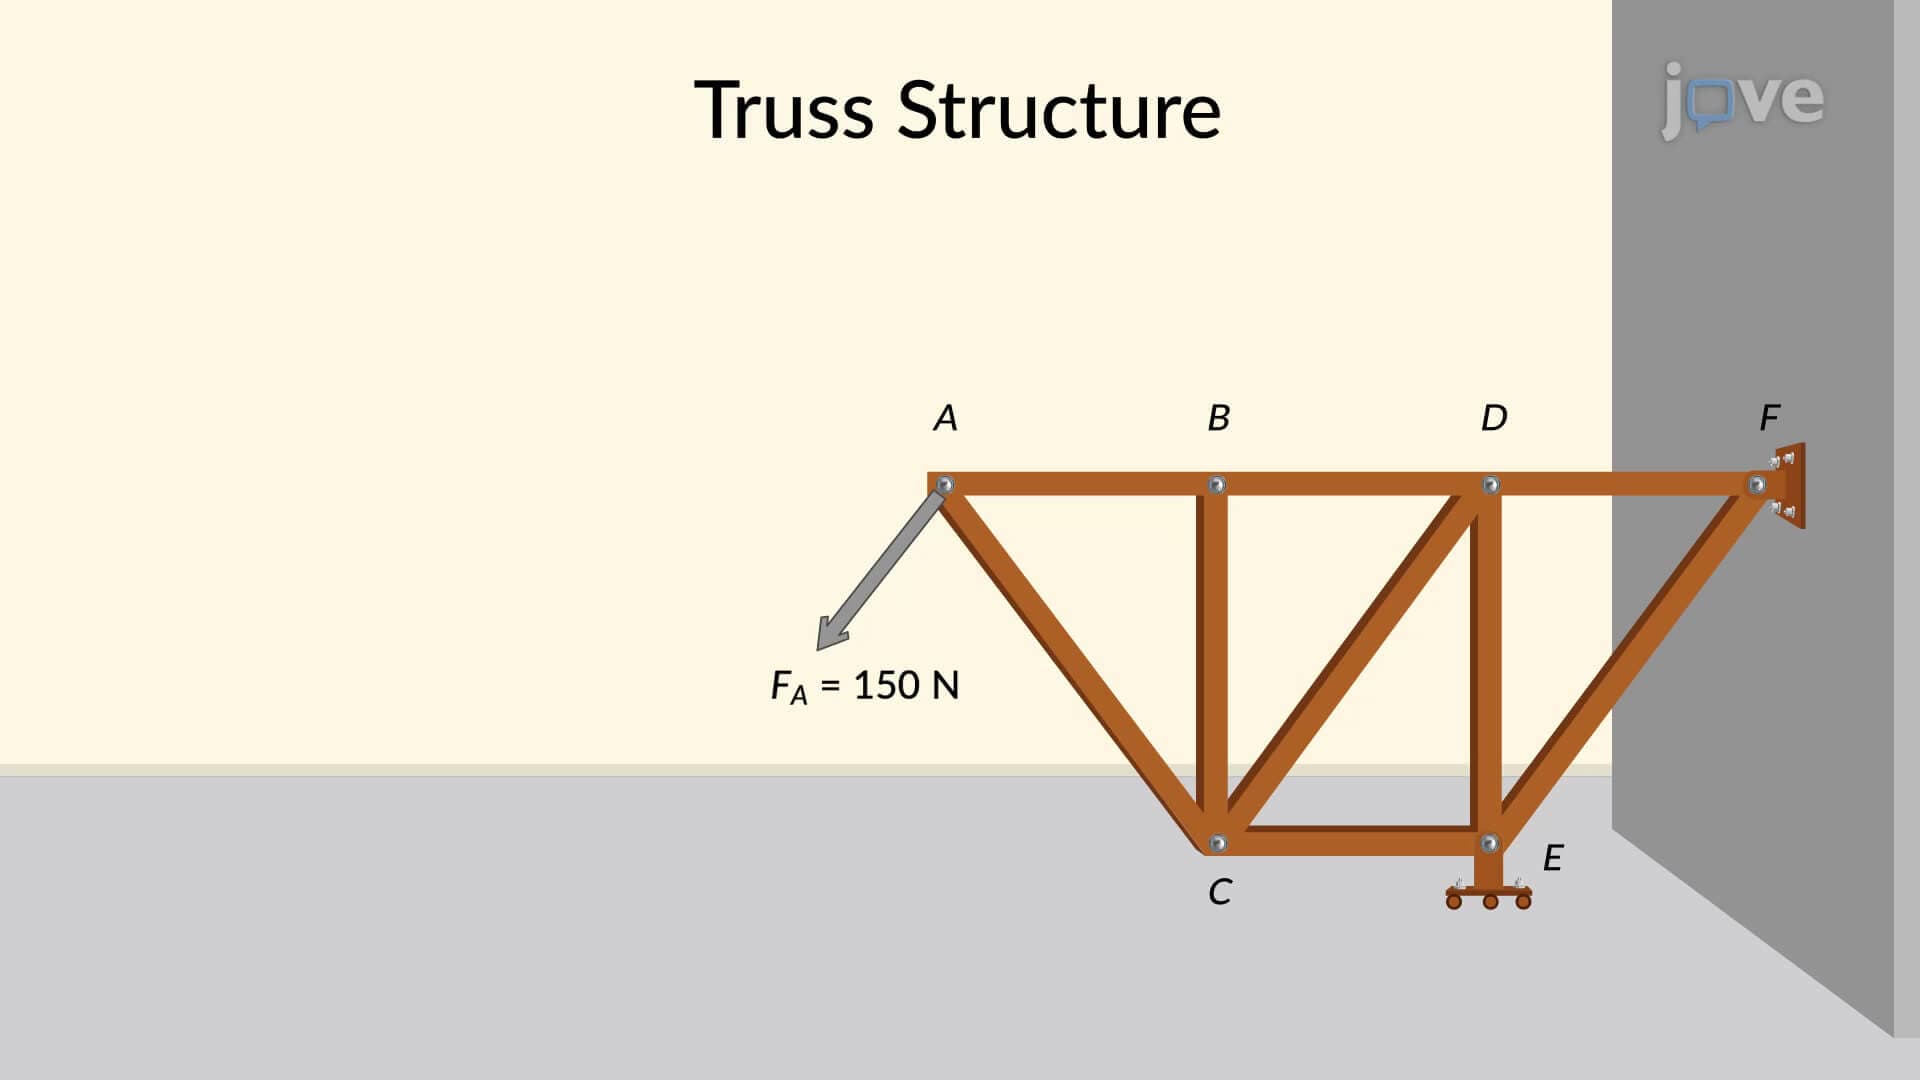
Method of Joints: Problem Solving II
 01:13
Maximum Deflection
The maximum deflection occurs at a specific point, known as point O, where the tangent to the deflection curve is horizontal. To find point O, the slope of the tangent at any...
 01:17
Beams with Unsymmetric Loadings
The first moment-area theorem determines the slope at any point on the beam. This theorem indicates that the change in slope between two points on a beam...