Computing Smooth Time Trajectories for Camera and Deformable Shape in Structure from Motion with Occlusion
Related Experiment Video
Updated: Jun 3, 2026
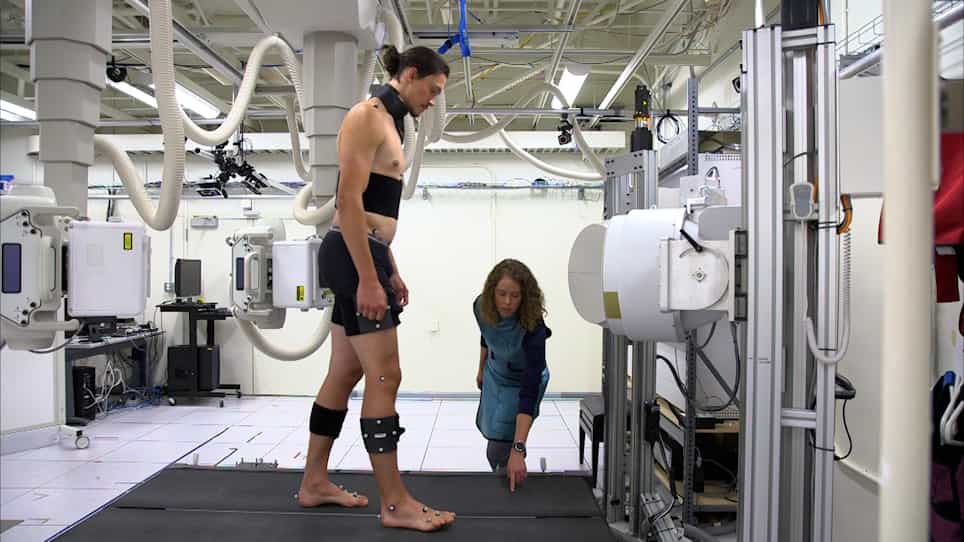
In Vivo Quantification of Hip Arthrokinematics during Dynamic Weight-bearing Activities using Dual Fluoroscopy
Published on: July 2, 2021

Abstract:
We address the classical computer vision problems of rigid and nonrigid structure from motion (SFM) with occlusion. We assume that the columns of the input observation matrix W describe smooth 2D point trajectories over time. We then derive a family of efficient methods that estimate the column space of W using compact parameterizations in the Discrete Cosine Transform (DCT) domain. Our methods tolerate high percentages of missing data and incorporate new models for the smooth time trajectories of 2D-points, affine and weak-perspective cameras, and 3D deformable shape. We solve a rigid SFM problem by estimating the smooth time trajectory of a single camera moving around the structure of interest. By considering a weak-perspective camera model from the outset, we directly compute euclidean 3D shape reconstructions without requiring postprocessing steps such as euclidean upgrade and bundle adjustment. Our results on real SFM data sets with high percentages of missing data compared positively to those in the literature. In nonrigid SFM, we propose a novel 3D shape trajectory approach that solves for the deformable structure as the smooth time trajectory of a single point in a linear shape space. A key result shows that, compared to state-of-the-art algorithms, our nonrigid SFM method can better model complex articulated deformation with higher frequency DCT components while still maintaining the low-rank factorization constraint. Finally, we also offer an approach for nonrigid SFM when W is presented with missing data.
Related Concept Videos
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:26
Orthogonal Trajectories
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...