Related Experiment Video
Updated: Jun 3, 2026

Comprehensive Understanding of Inactivity-Induced Gait Alteration in Rodents
Published on: July 6, 2022
Invariance of locomotor trajectories across visual and gait direction conditions
Quang-Cuong Pham1, Alain Berthoz, Halim Hicheur
1Laboratoire de Physiologie de la Perception et de l'Action, Collège de France CNRS, UMR 7152, 11 place Marcelin Berthelot, 75005, Paris, France. cuong.pham@normalesup.org

Abstract:
We studied the influence of vision (walking with or without vision) and of gait direction (walking forward or backward) on goal-oriented locomotion in humans. Subjects had to walk, in a free environment, from a given position and orientation towards a distant arrow which constrained their final position and orientation. We found that the average trajectories were mostly similar across the tested conditions, which suggests that locomotor trajectories are generated at a high cognitive level and, to some extent, independently of the detailed sensory and motor implementation levels. The variability profiles around the average trajectories were similar across the gait direction conditions but differed greatly across the visual conditions, indicating the existence of motor-independent and vision-dependent control mechanisms. Taken together, our observations argue further in favour of a top-down implementation of goal-oriented locomotion, where the control of locomotion is specified at the level of whole-body trajectories and then implemented through specific motor strategies.
More Related Videos
Related Concept Videos
 01:26
Orthogonal Trajectories
 01:20
Instantaneous Center of Zero Velocity
To analyze this, consider two points on the wheel: point A and point B. The absolute velocity of point B can be expressed as the vector sum of the absolute velocity of point A and the relative velocity of point B with respect to point A. To simplify this analysis,...
 01:03
Inertial Frames of Reference
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:27
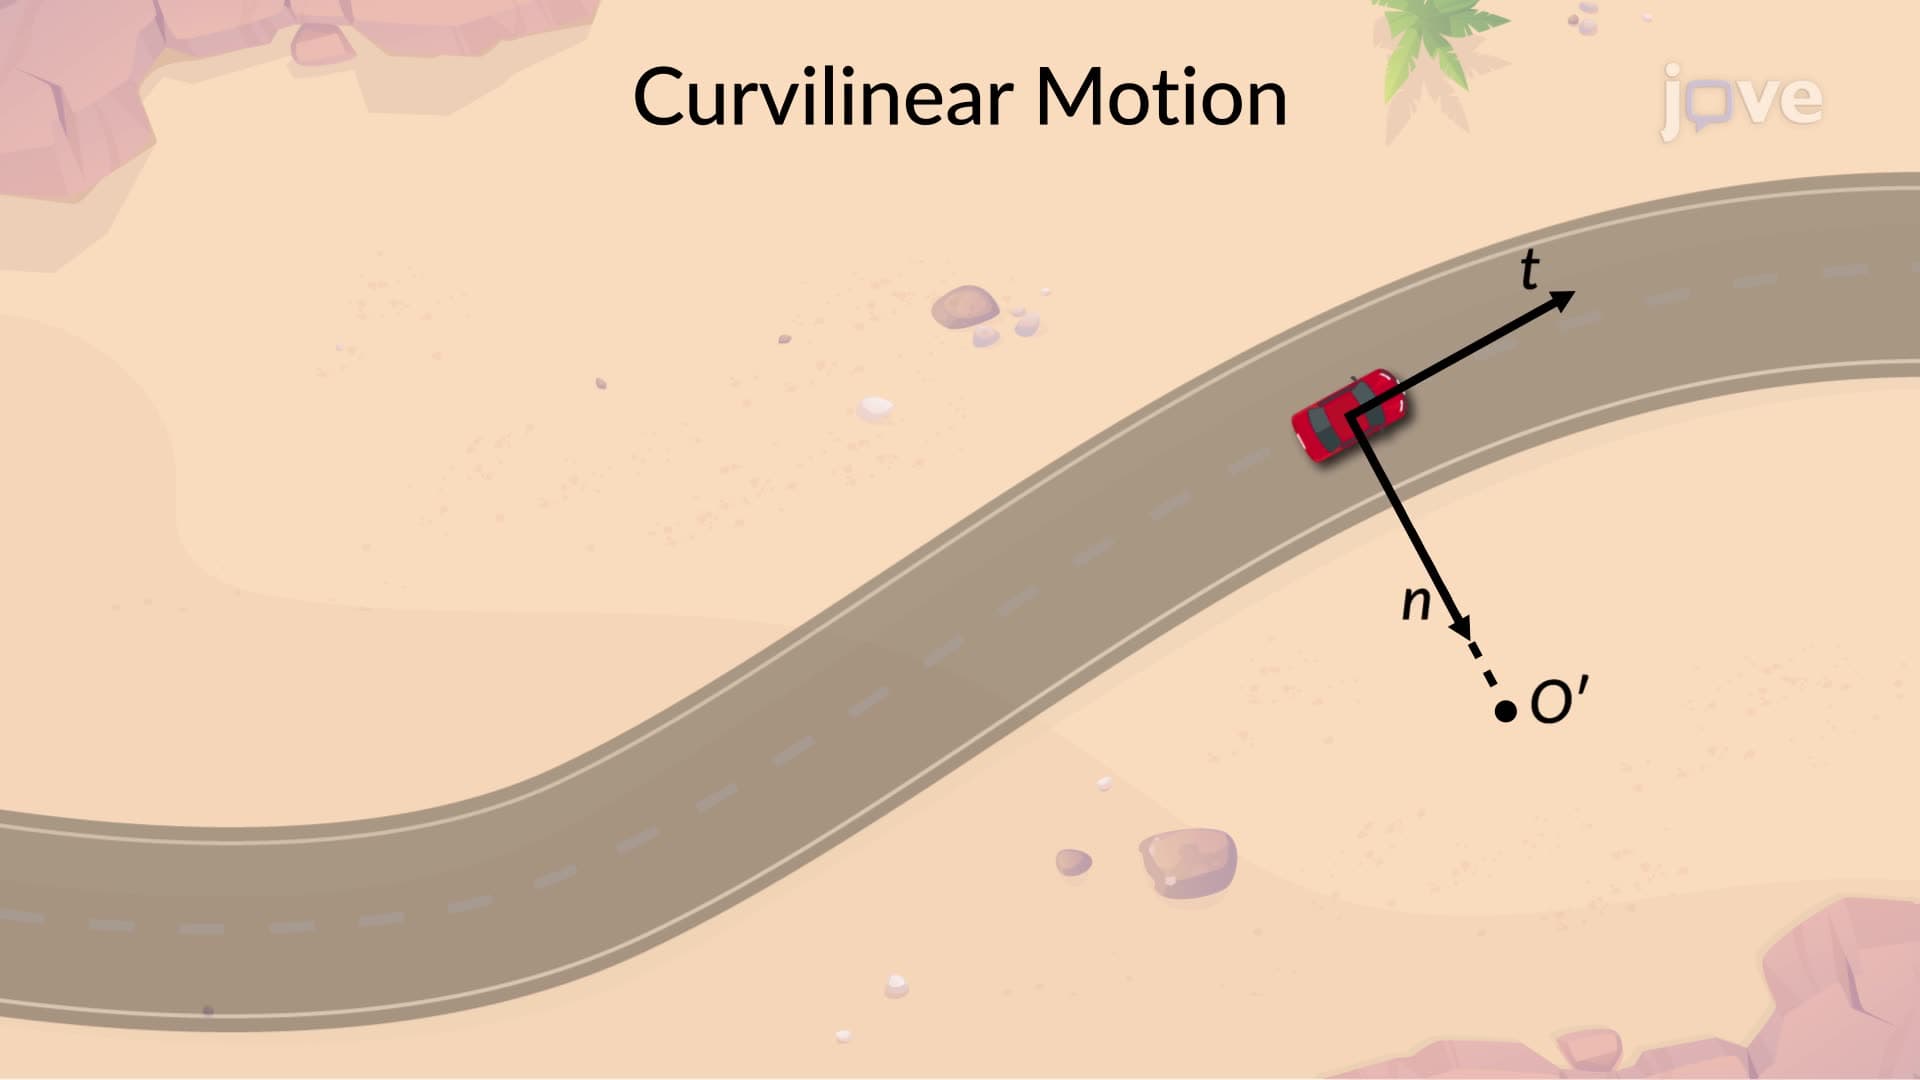
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...