Related Experiment Video
Updated: Jun 2, 2026
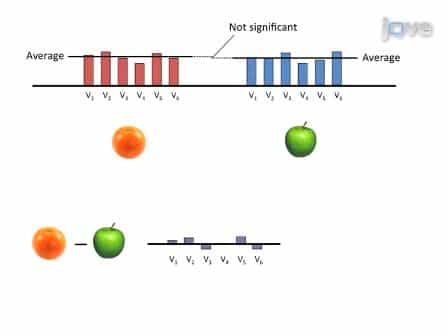

Cross-Modal Multivariate Pattern Analysis
Published on: November 9, 2011
Visual motion induces a forward prediction of spatial pattern
Neil W Roach1, Paul V McGraw, Alan Johnston
1Visual Neuroscience Group, School of Psychology, The University of Nottingham, Nottingham NG7 2RD, UK. nwr@psychology.nottingham.ac.uk

Abstract:
Cortical motion analysis continuously encodes image velocity but might also be used to predict future patterns of sensory input along the motion path. We asked whether this predictive aspect of motion is exploited by the human visual system. Targets can be more easily detected at the leading as compared to the trailing edge of motion [1], but this effect has been attributed to a nonspecific boost in contrast gain at the leading edge, linked to motion-induced shifts in spatial position [1-4]. Here we show that the detectability of a local sinusoidal target presented at the ends of a region containing motion is phase dependent at the leading edge, but not at the trailing edge. These two observations rule out a simple gain control mechanism that modulates contrast energy and passive filtering explanations, respectively. By manipulating the relative orientation of the moving pattern and target, we demonstrate that the resulting spatial variation in detection threshold along the edge closely resembles the superposition of sensory input and an internally generated predicted signal. These findings show that motion induces a forward prediction of spatial pattern that combines with the cortical representation of the future stimulus.

Related Concept Videos
 01:24
Vision
 01:15
Depth Perception and Spatial Vision
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:27
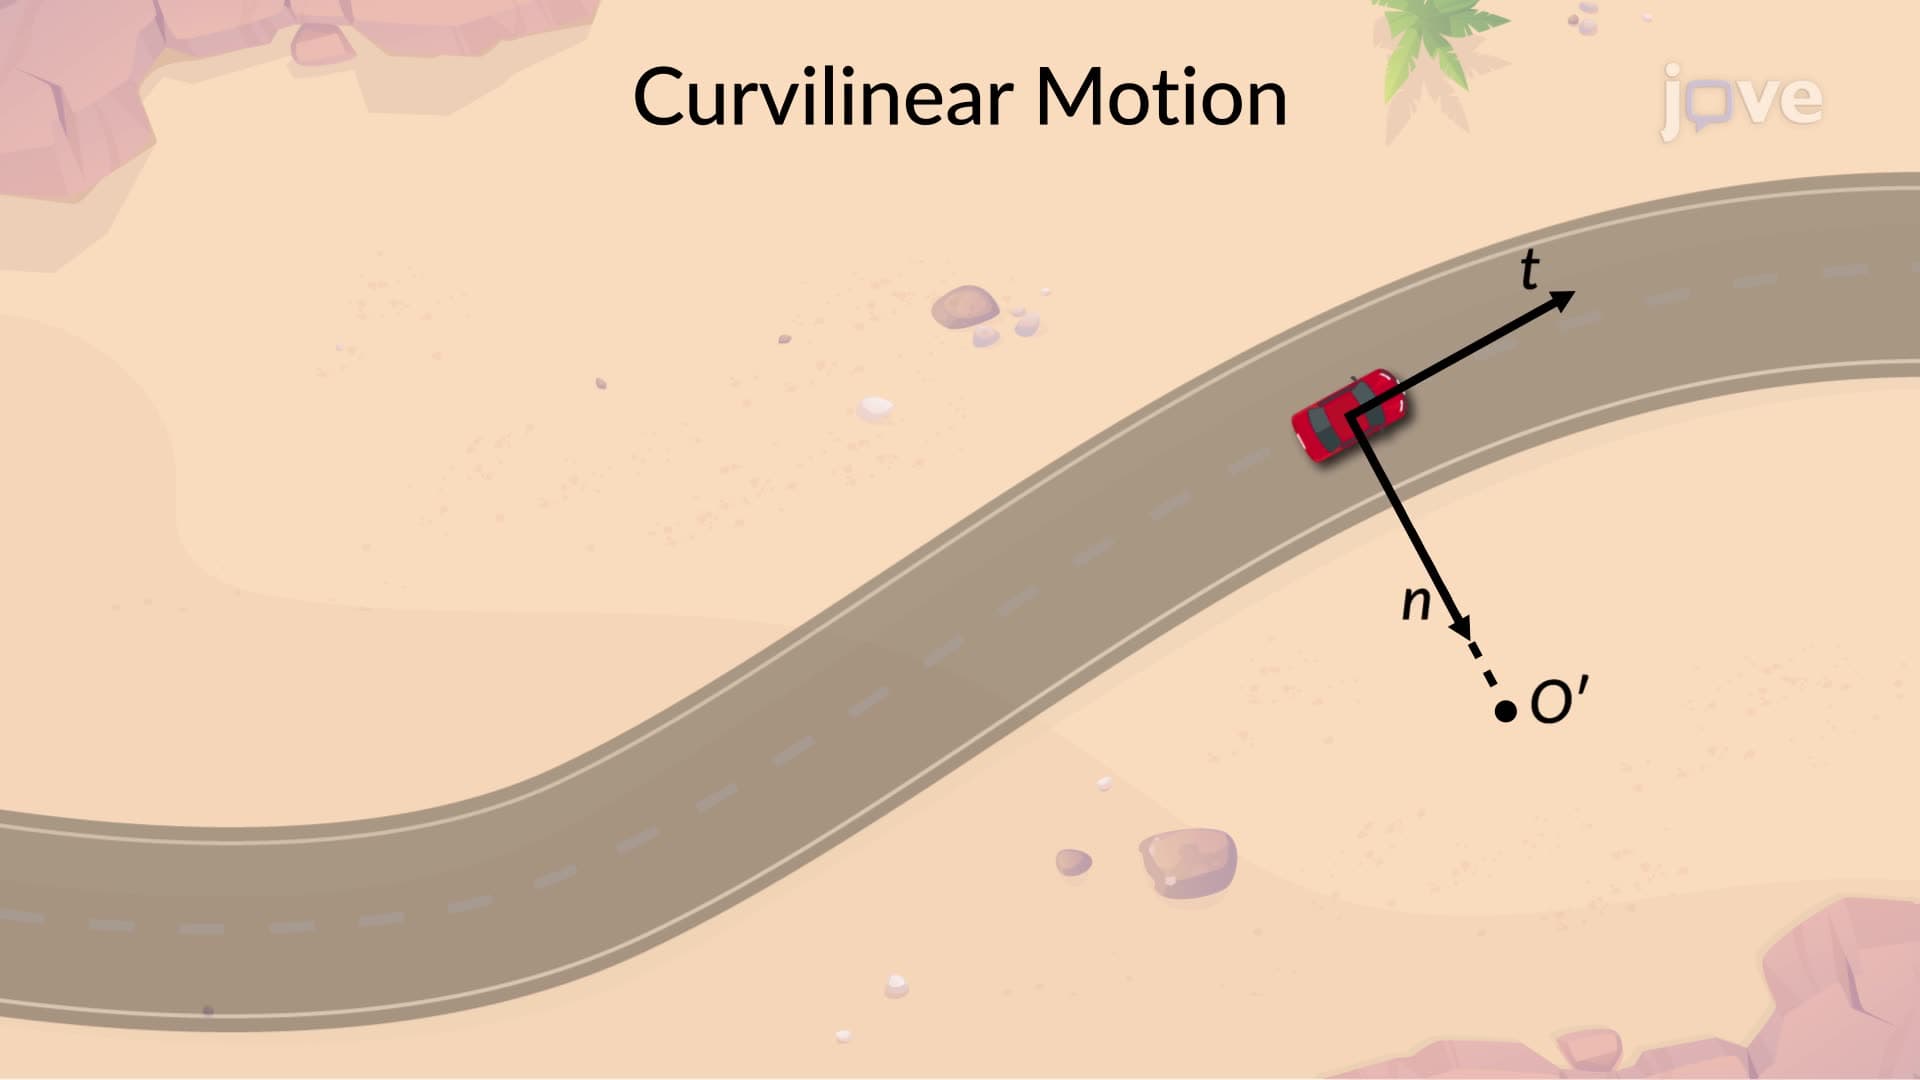
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...