Related Experiment Video
Updated: Jun 2, 2026


Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
Does tilt/translation ratio affect perception of deceleration in driving simulators?
Anca M Stratulat1, Vincent Roussarie, Jean-Louis Vercher
1UMR 6233 Institut des Sciences du Mouvement, CNRS-Université de la Méditerranée, Faculté des Sciences du Sport, Marseille Cedex, France. anca.stratulat@gmail.com

Abstract:
Tilt-coordination is a technique which uses the tilt-translation ambiguity of the vestibular system to simulate linear accelerations on dynamic driving simulators, in combination with real linear accelerations. However, the tilt/translation ratio is chosen empirically. We experimentally determine the most realistic tilt/translation ratio to simulate a given value of deceleration. Under specific conditions of driving simulation, five tilt/translation ratios were applied, with an inverse-proportional quantity of tilt and translation, so that the sum of the two (the proportion of the deceleration simulated by translational motion and the proportion simulated by tilt) was always equal to the same overall value (0.8 m/s(2)). We find that different ratios lead to different perceptions, depending on the quantity of tilt and translation. With a higher tilt ratio, the braking is perceived as being stronger than when there is a higher translation ratio and the most realistic tilt/translation ratio found is neither pure tilt, nor pure translation, but 35/65% tilt/translation. The way these different ratios are perceived during braking is discussed from vestibular and non-vestibular points of view.
Related Concept Videos
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
 01:10
Relative Motion Analysis - Acceleration
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:26
Application of Antiderivatives: Linear Motion
 01:27
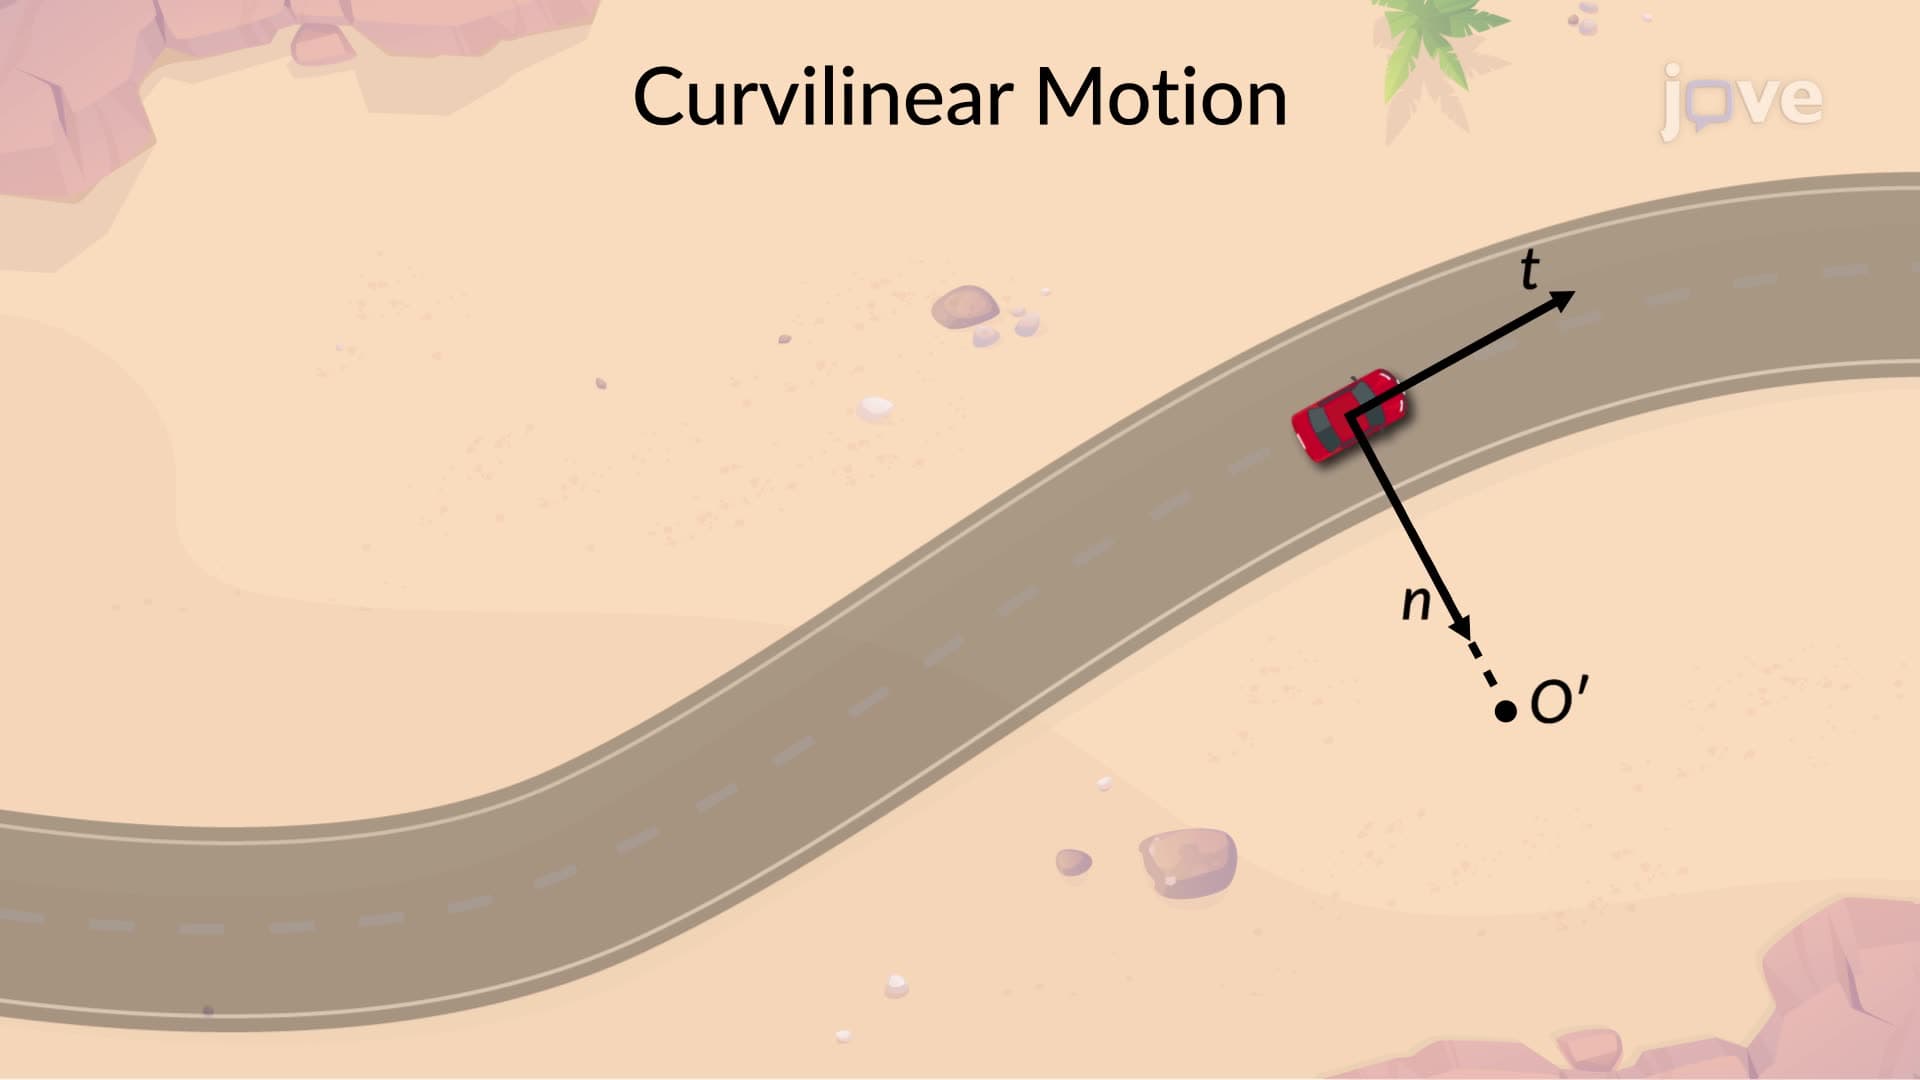
Curvilinear Motion: Normal and Tangential Components
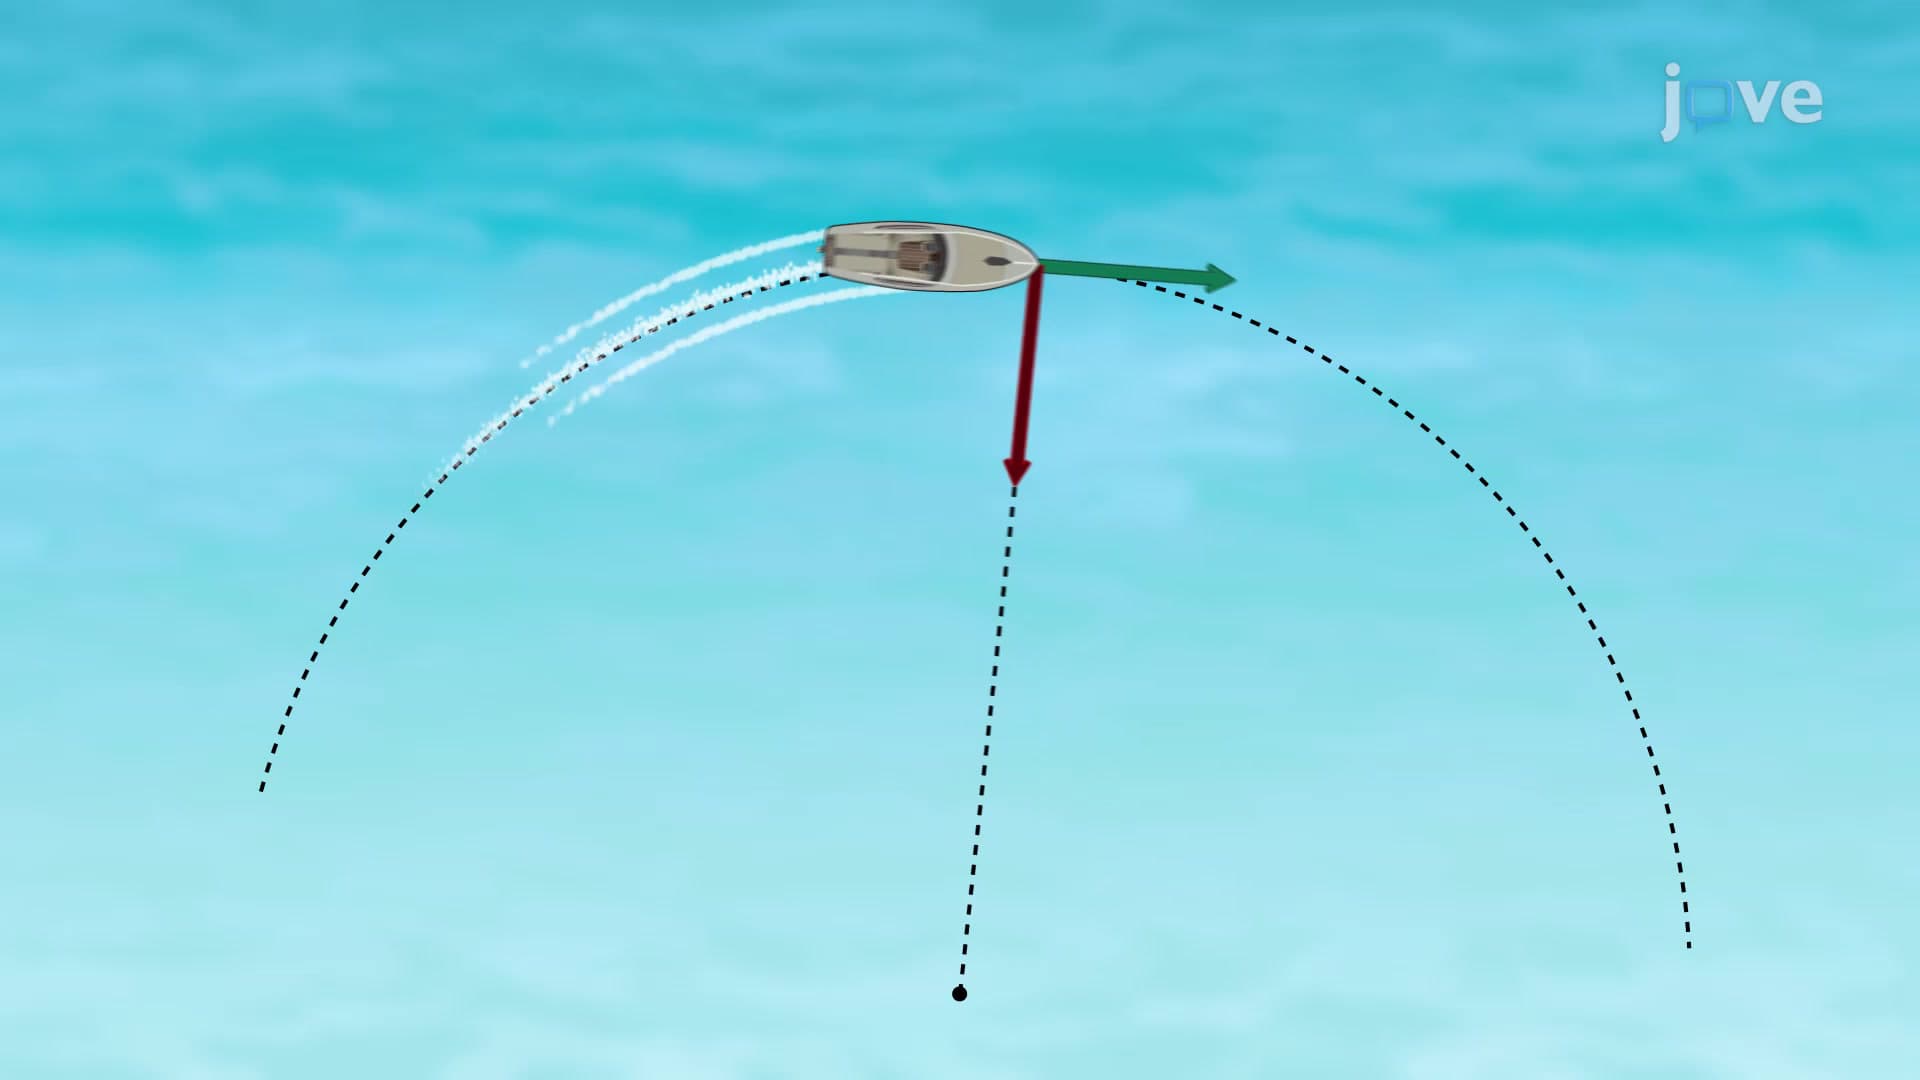
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:10
Direction of Acceleration Vectors