Related Experiment Video
Updated: May 31, 2026

WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Chaotic dynamics and control of deterministic ratchets
Fereydoon Family1, H A Larrondo, D G Zarlenga
1Department of Physics, Emory University, Atlanta, GA 30322, USA.

Abstract:
Deterministic ratchets, in the inertial and also in the overdamped limit, have a very complex dynamics, including chaotic motion. This deterministically induced chaos mimics, to some extent, the role of noise, changing, on the other hand, some of the basic properties of thermal ratchets; for example, inertial ratchets can exhibit multiple reversals in the current direction. The direction depends on the amount of friction and inertia, which makes it especially interesting for technological applications such as biological particle separation. We overview in this work different strategies to control the current of inertial ratchets. The control parameters analysed are the strength and frequency of the periodic external force, the strength of the quenched noise that models a non-perfectly-periodic potential, and the mass of the particles. Control mechanisms are associated with the fractal nature of the basins of attraction of the mean velocity attractors. The control of the overdamped motion of noninteracting particles in a rocking periodic asymmetric potential is also reviewed. The analysis is focused on synchronization of the motion of the particles with the external sinusoidal driving force. Two cases are considered: a perfect lattice without disorder and a lattice with noncorrelated quenched noise. The amplitude of the driving force and the strength of the quenched noise are used as control parameters.
Related Concept Videos
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:21
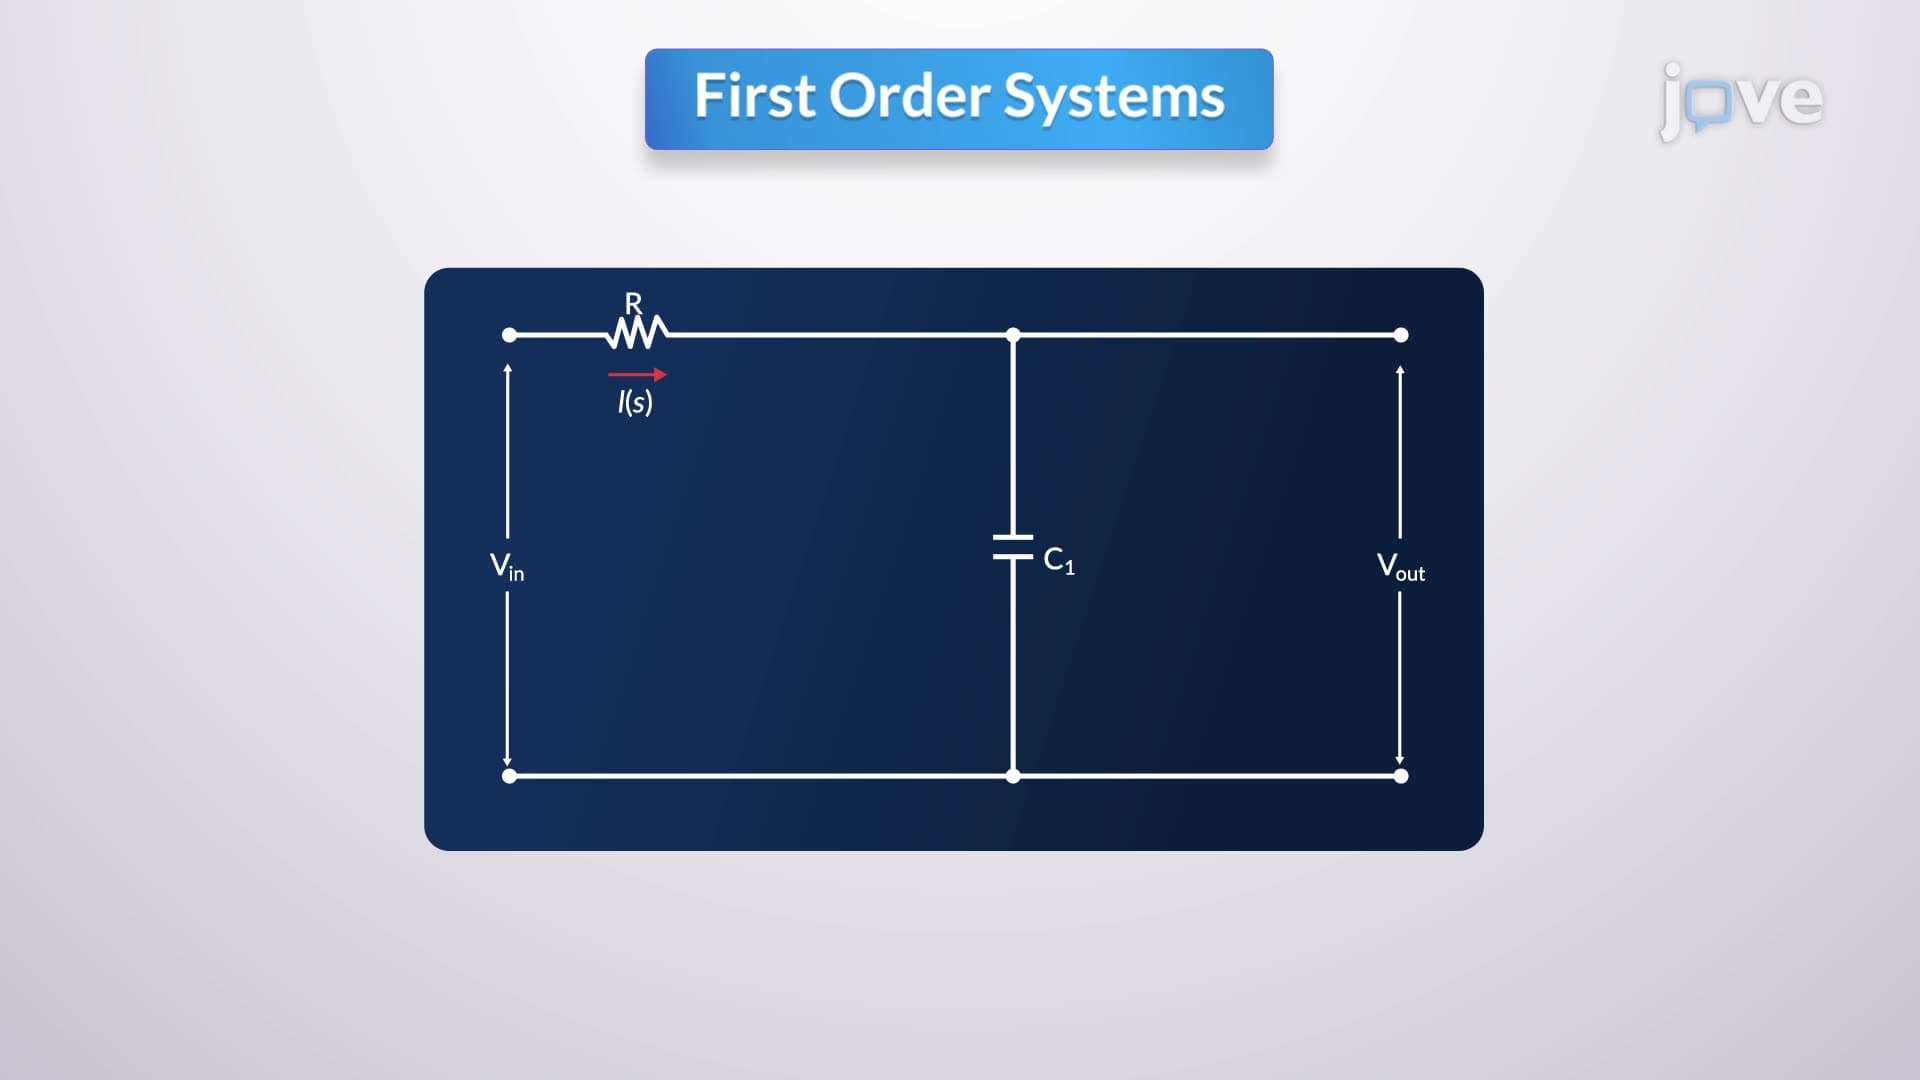
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
 01:15
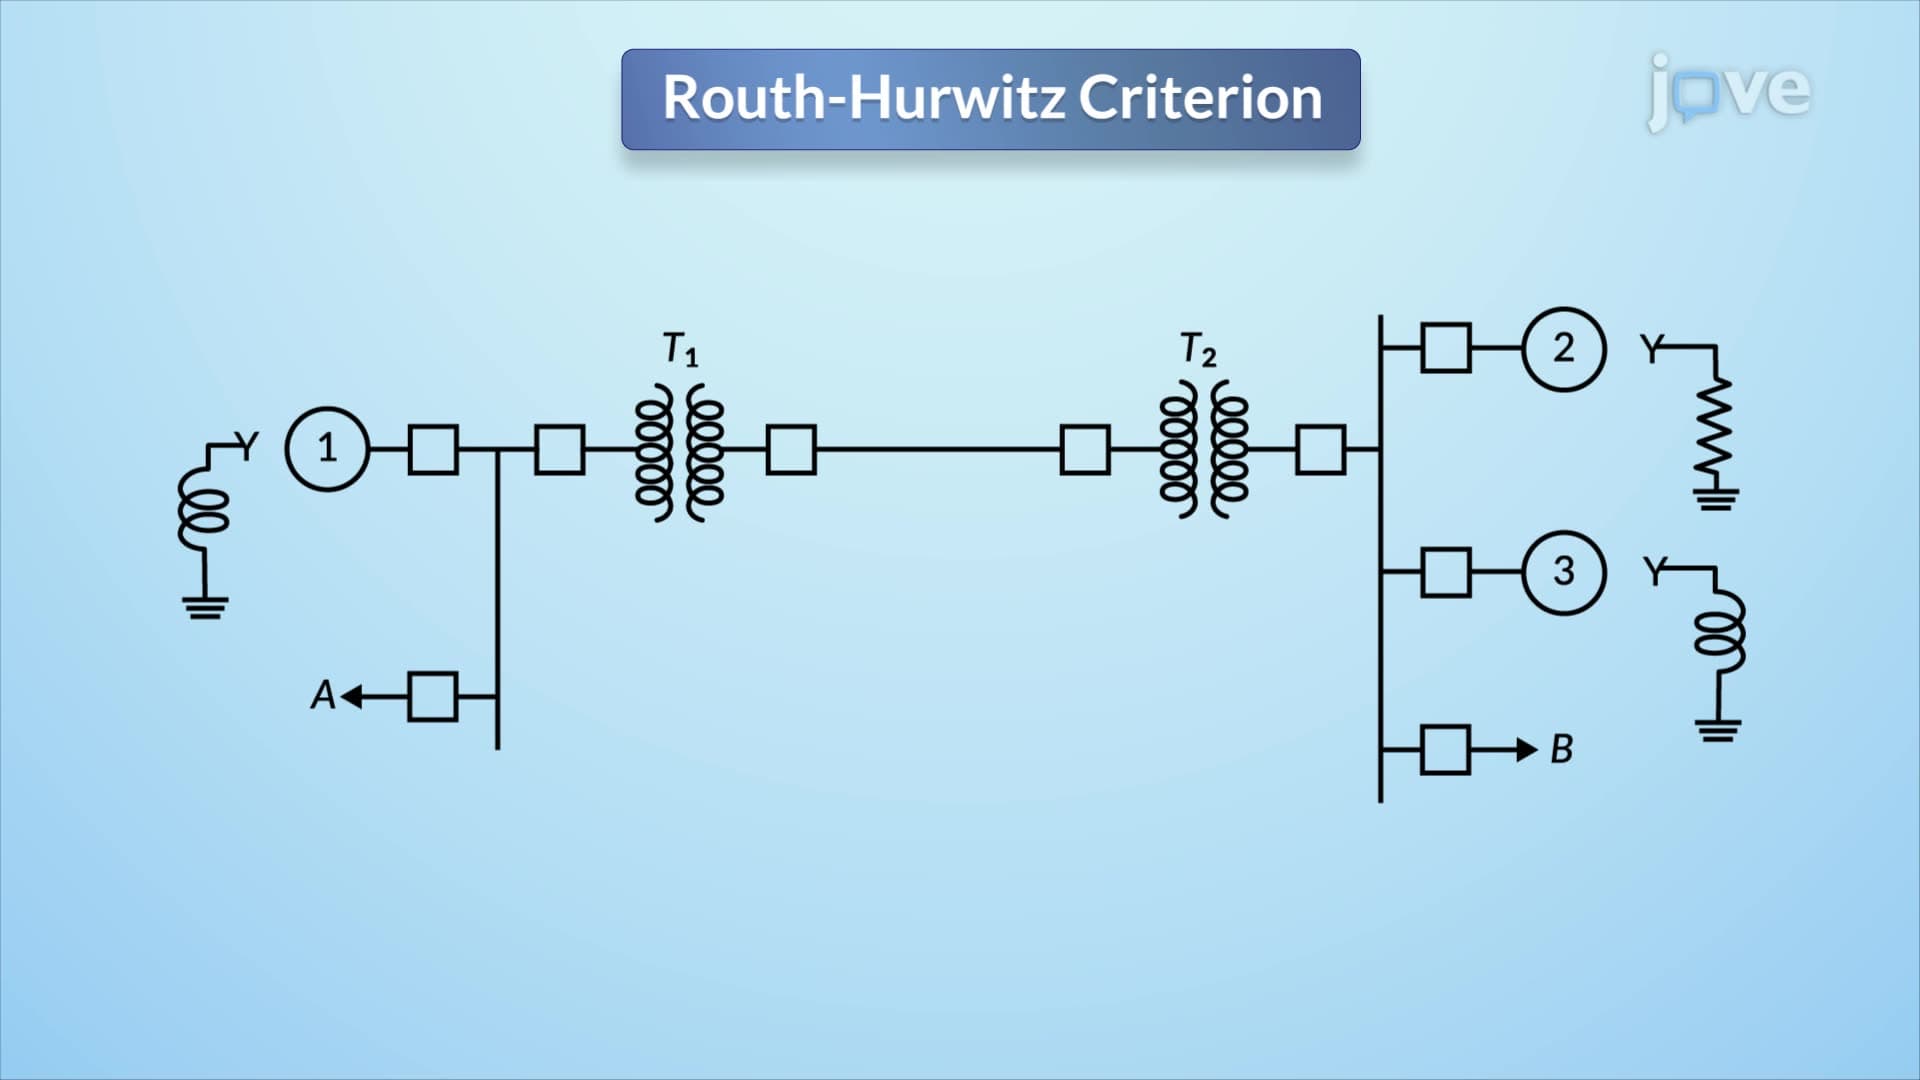
Routh-Hurwitz Criterion I
To apply the Routh-Hurwitz criterion, a Routh table is constructed. The table's rows are labeled with powers of the complex frequency variable s, starting from the...
 01:21
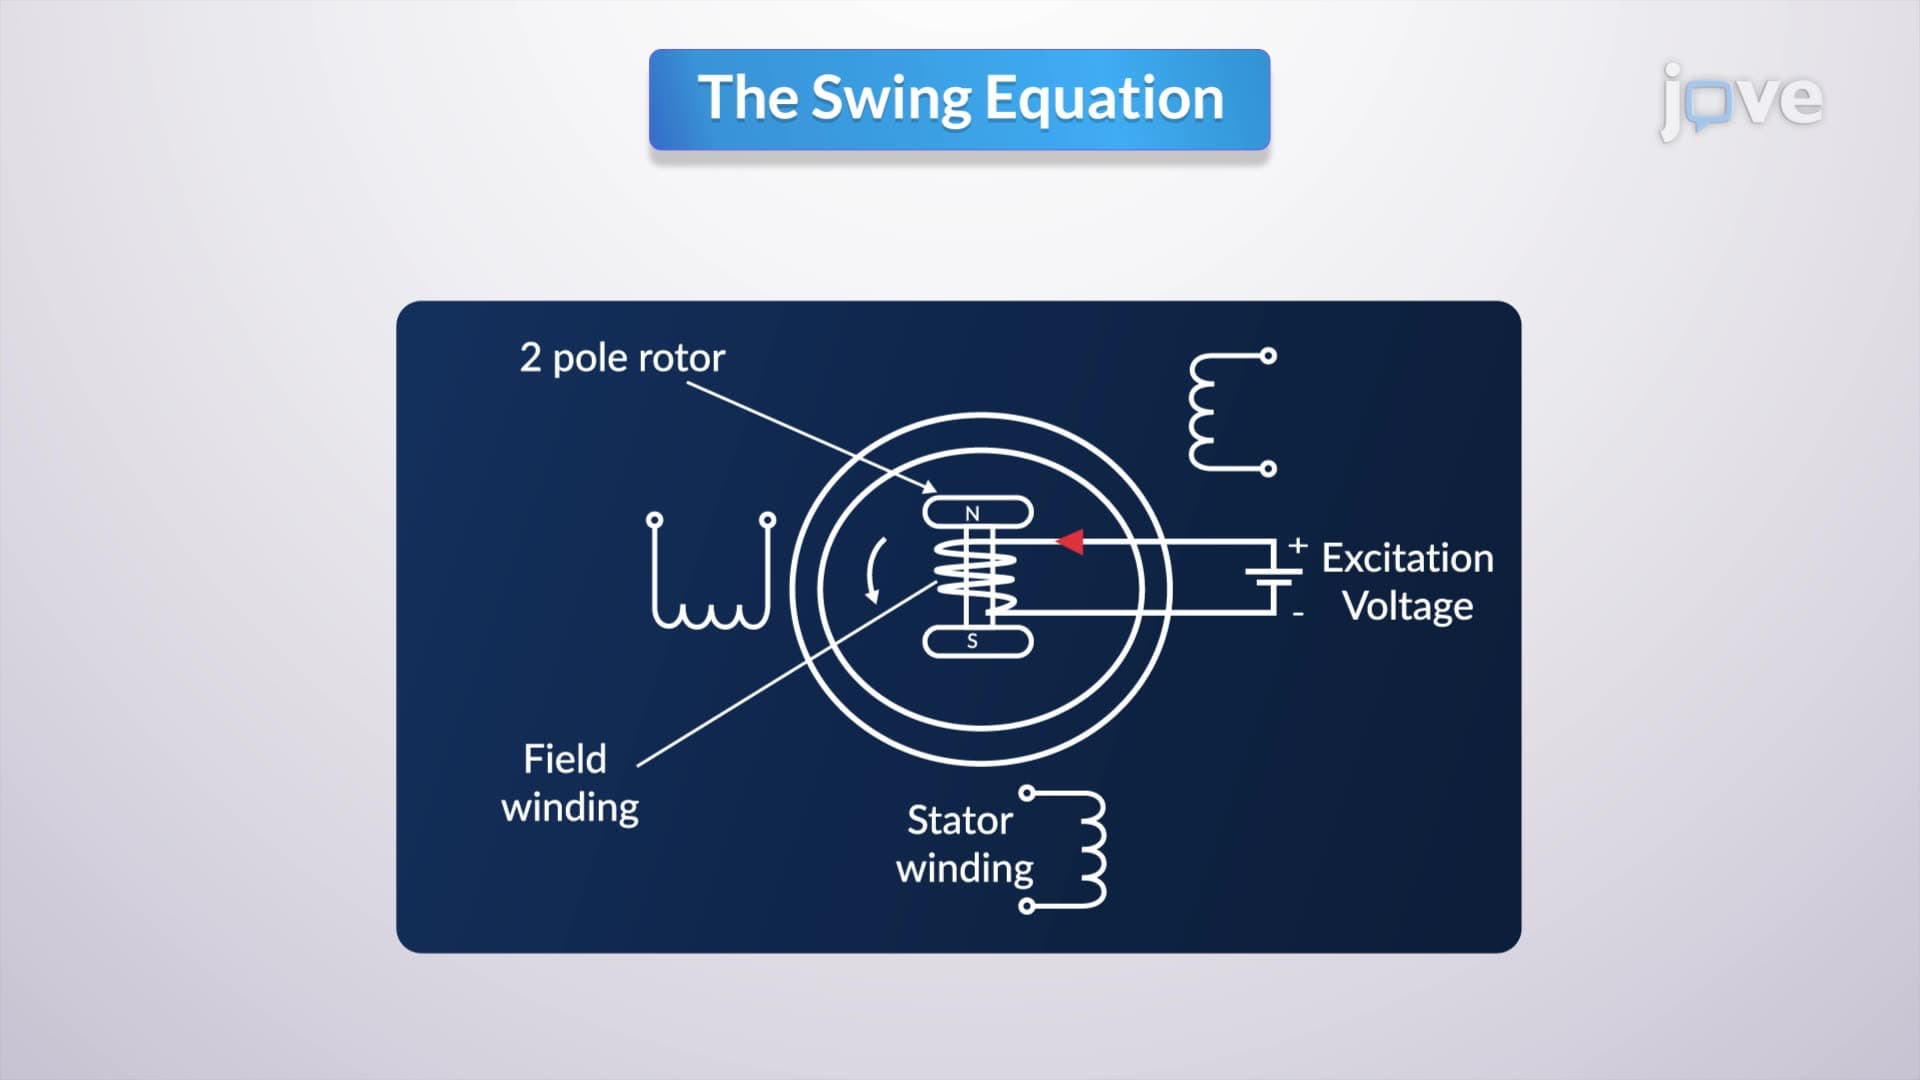
The Swing Equation
In a steady-state operation, the mechanical torque (Τm) supplied to the generator is balanced by the electrical torque (Τe)...