Related Experiment Video
Updated: May 29, 2026

Exploring Caspase Mutations and Post-Translational Modification by Molecular Modeling Approaches
Published on: October 13, 2022
An exact expression to calculate the derivatives of position-dependent observables in molecular simulations with
Pablo Echenique1, Claudio N Cavasotto, Monica De Marco
1Instituto de Química Física Rocasolano, Consejo Superior de Investigaciones Científicas, Madrid, Spain. echenique.p@gmail.com

Abstract:
In this work, we introduce an algorithm to compute the derivatives of physical observables along the constrained subspace when flexible constraints are imposed on the system (i.e., constraints in which the constrained coordinates are fixed to configuration-dependent values). The presented scheme is exact, it does not contain any tunable parameter, and it only requires the calculation and inversion of a sub-block of the Hessian matrix of second derivatives of the function through which the constraints are defined. We also present a practical application to the case in which the sought observables are the Euclidean coordinates of complex molecular systems, and the function whose minimization defines the flexible constraints is the potential energy. Finally, and in order to validate the method, which, as far as we are aware, is the first of its kind in the literature, we compare it to the natural and straightforward finite-differences approach in a toy system and in three molecules of biological relevance: methanol, N-methyl-acetamide and a tri-glycine peptide.
Related Concept Videos
 01:23
Equilibrium Conditions for a Particle
To understand the concept of equilibrium, let us first consider the forces acting on an object. When different forces act on an object, they can...
 01:26
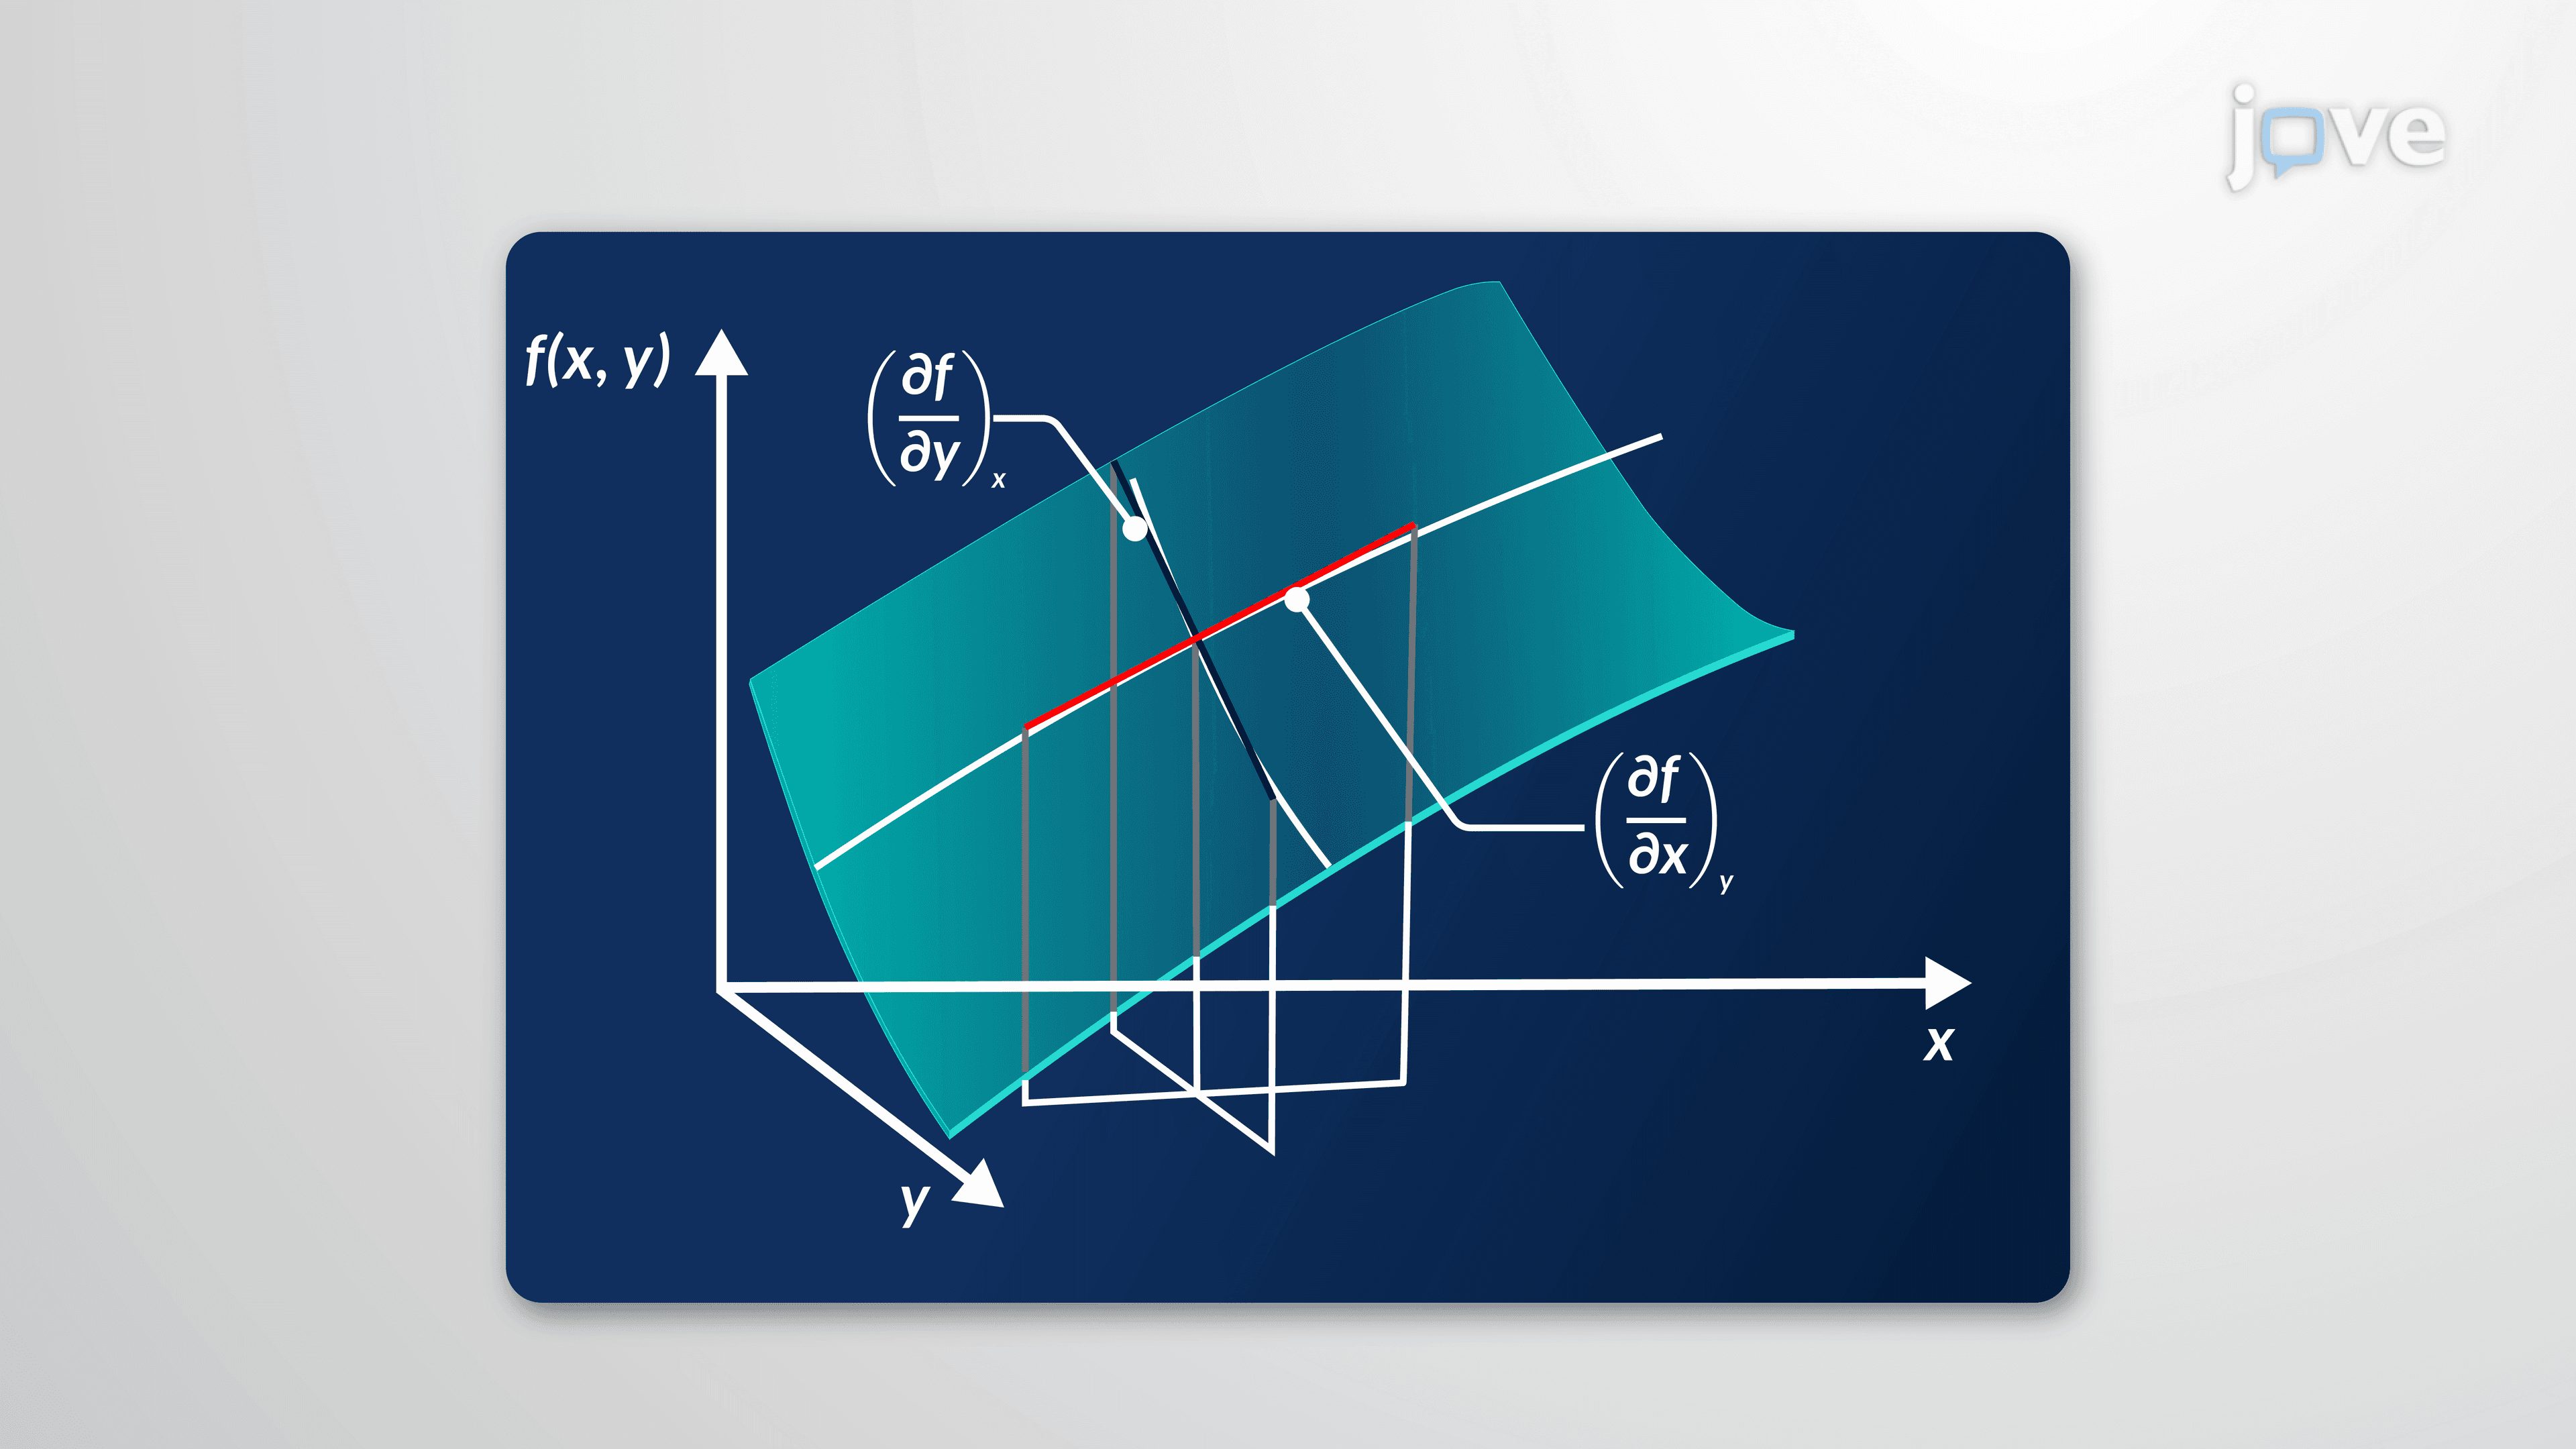
Partial Derivatives and Gas Laws
 01:27
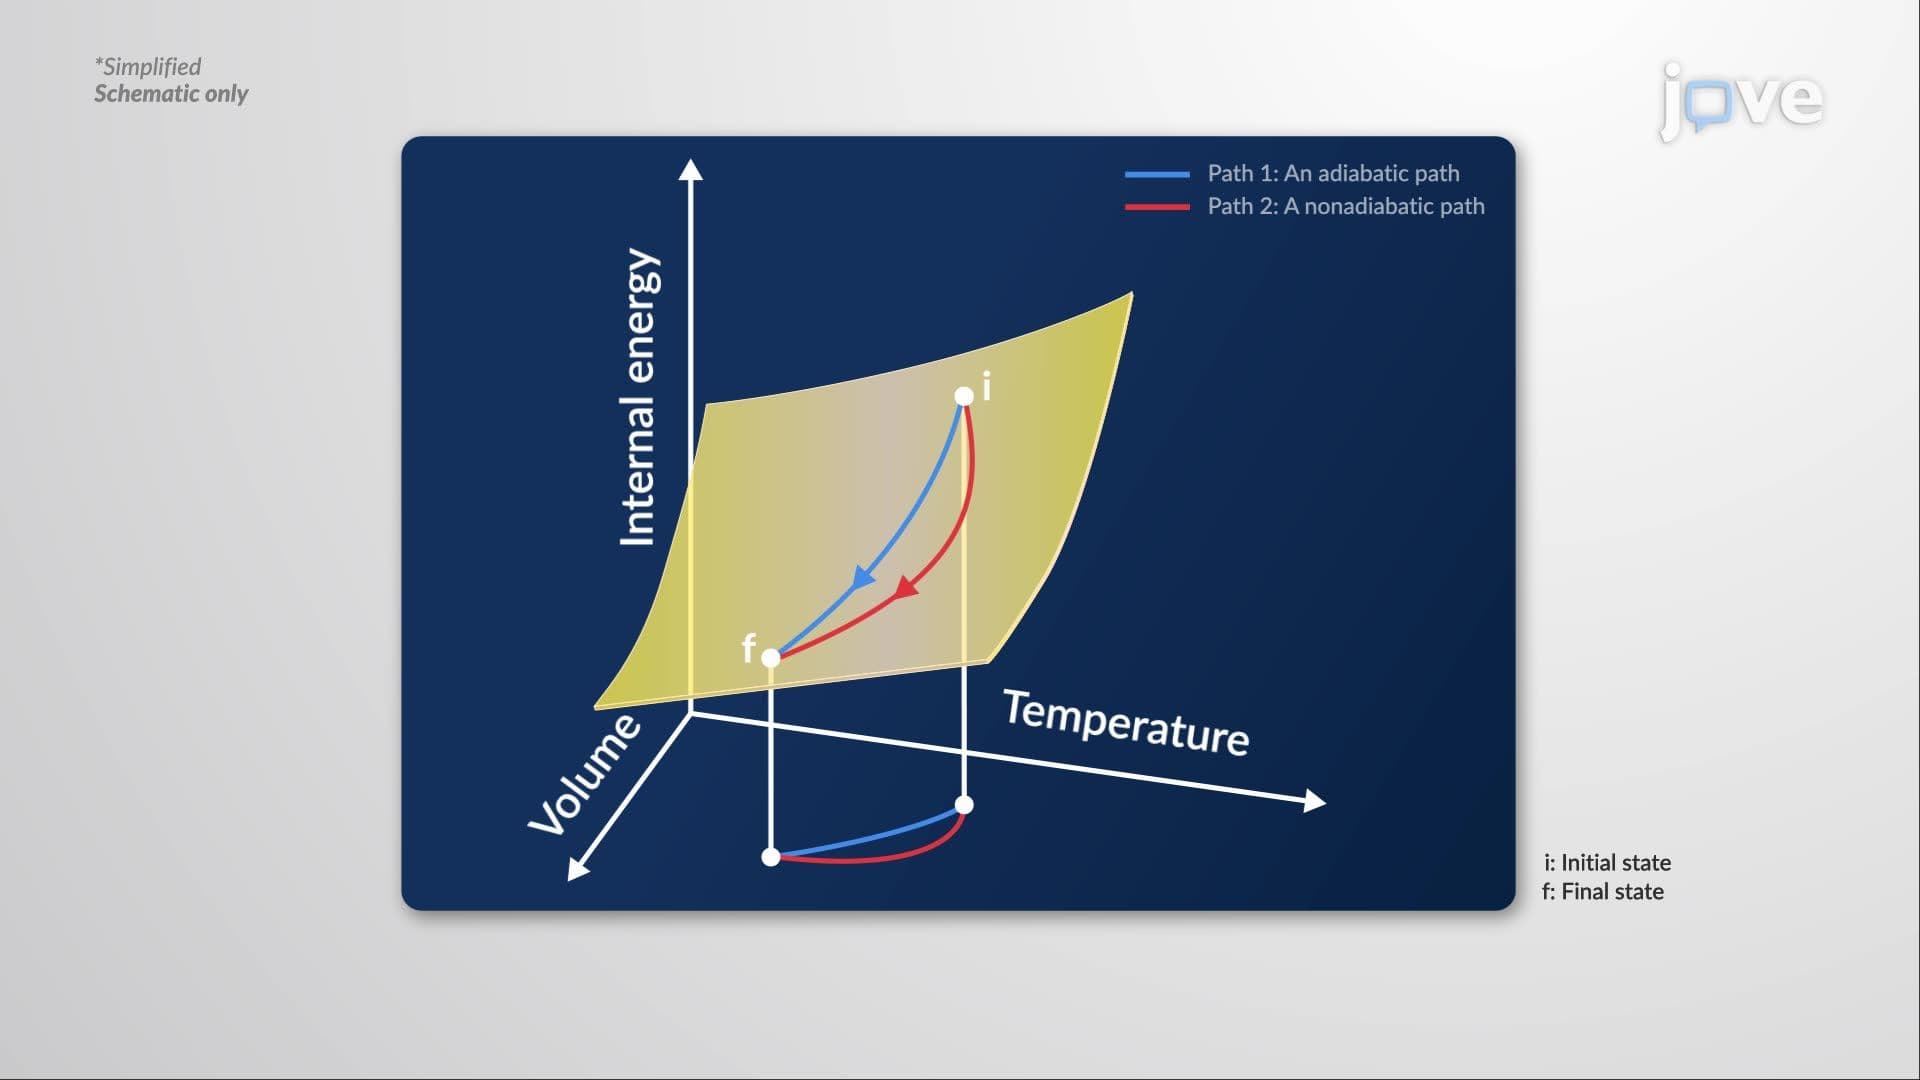
State Function, Exact and Inexact Differentials
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:13
Velocity and Position by Integral Method
Consider an example to calculate the velocity and position from the acceleration function. A motorboat is traveling at a constant velocity of 5.0 m/s when it starts to decelerate to arrive at the dock. Its acceleration is...
 01:30
Equations of Equilibrium in Three Dimensions
According to the vector equations of equilibrium, the vector sum of all the external forces acting on a body must...