Related Experiment Video
Updated: May 28, 2026
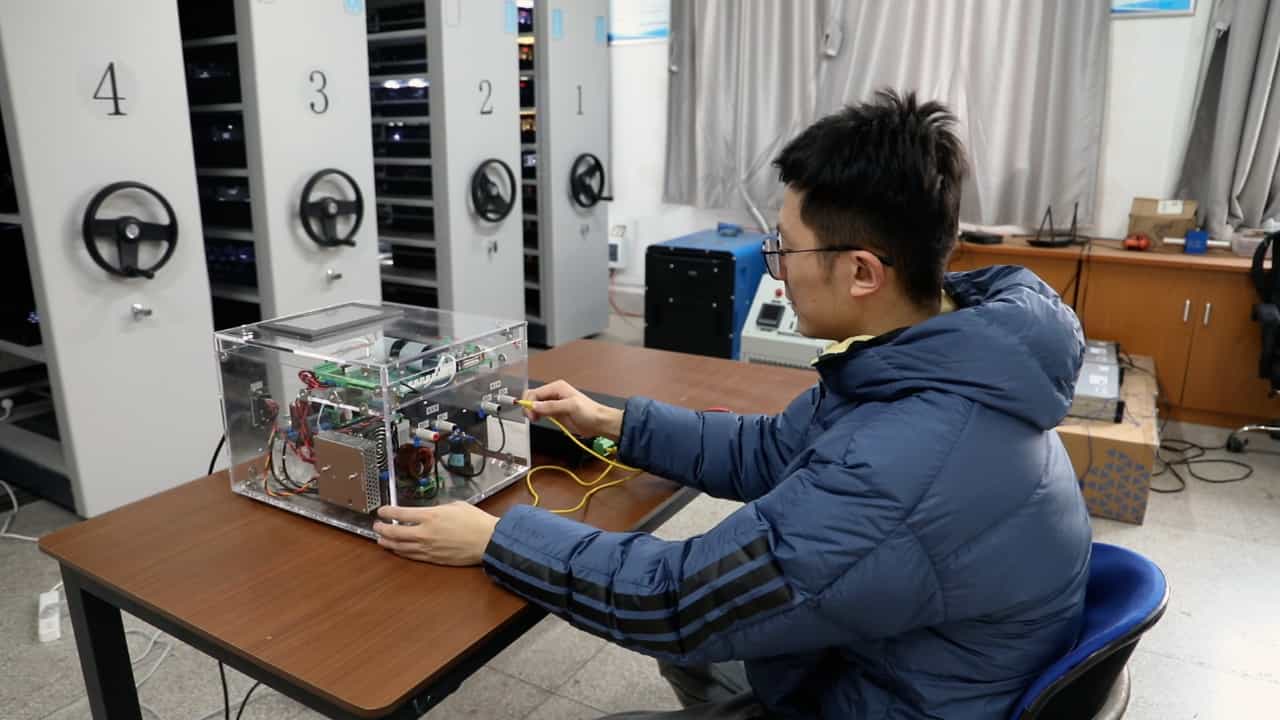

Experimental Investigation of the Hierarchical Control in DC Microgrids Using a Real-time Simulator
Published on: February 14, 2025
Decentralized supervisory based switching control for uncertain multivariable plants with variable input-output
Omid Namaki-Shoushtari1, Ali Khaki-Sedigh
1Faculty of Electrical and Computer Engineering, K. N. Toosi University of Technology, P.O. Box 16315-1355, Tehran 1431714191, Iran. onamakis@dena.kntu.ac.ir

Abstract:
In this paper, the design of decentralized switching control for uncertain multivariable plants is considered. In the proposed strategy, the uncertainty region is divided into smaller regions with a nominal model and specific control structure. The underlying design is based on the quantitative feedback theory (QFT). It is assumed that a MIMO-QFT controller exists for robust stability and performance of the individual uncertain sets. The proposed control structure is made up by these local decentralized controllers, which commute among themselves in accordance with the decision of a high level decision maker called the supervisor. The supervisor makes the decision by comparing the local models' behaviors with the one of the plant and selects the controller corresponding to the best fitted model. A hysteresis switching logic is used to slow down the switching to guarantee the overall closed loop stability. It is shown that this strategy provides a stable and robust adaptive controller to deal with complex multivariable plants with input-output pairing changes during the plant operation, which can facilitate the development of a reconfigurable decentralized control. Also, the multirealization technique is used to implement a family of controllers to achieve bumpless transfer. Simulation results are employed to show the effectiveness of the proposed method.
Related Concept Videos
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:25
Control Systems: Applications
In modern vehicles, control systems manage various functions to enhance performance and safety. The steering wheel and accelerator are primary inputs in a car's control system. The direction...
 01:10
Control Systems
At the heart...
 01:25
Multimachine Stability
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by:
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...