Related Experiment Video
Updated: Oct 10, 2026
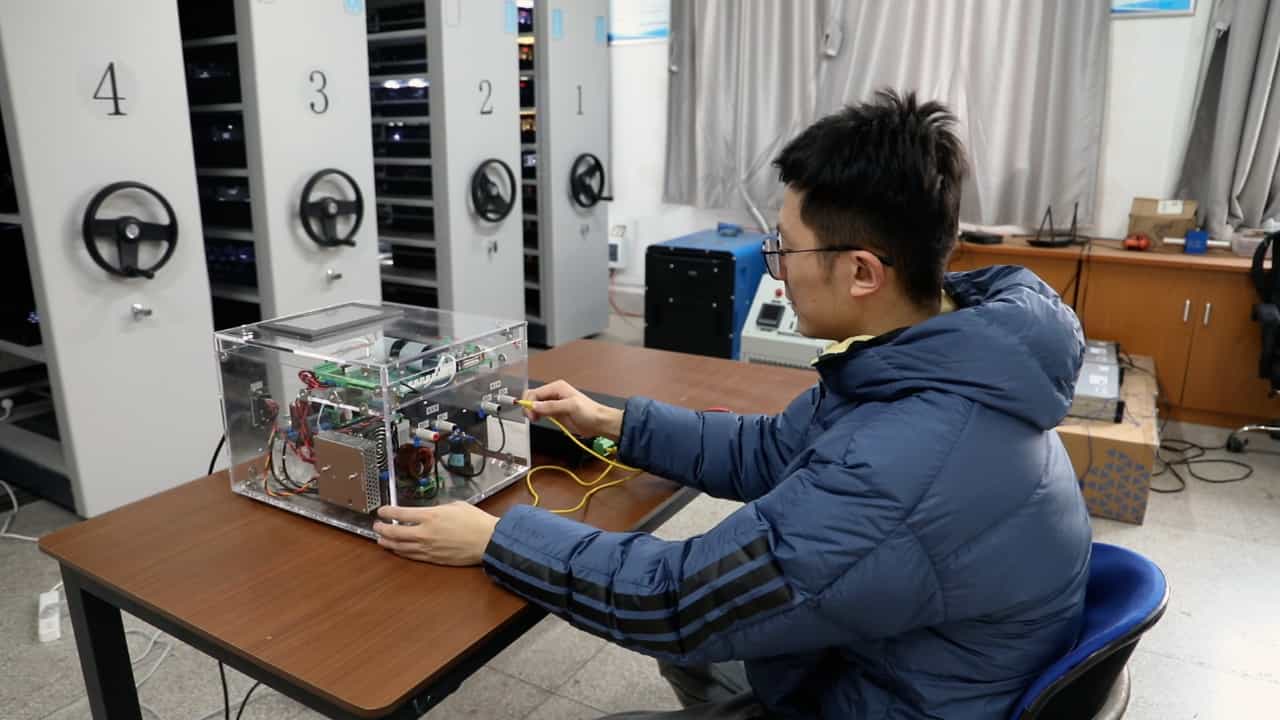

Experimental Investigation of the Hierarchical Control in DC Microgrids Using a Real-time Simulator
Published on: February 14, 2025
A deep reinforcement learning-based distributed adaptive fixed-time fault-tolerant control for DC microgrids against
Hua Han1, Shujin Chen1, Jia Liu2
1School of Automation, Central South University, Changsha 410083, China.

Abstract:
With the deep integration of renewable energy and DC loads, DC microgrids have become critical components of modern power systems. The widespread application of software-intensive controllers and power electronic devices has enhanced system flexibility but has also notably increased the risks of cyber-attacks and actuator faults. Such risks may compromise system stability and, in severe cases, cause damage to critical equipment, resulting in substantial economic losses. To address these issues, this paper proposes a distributed adaptive fault-tolerant control strategy based on fixed-time consensus and deep reinforcement learning (DRL), aiming to enhance the operational reliability of DC microgrids under actuator fault conditions. Firstly, the actuator fault effects are mapped to corruptions of control signals, which are adaptively compensated by voltage and current secondary control. Then, current sharing and voltage recovery mechanism under actuator faults is proposed based on fixed-time consensus and DRL algorithms. Besides, the fixed-time stability of the proposed control strategy is rigorously proven through the Lyapunov function. Simulation and control-hardware-in-the-loop (CHIL) experiments demonstrate that the proposed strategy exhibits excellent fault-tolerant capability and robustness under various actuator faults, load changes and communication interruptions.

Related Concept Videos
 01:26
Reclosers and Fuses
A comprehensive protection scheme for radial distribution...
 01:25
Distribution Reliability and Automation
 01:28
Load-frequency control
 01:21
Distributed Loads: Problem Solving
 01:24
Fast Decoupled and DC Powerflow
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...