Related Experiment Video
Updated: May 28, 2026
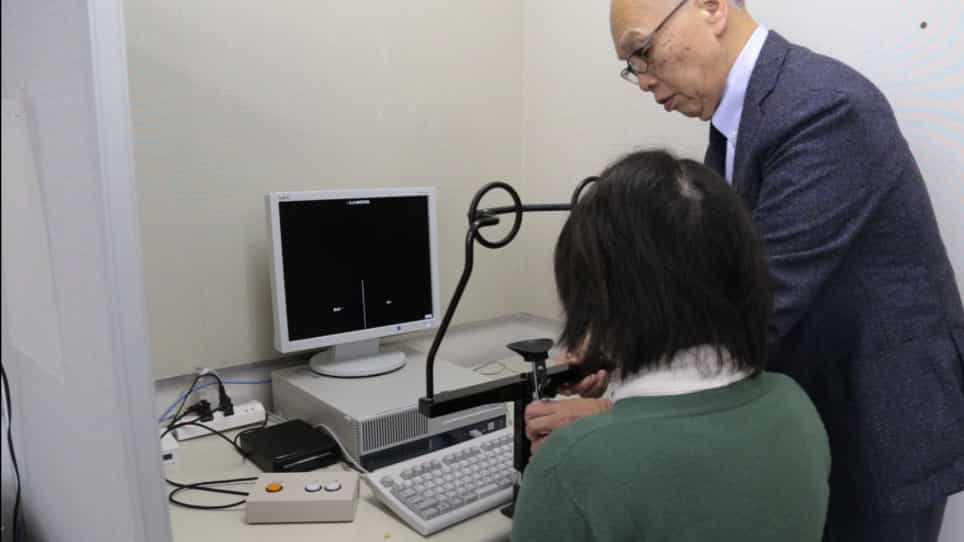
Generating Strictly Controlled Stimuli for Figure Recognition Experiments
Published on: March 18, 2019
The role of local features in shape discrimination of contour- and surface-defined radial frequency patterns at low
Iliya V Ivanov1, Kathy T Mullen
1McGill Vision Research, Department of Ophthalmology, McGill University, 687 Pine Avenue West, H4-14, Montréal, Canada H3A 1A1. iliya.ivanov@mcgill.ca

Abstract:
Shape processing involves a progression from local to global analysis. A key aspect of this is the binding of distributed local features into an overall form followed by the extraction of the shape independently of its local contrast and spatial scales, so enabling the shape to be encoded based on its proportions without reference to its exact size or retinal location. Here we use contour- and surface-defined radial frequency (RF) patterns in a shape discrimination task, previously thought to reflect a global processing stage that has reached contrast and scale invariance. We compare performance across different spatial scales for a wide range of RF patterns (contour spatial frequencies of 0.7-10.0cpd, pattern radii of 0.5-10.5°), and sharp- and smooth-edged surface-RF patterns, all at low contrast (5× detection threshold). We show that shape discrimination thresholds for RF patterns have a complex series of dependencies on stimulus size (radius), contour spatial frequency (thickness) and contrast, with no scale invariance. Our results are at odds with earlier work showing no effect of radius and spatial frequency on discrimination thresholds. We show that this discrepancy can be accounted for by a differential effect of contrast on shape discrimination, with shape invariance only stabilizing at higher contrasts (10-20× threshold).
Related Concept Videos
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:03
IR Frequency Region: Fingerprint Region
The...
 01:12
Radius of Gyration of an Area
 01:19
Degree of Curvature and Radius of Curvature
 01:27
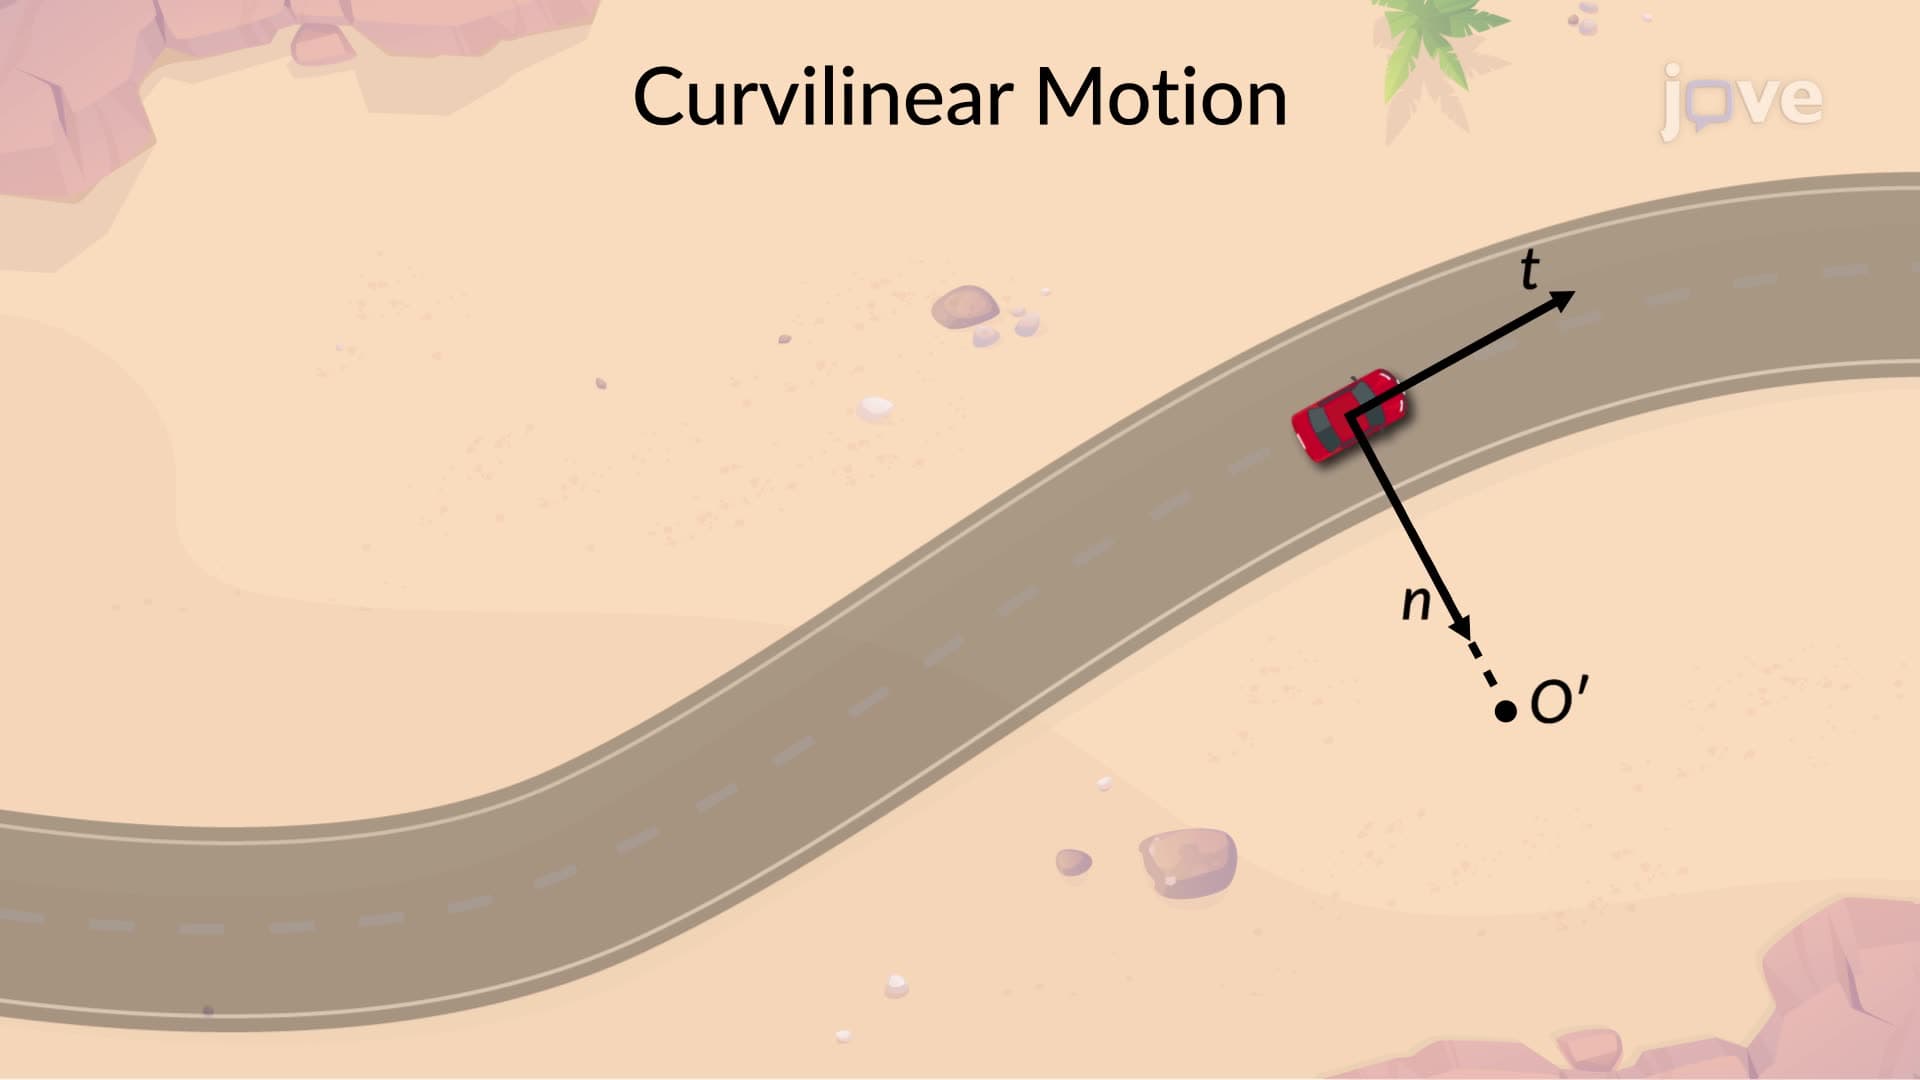
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.