Related Experiment Video
Updated: May 26, 2026
Automated Analysis of C. elegans Swim Behavior Using CeleST Software
Published on: December 7, 2016
3D kinematic and dynamic analysis of the front crawl tumble turn in elite male swimmers
1Univ. Bordeaux, I2M, UMR CNRS 5295 Talence, France. fred_puel@hotmail.com

Abstract:
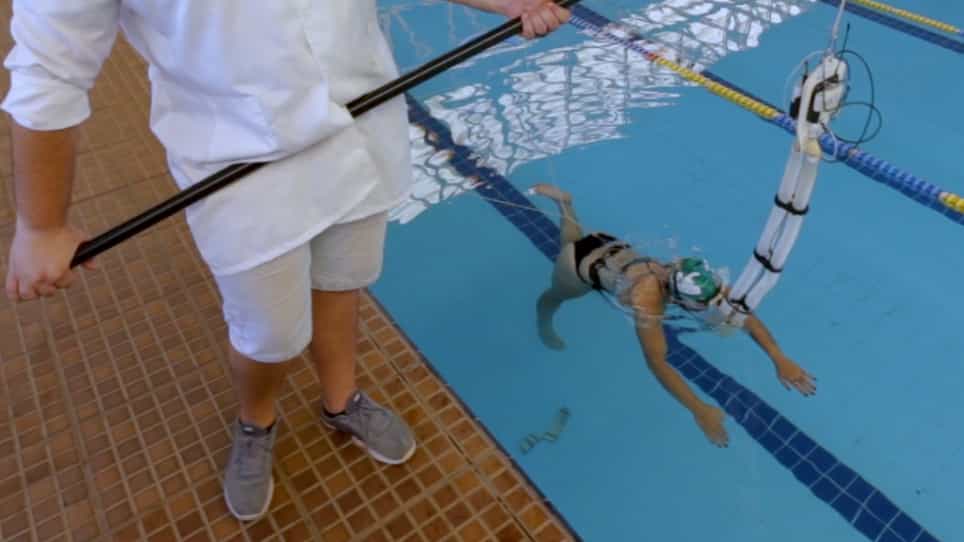
The aim of this study was to identify kinematic and dynamic variables related to the best tumble turn times (3mRTT, the turn time from 3-m in to 3-m out, independent variable) in ten elite male swimmers using a three-dimensional (3D) underwater analysis protocol and the Lasso (least absolute shrinkage and selection operator) as statistical method. For each swimmer, the best-time turn was analyzed with five stationary and synchronized underwater cameras. The 3D reconstruction was performed using the Direct Linear Transformation algorithm. An underwater piezoelectric 3D force platform completed the set-up to compute dynamic variables. Data were smoothed by the Savitzky-Golay filtering method. Three variables were considered relevant in the best Lasso model (3mRTT=2.58-0.425 RD+0.204 VPe+0.0046 TD): the head-wall distance where rotation starts (RD), the horizontal speed at the force peak (VPe), and the 3D length of the path covered during the turn (TD). Furthermore, bivariate analysis showed that upper body (CUBei) and lower limb extension indexes at first contact (CLLei) were also linked to the turn time (r=-0.65 and p<0.05 for both variables). Thus the best turn times were associated with a long RD, slower VPe and reduced TD. By an early transverse rotation, male elite swimmers reach the wall with a slightly flexed posture that results in fast extension. These swimmers opt for a movement that is oriented forward and they focus on reducing the distance covered.
Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:11
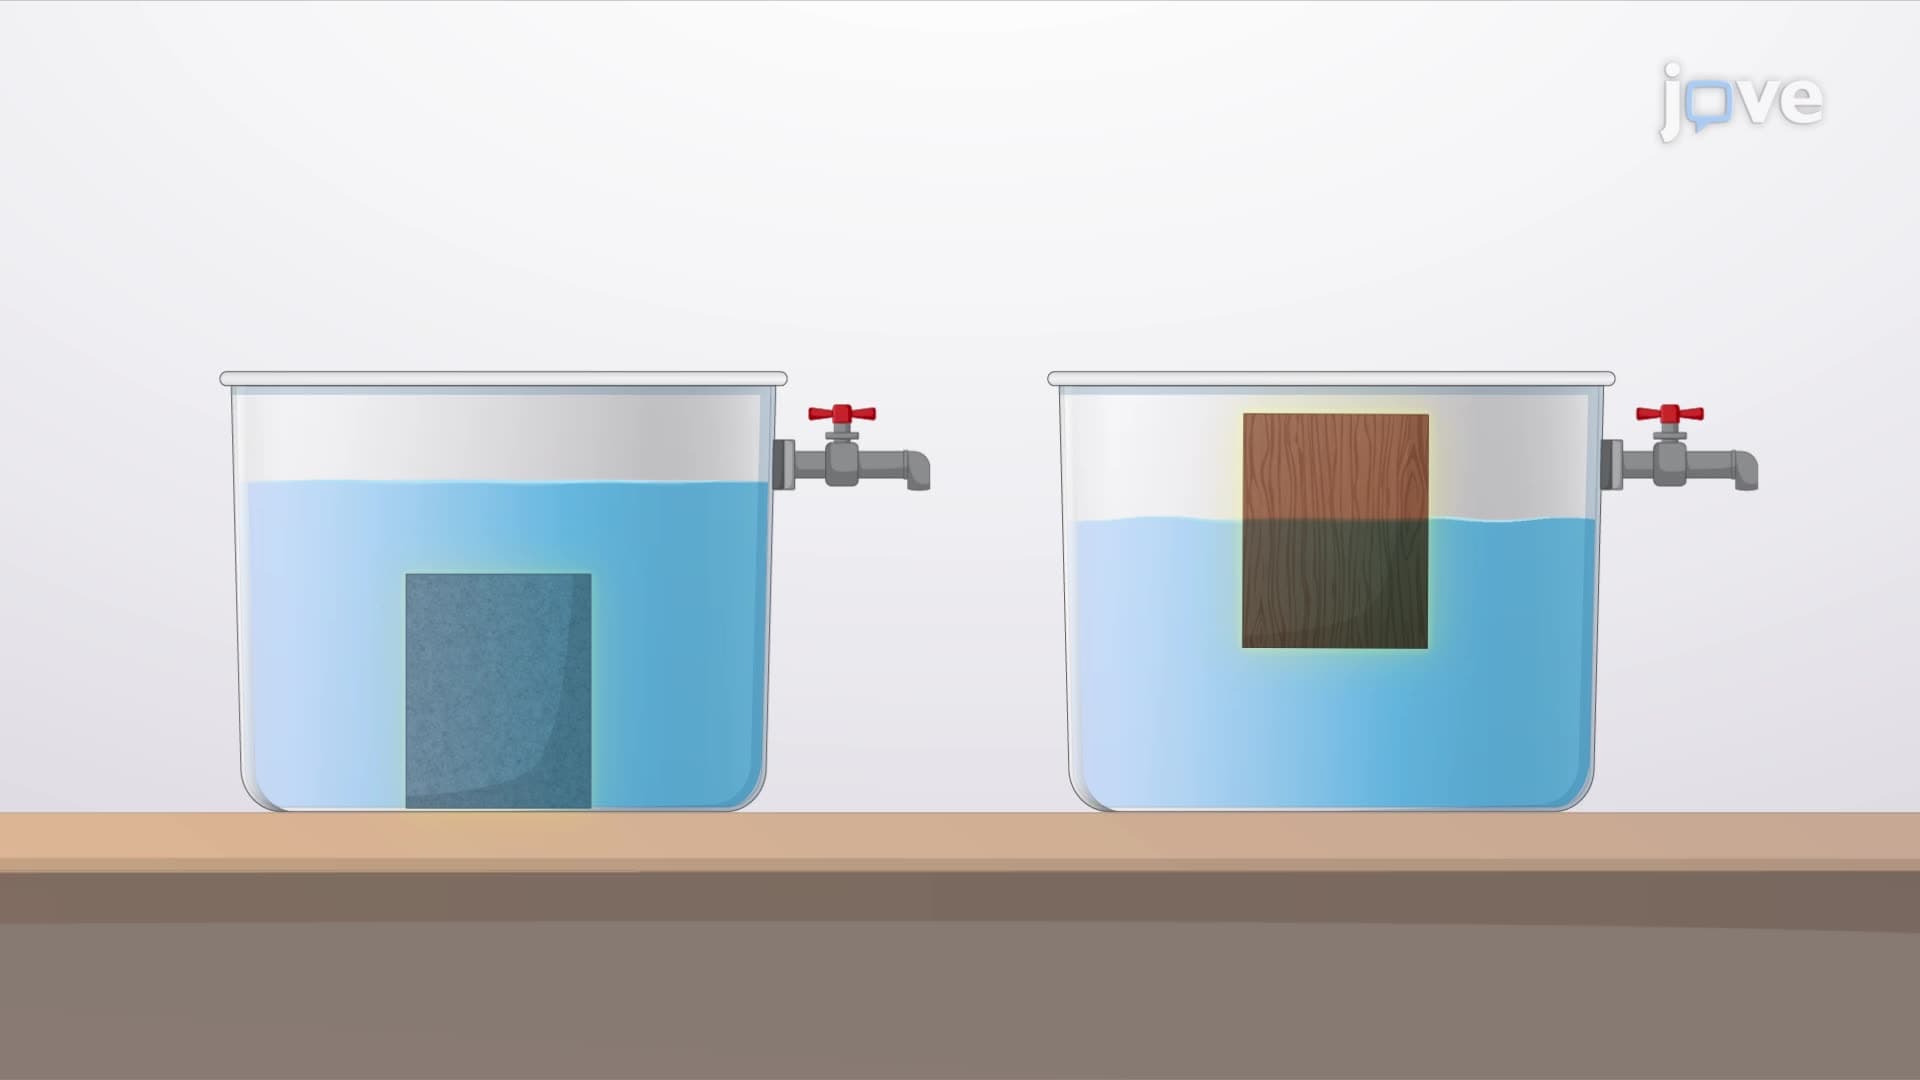
Buoyancy and Stability for Submerged and Floating Bodies