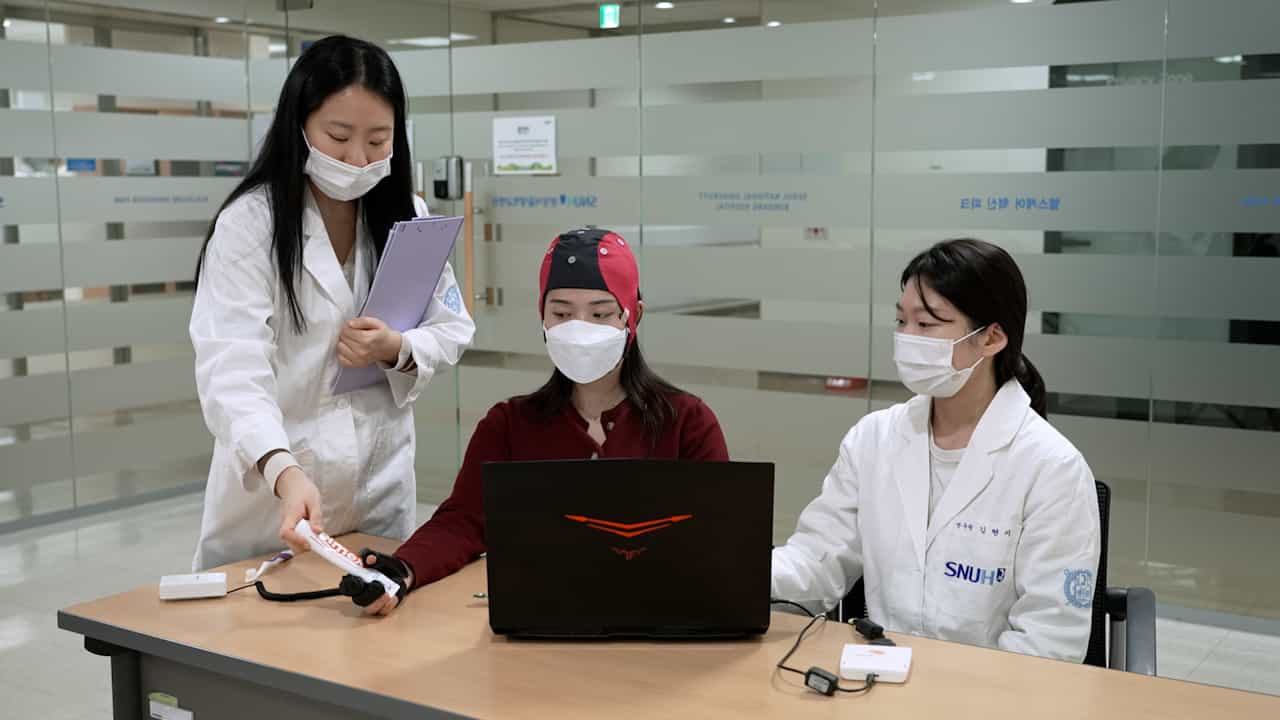
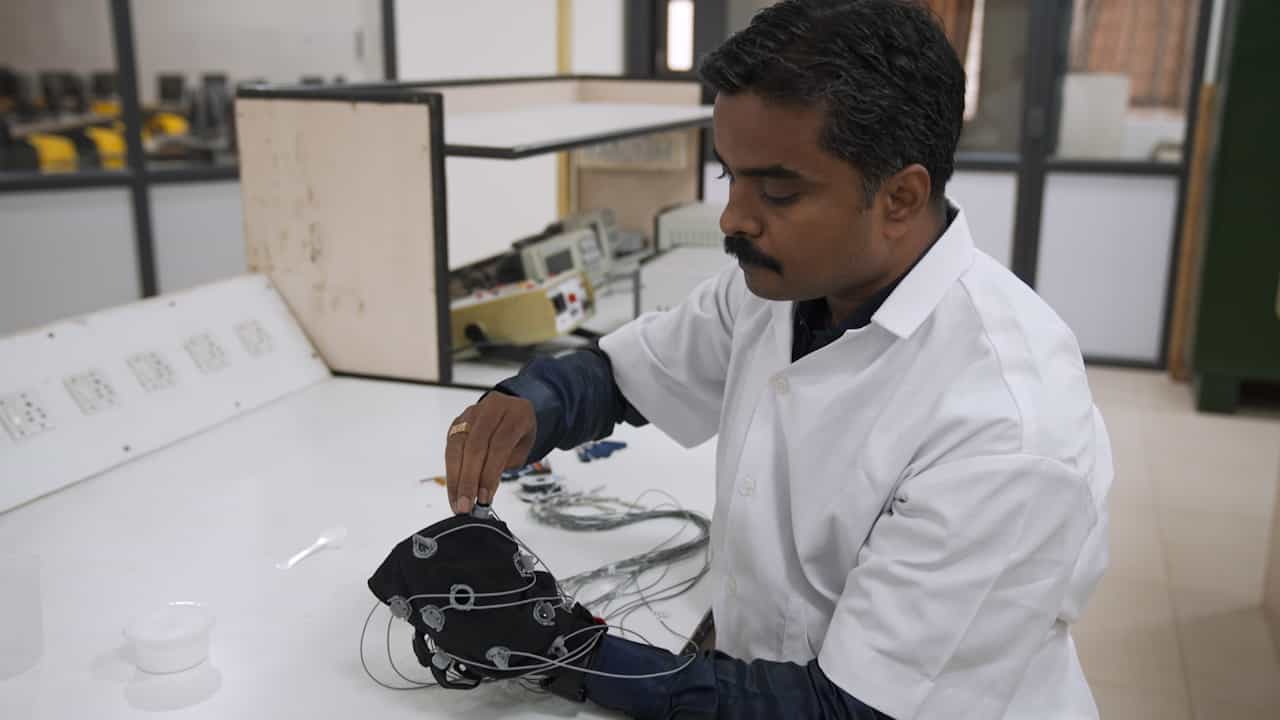
Related Experiment Video
Updated: May 26, 2026

Motor Imagery Brain-Computer Interface in Rehabilitation of Upper Limb Motor Dysfunction After Stroke
Published on: September 1, 2023
A self-paced motor imagery based brain-computer interface for robotic wheelchair control
Chun Sing Louis Tsui1, John Q Gan, Huosheng Hu
1Department of Medical Physics and Bioengineering, University Hospitals Bristol NHS Foundation Trust, Bristol, United Kingdom. chun_sing_tsui@hotmail.com

Abstract:
This paper presents a simple self-paced motor imagery based brain-computer interface (BCI) to control a robotic wheelchair. An innovative control protocol is proposed to enable a 2-class self-paced BCI for wheelchair control, in which the user makes path planning and fully controls the wheelchair except for the automatic obstacle avoidance based on a laser range finder when necessary. In order for the users to train their motor imagery control online safely and easily, simulated robot navigation in a specially designed environment was developed. This allowed the users to practice motor imagery control with the core self-paced BCI system in a simulated scenario before controlling the wheelchair. The self-paced BCI can then be applied to control a real robotic wheelchair using a protocol similar to that controlling the simulated robot. Our emphasis is on allowing more potential users to use the BCI controlled wheelchair with minimal training; a simple 2-class self paced system is adequate with the novel control protocol, resulting in a better transition from offline training to online control. Experimental results have demonstrated the usefulness of the online practice under the simulated scenario, and the effectiveness of the proposed self-paced BCI for robotic wheelchair control.