Related Experiment Video
Updated: May 25, 2026
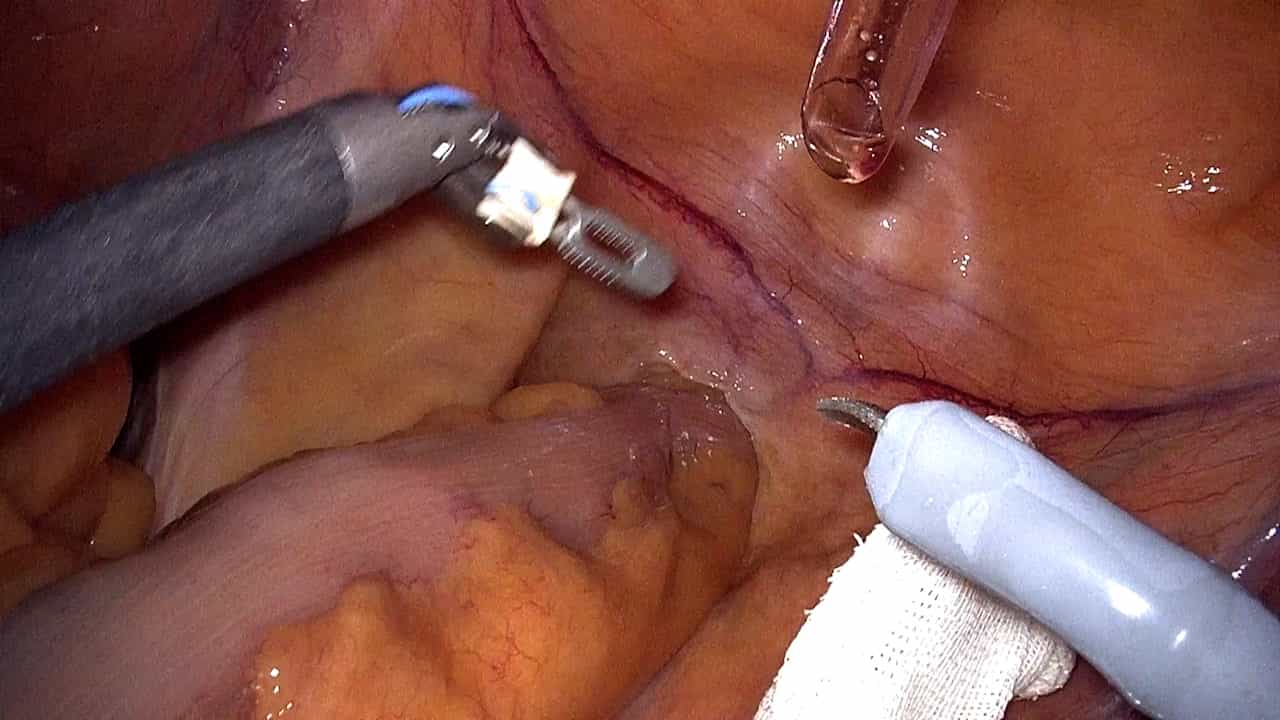

Surgical Robot-Assisted Transanal Specimen Extraction Radical Sigmoidectomy Without an Auxiliary Abdominal Incision
Published on: June 13, 2025
In vivo experiments of a surgical robot with vision field control for Single Port Endoscopic Surgery
Yuta Sekiguchi1, Yo Kobayashi, Hiroki Watanabe
1Graduate School of Science and Engineering, Waseda University, Japan.

Abstract:
Recently, robotics systems are focused to assist in Single Port Endoscopic Surgery (SPS). However, the existing system required a manual operation of vision and viewpoint, hindering the surgical task. We proposed a surgical endoscopic robot for SPS with dynamic vision control, the endoscopic view being manipulated by a master controller. The prototype robot consists of a manipulator for vision control, and dual tool tissue manipulators (gripping: 5DOFs, cautery: 3DOFs) can be attached at the tip of sheath manipulator. In particular, this paper focuses on an in vivo experiment. We showed that vision control in the stomach and a cautery task by a cautery tool could be effectively achieved.

