Related Experiment Video
Updated: May 25, 2026


A Structured Rehabilitation Protocol for Improved Multifunctional Prosthetic Control: A Case Study
Published on: November 6, 2015
Redundancy and joint limits of a seven degree of freedom upper limb exoskeleton
Levi Makaio Miller1, Hyunchul Kim, Jacob Rosen
1Dept of Mechanical Engineering, University of Washington, Seattle, WA, USA. makaio@uw.edu

Abstract:
The seven degree of freedom arm model is widely used in robotics, computer graphics, and much more. For wearable robotic systems, which are subject to joint limits, it is desirable to relate the joint limits to the redundantly of the system. A brief review of the arm model, redundant space and kinematics is presented. Following this review a closed form method is developed calculate the interval of the swivel angle (which characterizes the redundancy) that produces arm configurations that stay within joint limits.


Related Concept Videos
 01:07
Development of the Limb Synovial Joints
The mesenchymal stem cells differentiate into chondrocytes that form the hyaline cartilage, and later the cartilaginous model of the bone. This model further transforms into a bone. This process is known as endochondral ossification.
During development, the limbs...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:27
Support Reactions in Three Dimensions
Ball and Socket Joint is one of the supports allowing free rotation about any axis. This freedom of rotation is...
 01:30
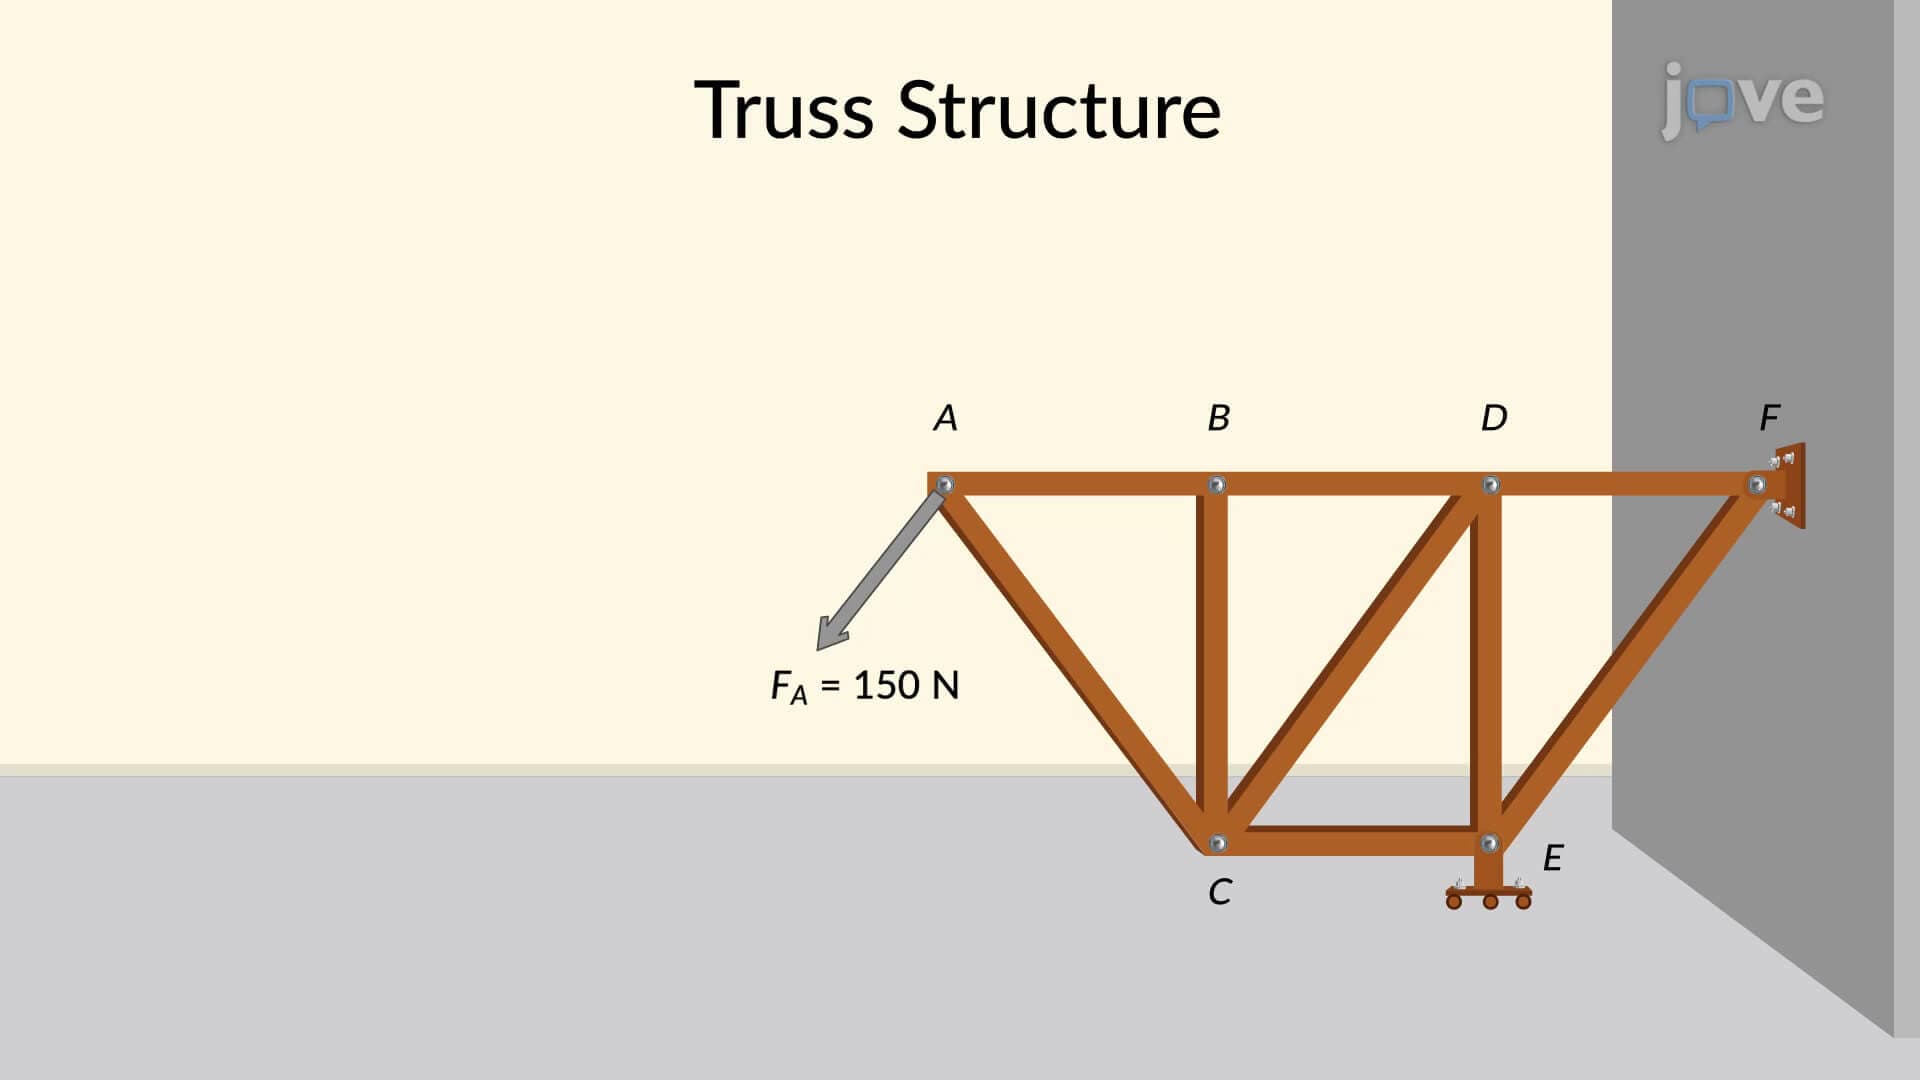
Method of Joints: Problem Solving II
 01:15
Bones of the Upper Limb: Ulna
 01:19
Bones of the Upper Limb: Humerus