Related Experiment Video
Updated: Oct 8, 2026


Investigating Motor Skill Learning Processes with a Robotic Manipulandum
Published on: February 12, 2017
Robust disturbance-aware actor-critic reinforcement learning for multi-DOF robotic manipulators
Viet Ngu Nguyen1, Thi Minh Tam Le1, Duc Hung Pham1
1Faculty of Electrical and Electronic Engineering, Hung Yen University of Technology and Education, Vietnam.

Abstract:
Building on recent insights that augmenting reinforcement-learning policies with disturbance estimates improves robustness and sim-to-real transfer, this paper proposes a disturbance-aware actor-critic RL framework for high-precision robotic manipulators. We derive the dynamics of manipulators ranging from two to six degrees of freedom and design a nonlinear disturbance observer that provides real-time estimates of lumped uncertainties. Unlike conventional feedforward-only designs, the proposed DACRL framework deeply integrates DOB information into the actor-critic's learning state, cost function, and update laws to explicitly compensate for unknown dynamics and disturbances. A Lyapunov-based analysis proves that tracking errors, observer errors and neural-network weight errors remain uniformly ultimately bounded. Extensive simulations show that the proposed controller achieves sub-degree tracking errors across multiple DOF cases, with the 2-DOF example achieving steady-state errors below ±0.02 rad (Joint 1) and ±0.05 rad (Joint 2) and delivering faster convergence and smoother torques than conventional RL and DOB baselines. The disturbance-aware controller generalizes across trajectories and payloads, offering improved robustness while retaining learning flexibility. While the current study focuses on performance and robustness, future work could explore the integration of disturbance-observer-based control barrier functions to formally address safety constraints during the learning process. Simulation results suggest that the disturbance-aware controller can improve robustness while retaining learning flexibility. Real-platform validation remains an important direction for future work.
Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:27
Support Reactions in Three Dimensions
Ball and Socket Joint is one of the supports allowing free rotation about any axis. This freedom of rotation is...
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 01:24
Muscle Coordination and Action
Agonists
Agonist muscles, often called prime movers, are the primary muscles responsible for producing a specific movement.
 00:49
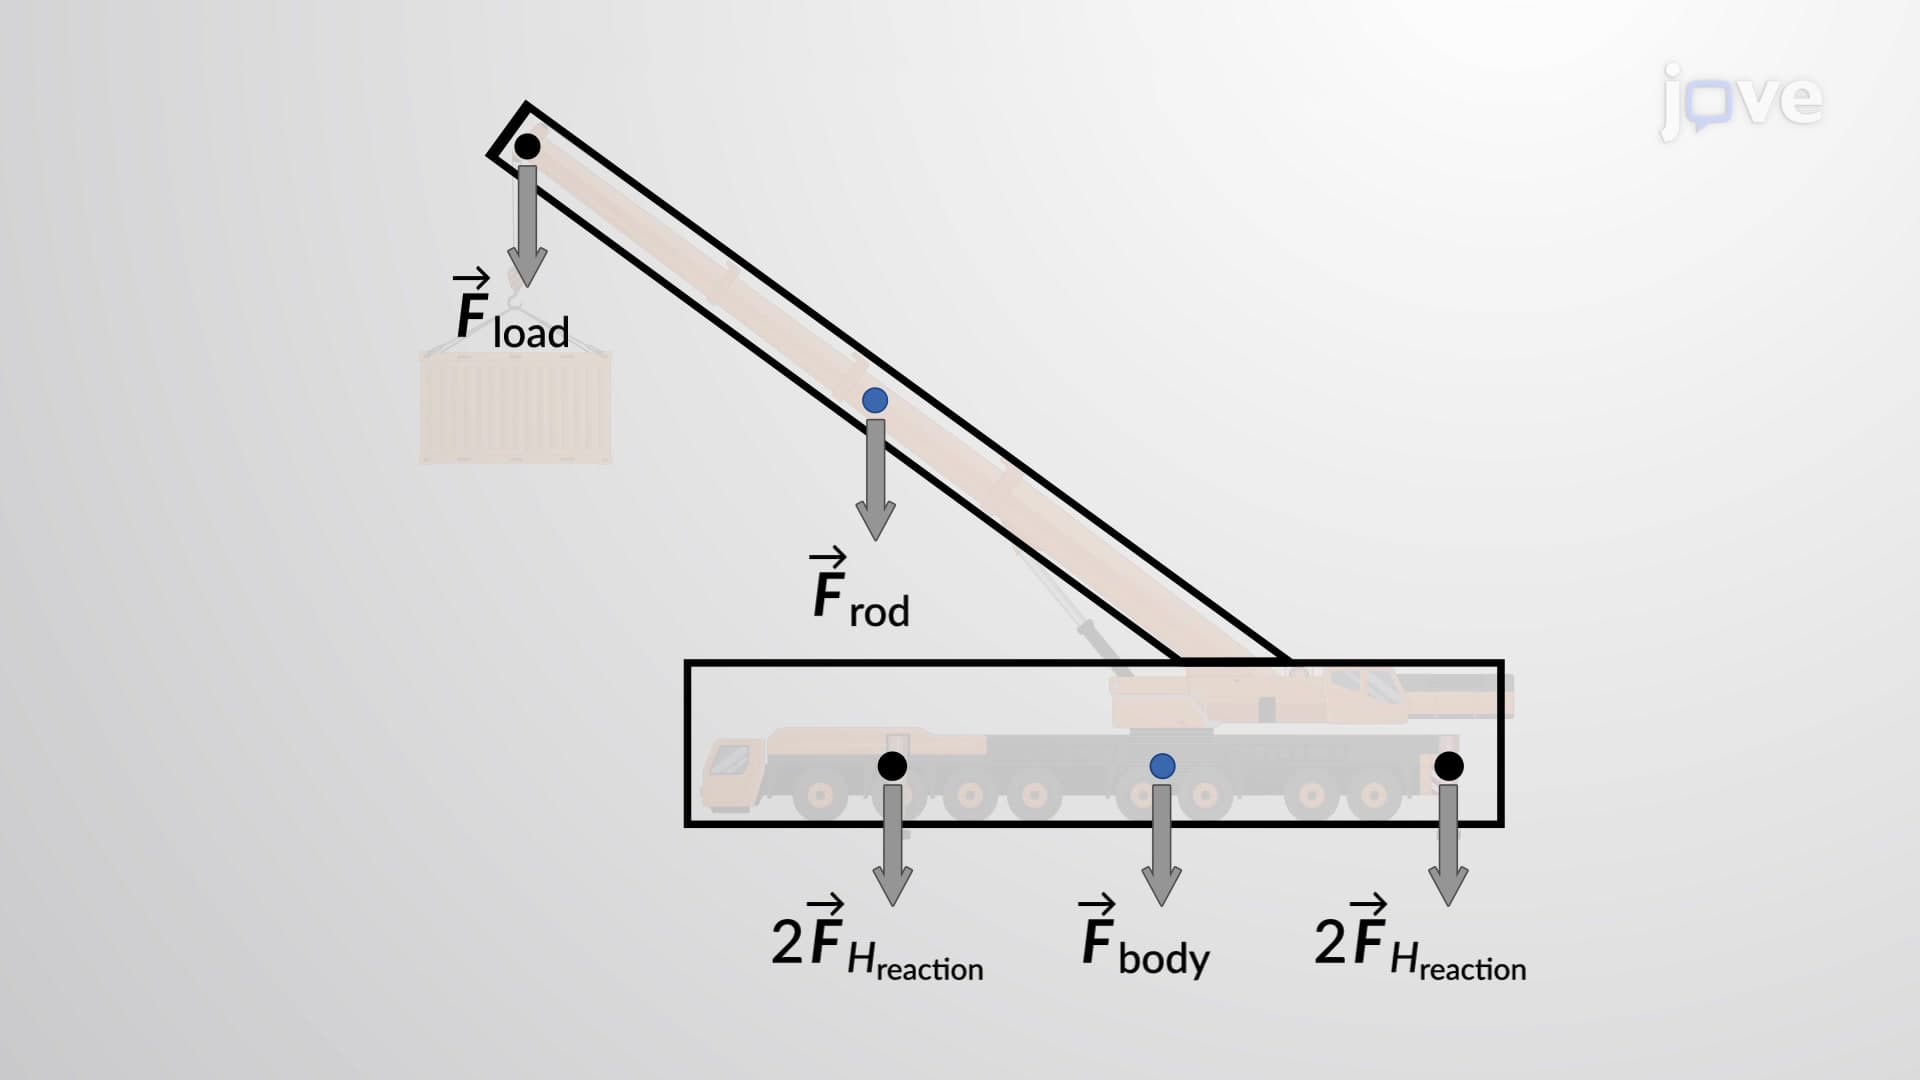
Rigid Body Equilibrium Problems - I