Related Experiment Video
Updated: May 25, 2026
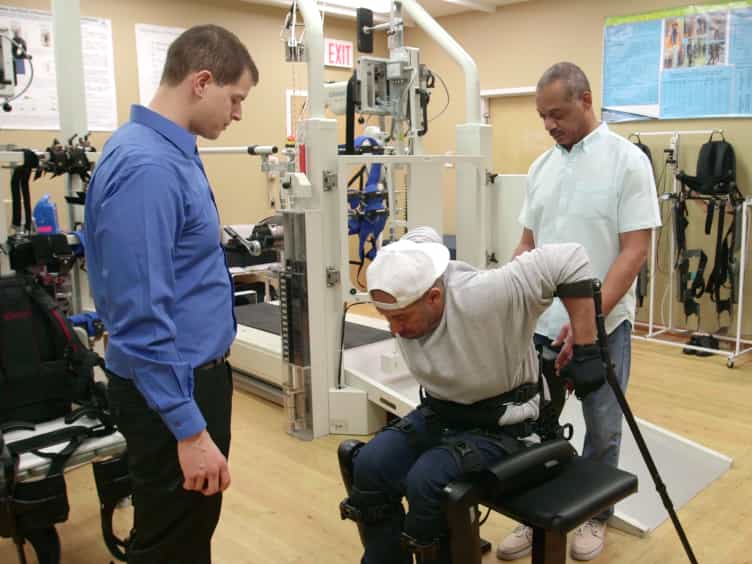

Training Persons with Spinal Cord Injury to Ambulate Using a Powered Exoskeleton
Published on: June 16, 2016
Inertia compensation control of a one-degree-of-freedom exoskeleton for lower-limb assistance: initial experiments
Gabriel Aguirre-Ollinger1, J Edward Colgate, Michael A Peshkin
1School of Electrical, Mechanical and Mechatronic Systems, University of Technology, Sydney, Broadway, NSW 2007, Australia. gabriel.aguirre-ollinger@uts.edu.au

Abstract:
A new method of lower-limb exoskeleton control aimed at improving the agility of leg-swing motion is presented. In the absence of control, an exoskeleton's mechanism usually hinders agility by adding mechanical impedance to the legs. The uncompensated inertia of the exoskeleton will reduce the natural frequency of leg swing, probably leading to lower step frequency during walking as well as increased metabolic energy consumption. The proposed controller emulates inertia compensation by adding a feedback loop consisting of low-pass filtered angular acceleration multiplied by a negative gain. This gain simulates negative inertia in the low-frequency range. The resulting controller combines two assistive effects: increasing the natural frequency of the lower limbs and performing net work per swing cycle. The controller was tested on a statically mounted exoskeleton that assists knee flexion and extension. Subjects performed movement sequences, first unassisted and then using the exoskeleton, in the context of a computer-based task resembling a race. In the exoskeleton's baseline state, the frequency of leg swing and the mean angular velocity were consistently reduced. The addition of inertia compensation enabled subjects to recover their normal frequency and increase their selected angular velocity. The work performed by the exoskeleton was evidenced by catch trials in the protocol.

