Related Experiment Video
Updated: May 25, 2026
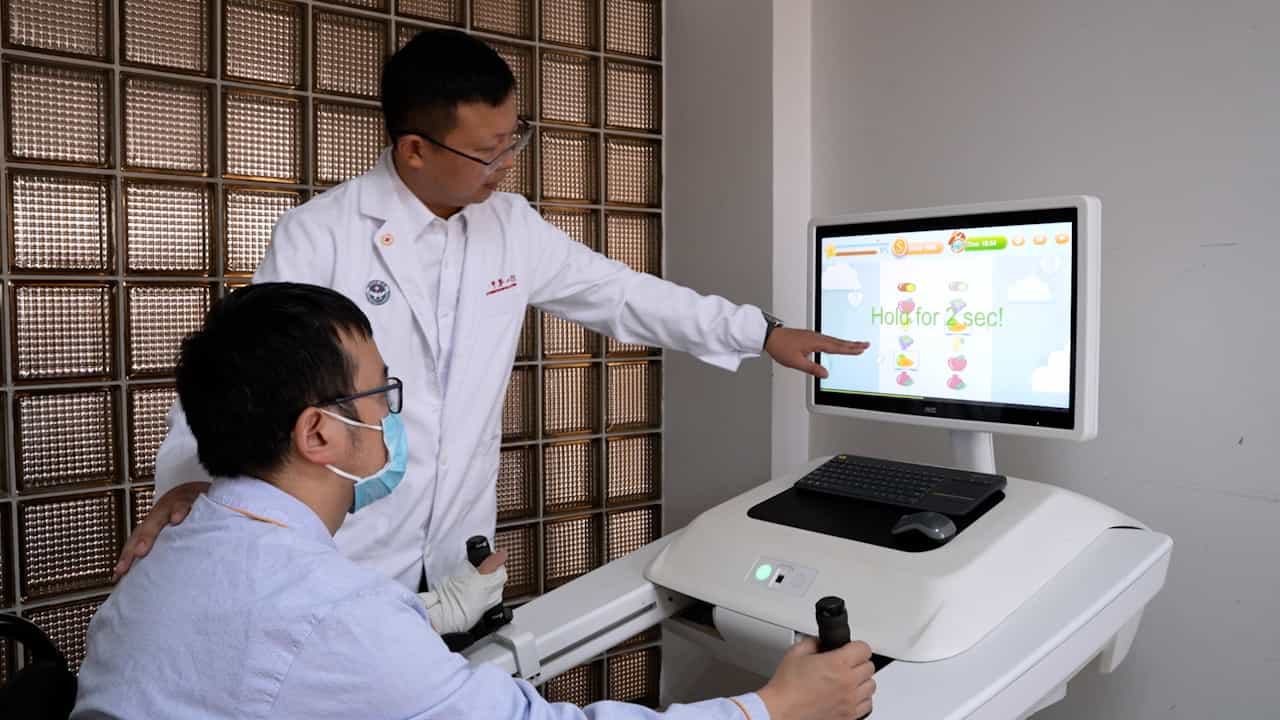

Application of a Dual Upper Limb Task-Oriented Robotic System for the Functional Recovery of the Upper Limb in Stroke Patients
Published on: October 11, 2024
A tailored exercise of manipulation of virtual tools to treat upper limb impairment in Multiple Sclerosis
Angelo Basteris1, Alice De Luca, Vittorio Sanguineti
1Dept. of Informatics, Systems and Telematics, University of Genoa, Genoa, Italy. angelo.basteris@unige.it

Abstract:
We developed a robot-assisted rehabilitation protocol, specifically designed to treat cerebellar and motor symptoms in subjects with Multiple Sclerosis. The task consists of controlling a `virtual' tool (a mass-spring system), under the effect of a resistive force. The exercise is designed in such a way that task difficulty and the degree of resistance are automatically adjusted to the individual patients' impairment. The protocol included a total of eight 40 min training sessions (2 sessions/week), and automatic regulation of difficulty and resistance was repeated at the beginning of each session. Preliminary results suggest that subjects improve their performance, both within and between sessions. Moreover, task difficulty and resistance tend to increase across sessions, indicating that subjects gradually improve their ability to deal with more challenging versions of the task.

