Related Experiment Video
Updated: May 25, 2026
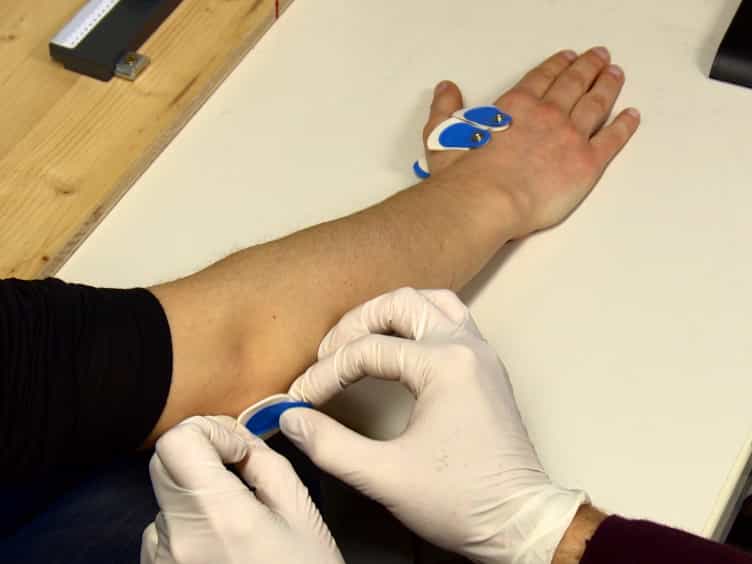

Force and Position Control in Humans - The Role of Augmented Feedback
Published on: June 19, 2016
Survey of visual and force/tactile control of robots for physical interaction in Spain
Gabriel J Garcia1, Juan A Corrales, Jorge Pomares
1Physics, Systems Engineering and Signal Theory Department, University of Alicante, PO Box 99, 03080, Alicante, Spain; E-Mails: jcorrales@ua.es (J.A.C.); jpomares@ua.es (J.P.); Fernando.Torres@ua.es (F.T.).

Abstract:
Sensors provide robotic systems with the information required to perceive the changes that happen in unstructured environments and modify their actions accordingly. The robotic controllers which process and analyze this sensory information are usually based on three types of sensors (visual, force/torque and tactile) which identify the most widespread robotic control strategies: visual servoing control, force control and tactile control. This paper presents a detailed review on the sensor architectures, algorithmic techniques and applications which have been developed by Spanish researchers in order to implement these mono-sensor and multi-sensor controllers which combine several sensors.
Related Concept Videos
 01:10
Control Systems
At the heart...
 01:22
Mechanical Systems
 01:19
Electro-mechanical Systems
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...
 01:25
Control Systems: Applications
In modern vehicles, control systems manage various functions to enhance performance and safety. The steering wheel and accelerator are primary inputs in a car's control system. The direction...
 01:18
Hierarchy of Motor Control
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...