Related Experiment Video
Updated: May 23, 2026
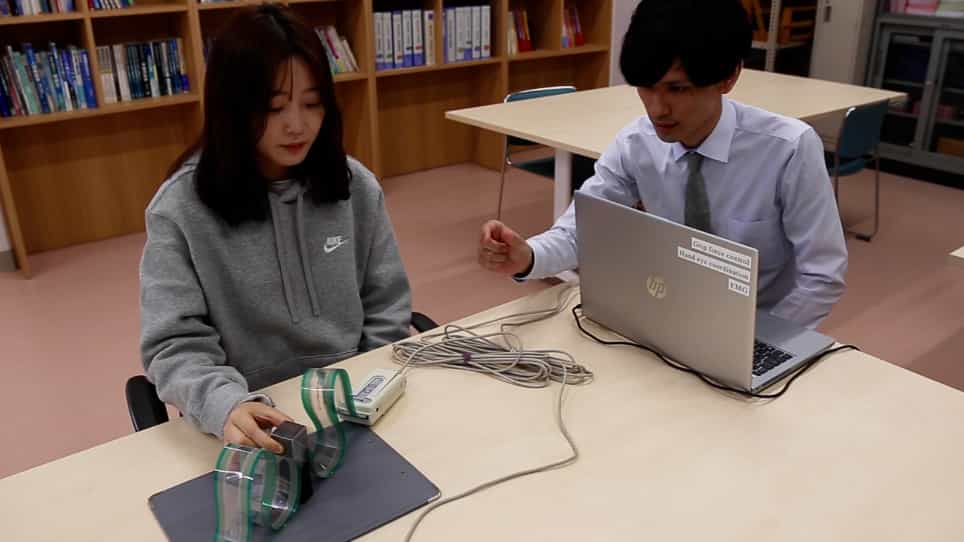
Measurement of Spatial Stability in Precision Grip
Published on: June 4, 2020
Stability control of grasping objects with different locations of center of mass and rotational inertia
Gregory P Slota1, Moon Suk Suh, Mark L Latash
1Kinesiology, Pennsylvania State University, University Park, PA 16802, USA. gslota@psu.edu

Abstract:
The objective of this study was to observe how the digits of the hand adjust to varying location of the center of mass (CoM) above or below the grasp and rotational inertia (RI) of a handheld object. Such manipulations do not immediately affect the equilibrium equations while stability control is affected. Participants were instructed to hold a handle, instrumented with 5 force-torque transducers and a 3-D rotational tilt sensor, while either the location of the CoM or the RI values were adjusted. On the whole, people use 2 mechanisms to adjust to the changed stability requirements; they increase the grip force and redistribute the total moment between the normal and tangential forces offsetting internal torques. The increase in grip force, an internal force, and offsetting internal torques allows for increases in joint and hand rotational apparent stiffness while not creating external forces-torques that would unbalance the equations of equilibrium.


Related Concept Videos
 01:30
Applications of Integration to Find Centers of Mass
 01:15
Center of Gravity
To determine its location, the principle of moments can be utilized by dividing the object into...
 00:58
Center of Gravity
 01:03
Finding the Center of Gravity
 01:14
Stability of structures
 01:03
Center of Mass: Introduction