Related Experiment Video
Updated: May 23, 2026
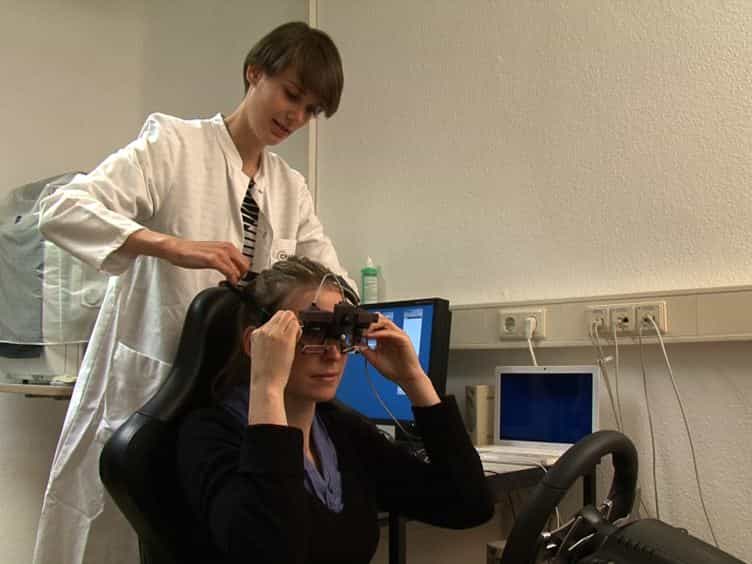
Driving Simulation in the Clinic: Testing Visual Exploratory Behavior in Daily Life Activities in Patients with Visual Field Defects
Published on: September 18, 2012
Clinical evaluation of semiautonomous smart wheelchair architecture (Drive-Safe System) with visually impaired
Vinod Sharma1, Richard C Simpson, Edmund F LoPresti
1Department of Bioengineering, University of Pittsburgh, Pittsburgh, PA 15213, USA. vks3@pitt.edu

Abstract:
Nonambulatory, visually impaired individuals mostly rely on caregivers for their day-to-day mobility needs. The Drive-Safe System (DSS) is a modular, semiautonomous smart wheelchair system aimed at providing independent mobility to people with visual and mobility impairments. In this project, clinical evaluation of the DSS was performed in a controlled laboratory setting with individuals who have visual impairment but no mobility impairment. Their performance using DSS was compared with their performance using a standard cane for navigation assistance. Participants rated their subjective appraisal of the DSS by using the National Aeronautics and Space Administration-Task Load Index inventory. DSS significantly reduced the number and severity of collisions compared with using a cane alone and without increasing the time required to complete the task. Users rated DSS favorably; they experienced less physical demand when using the DSS, but did not feel any difference in perceived effort, mental demand, and level of frustration when using the DSS alone or along with a cane in comparison with using a cane alone. These findings suggest that the DSS can be a safe, reliable, and easy-to-learn and operate independent mobility solution for visually impaired wheelchair users.