Related Experiment Video
Updated: May 20, 2026

Profiling Maternal Behavior Responses During Whole-Brain Imaging
Published on: January 24, 2025
Interaction of first- and second-order signals in the extraction of global-motion and optic-flow
Craig Aaen-Stockdale1, Timothy Ledgeway, Paul McGraw
1McGill Vision Research Unit, Dept. of Ophthalmology, McGill University, Montreal, Quebec, Canada H3A 1A1. signaldetection@yahoo.co.uk

Abstract:
The intention of this series of experiments was to determine the extent to which the pathways sensitive to first-order and second-order motion are independent of one another at, and above, the level of global motion integration. We used translational, radial and rotational motion stimuli containing luminance-modulated dots, contrast-modulated dots, or a mixture of both. Our results show that the two classes of motion stimuli interact perceptually in a global motion coherence task, and the extent of this interaction is governed by whether the two varieties of local motion signal produce an equivalent response in the pathways that encode each type of motion. This provides strong psychophysical evidence that global motion and optic flow processing are cue-invariant. The fidelity of the first-order motion signal was moderated by either reducing the luminance of the dots or by increasing the displacement of the dots on each positional update. The experiments were carried out with two different types of second-order elements (contrast-modulated dots and flicker-modulated dots) and the results were comparable, suggesting that these findings are generalisable to a variety of second-order stimuli. In addition, the interaction between the two different types of second-order stimuli was investigated and we found that the relative modulation depth was also crucial to whether the two populations interacted. We conclude that the relative output of local motion sensors sensitive to either first-order or second-order motion dictates their weight in subsequent cue-invariant global motion computations.
Related Concept Videos
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:02
¹H NMR: Interpreting Distorted and Overlapping Signals
As Δν decreases and the signals move closer, the doublets appear increasingly distorted. The intensities of the inner lines increase at the cost of those of the outer lines as the signals are slanted or...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:27
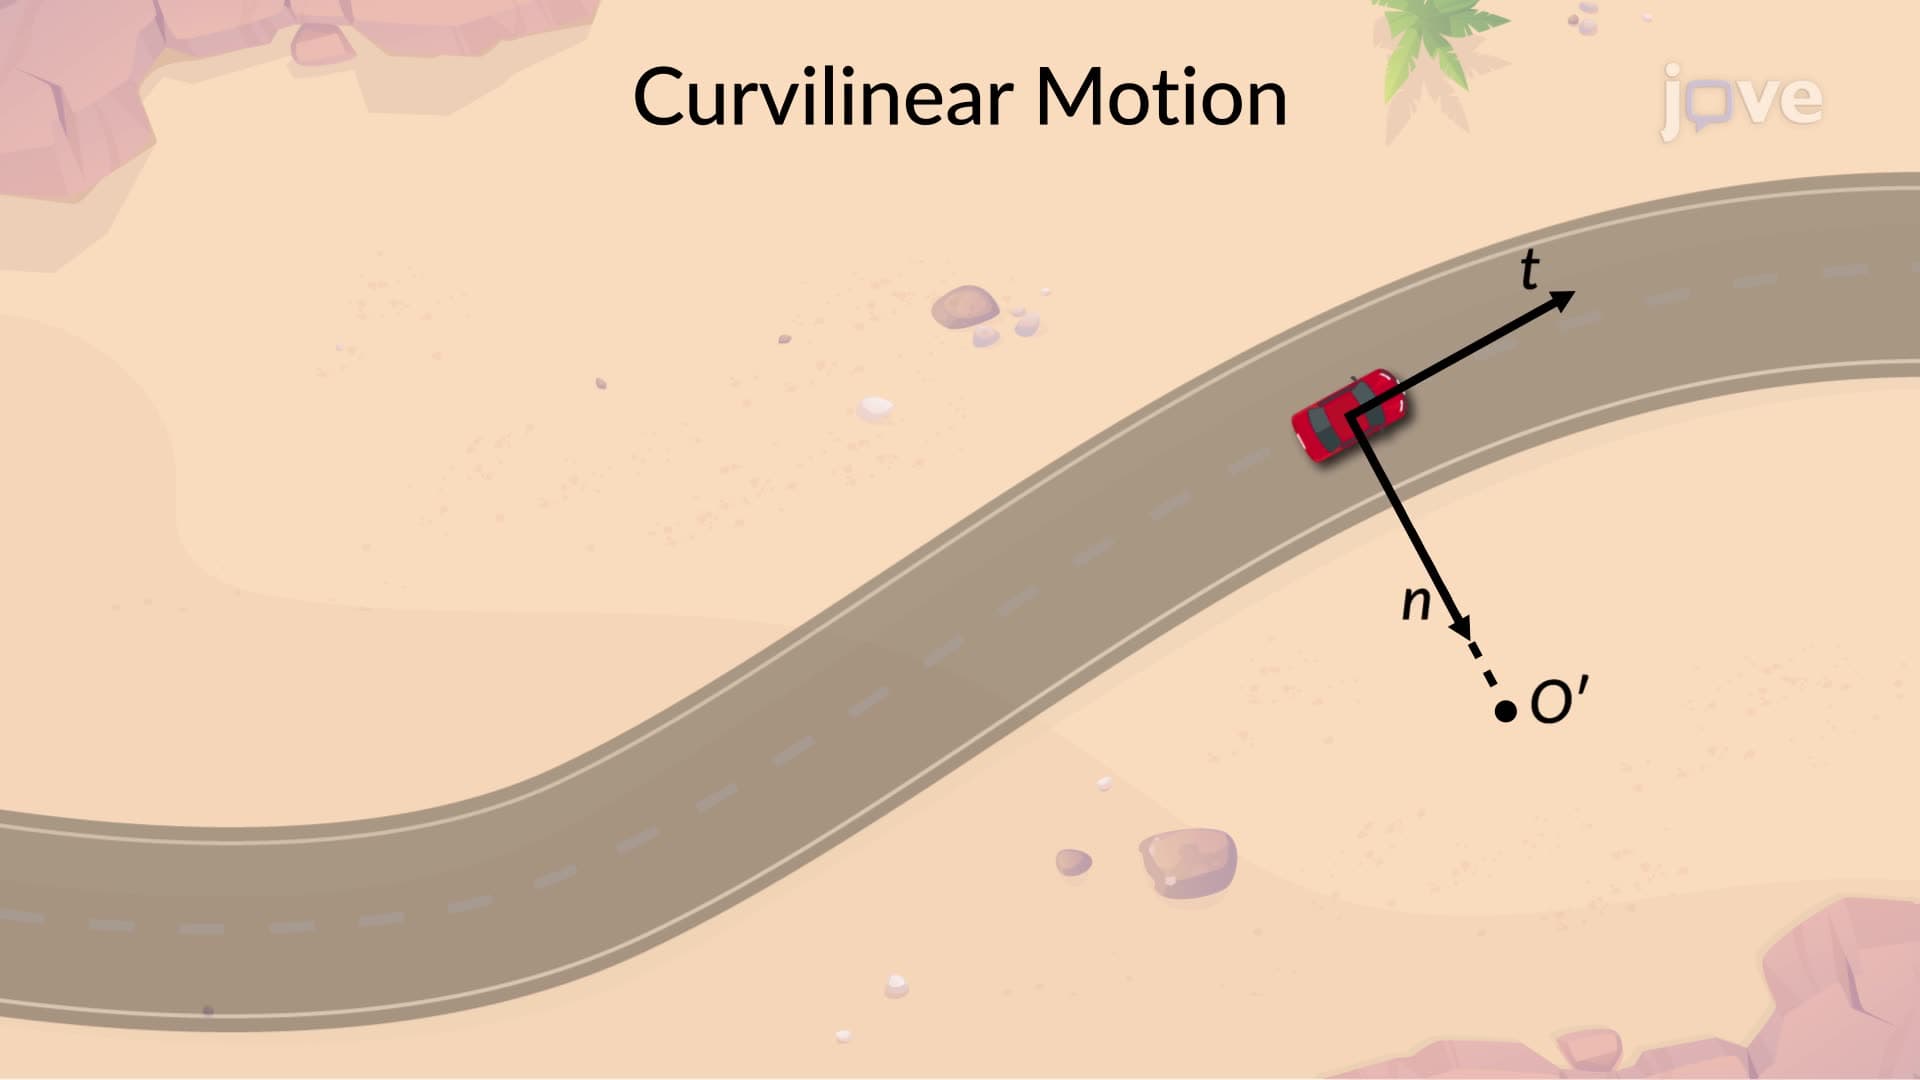
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...