Related Experiment Video
Updated: May 18, 2026

Experimental Methods to Study Human Postural Control
Published on: September 11, 2019
A fundamental mechanism of legged locomotion with hip torque and leg damping
1Department of Mechanical Engineering, Purdue University, West Lafayette, IN 47906, USA. shen38@purdue.edu

Abstract:
New models and theories of legged locomotion are needed to better explain and predict the robustly stable legged locomotion of animals and some bio-inspired robots. In this paper we observe that a hip-torque and leg-damping mechanism is fundamental to many legged robots and some animals and determine its affect on locomotion dynamics. We discuss why this hip-torque-and-leg-damping mechanism is not so easily understood. We investigate how hip-torque and leg-damping affect the stability and robustness of locomotion using a mathematical model: First, we extend the canonical spring-loaded-inverted-pendulum model to include constant hip torque and leg damping proportional to leg length speed. Then, we calculate the stability and robustness of locomotion as a function of increasing levels of torque and damping, starting from zero-the energy conserving and marginally stable special case-to high levels of torque and damping. We find that the stabilizing effects of hip-torque and leg-damping occur in the context of the piecewise-continuous dynamics of legged locomotion, and so linear intuition does not apply. We discover that adding hip torque and leg damping changes the stability of legged locomotion in an unexpected way. When a small amount of torque and damping are added, legged locomotion is initially destabilized. As more torque and damping are added, legged locomotion turns stable and becomes increasingly more stable and more robust the more torque and damping are added. Also, stable locomotion becomes more probable over the biologically-relevant region of the parameter space, indicating greater prediction and explanatory capabilities of the model. These results provide a more clear understanding of the hip-torque-and-leg-damping mechanism of legged locomotion, and extend existing theory of legged locomotion towards a greater understanding of robustly stable locomotion.
Related Concept Videos
 01:20
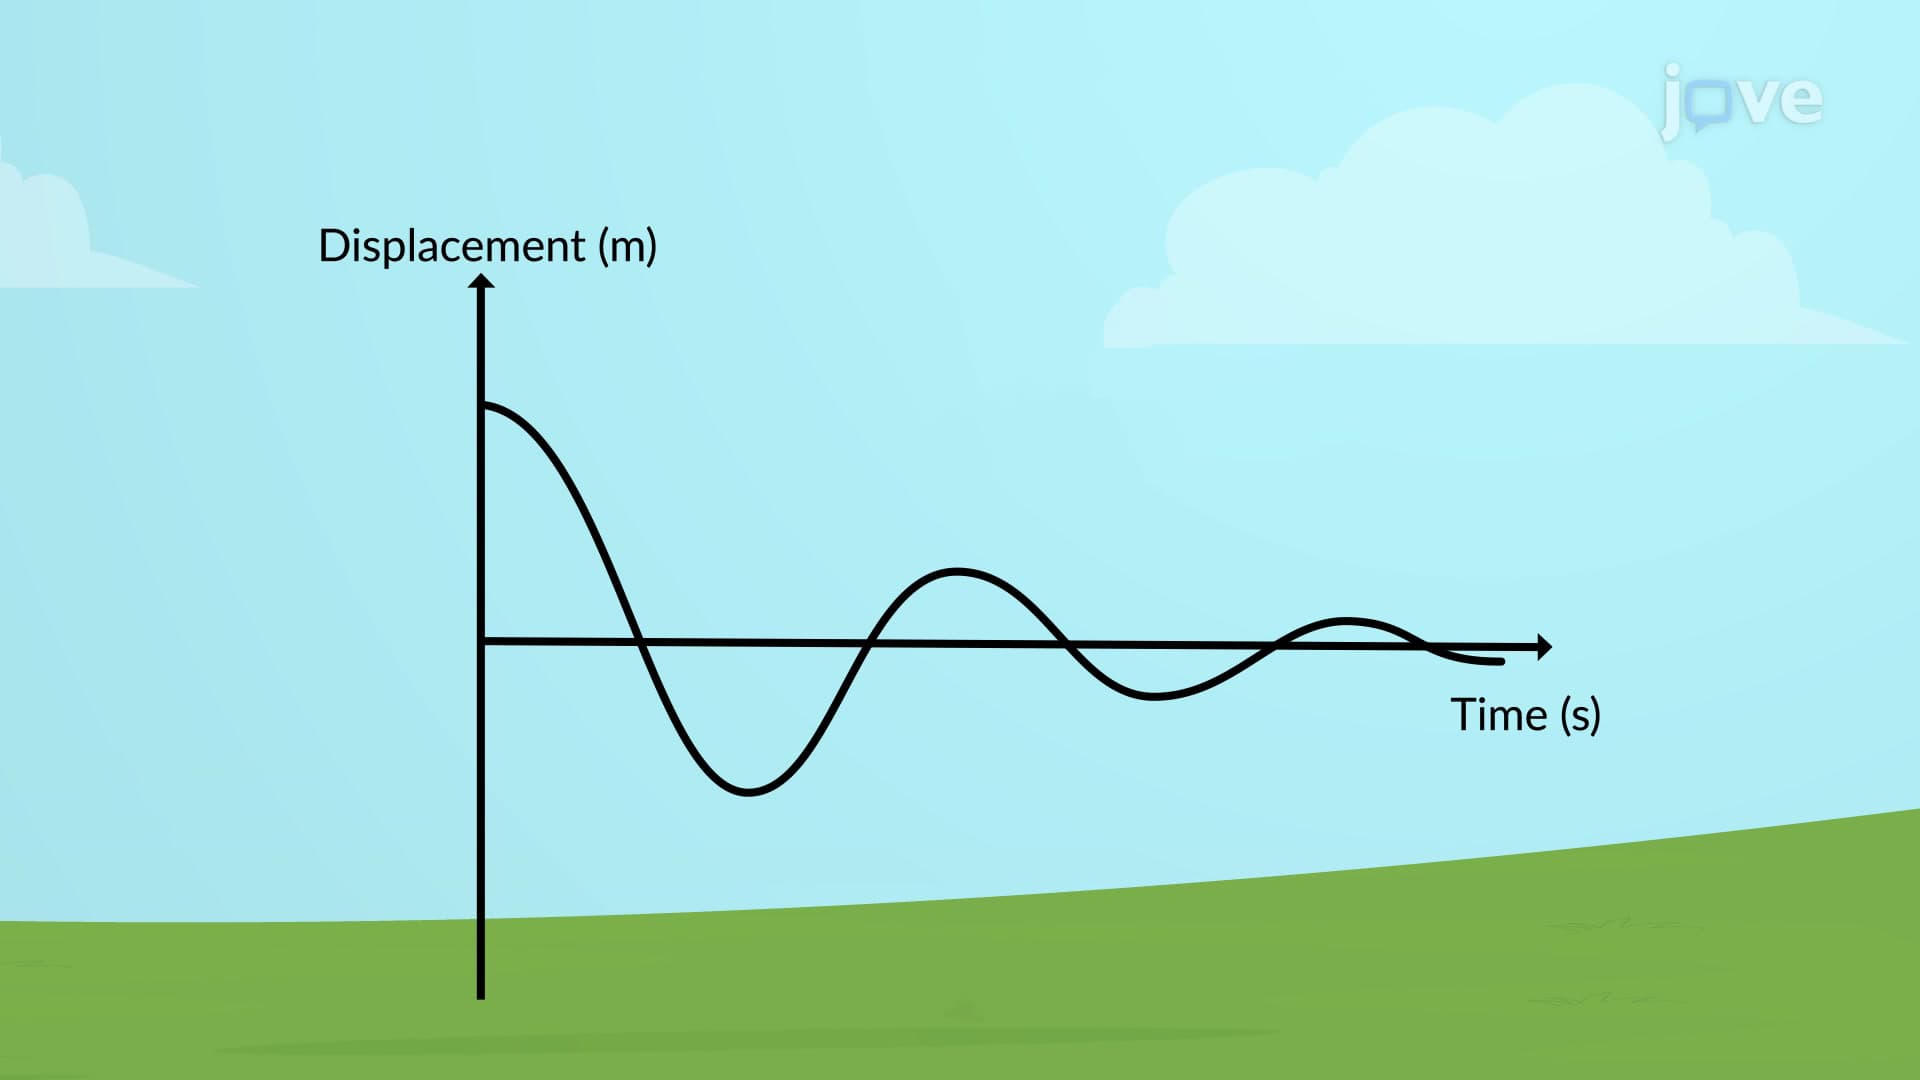
Types of Damping
 01:19
Root-Locus Method
This system can be represented by a block diagram,...
 01:28
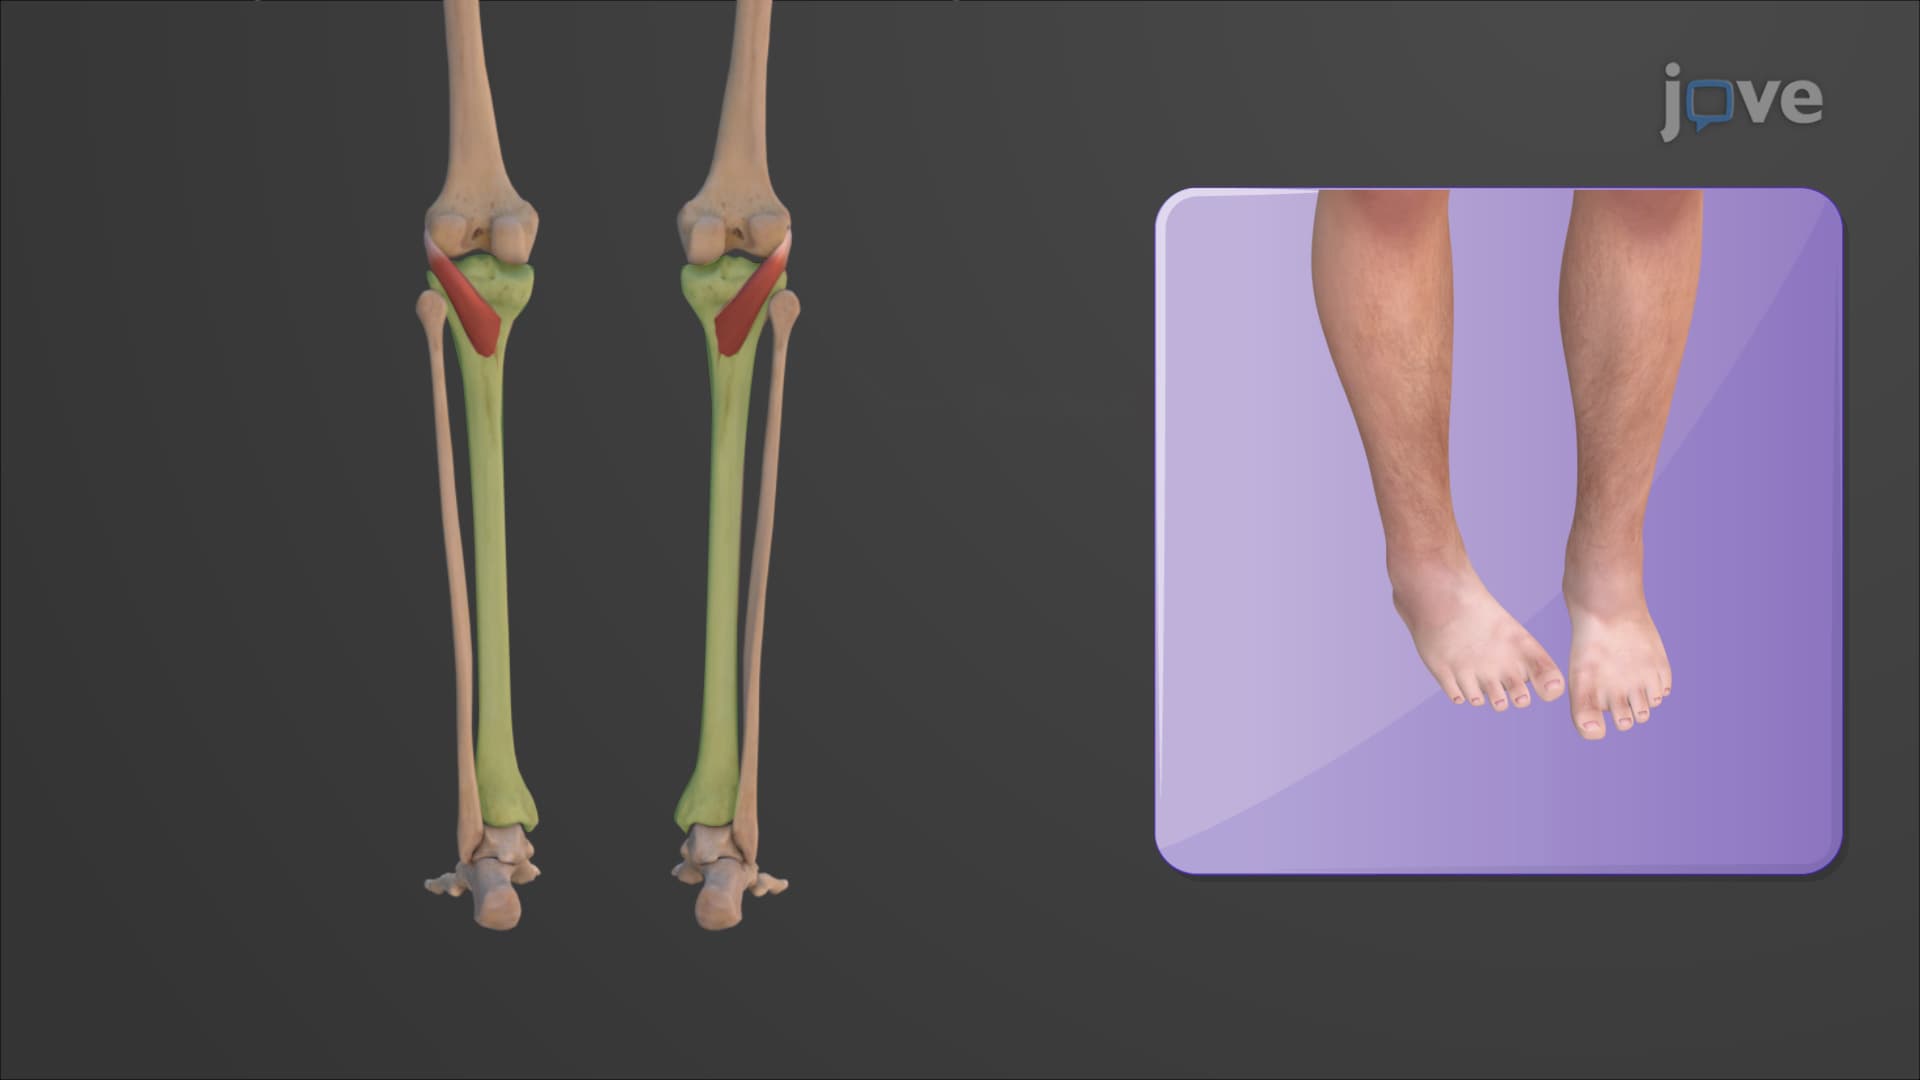
Muscles of the Leg that Move the Foot and Toes
Anterior Compartment
The anterior compartment includes muscles that contribute to the dorsiflexion of the foot. This compartment houses the tibialis anterior, extensor hallucis longus, and extensor digitorum longus muscles.
 01:07
Damped Oscillations
Although friction and other non-conservative...
 01:23
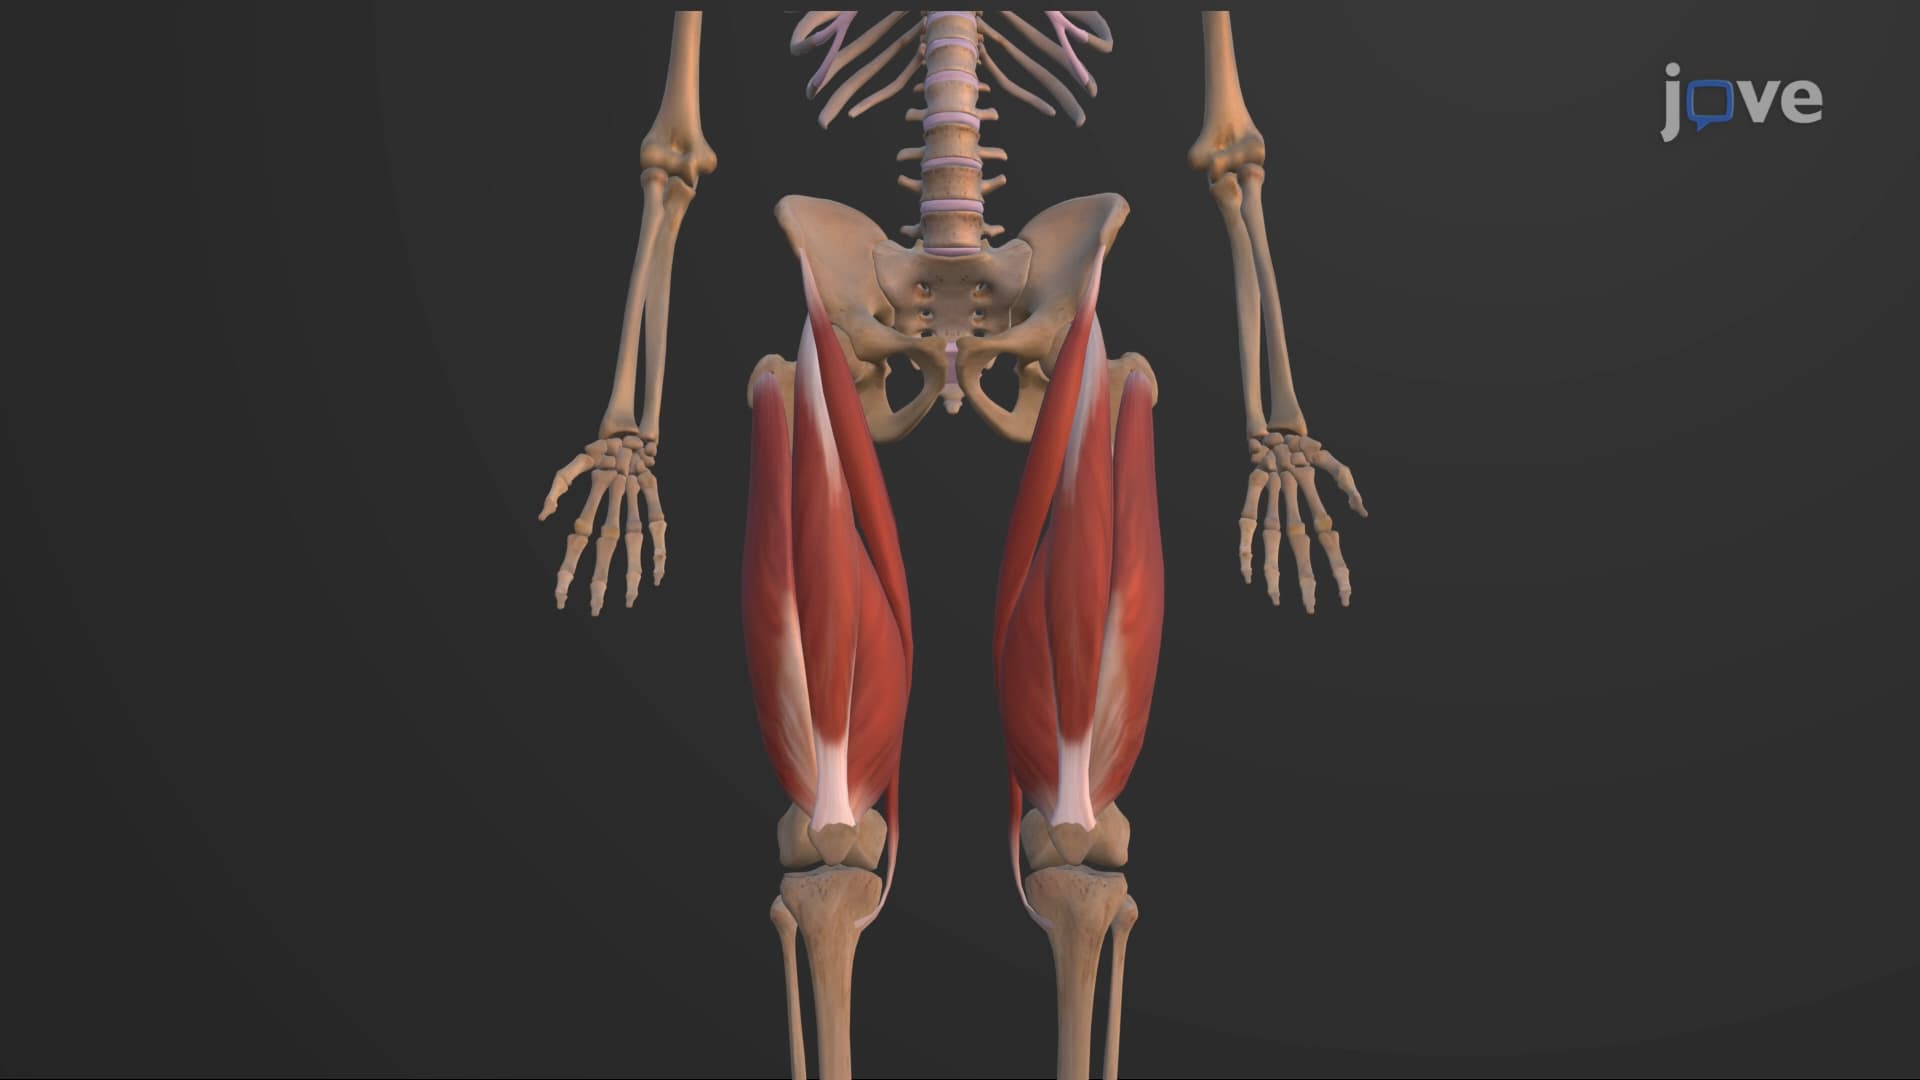
Muscles that Move the Leg
Anterior Compartment
The quadriceps femoris, the most visible muscle of the anterior compartment, is integral for leg extension and thigh flexion. It is formed by merging four distinct muscles — the vastus lateralis, vastus medialis, vastus intermedius, and rectus femoris. The quadriceps tendon, a shared tendon of the four quadriceps muscles, is affixed to...
 01:10
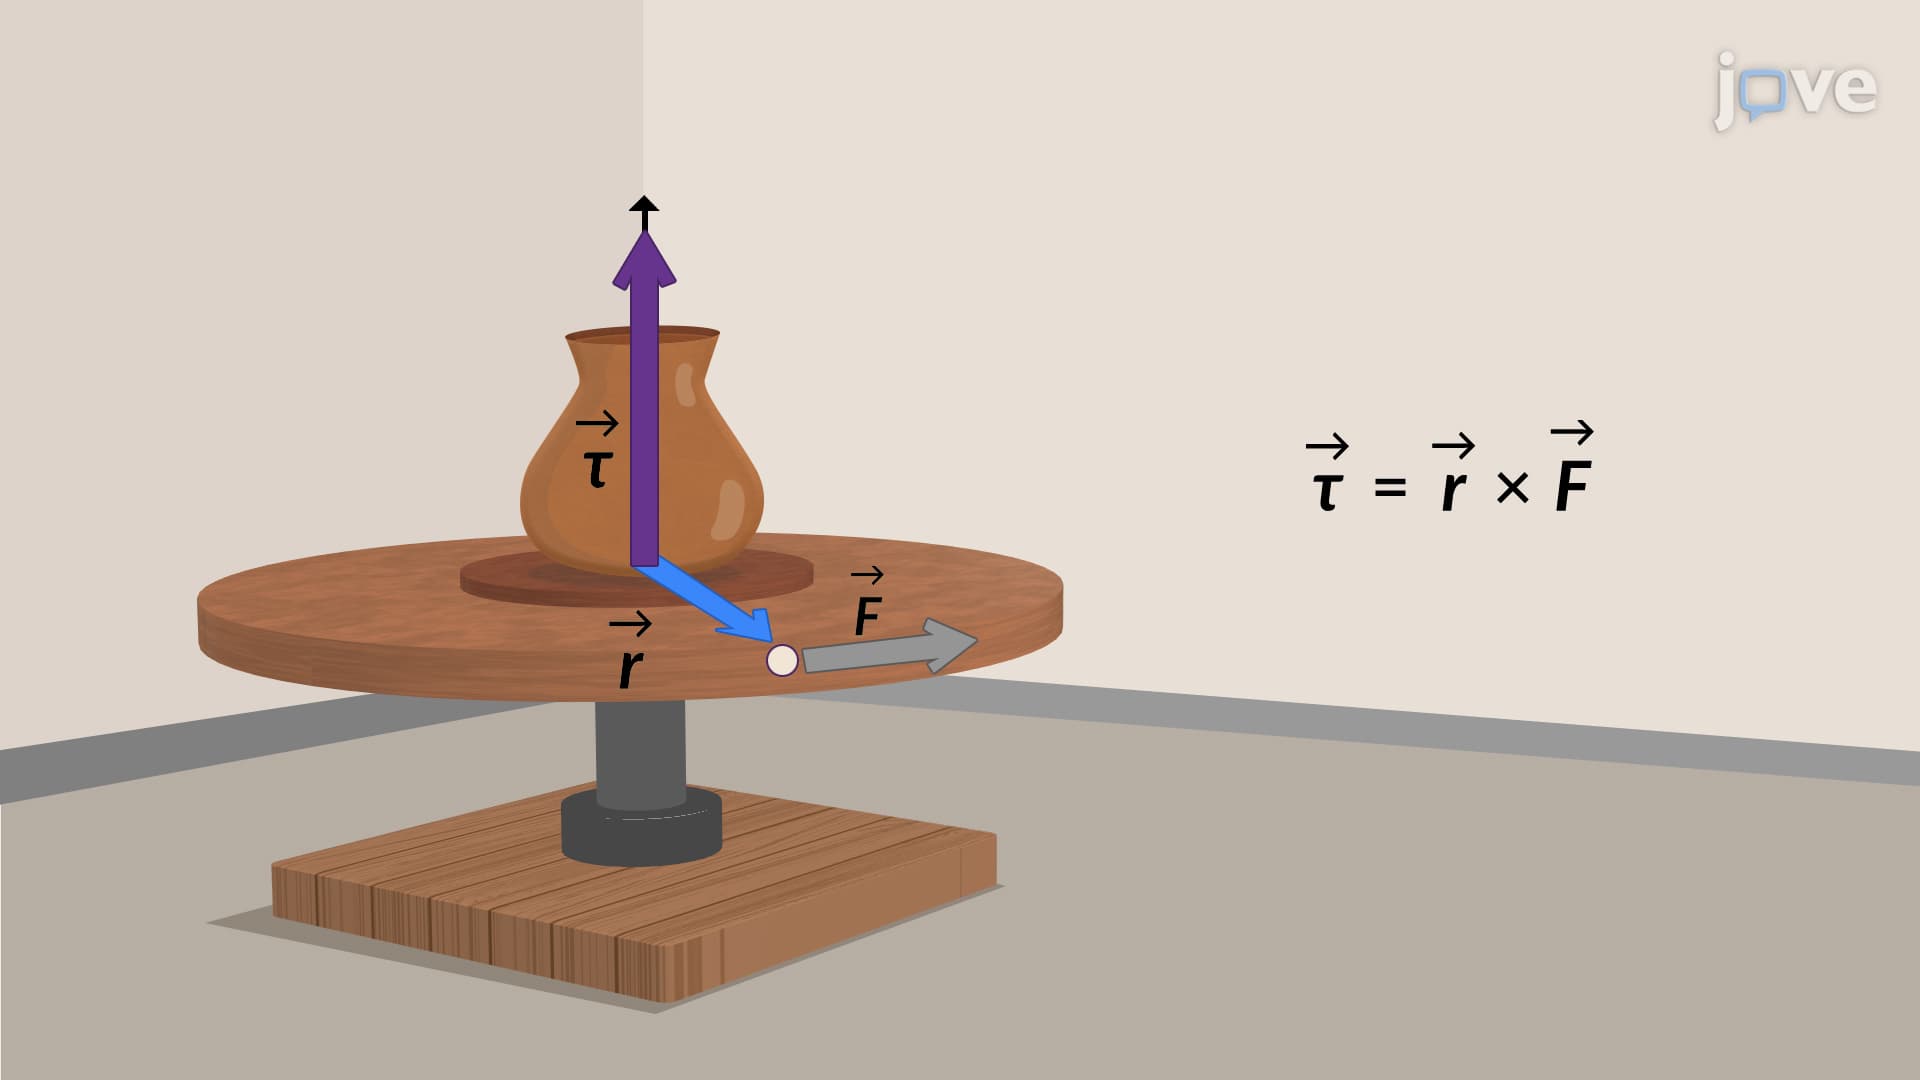
Torque
Torque can be considered as the rotational counterpart to force. Since forces change the translational...