Related Experiment Video
Updated: May 16, 2026
Subject-specific Musculoskeletal Model for Studying Bone Strain During Dynamic Motion
Published on: April 11, 2018
Force and torque modelling of drilling simulation for orthopaedic surgery
Troy MacAvelia1, Ahmad Ghasempoor, Farrokh Janabi-Sharifi
1a Department of Mechanical and Industrial Engineering , Ryerson University , 350 Victoria Street, Toronto , Ontario , M5B 2K3 Canada.

Abstract:
The advent of haptic simulation systems for orthopaedic surgery procedures has provided surgeons with an excellent tool for training and preoperative planning purposes. This is especially true for procedures involving the drilling of bone, which require a great amount of adroitness and experience due to difficulties arising from vibration and drill bit breakage. One of the potential difficulties with the drilling of bone is the lack of consistent material evacuation from the drill's flutes as the material tends to clog. This clogging leads to significant increases in force and torque experienced by the surgeon. Clogging was observed for feed rates greater than 0.5 mm/s and spindle speeds less than 2500 rpm. The drilling simulation systems that have been created to date do not address the issue of drill flute clogging. This paper presents force and torque prediction models that account for this phenomenon. The two coefficients of friction required by these models were determined via a set of calibration experiments. The accuracy of both models was evaluated by an additional set of validation experiments resulting in average R² regression correlation values of 0.9546 and 0.9209 for the force and torque prediction models, respectively. The resulting models can be adopted by haptic simulation systems to provide a more realistic tactile output.
Related Concept Videos
 01:15
Thin-Walled Hollow Shafts
 01:09
Transmission Shafts: Problem Solving
Next, use bending moment diagrams for the shaft to...
 01:10
Deformation in a Circular Shaft
 01:10
Residual Stresses in Circular Shafts
 01:10
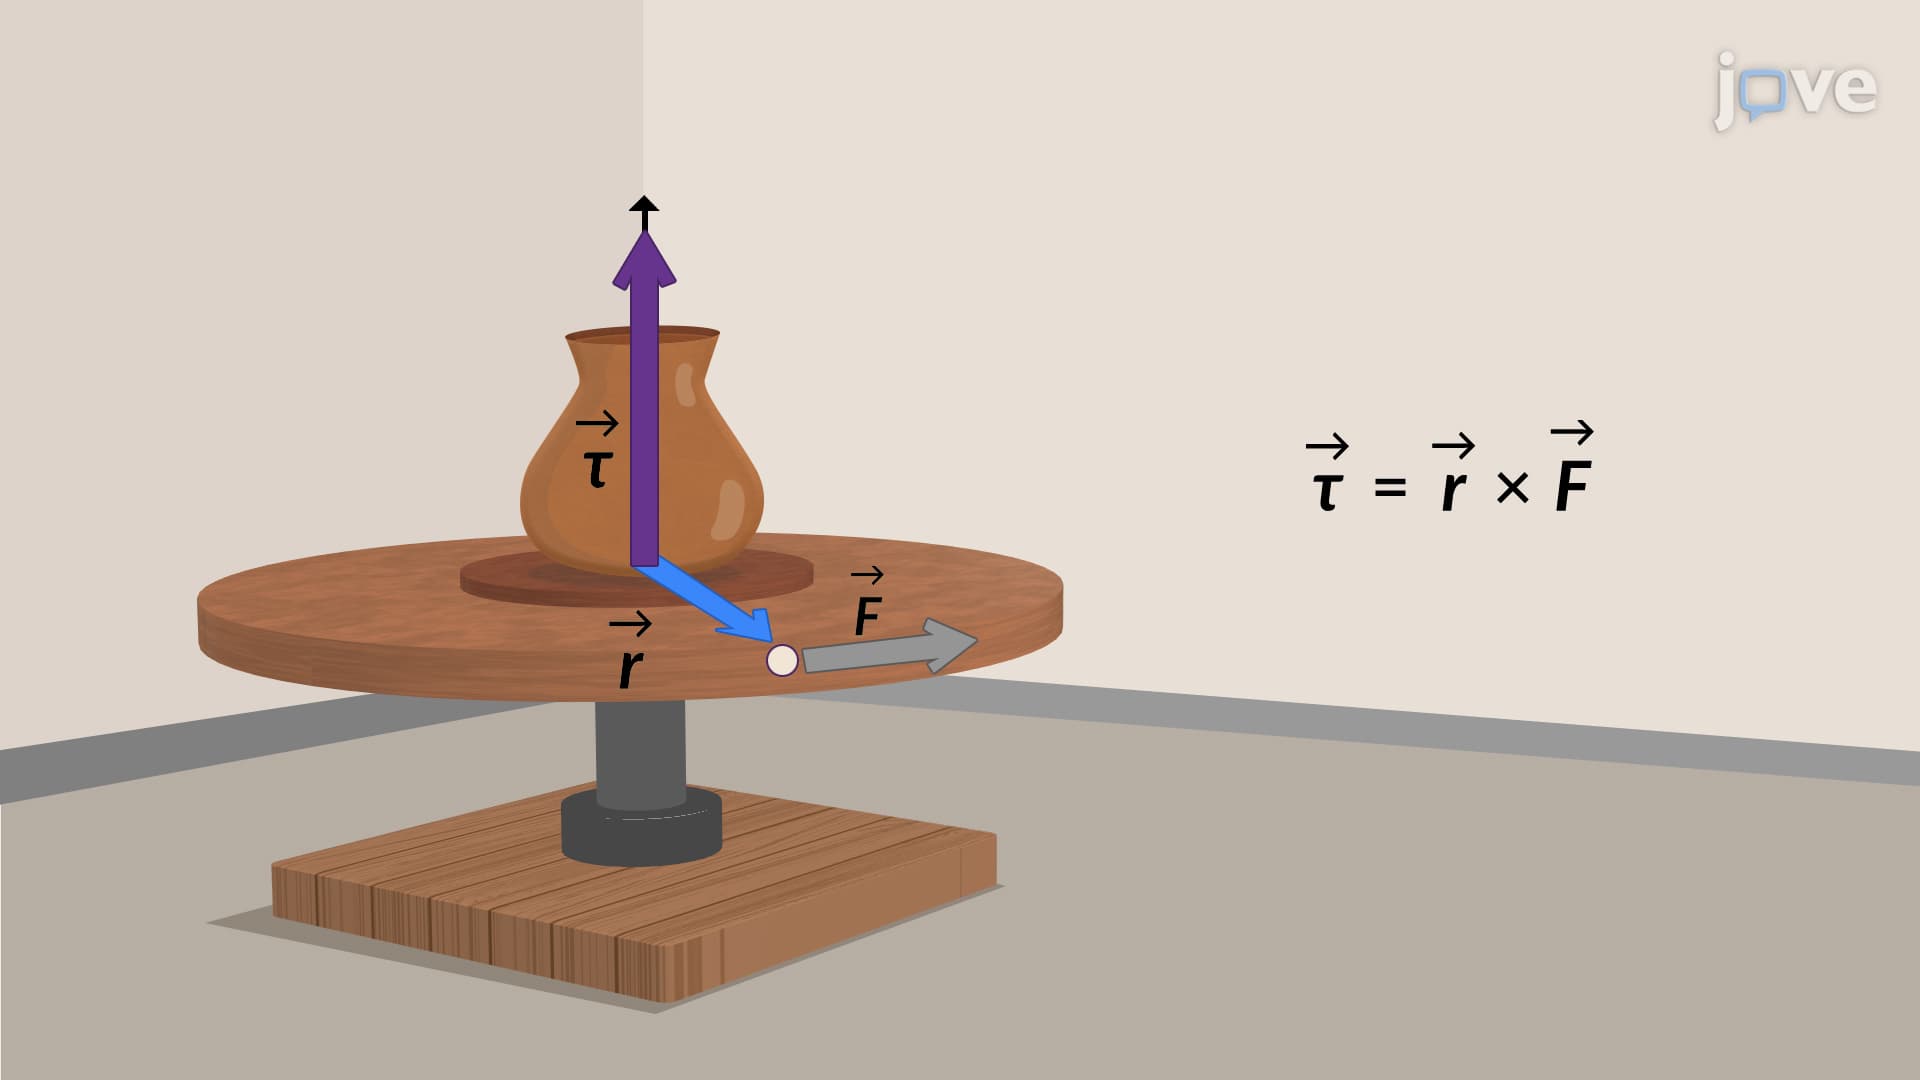
Torque
Torque can be considered as the rotational counterpart to force. Since forces change the translational...
 01:15
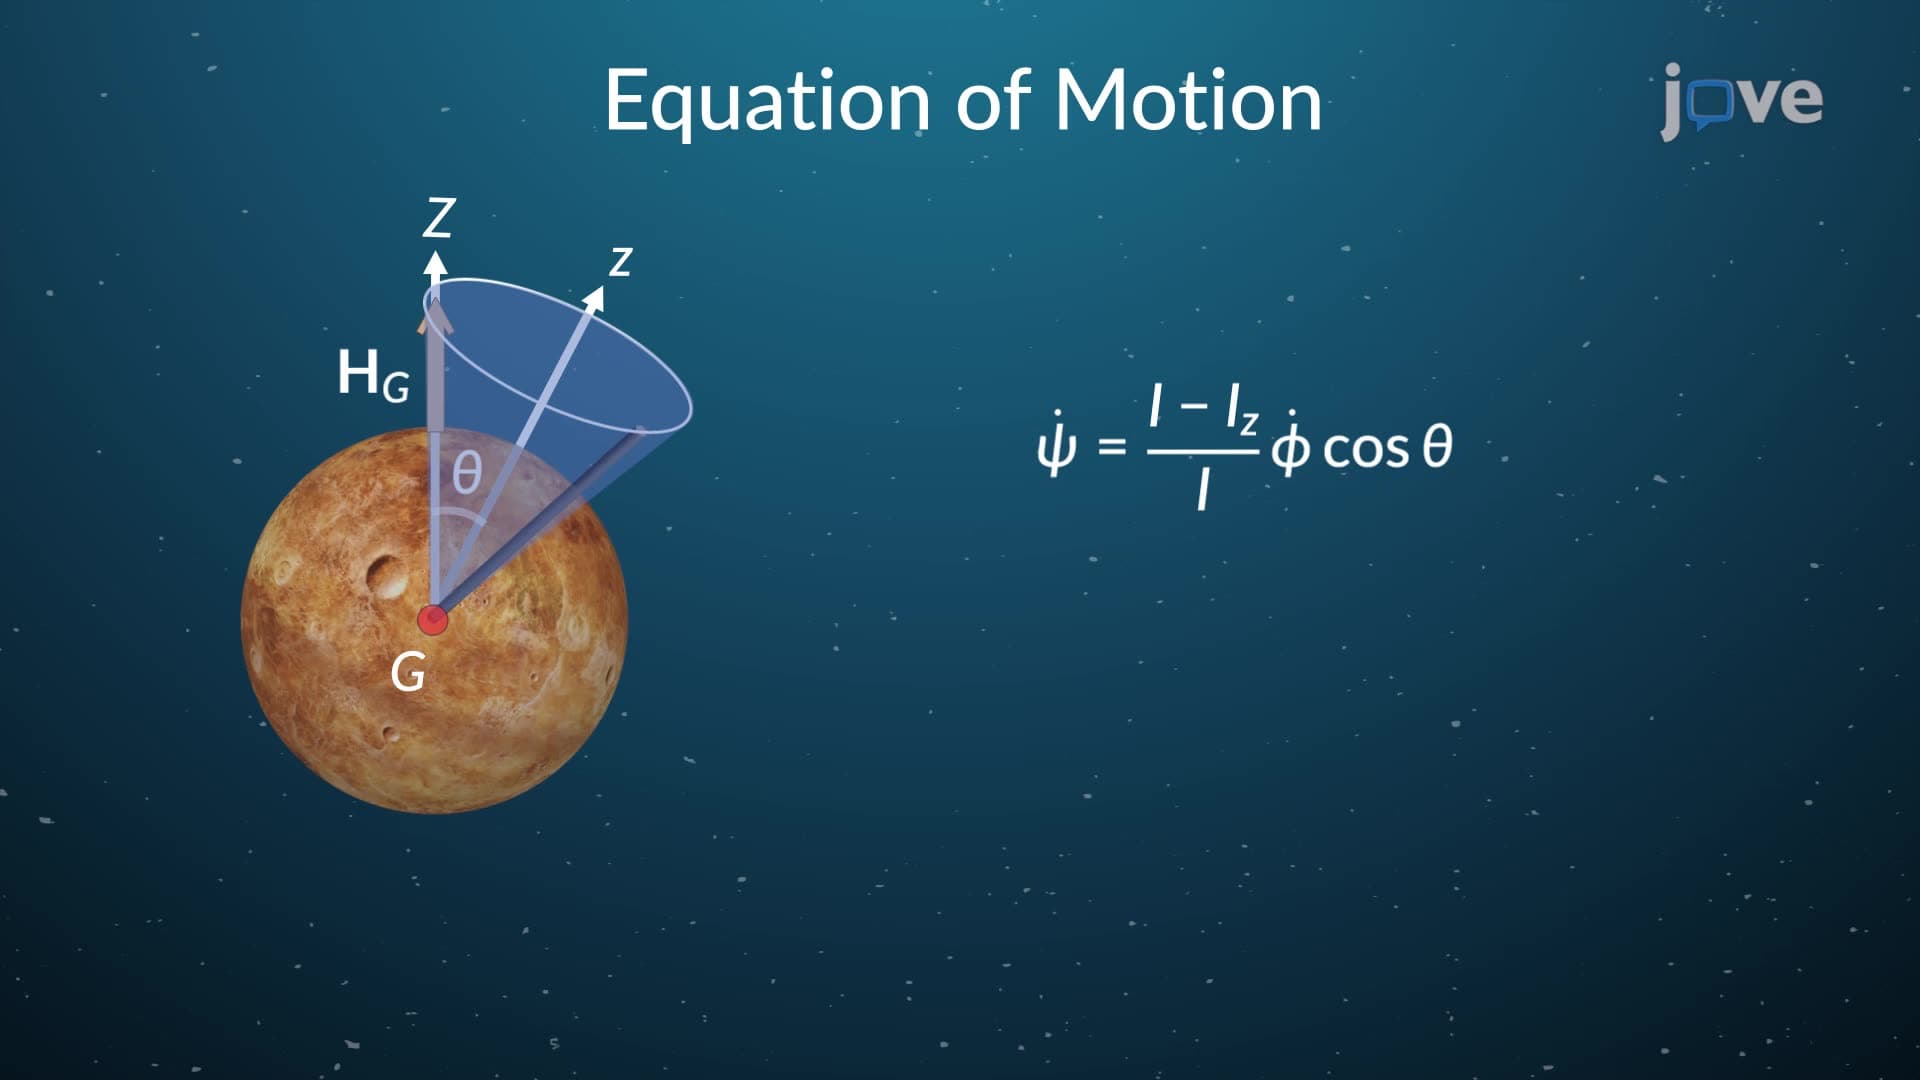
Torque Free Motion