Related Experiment Video
Updated: May 16, 2026
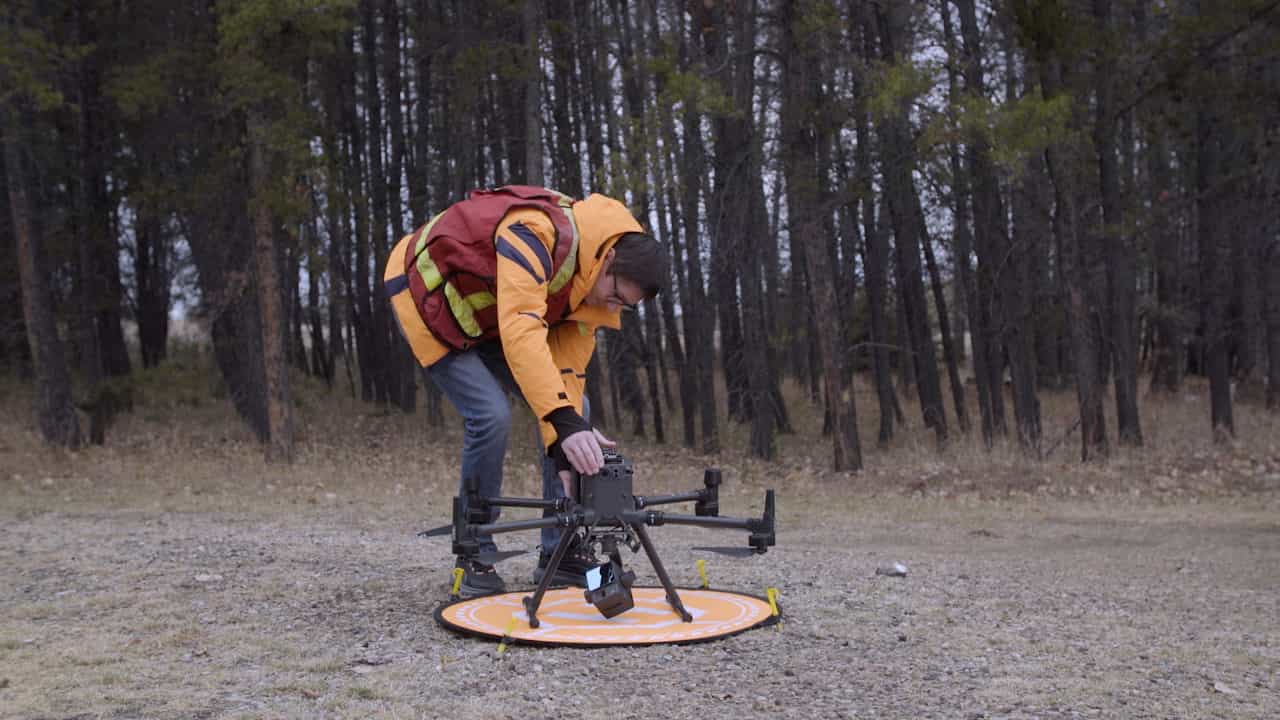
Collecting and Processing Drone-based Remotely Sensed Data for Use in Forest Recovery Monitoring
Published on: October 24, 2025
An adaptive altitude information fusion method for autonomous landing processes of small unmanned aerial rotorcraft
1Science and Technology on Inertial Laboratory, Beijing 100191, China. yushangtianxia@163.com

Abstract:
This paper presents an adaptive information fusion method to improve the accuracy and reliability of the altitude measurement information for small unmanned aerial rotorcraft during the landing process. Focusing on the low measurement performance of sensors mounted on small unmanned aerial rotorcraft, a wavelet filter is applied as a pre-filter to attenuate the high frequency noises in the sensor output. Furthermore, to improve altitude information, an adaptive extended Kalman filter based on a maximum a posteriori criterion is proposed to estimate measurement noise covariance matrix in real time. Finally, the effectiveness of the proposed method is proved by static tests, hovering flight and autonomous landing flight tests.
Related Concept Videos
 01:29
Application of Linearization and Approximation
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:30
Derivatives of Inverse Trigonometric Functions