Related Experiment Video
Updated: May 15, 2026


Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
Modeling and simulation of soft sensor design for real-time speed estimation, measurement and control of induction
1LIAS (Laboratory of Informatic and Automatic for the Systems), University of Poitiers, Bâtiment B25-2, rue Pierre Brousse BP 633 86022 Poitiers Cedex, France. erik.etien@univ-poitiers.fr

Abstract:
This paper deals with the design of a speed soft sensor for induction motor. The sensor is based on the physical model of the motor. Because the validation step highlight the fact that the sensor cannot be validated for all the operating points, the model is modified in order to obtain a fully validated sensor in the whole speed range. An original feature of the proposed approach is that the modified model is derived from stability analysis using automatic control theory.

Related Concept Videos
 01:19
Electro-mechanical Systems
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...
 01:24
Wind Turbine Machine Models
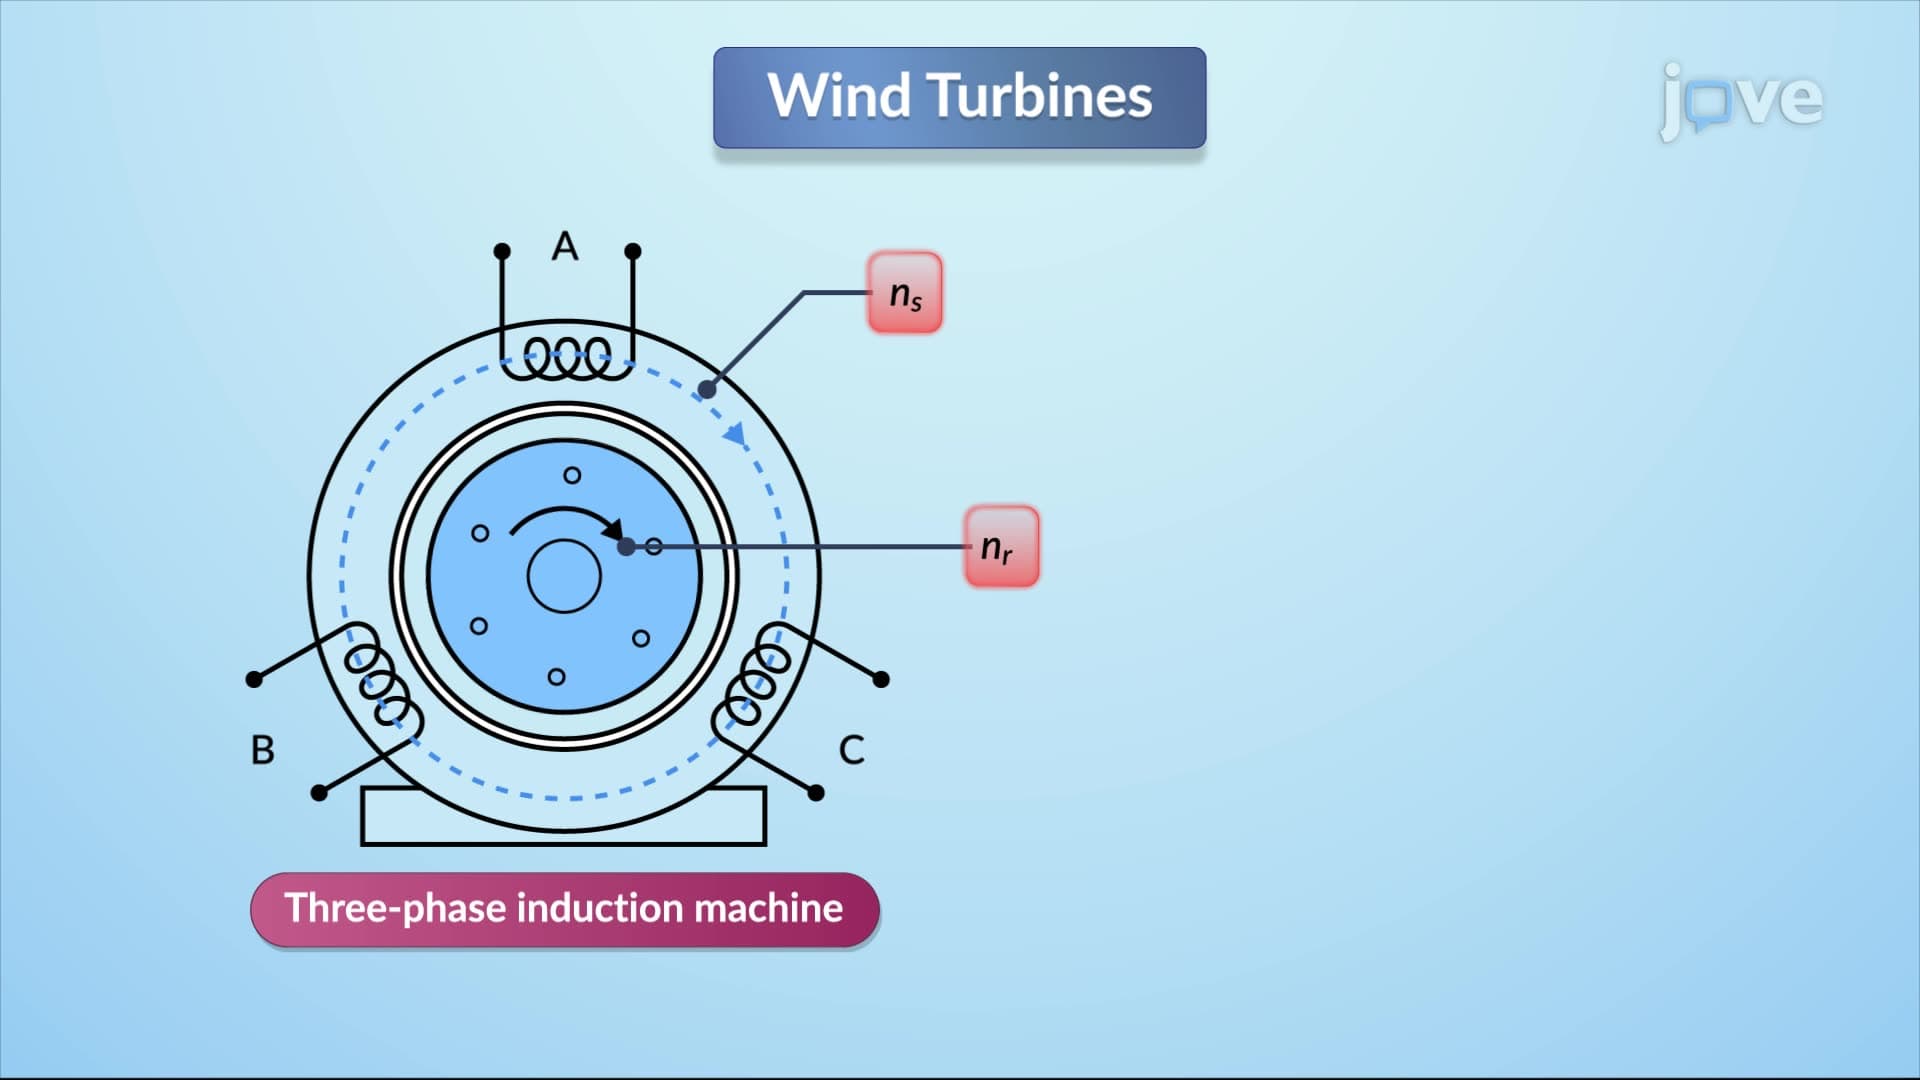
Induction machines interact through the rotating magnetic field generated by the stator and the rotor. The key parameter is slip, which is the difference between synchronous speed and rotor speed relative to synchronous speed. Slip is...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:13
Torque On A Current Loop In A Magnetic Field
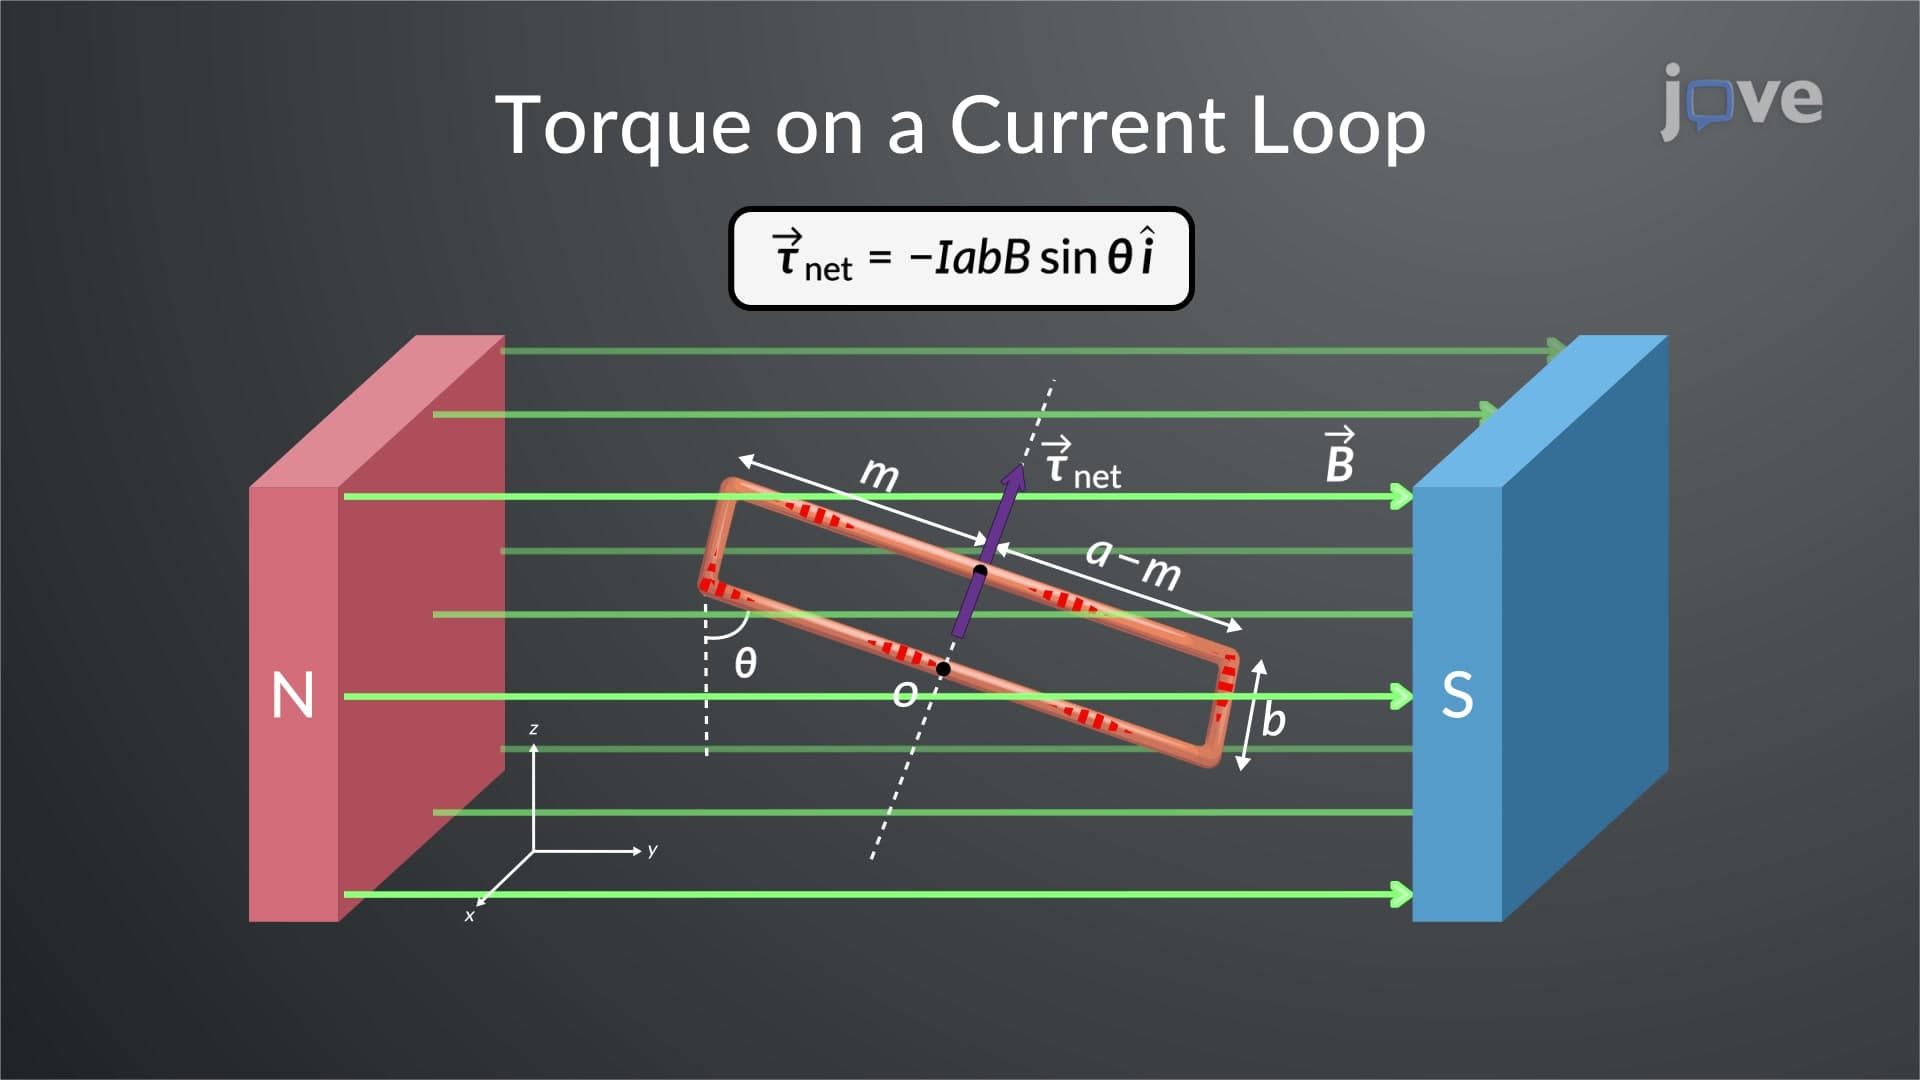
Consider a rectangular current-carrying loop containing N turns of wire, placed in a uniform magnetic field. The net force on a current-carrying loop...
 01:24
PI Controller: Design