Related Experiment Video
Updated: May 14, 2026

Using a Split-belt Treadmill to Evaluate Generalization of Human Locomotor Adaptation
Published on: August 23, 2017
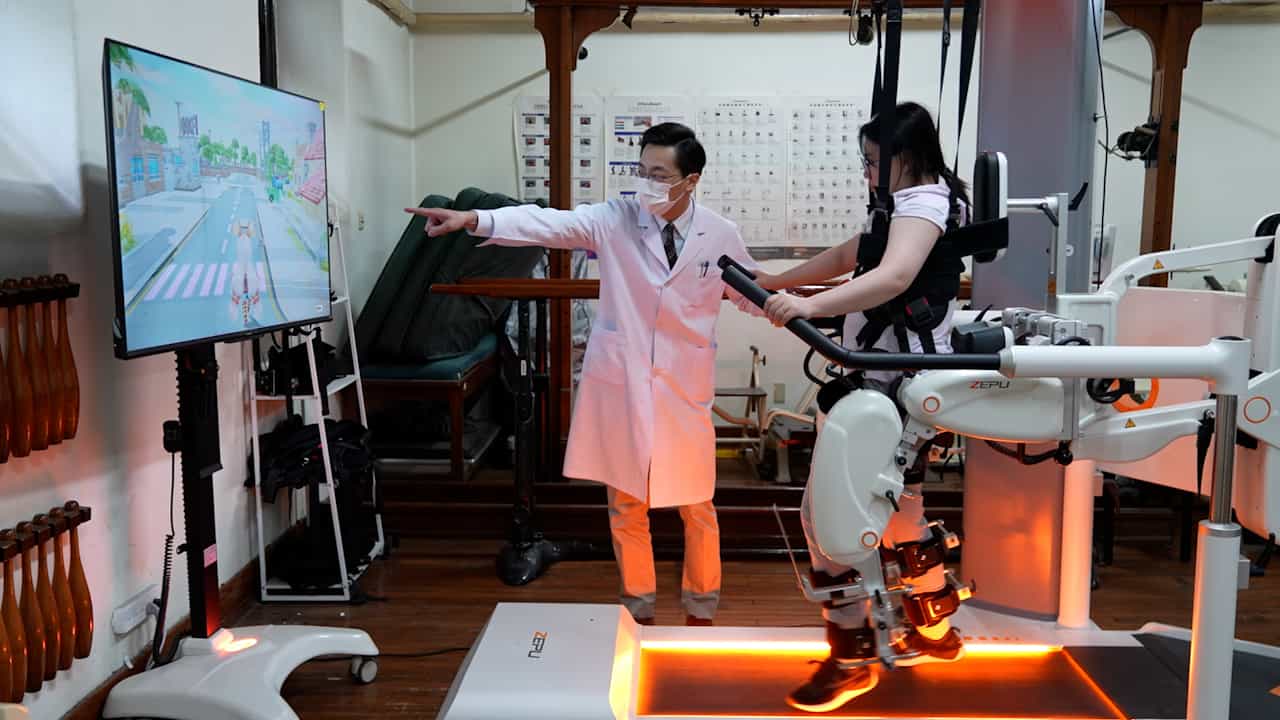
Aftereffects of robotic-assisted treadmill walking on the locomotor pattern in humans
Kiyotaka Kamibayashi1, Hiroaki Kawamoto, Yoshiyuki Sankai
1Faculty of Engineering, Information and Systems, University of Tsukuba, 1-1-1 Tennodai, Tsukuba, Ibaraki, Japan. kamibayashi@iit.tsukuba.ac.jp

Abstract:
We investigated the possible aftereffects on the locomotor pattern of treadmill walking after walking with the assistance of a robot suit HAL in nine healthy subjects. After walking on a treadmill at a speed of 3.5 km/h for 180 s as a pre-condition, each subject walked with robotic assistance to the hip and knee joints of both legs at the same speed for 600 s. The subjects performed normal walking for 300 s as a post-condition after the assisted walking. Compared with normal walking in the pre-condition, gait cycle duration and step length increased significantly during the assisted walking period. The increased gait cycle duration and step length during the assisted walking period returned to that of the pre-condition period soon after the start of the post-condition. In contrast, the range of motion (ROM) within one step cycle during the initial 60 s of the post-condition period gradually increased in the hip joint, but not in the knee joint. Compared with the mean hip ROM in the initial 10 s of the post-condition, significant increases in mean ROM every 10 s were observed in 4 phases of 20-60 s each in the right leg and in 3 phases of 20-50 s each in the left leg. Although strong aftereffects of the robotic assistance on the locomotor pattern were not observed in the present study, small adaptive changes were seen only in hip ROM during the initial normal walking phase immediately after assisted walking.