Related Experiment Video
Updated: May 14, 2026


Age-dependent Dynamics of Locomotion in Caenorhabditis elegans: A Lyapunov Exponent Analysis
Published on: September 23, 2025
Covariant Lyapunov vectors from reconstructed dynamics: the geometry behind true and spurious Lyapunov exponents
Hong-liu Yang1, Günter Radons, Holger Kantz
1Institute of Mechatronics, Reichenhainer Strasse 88, D-09126 Chemnitz, Germany.

Abstract:
The estimation of Lyapunov exponents from time series suffers from the appearance of spurious Lyapunov exponents due to the necessary embedding procedure. Separating true from spurious exponents poses a fundamental problem which is not yet solved satisfactorily. We show, in this Letter, analytically and numerically that covariant Lyapunov vectors associated with true exponents lie in the tangent space of the reconstructed attractor. Therefore, we use the angle between the covariant Lyapunov vectors and the tangent space of the reconstructed attractor to identify the true Lyapunov exponents. The usefulness of our method, also for noisy situations, is demonstrated by applications to data from model systems and a NMR laser experiment.
Related Concept Videos
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:06
Divergence and Stokes' Theorems
 01:27
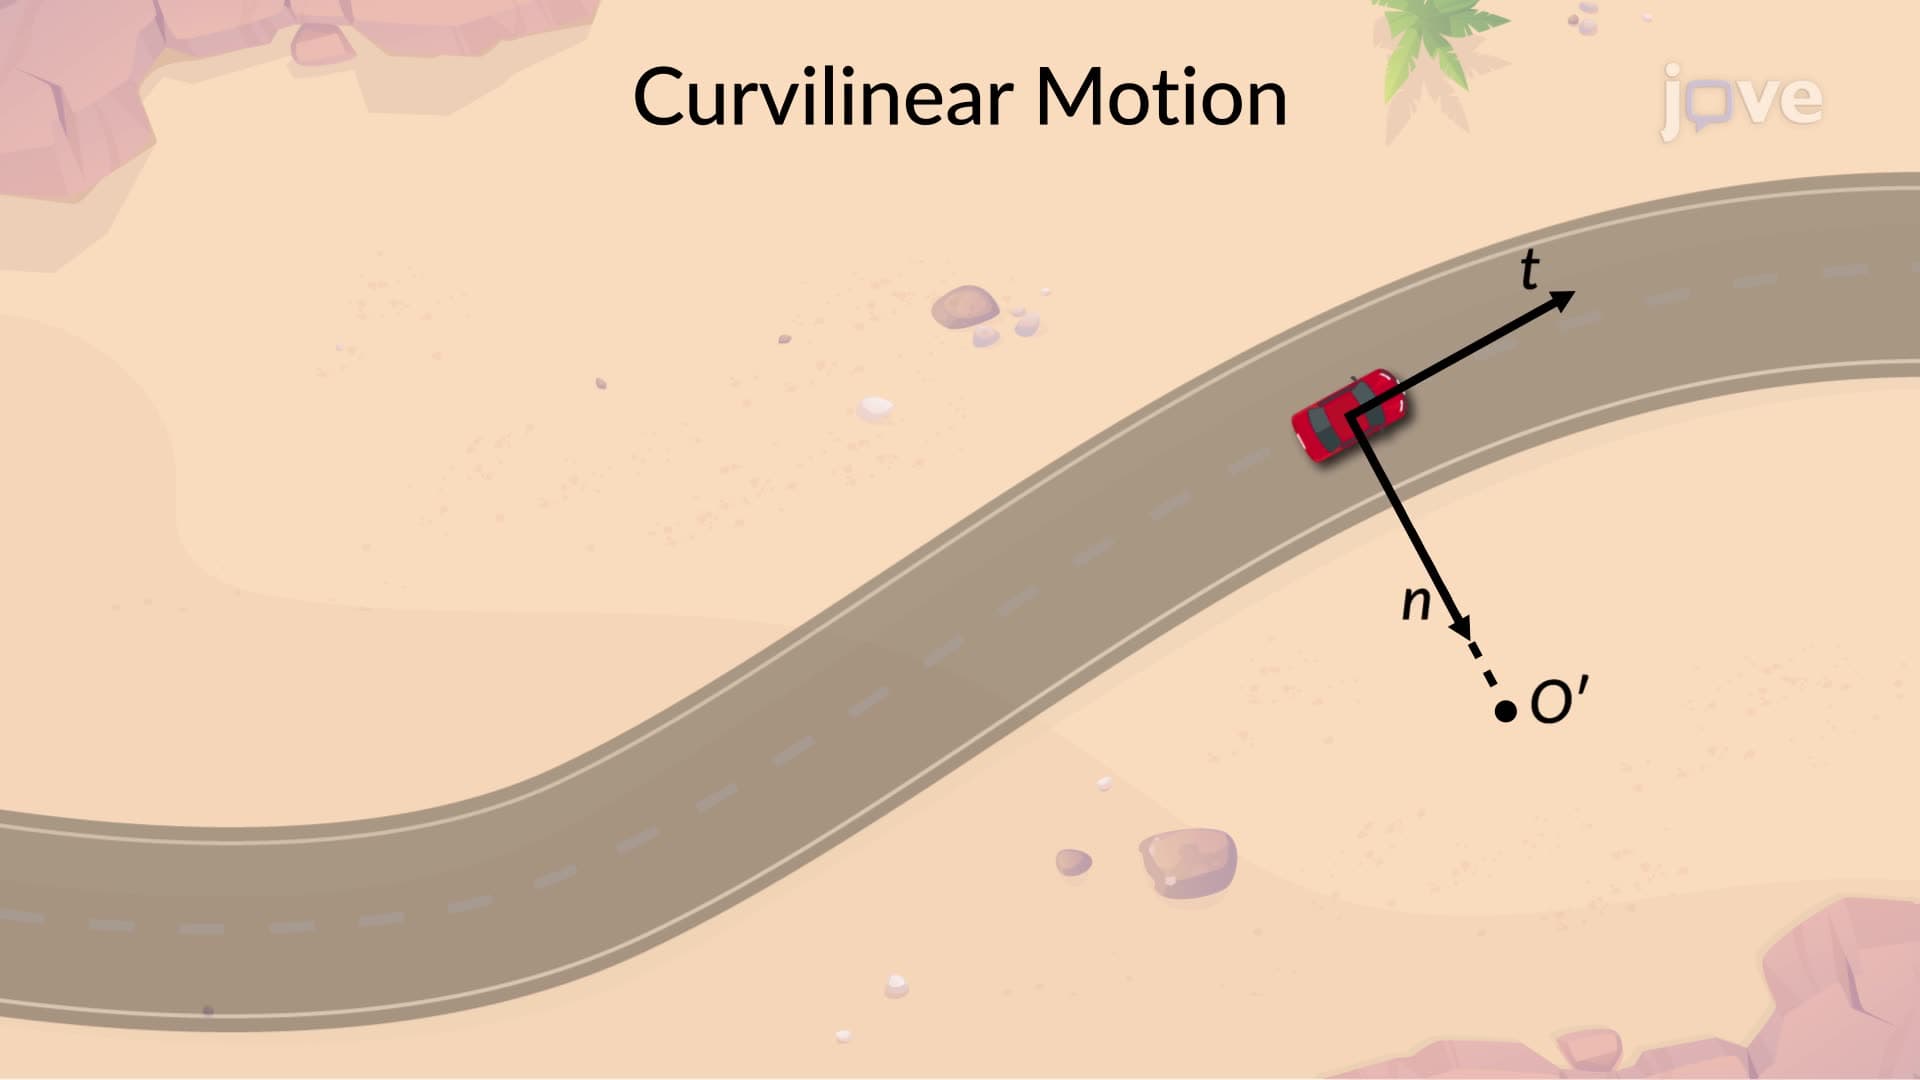
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:20
Region of Convergence of Laplace Tarnsform
Consider a decaying exponential signal that begins at a specific time. When deriving its Laplace transform, the time-domain variable is replaced with a complex variable. This substitution...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
 01:17
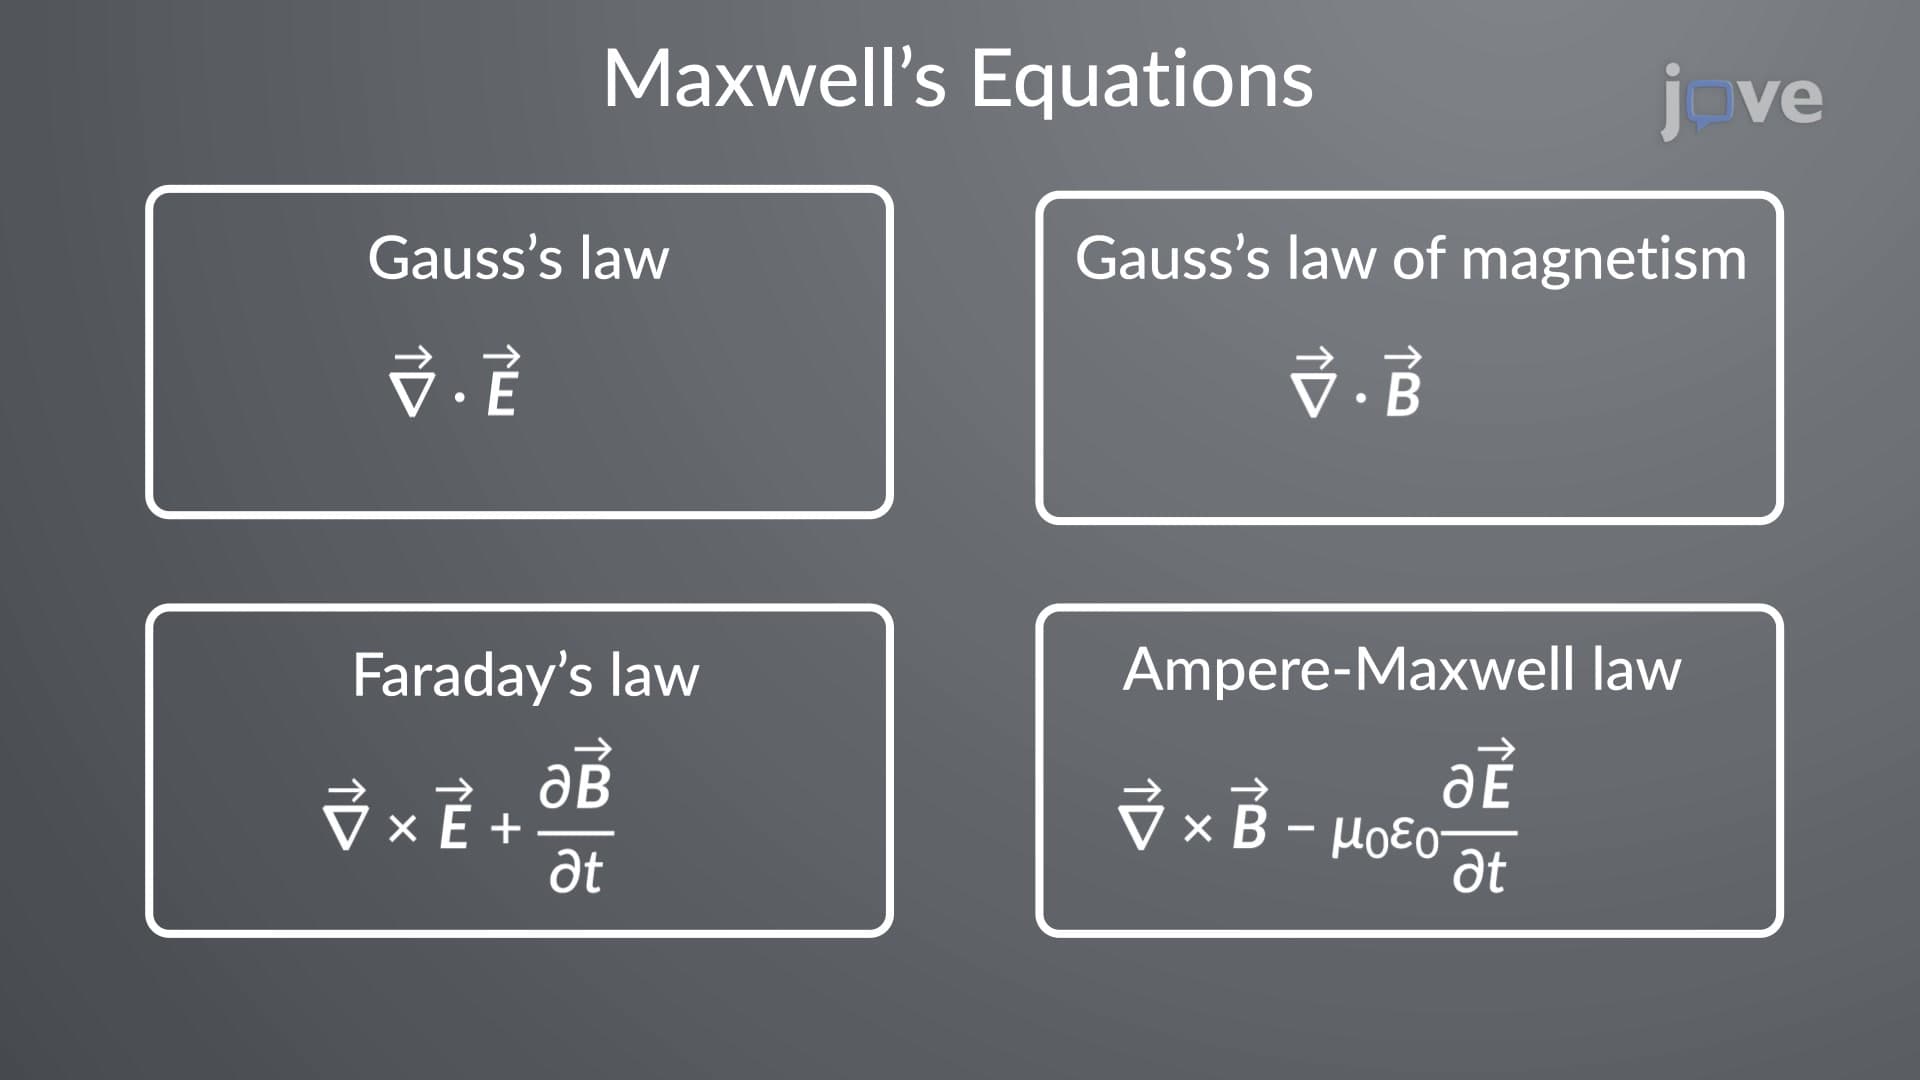
Differential Form of Maxwell's Equations