Non-linear adaptive controllers for an over-actuated pneumatic MR-compatible stepper
Related Experiment Video
Updated: May 14, 2026
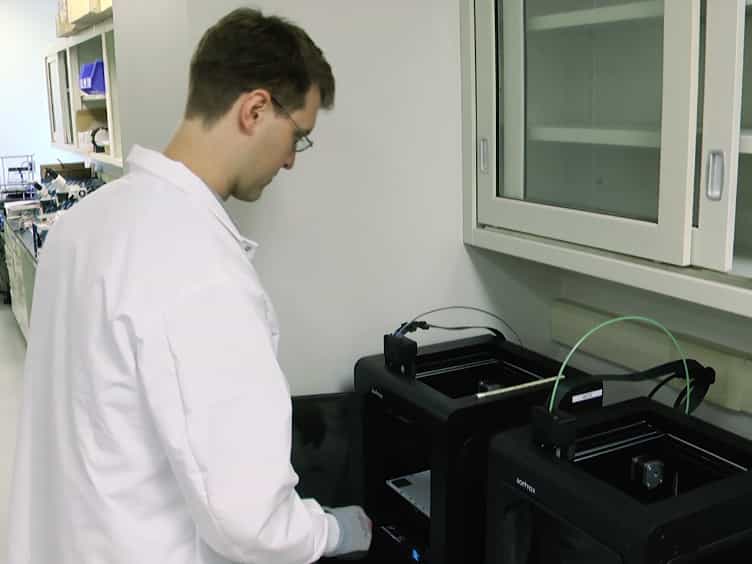
Three-dimensional Printing of Thermoplastic Materials to Create Automated Syringe Pumps with Feedback Control for Microfluidic Applications
Published on: August 30, 2018
Christoph Hollnagel1, Heike Vallery, Rainer Schädler
1Sensory-Motor Systems-SMS Lab, Institute of Robotics and Intelligent Systems-IRIS, ETH Zurich, Zurich, Switzerland.

Abstract:
Pneumatics is one of the few actuation principles that can be used in an MR environment, since it can produce high forces without affecting imaging quality. However, pneumatic control is challenging, due to the air high compliance and cylinders non-linearities. Furthermore, the system's properties may change for each subject. Here, we present novel control strategies that adapt to the subject's individual anatomy and needs while performing accurate periodic gait-like movements with an MRI compatible pneumatically driven robot. In subject-passive mode, an iterative learning controller (ILC) was implemented to reduce the system's periodic disturbances. To allow the subjects to intend the task by themselves, a zero-force controller minimized the interaction forces between subject and robot. To assist patients who may be too weak, an assist-as-needed controller that adapts the assistance based on online measurement of the subject's performance was designed. The controllers were experimentally tested. The ILC successfully learned to reduce the variability and tracking errors. The zero-force controller allowed subjects to step in a transparent environment. The assist-as-needed controller adapted the assistance based on individual needs, while still challenged the subjects to perform the task. The presented controllers can provide accurate pneumatic control in MR environments to allow assessments of brain activation.

Related Concept Videos
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:24
PI Controller: Design
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...