Related Experiment Video
Updated: May 12, 2026
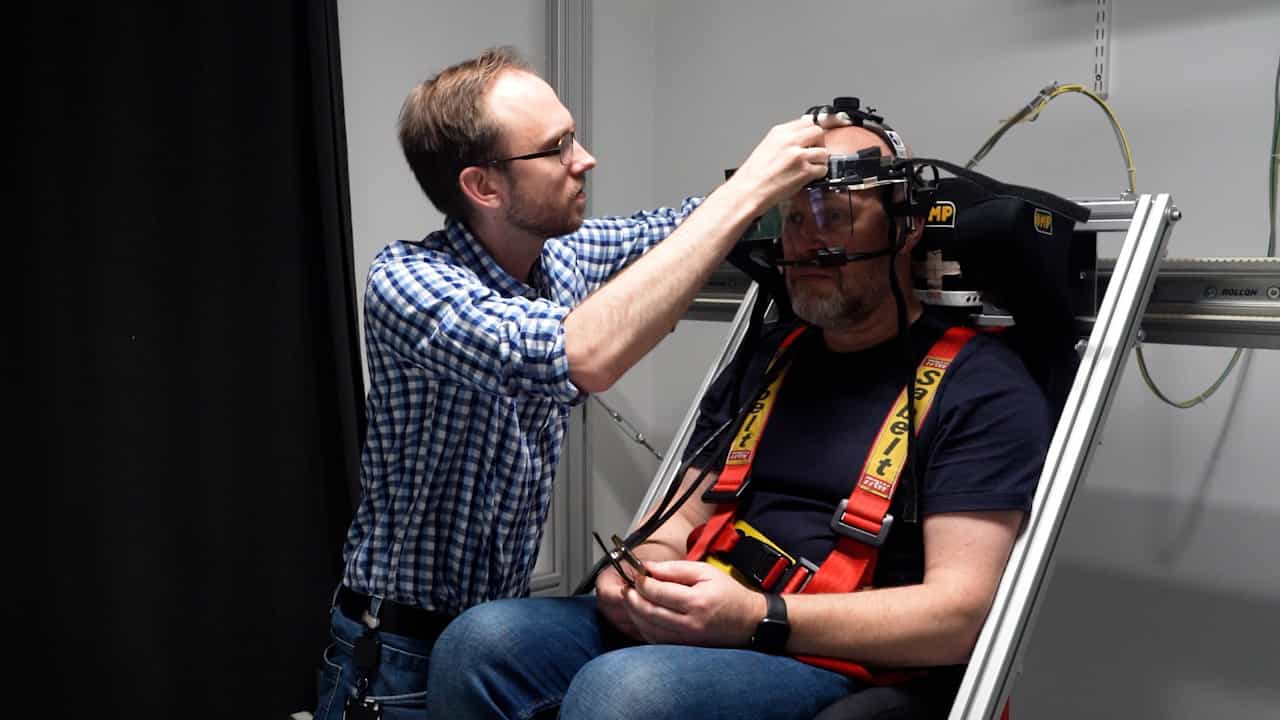

Using Eye-tracking to Assess the Relative Importance of Visual and Vestibular Input to Subcortical Motion Processing in the Roll Plane
Published on: August 22, 2025
Effects of stimulus eccentricity on the perception of visually induced self-motion facilitated by simulated viewpoint
1Faculty of Child Development, Nihon Fukushi University, Okuda, Mihama-cho, Aichi 470-3295, Japan. shinji@n-fukushi.ac.jp

Abstract:
The present investigation aimed to examine the effects of stimulus eccentricity in the facilitation of vection by a jittering visual inducer. A psychophysical experiment revealed that the central region of the visual field is more critical in facilitation by perspective viewpoint jitter than the peripheral area. The results suggest that the perceptual mechanism underlying the facilitation by jitter may be different from that responsible for generating standard vection from non-jittering visual motion, because the effects of stimulus eccentricity were quite different in these two situations.
Related Concept Videos
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:03
Inertial Frames of Reference
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:05
Mechanism of Ciliary Motion
The cilia are made up of microtubules in a 9+2 arrangement, with nine microtubule doublet ring bundles, surrounding a pair of central singlet microtubule bundles. The doublet microtubule bundles are...
01:05Mechanism of Ciliary Motion
The cilia are made up of microtubules in a 9+2 arrangement, with nine microtubule doublet ring bundles, surrounding a pair of central singlet microtubule bundles. The doublet microtubule bundles are...