Modeling heading and path perception from optic flow in the case of independently moving objects
Related Experiment Video
Updated: May 12, 2026
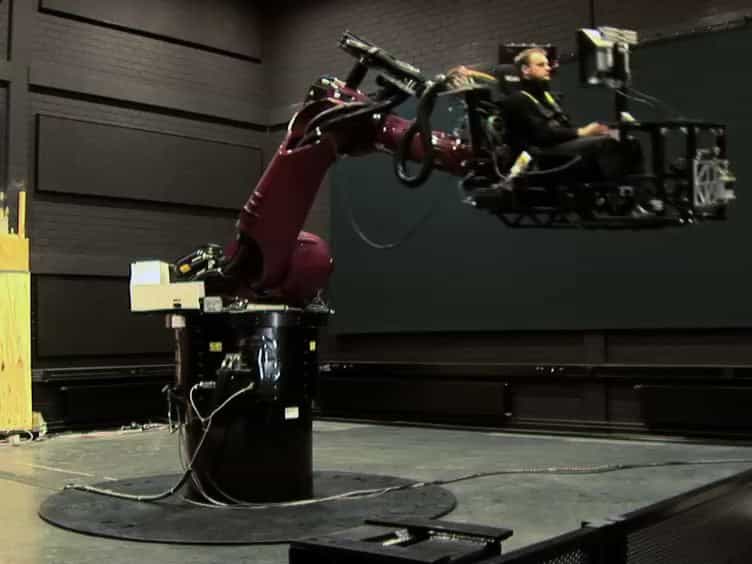
MPI CyberMotion Simulator: Implementation of a Novel Motion Simulator to Investigate Multisensory Path Integration in Three Dimensions
Published on: May 10, 2012
Florian Raudies1, Heiko Neumann
1Center for Computational Neuroscience and Neural Technology, Boston University Boston, MA, USA ; Center of Excellence for Learning in Education, Science, and Technology, Boston University Boston, MA, USA.

Abstract:
Humans are usually accurate when estimating heading or path from optic flow, even in the presence of independently moving objects (IMOs) in an otherwise rigid scene. To invoke significant biases in perceived heading, IMOs have to be large and obscure the focus of expansion (FOE) in the image plane, which is the point of approach. For the estimation of path during curvilinear self-motion no significant biases were found in the presence of IMOs. What makes humans robust in their estimation of heading or path using optic flow? We derive analytical models of optic flow for linear and curvilinear self-motion using geometric scene models. Heading biases of a linear least squares method, which builds upon these analytical models, are large, larger than those reported for humans. This motivated us to study segmentation cues that are available from optic flow. We derive models of accretion/deletion, expansion/contraction, acceleration/deceleration, local spatial curvature, and local temporal curvature, to be used as cues to segment an IMO from the background. Integrating these segmentation cues into our method of estimating heading or path now explains human psychophysical data and extends, as well as unifies, previous investigations. Our analysis suggests that various cues available from optic flow help to segment IMOs and, thus, make humans' heading and path perception robust in the presence of such IMOs.
Related Concept Videos
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:15
Depth Perception and Spatial Vision
 01:20
Parallel Processing
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:27
Uniform Depth Channel Flow