Related Experiment Video
Updated: May 11, 2026
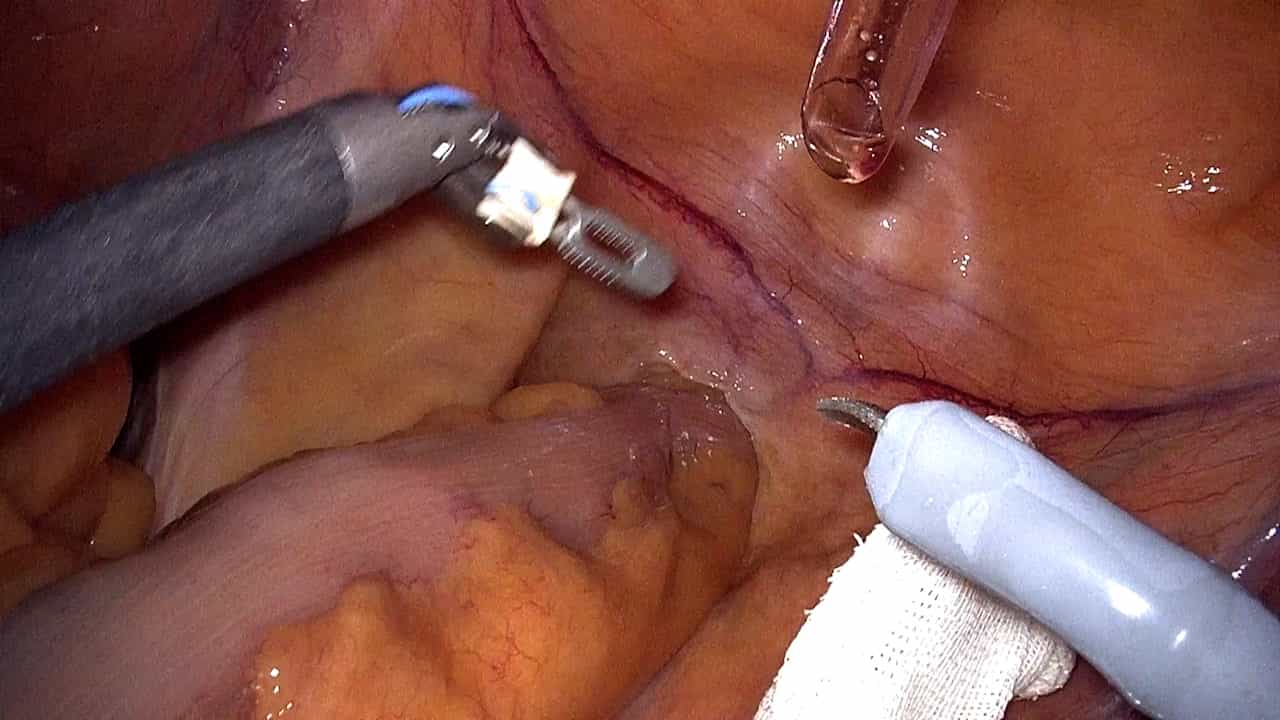

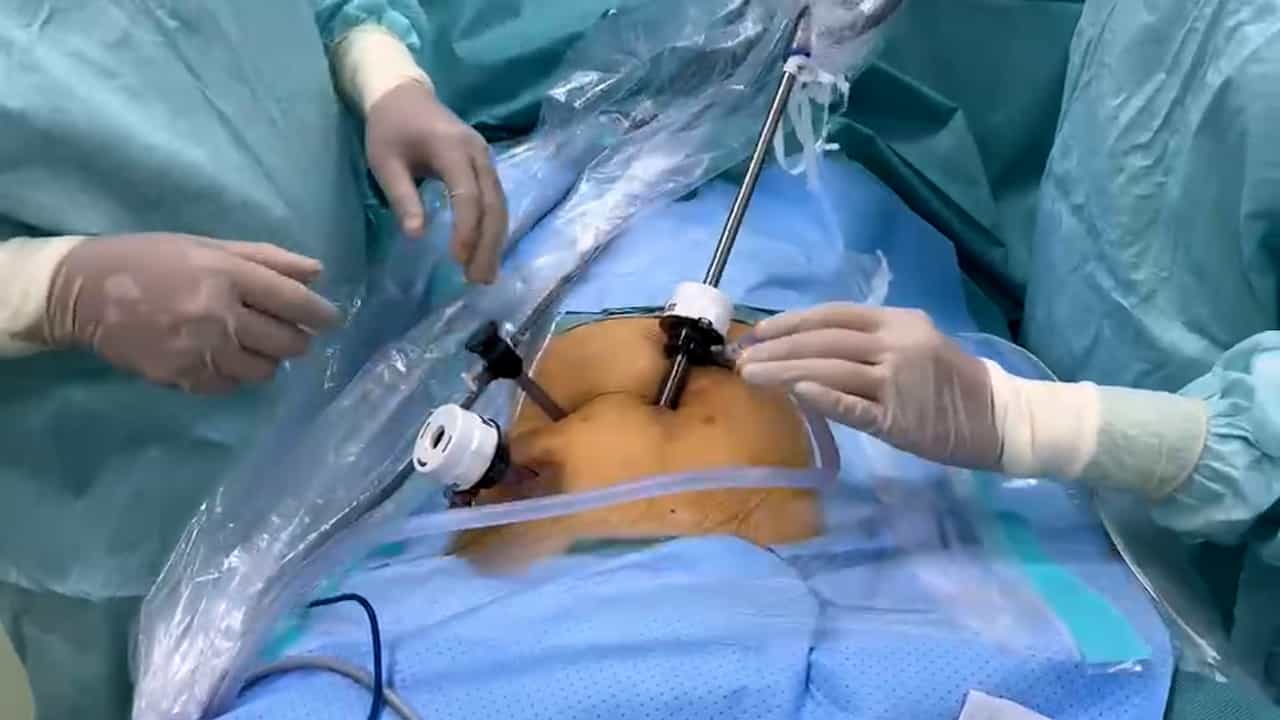
Surgical Robot-Assisted Transanal Specimen Extraction Radical Sigmoidectomy Without an Auxiliary Abdominal Incision
Published on: June 13, 2025
Application of design rationale for a robotic system for single-incision laparoscopic surgery and natural orifice
1Department of Biomedical Engineering, University of Strathclyde, Glasgow, UK. w.yao@strath.ac.uk

Abstract:
Current endoscopes and instruments are inadequate in some respects for complex intra-abdominal surgery because they are too flexible and cannot provide robust grasping and anatomic retraction. Minimal invasive surgery devices represent a sophisticated class of mechanical instruments making use of a range of mechanisms integrated into modular platforms that can be combined to undertake complex medical procedures. Although the machine elements concerned represent classic mechanical engineering devices, issues of miniaturization, surgical procedure compliance and location control conspire to present a design challenge. In order to capture, document and resolve the design requirements for this complex application, quality functional deployment has been applied in combination with design rationale, captured through issue-based information system mapping. This article reports the use of these tools to produce robot designs with improved dexterity and triangulation that are basic requirements in laparoscopy.