Related Experiment Video
Updated: Sep 27, 2026
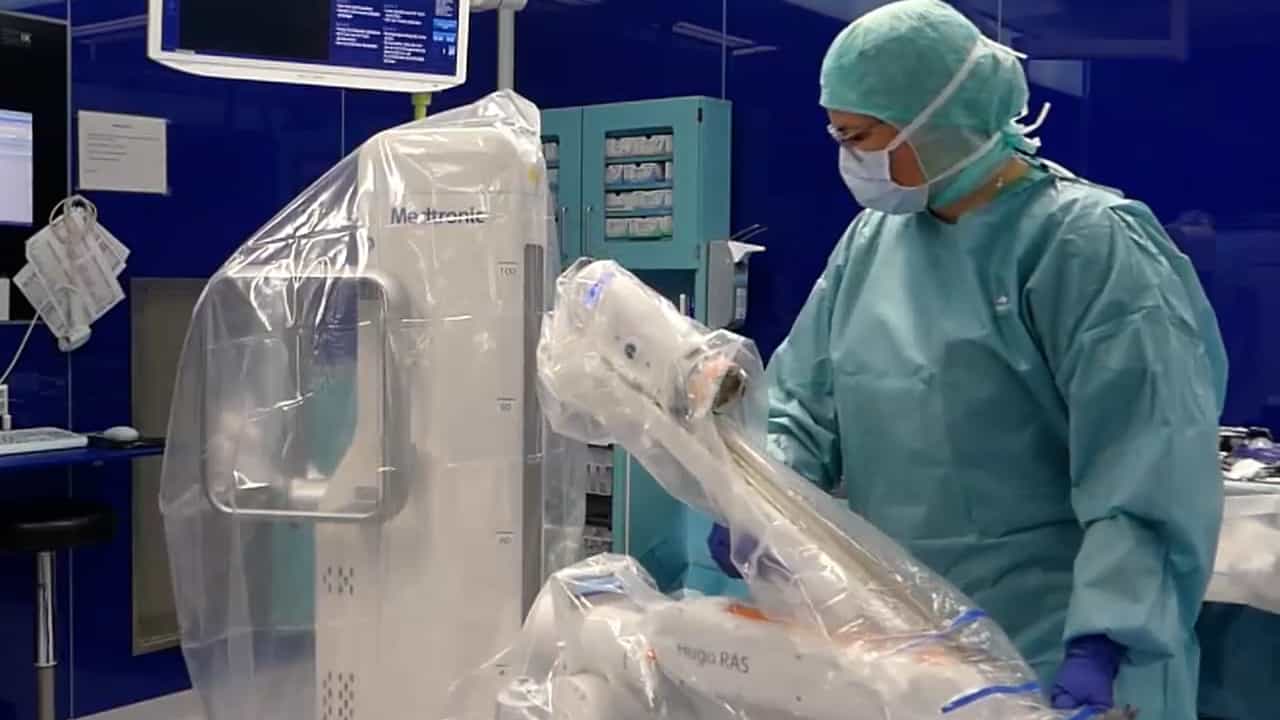

Robotics in Surgery: A Modular Robotic Platform Driven Gastric Wedge Resection
Published on: February 7, 2025
New Frontiers in Robotic Ventral Hernia Repair: A Qualitative Systematic Review of Robotic Approaches Other than Da
Gabriela Lyons1, Clara Avelar Mendes de Vasconcellos2, Thiago Souza E Silva3
1Centro Universitário Souza Marques, Rio de Janeiro, Brazil.

Introduction:
Robotic-assisted ventral hernia repair has expanded over the last decade, largely driven by the widespread adoption of the da Vinci platform. Although this system offers advantages in visualization, precision, and dexterity, concerns regarding cost, accessibility, and platform design have stimulated the development of alternative robotic systems. However, evidence evaluating the clinical implementation and technological impact of these emerging platforms in abdominal wall surgery remains limited. We conducted a systematic review to assess new robotic platforms used for ventral hernia repair.
Methods:
This mixed-methods systematic review was conducted in accordance with PRISMA 2020 guidelines. Studies reporting robotic ventral hernia repair performed using non-da Vinci platforms were included. PubMed/MEDLINE, Embase, LILACS, Cochrane Library, SciELO, and Web of Science were systematically searched from database inception to July 2025. Qualitative thematic synthesis served as the primary analysis, complemented by descriptive evaluation of perioperative clinical outcomes. Extracted data included study characteristics, robotic platform, surgical approach, operative and docking times, postoperative complications, conversion, and length of hospital stay. Due to clinical and methodological heterogeneity, quantitative meta-analysis was not performed.
Results:
From 218 records identified, 10 studies (6 case series, 3 case reports, and 1 cohort), comprising 95 patients, met inclusion criteria. Three robotic platforms were evaluated: Hugo, Versius, and SSI Mantra. Qualitative synthesis identified consistent domains influencing platform adoption, primarily related to intrinsic robot strengths and limitations, surgeon-robot interaction, intraoperative characteristics, and economic considerations. A secondary qualitative analysis further contextualized these findings within ventral hernia surgery, highlighting domains related to abdominal wall reconstruction, mesh-based repair, workflow adaptability, and learning-curve progression. Across studies, emerging platforms demonstrated clinical feasibility with four conversions reported overall (3 in Hugo and 1 in Versius). Operative time ranged from 39 to 450 minutes, while docking time varied from 10 to 30 minutes. Perioperative outcomes were generally favorable, with isolated complications reported, including seroma, hematoma, urinary retention, wound infection, and drain-related complications, and no recurrences observed during short-term follow-up (7-310 days).
Conclusion:
New robotic platforms for ventral hernia repair demonstrate early clinical feasibility with favorable short-term outcomes. Current evidence remains limited, and further prospective comparative studies are required to clarify their role in robotic abdominal wall surgery.