Related Experiment Video
Updated: May 11, 2026

Dynamic Clamp Methods to Investigate Impaired Neuronal Excitability Associated with Autism
Published on: October 17, 2025
A mode-dependent approach to state estimation of recurrent neural networks with Markovian jumping parameters and
He Huang1, Tingwen Huang, Xiaoping Chen
1School of Electronics and Information Engineering, Soochow University, Suzhou 215006, PR China. cshhuang@gmail.com

Abstract:
This paper is concerned with the problem of state estimation of recurrent neural networks with Markovian jumping parameters and mixed delays. A mode-dependent approach is proposed by constructing a novel Lyapunov functional, where some terms involving triple or quadruple integrals are taken into account. The advantage is that as many as possible of the Lyapunov matrices are chosen to be mode-dependent. Several design criteria are established under which the estimation error system is globally exponentially stable in the mean square sense. The gain matrices of the state estimator can be then found by solving a set of coupled linear matrix inequalities. It is shown in theory that better performance can be achieved by this approach. Furthermore, by introducing some scaling parameters, this approach is effectively employed to deal with the state estimation problem of the neural networks with complex dynamic behaviors, to which some existing results are not applicable.
Related Concept Videos
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:06
Model Approaches for Pharmacokinetic Data: Distributed Parameter Models
The distributed parameter models are specifically designed to account for variations and differences in some drug classes. This model is particularly useful for assessing regional concentrations of anticancer or...
 01:27
State Space Representation
Consider an RLC circuit, a...
 01:21
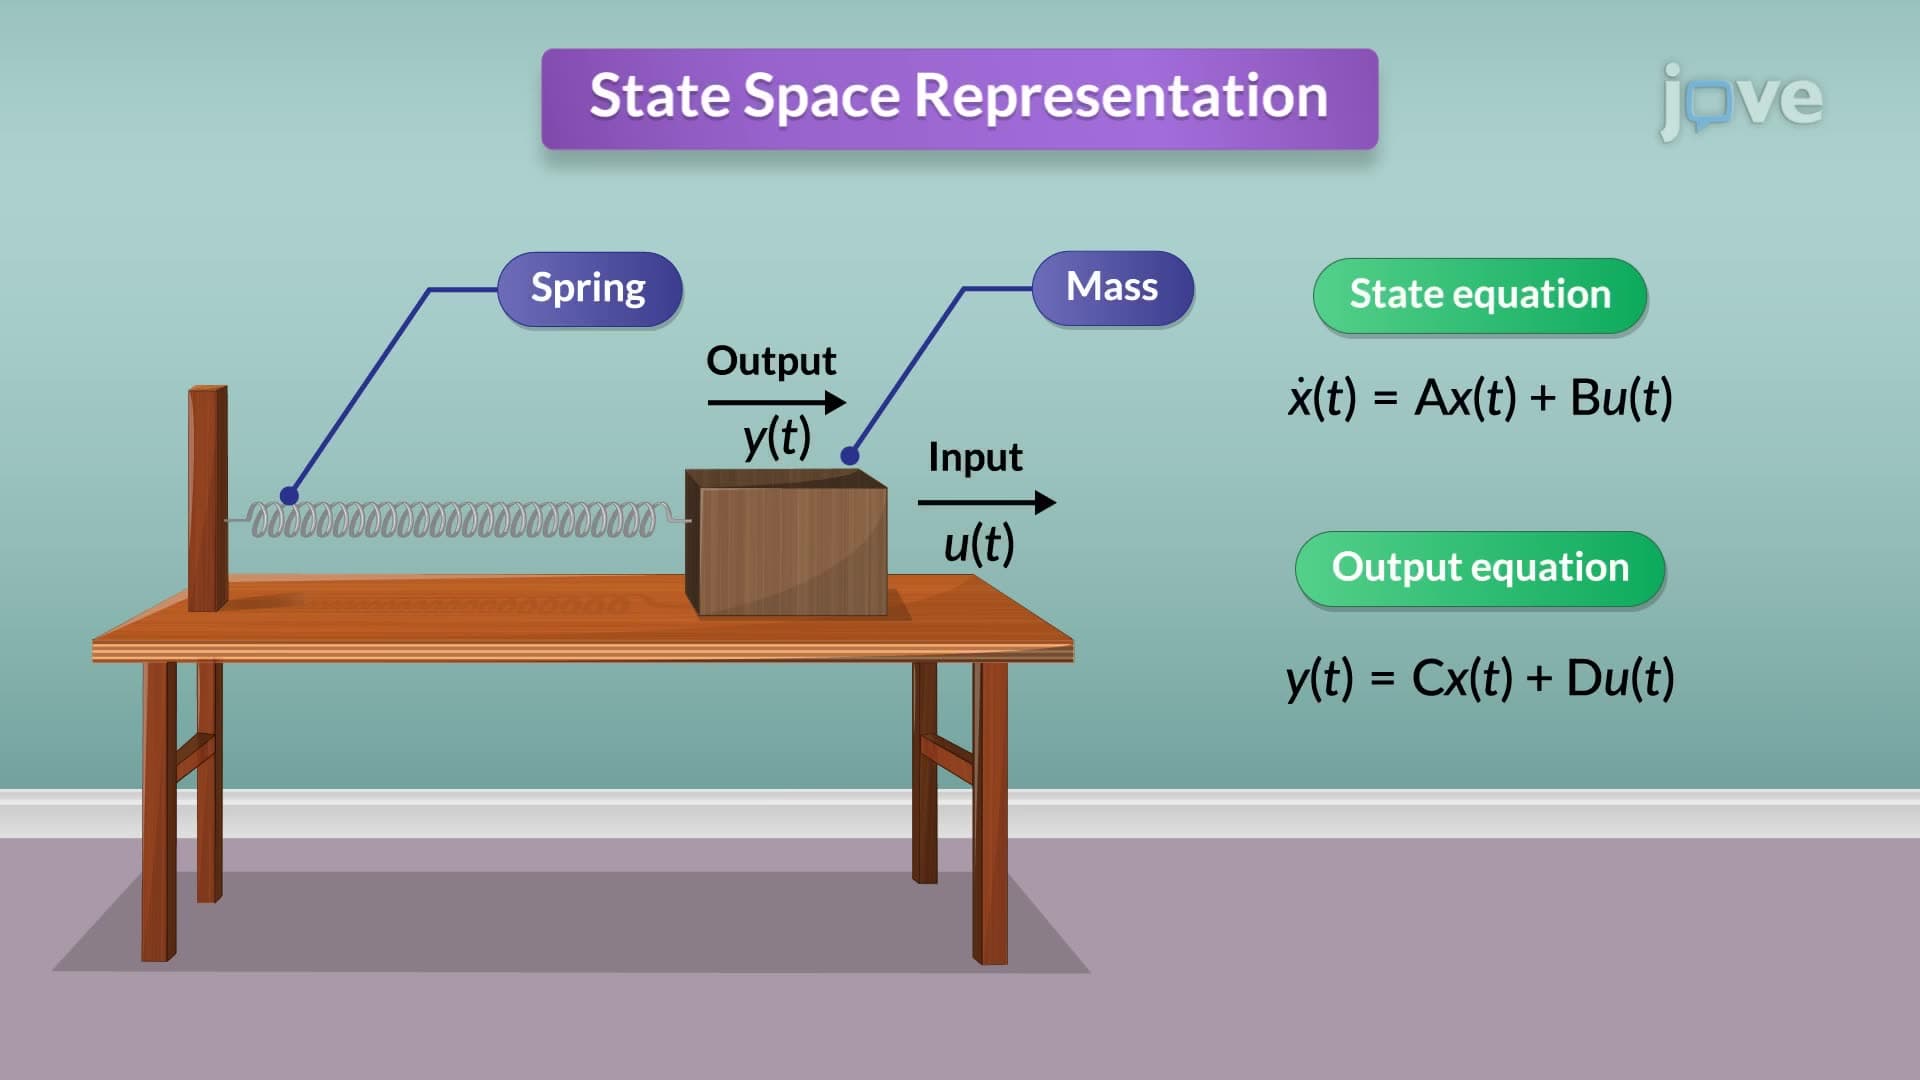
State Space to Transfer Function
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
 01:13
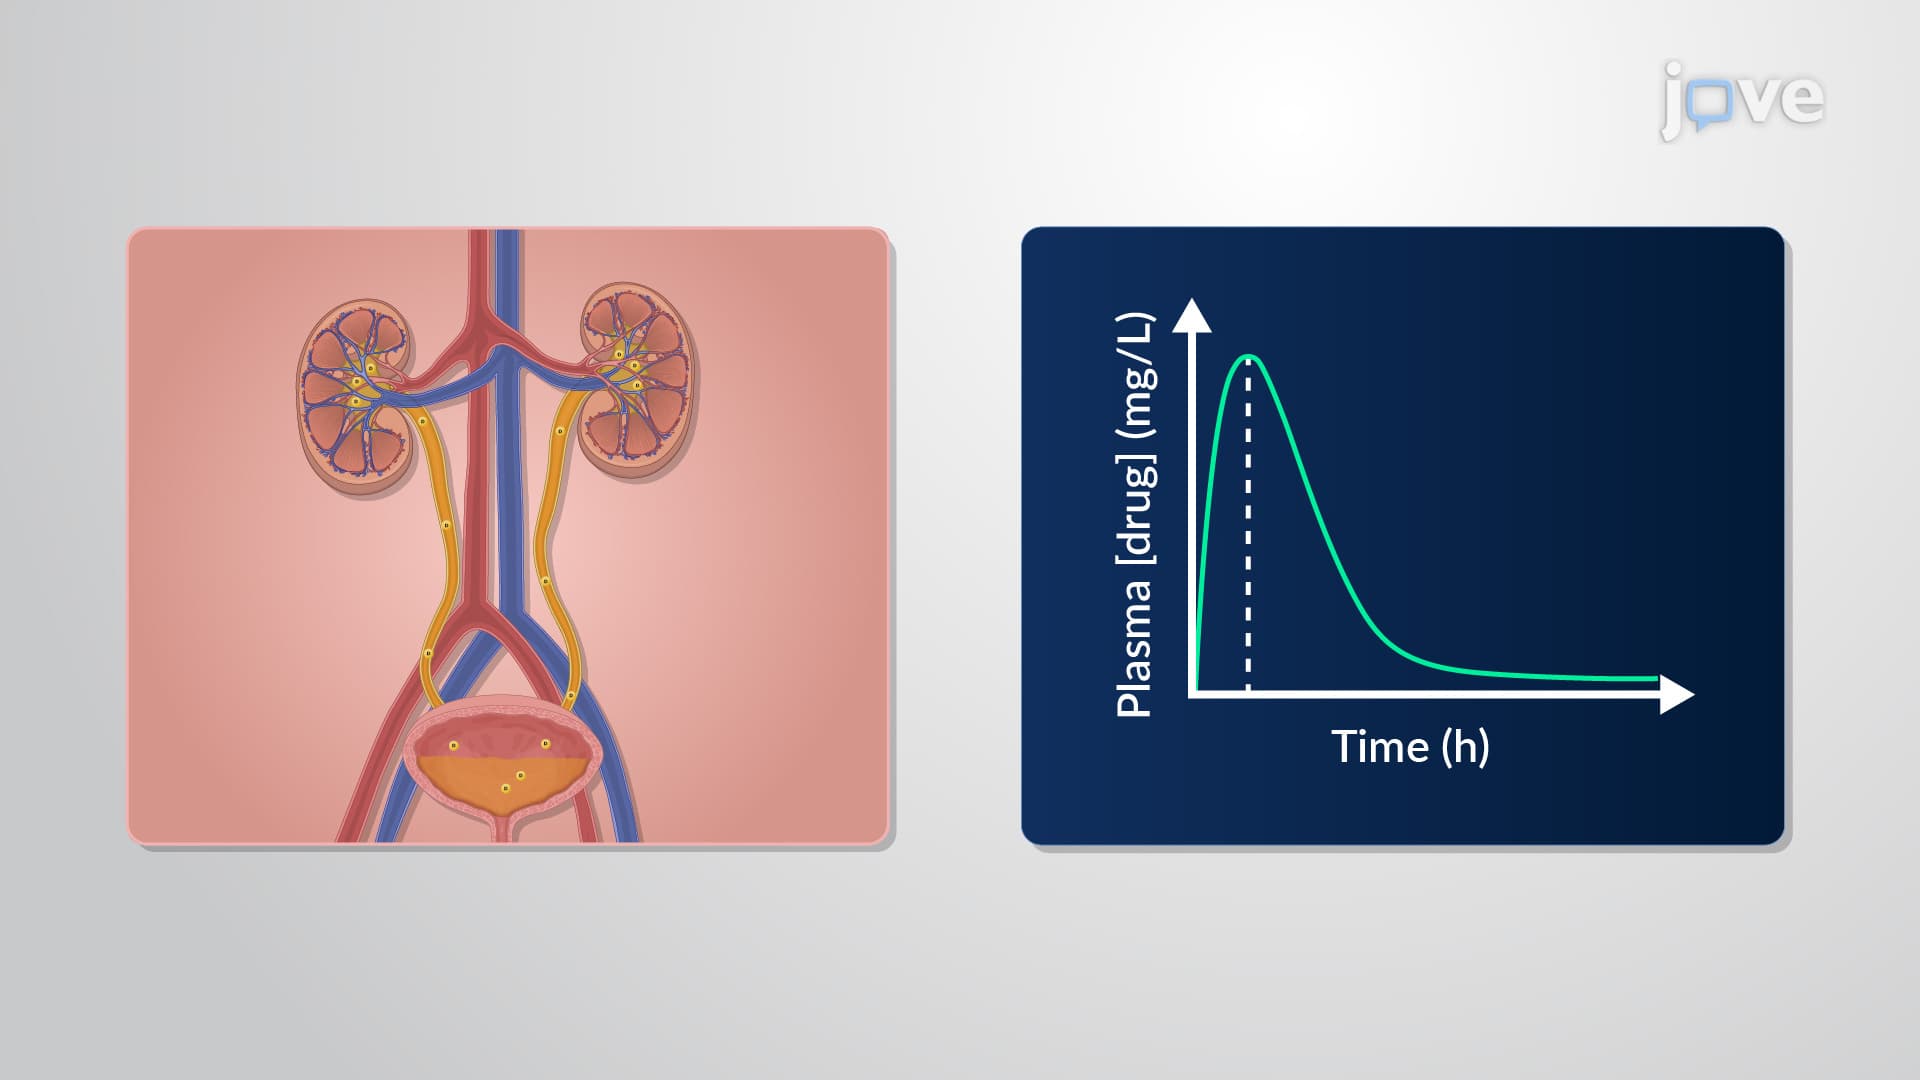
Parameters Affecting Nonlinear Elimination: Zero-Order Input, First-Order Absorption and Two-Compartment Model
When a drug is administered through a constant intravenous infusion and eliminated via nonlinear pharmacokinetics, it follows zero-order input. For example, oral drugs undergo first-order absorption upon administration and are eliminated through nonlinear pharmacokinetics.
In the case of subcutaneously administered drugs,...
 01:23
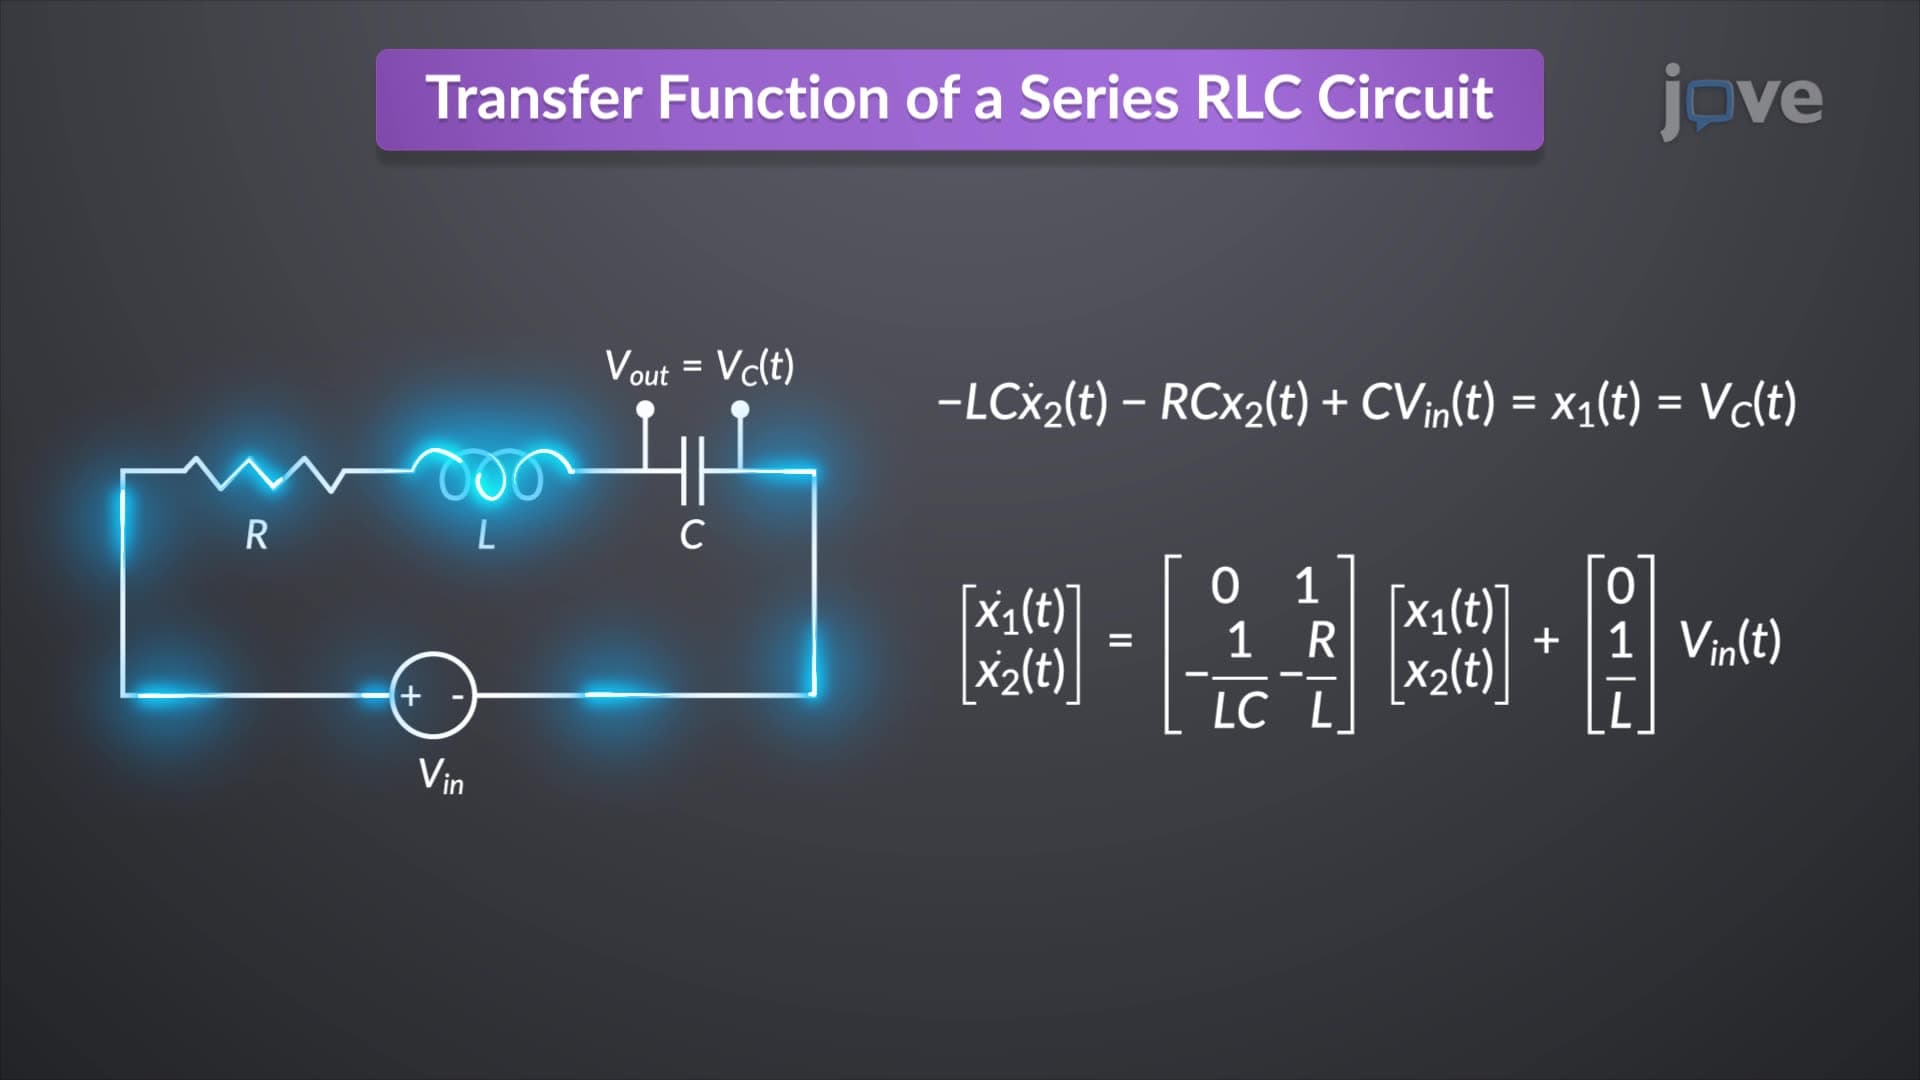
Transfer Function to State Space
In an RLC...