Related Experiment Video
Updated: May 9, 2026

A Protocol for Comprehensive Assessment of Bulbar Dysfunction in Amyotrophic Lateral Sclerosis (ALS)
Published on: February 21, 2011
On smoothing articulatory trajectories obtained from Gaussian mixture model based acoustic-to-articulatory inversion
Prasanta K Ghosh1, Shrikanth S Narayanan
1Electrical Engineering, Indian Institute of Science (IISc), Bangalore, Karnataka 560012, India. prasantg@ee.iisc.ernet.in

Abstract:
It is well-known that the performance of acoustic-to-articulatory inversion improves by smoothing the articulatory trajectories estimated using Gaussian mixture model (GMM) mapping (denoted by GMM + Smoothing). GMM + Smoothing also provides similar performance with GMM mapping using dynamic features, which integrates smoothing directly in the mapping criterion. Due to the separation between smoothing and mapping, what objective criterion GMM + Smoothing optimizes remains unclear. In this work a new integrated smoothness criterion, the smoothed-GMM (SGMM), is proposed. GMM + Smoothing is shown, both analytically and experimentally, to be identical to the asymptotic solution of SGMM suggesting GMM + Smoothing to be a near optimal solution of SGMM.
Related Concept Videos
 01:10
Reconstruction of Signal using Interpolation
 01:26
Orthogonal Trajectories
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:27
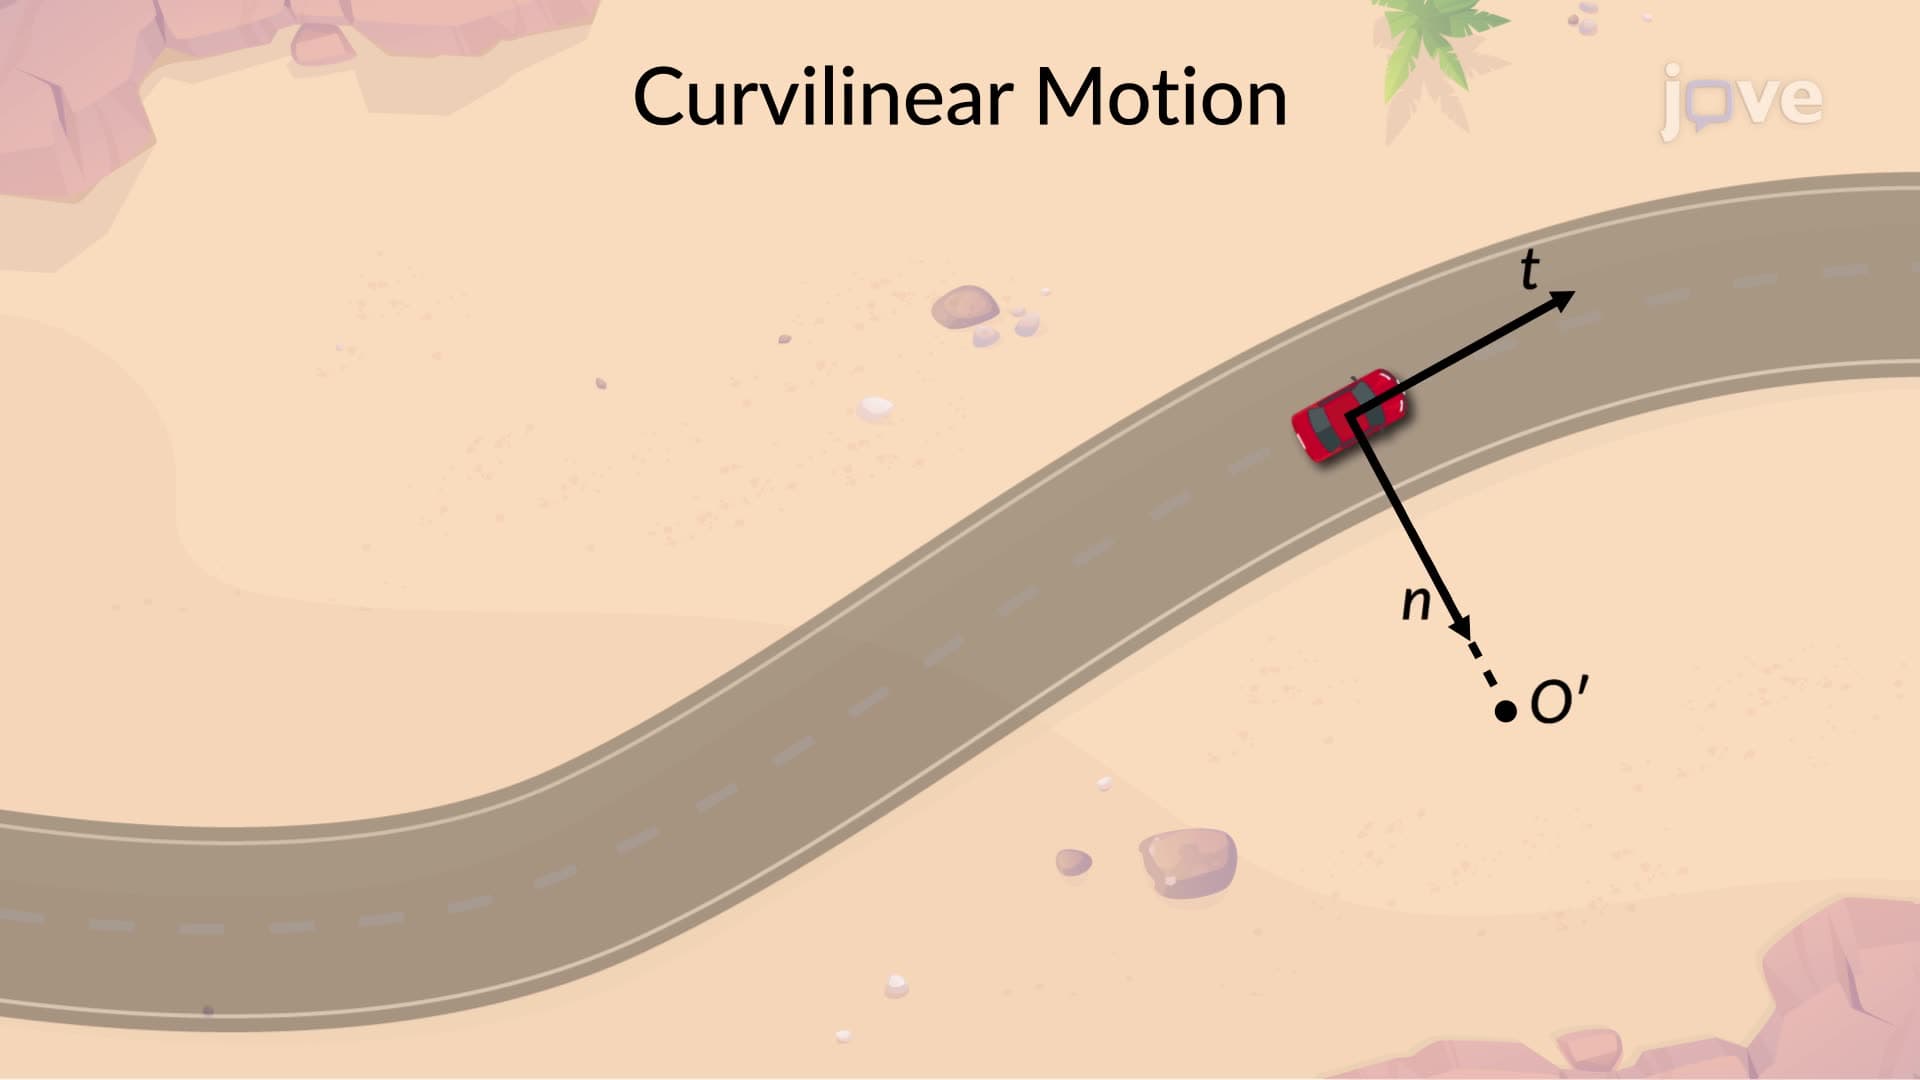
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:26
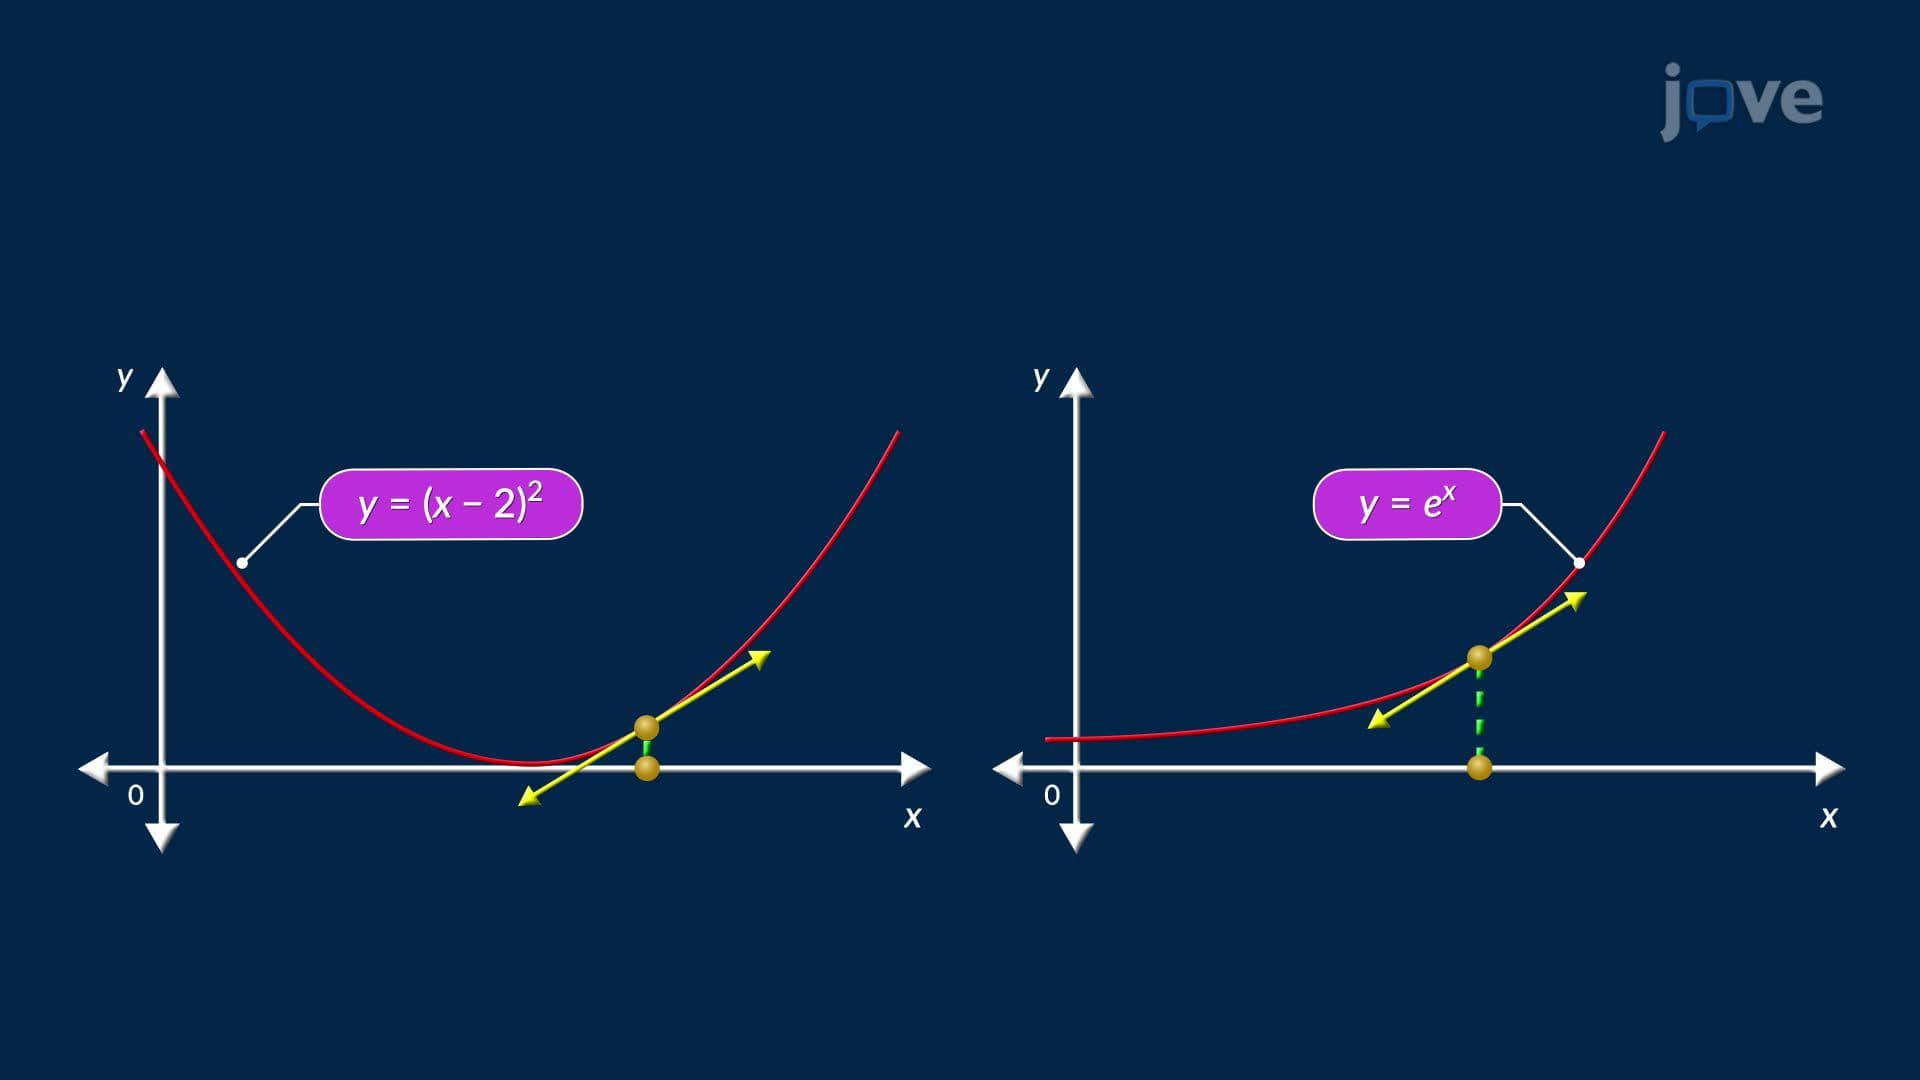
Linearization and Approximation
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.