Related Experiment Video
Updated: May 8, 2026
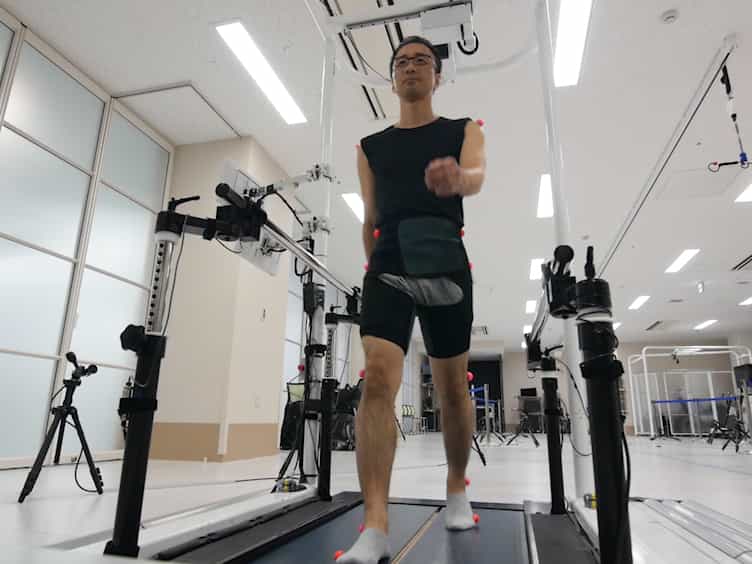

Clinical-oriented Three-dimensional Gait Analysis Method for Evaluating Gait Disorder
Published on: March 4, 2018
Monocular 3-D gait tracking in surveillance scenes

Abstract:
Gait recognition can potentially provide a noninvasive and effective biometric authentication from a distance. However, the performance of gait recognition systems will suffer in real surveillance scenarios with multiple interacting individuals and where the camera is usually placed at a significant angle and distance from the floor. We present a methodology for view-invariant monocular 3-D human pose tracking in man-made environments in which we assume that observed people move on a known ground plane. First, we model 3-D body poses and camera viewpoints with a low dimensional manifold and learn a generative model of the silhouette from this manifold to a reduced set of training views. During the online stage, 3-D body poses are tracked using recursive Bayesian sampling conducted jointly over the scene's ground plane and the pose-viewpoint manifold. For each sample, the homography that relates the corresponding training plane to the image points is calculated using the dominant 3-D directions of the scene, the sampled location on the ground plane and the sampled camera view. Each regressed silhouette shape is projected using this homographic transformation and is matched in the image to estimate its likelihood. Our framework is able to track 3-D human walking poses in a 3-D environment exploring only a 4-D state space with success. In our experimental evaluation, we demonstrate the significant improvements of the homographic alignment over a commonly used similarity transformation and provide quantitative pose tracking results for the monocular sequences with a high perspective effect from the CAVIAR dataset.
Related Concept Videos
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...